
Roshello Worldpythonros Noetic Python Cmakelist Csdn

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客
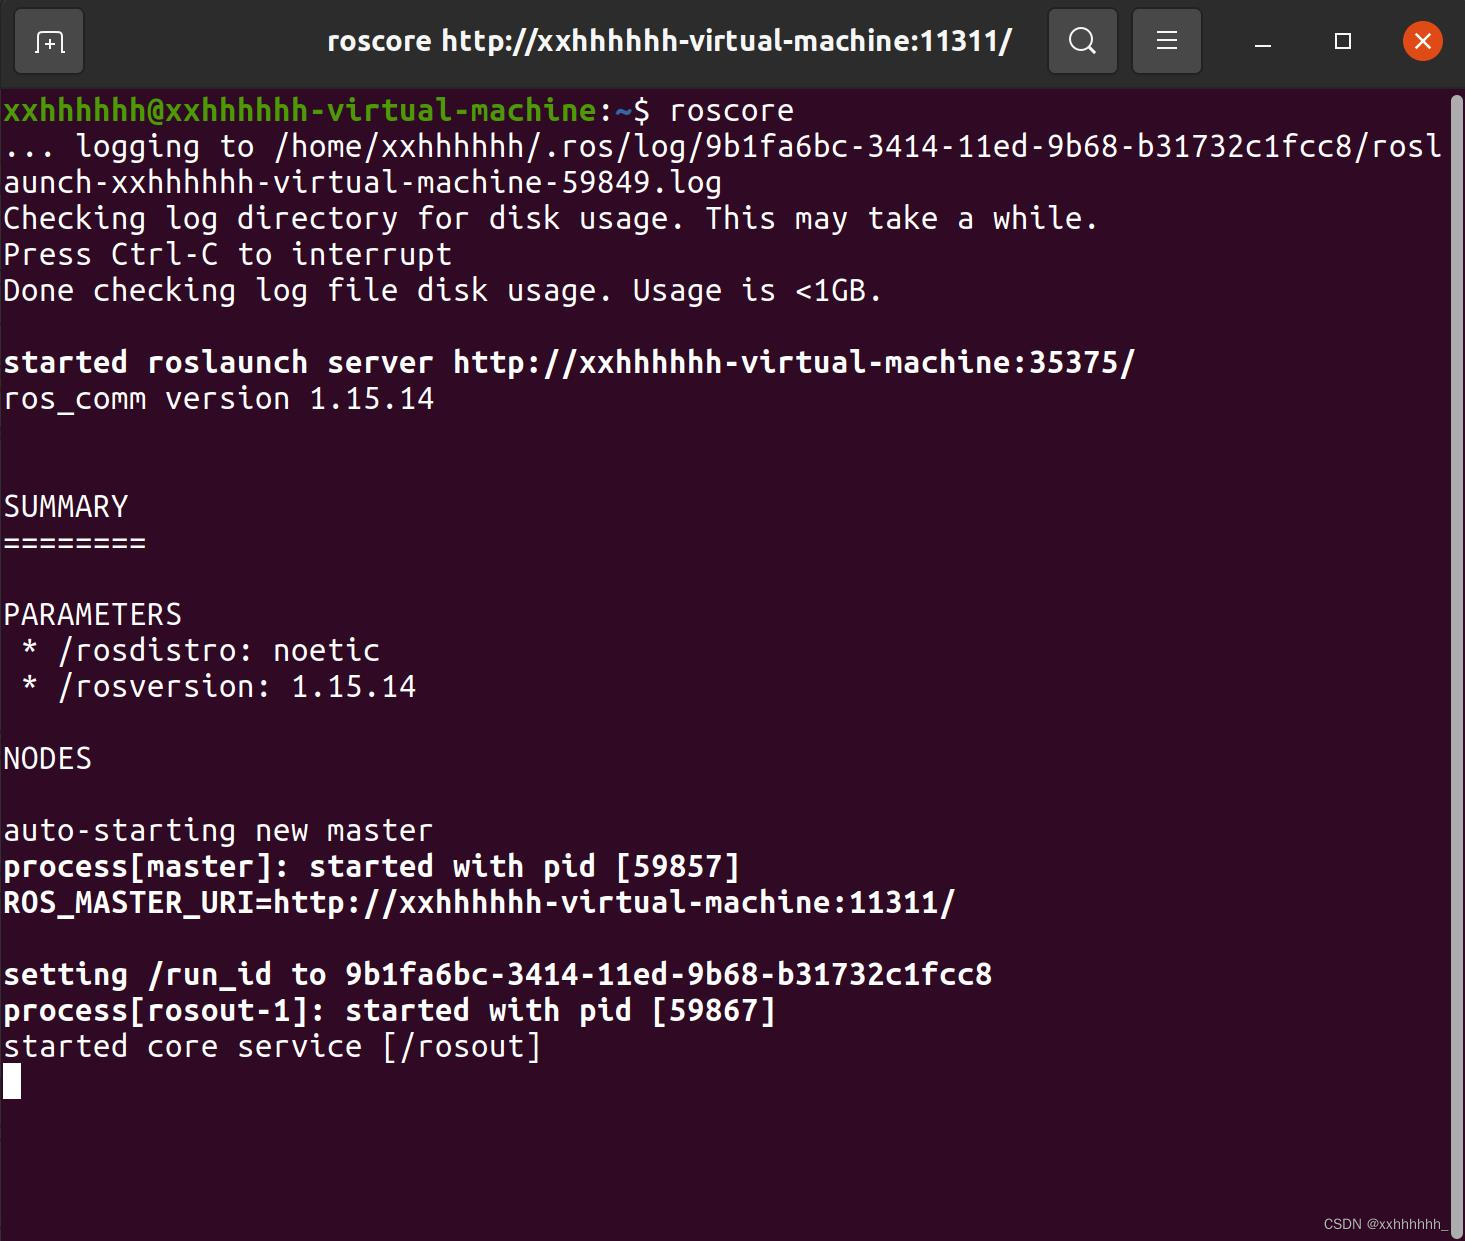
傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

傻瓜教程——ROS运行hello world(python版)_ros noetic python 的cmakelist-CSDN博客

Ros Noetic Python – Ros マニピュレータ Python – TSCPU
Ros Noetic Python – Ros Robot Tutorial – FMAQDW

GitHub - pubuduwanigasekara/robotics-with-ros: ROS Noetic | Python ...
Advertisement Space (300x250)
GitHub - pubuduwanigasekara/robotics-with-ros: ROS Noetic | Python ...

Programming ROS Subscribers In Python - ROS Noetic - YouTube
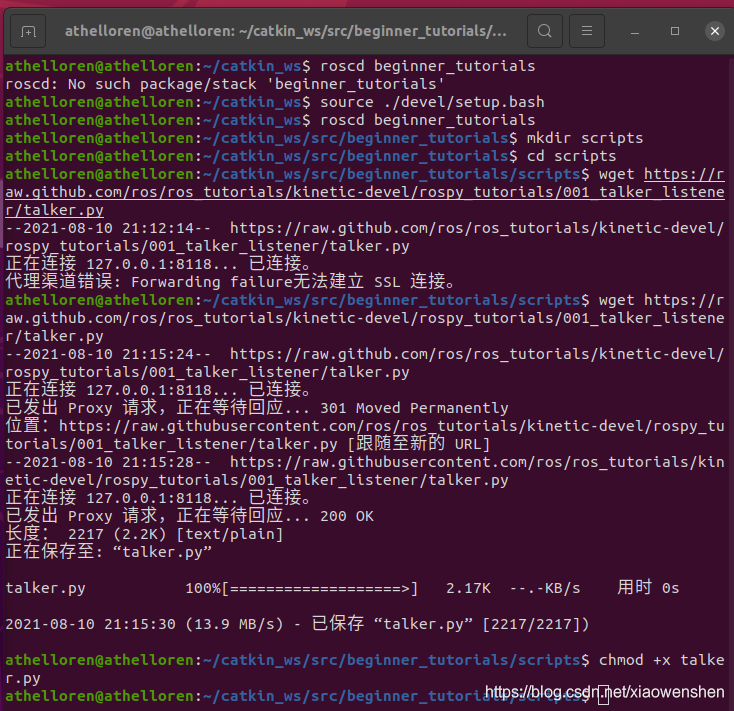
ROS Noetic入门笔记(七)使用Python编写简单的Publisher与Suscriber_ros noetic python代码写成 ...
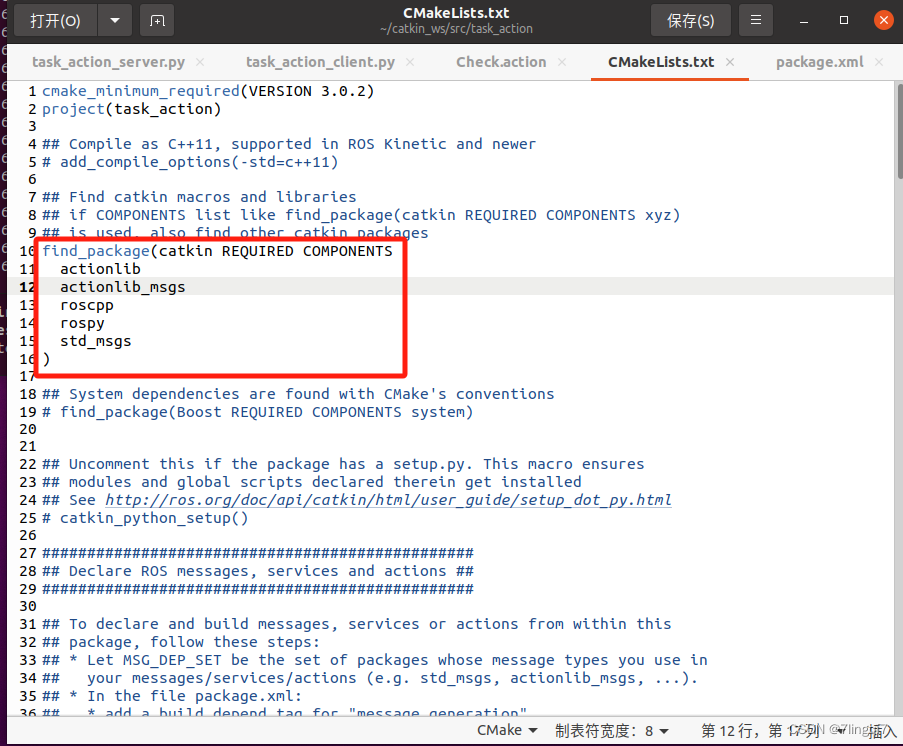
【ros实验三】使用 ROS 动作(Action)机制实现目标请求——实现零件完成度检测(python)_ros action python ...
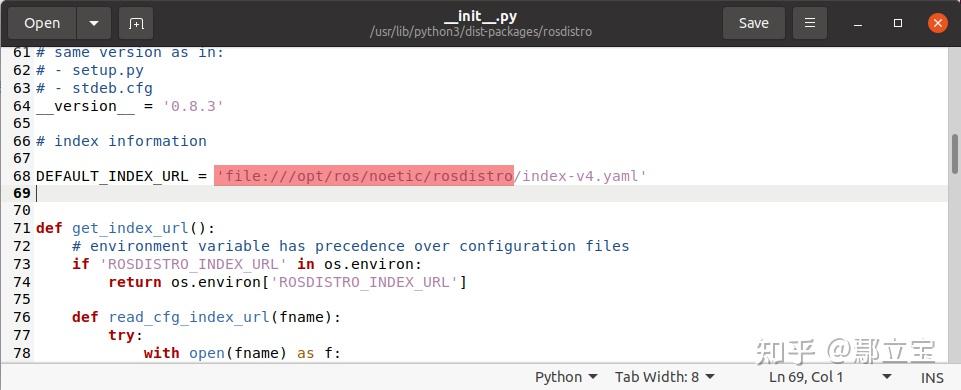
Ubuntu20.04.4安装ROS Noetic详细教程_ros noetic install-CSDN博客

roslaunch 报错 numpy与python版本冲突_ros noetic roslaunch 错误python-CSDN博客

roslaunch 报错 numpy与python版本冲突_ros noetic roslaunch 错误python-CSDN博客

Ros Noetic 20.04 跑通mpc_ros包保姆级教程_ros mpc-CSDN博客
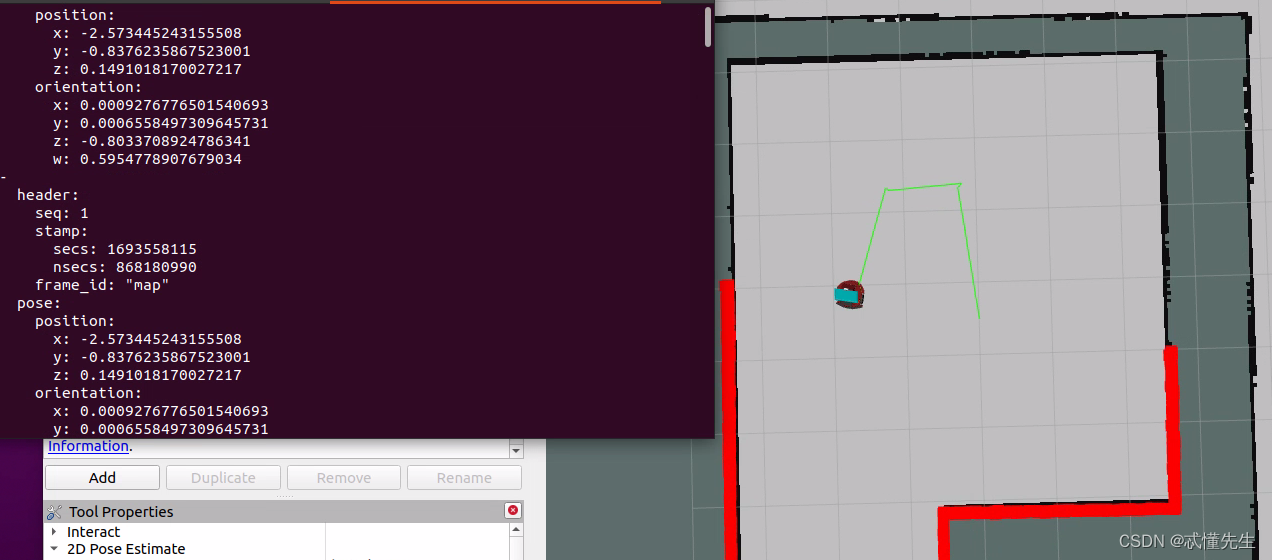
Ros noetic 机器人坐标记录运动路径和发布 实战教程(A)_ros记录路径-CSDN博客

Lesson 12: Set Predefined Positions for Your Robotic Arm in ROS Noetic ...
Advertisement Space (336x280)

ROS noetic 关于“无法定位软件包 python-serial”报错-CSDN博客
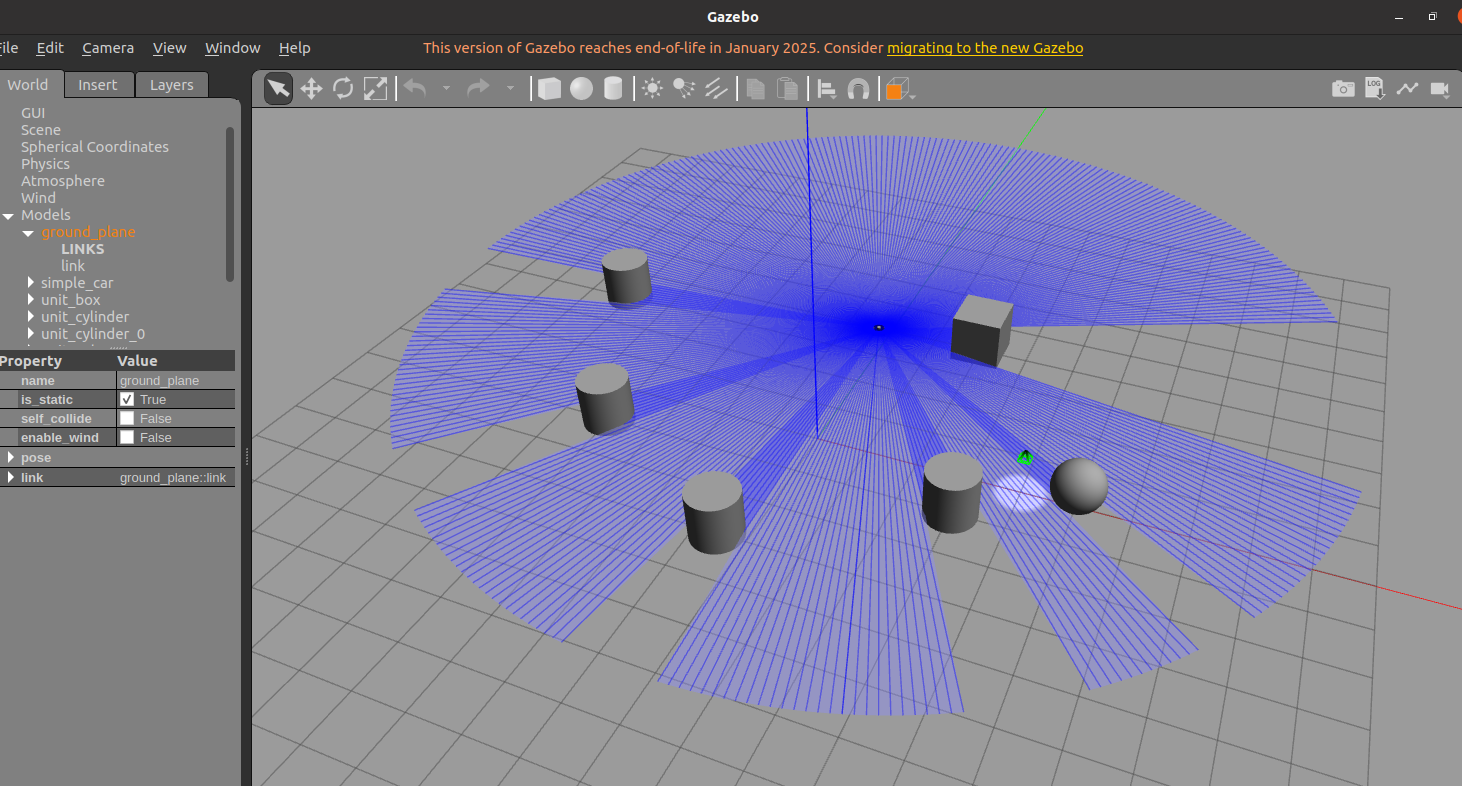
第13天 ROS Noetic Gazebo差速小车从零搭建|键盘遥控、雷达数据读取、Python自主节点全流程-CSDN博客
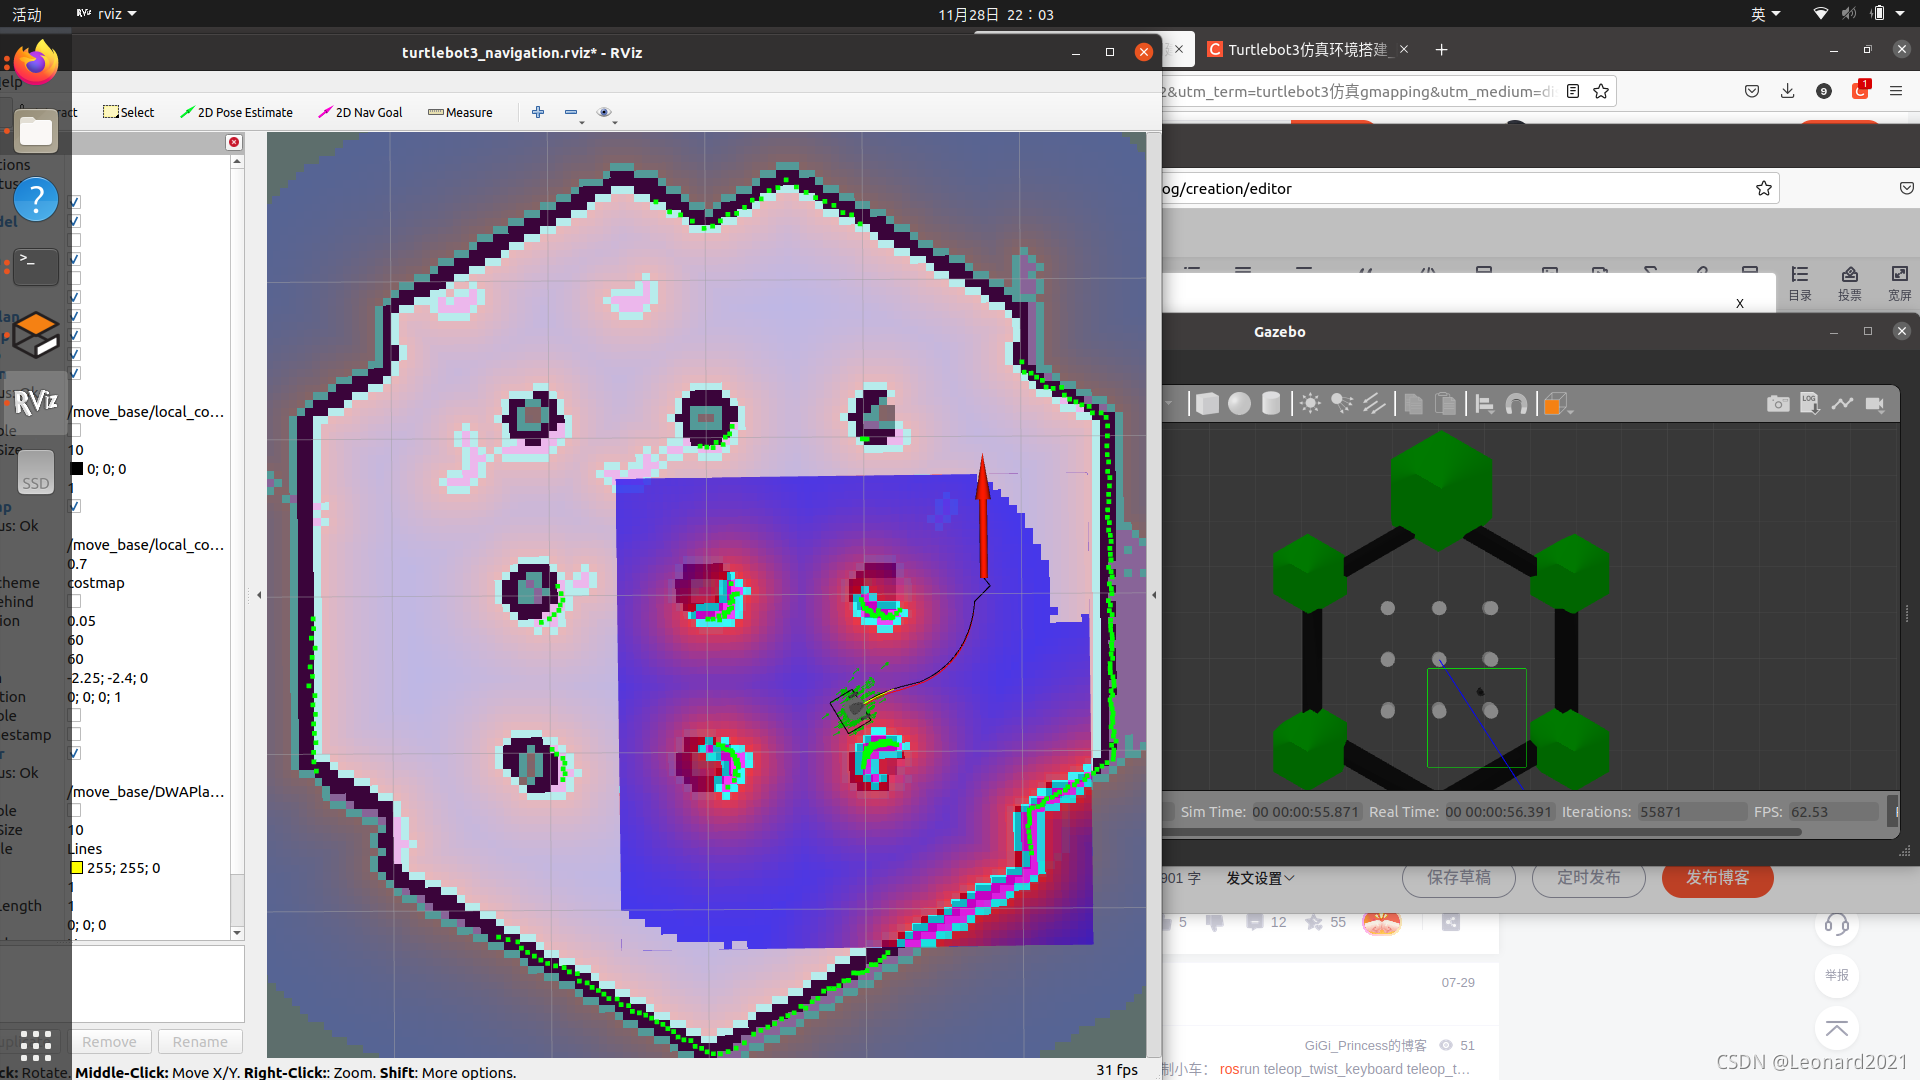
Ubuntu20.04 ROS Noetic 中使用turtlebot3仿真gmapping_ros noetic turtlebot-CSDN博客

【预测控制】【ROS Noetic + CoppeliaSim 】双臂抓取+静态/动态避障-CSDN博客
[ROS Q&A] How to import python modules from different ROS packages?
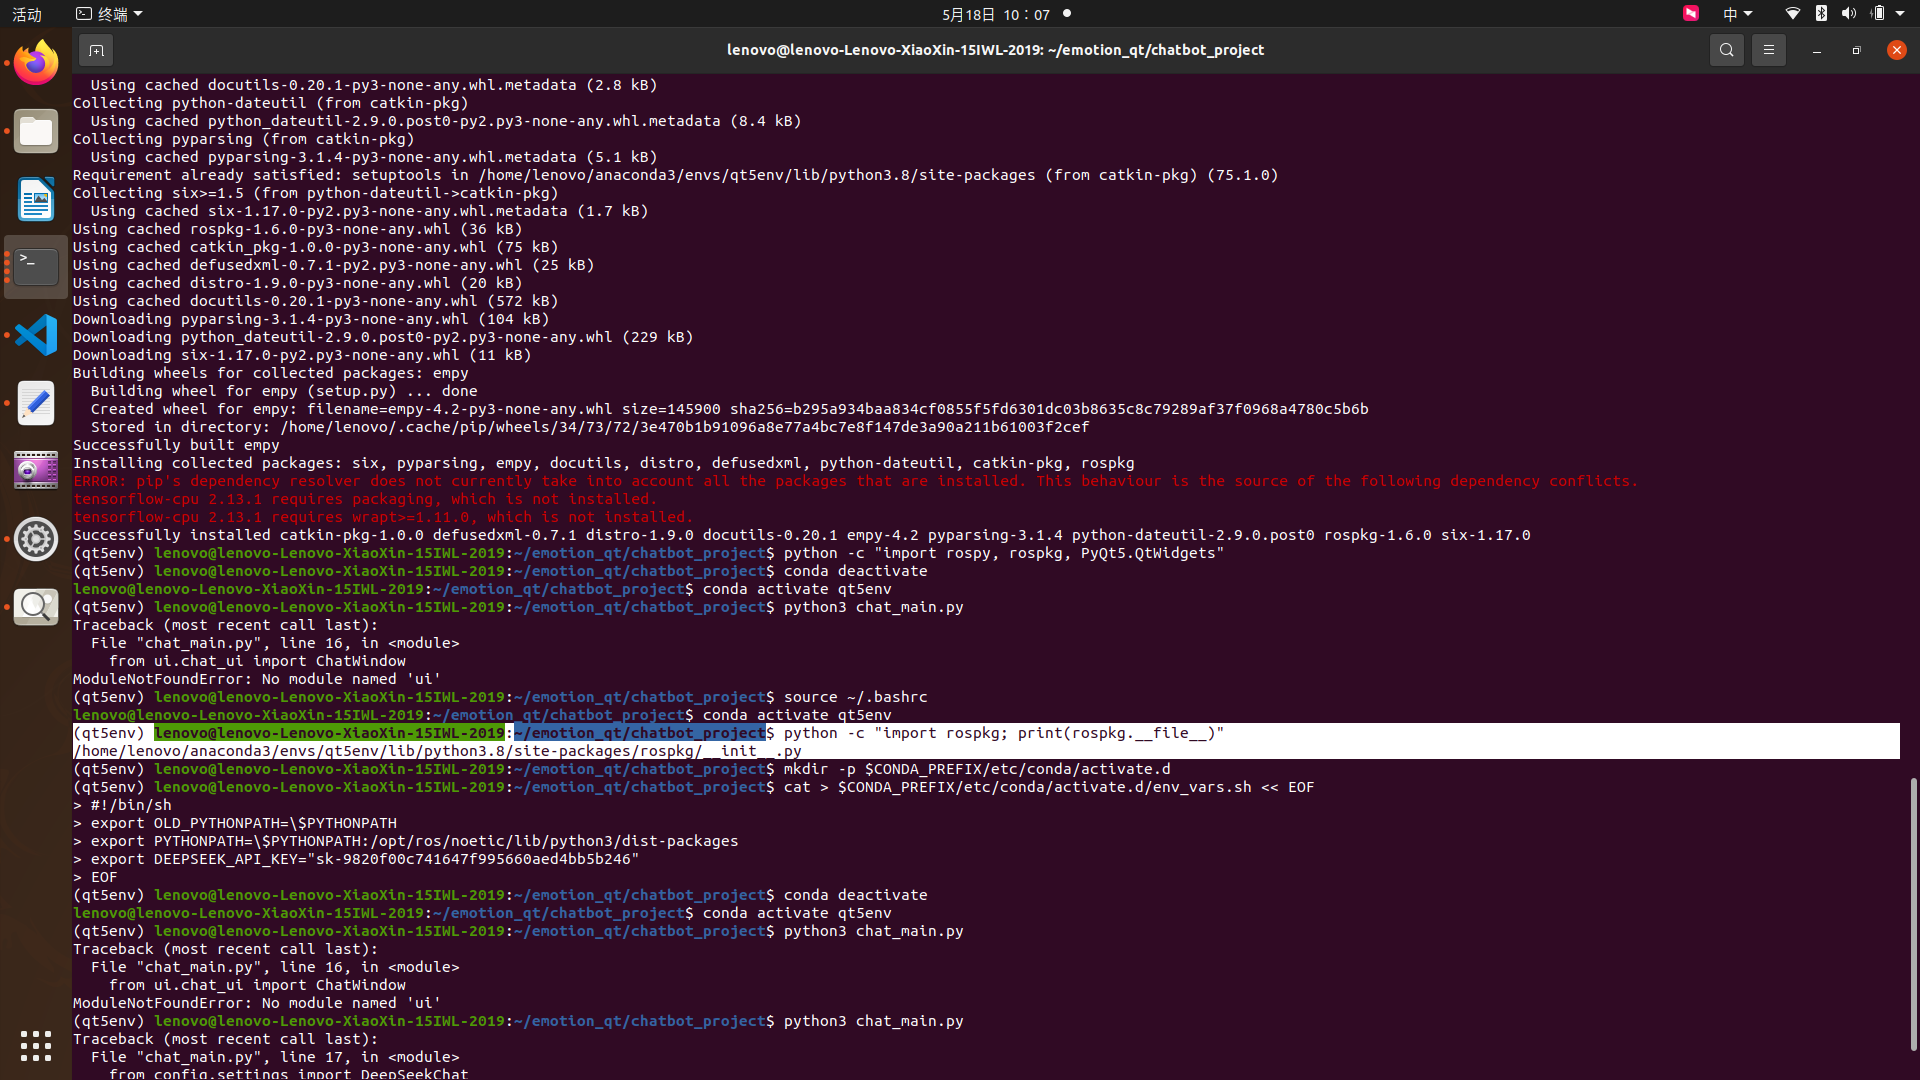
# 强制 conda 环境继承 ROS 的 Python 路径export PYTHONPATH=$PYTHONPATH:/opt/ros ...
Ultimate Robotics Programming with ROS 2 and Python

Multiple Publishers and subscribers in ROS | ROS Noetic Tutorial 5
How to set/get parameters from another node | ROS 2 Humble Python ...

ROS Tutorial #14 ROS Noetic Examining the Simple Publisher and ...
Advertisement Space (336x280)

kenetic ros创建python功能包时无法通过cmake_kinetic ros创建python功能包-CSDN博客

Tutorial: Build and run a new ROS package - PAL SDK 23.1 documentation
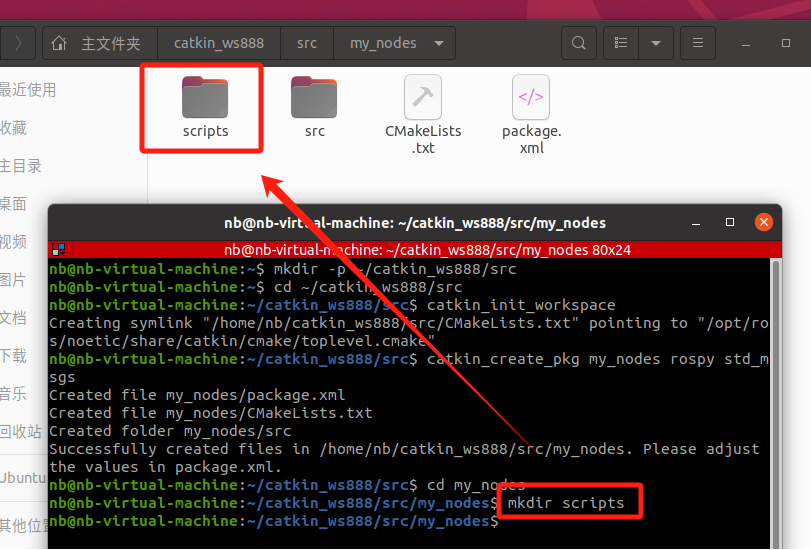
ROS入门之Node节点通信例程(ros1 noetic版本)-CSDN博客
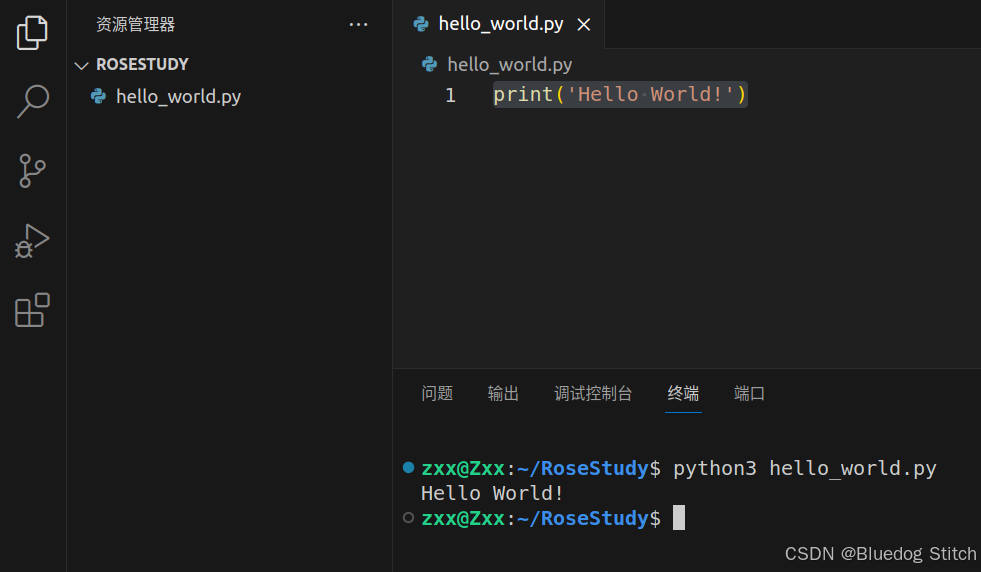
学习《ROS2机器人开发从入门到实践》Passage1_ros 2机器人开发从入门到实践-CSDN博客
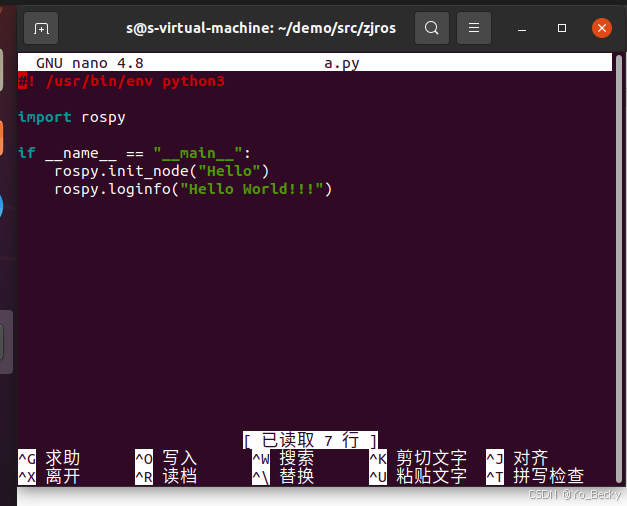
ROS入门详细教程——动手实现你的第一个程序:Hello World!_ros教程-CSDN博客

ROS1&ROS2之CmakeList.txt和package.xml用法详解_ros2 cmakelist-CSDN博客