
Runtime Ros Parameters Phntm Bridge Documentation
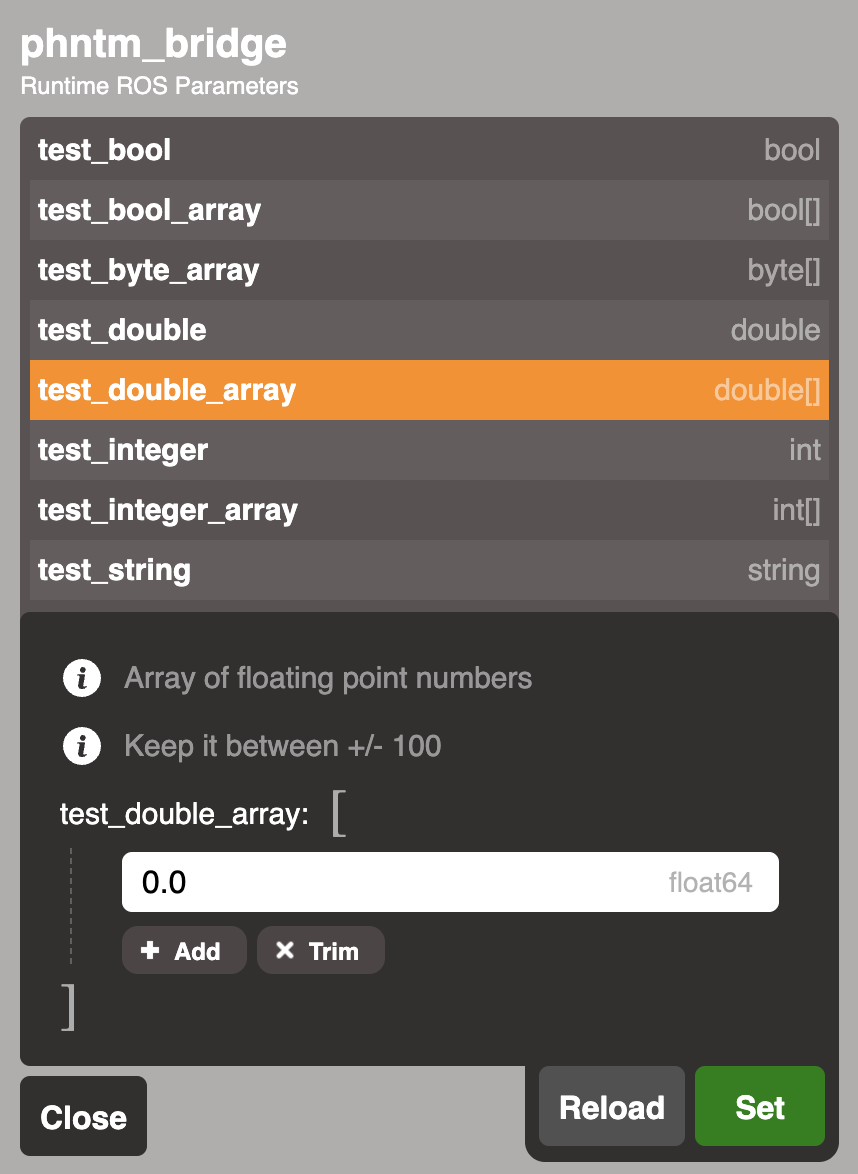
Runtime ROS Parameters / PHNTM Bridge Documentation
[ROS Q&A] How to load ROS parameters in Runtime | The Construct
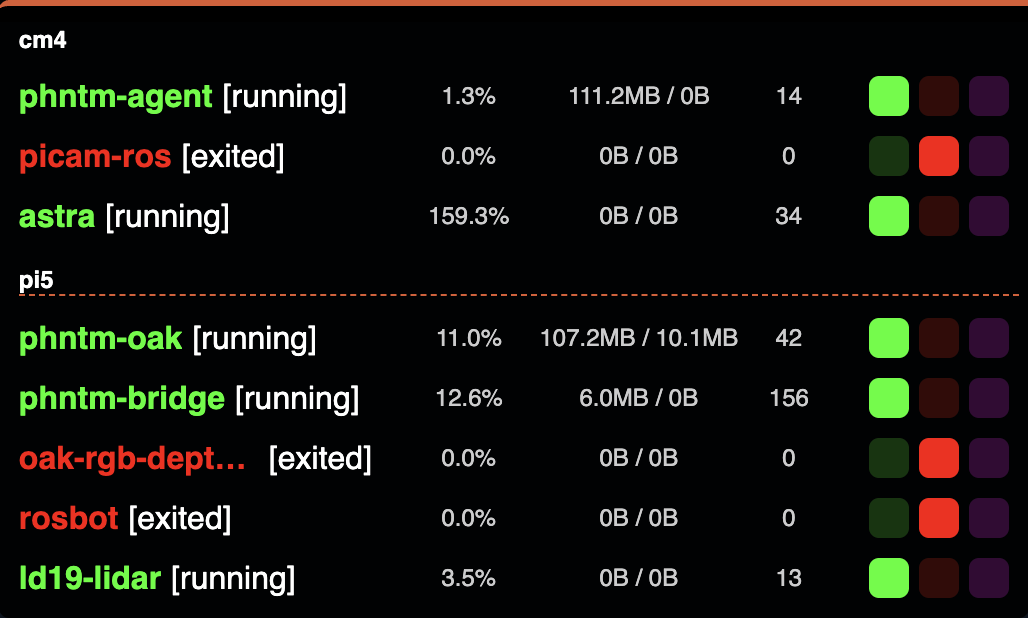
Docker Control / PHNTM Bridge Documentation

Understanding Parameters - ROS 2 Documentation - Humble Documentation ...
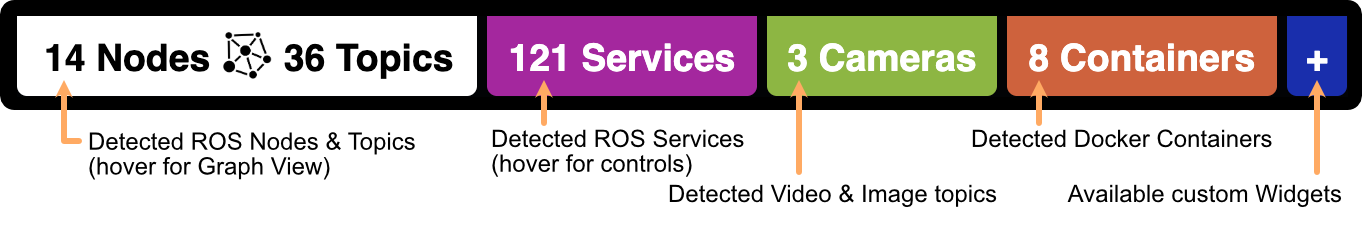
User Interface Overview / PHNTM Bridge Documentation

ROS Bridge API Documentation Guide | PDF | Metadata | Json
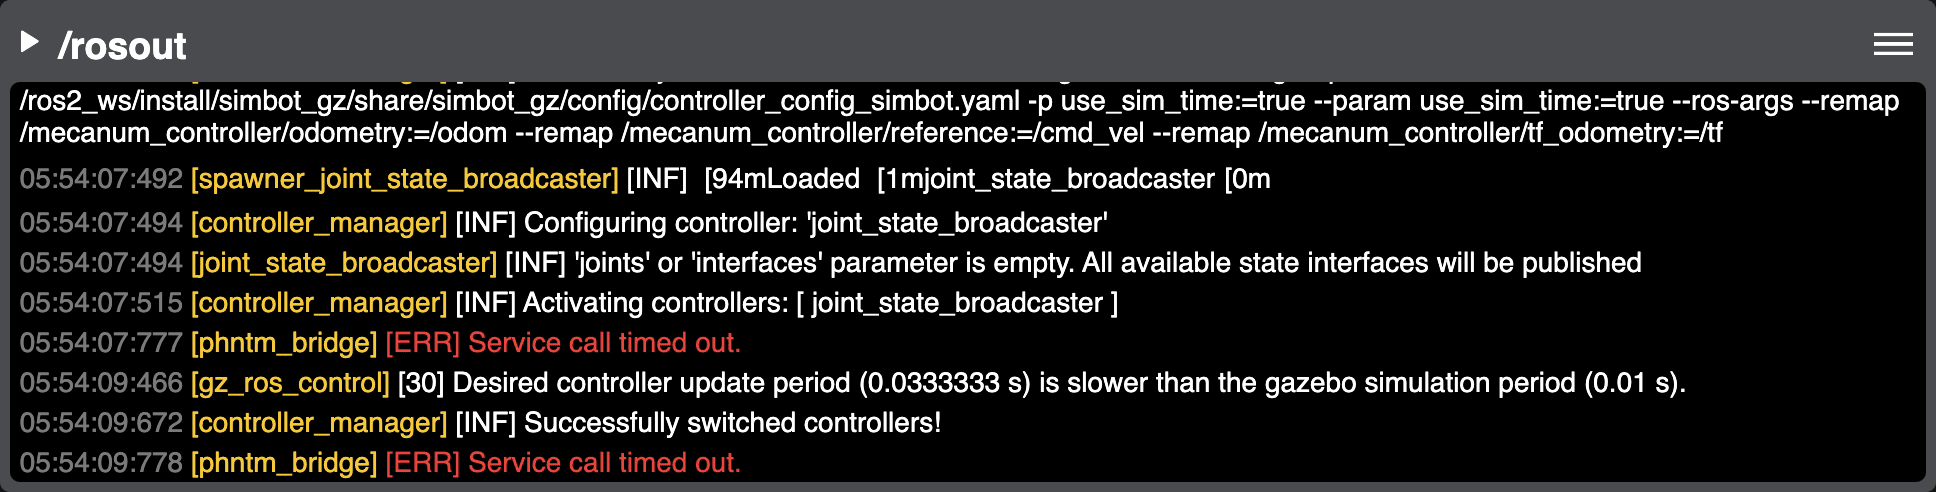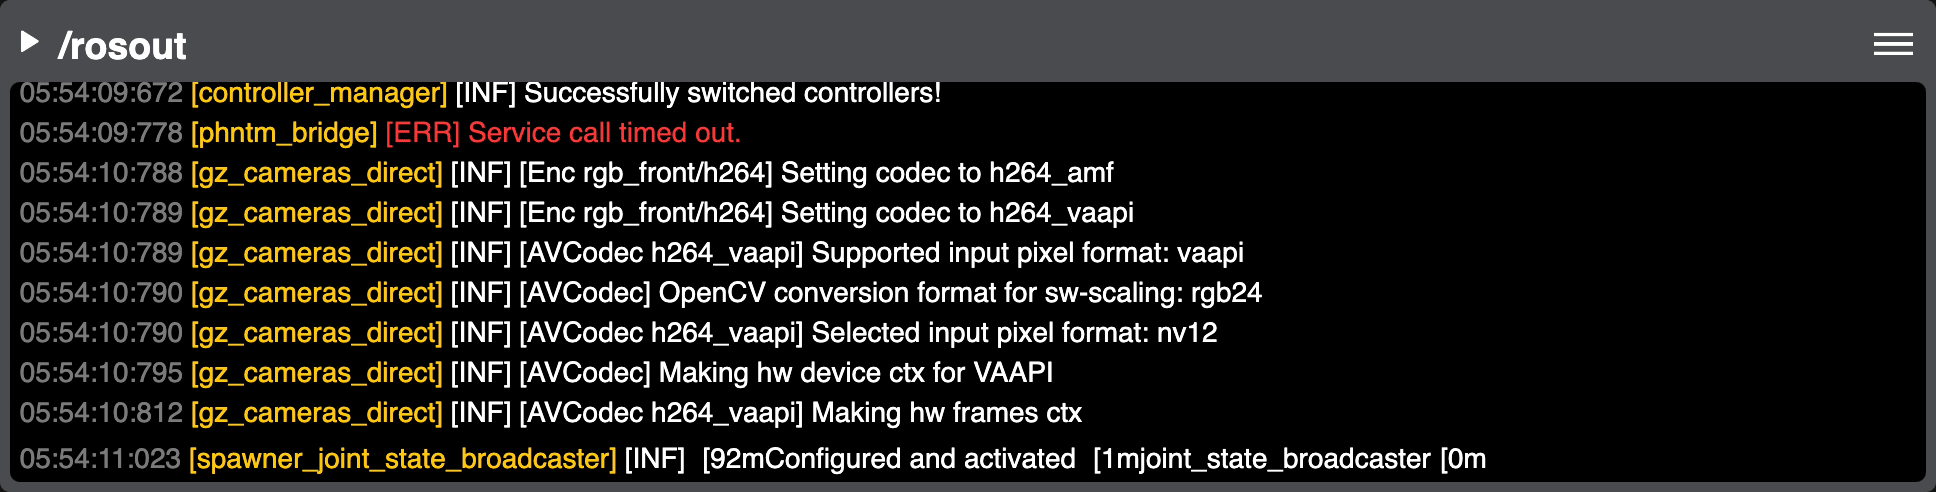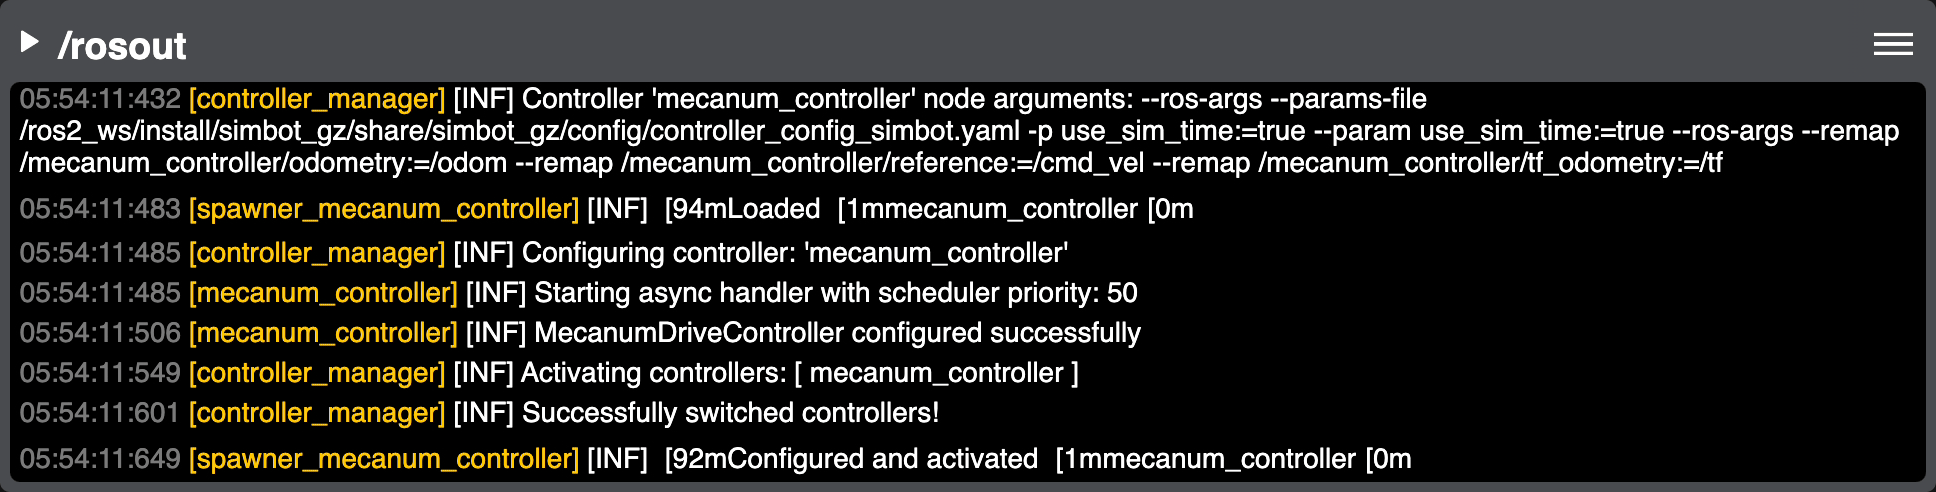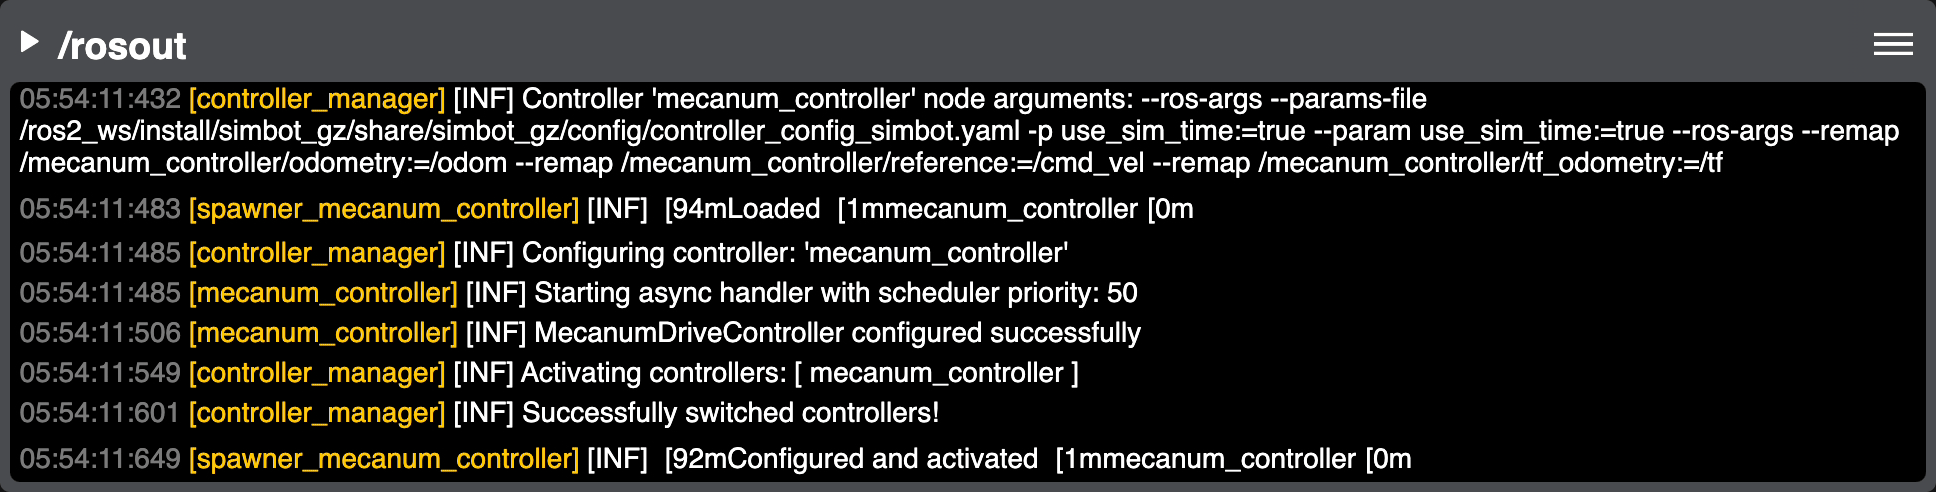
Log / PHNTM Bridge Documentation
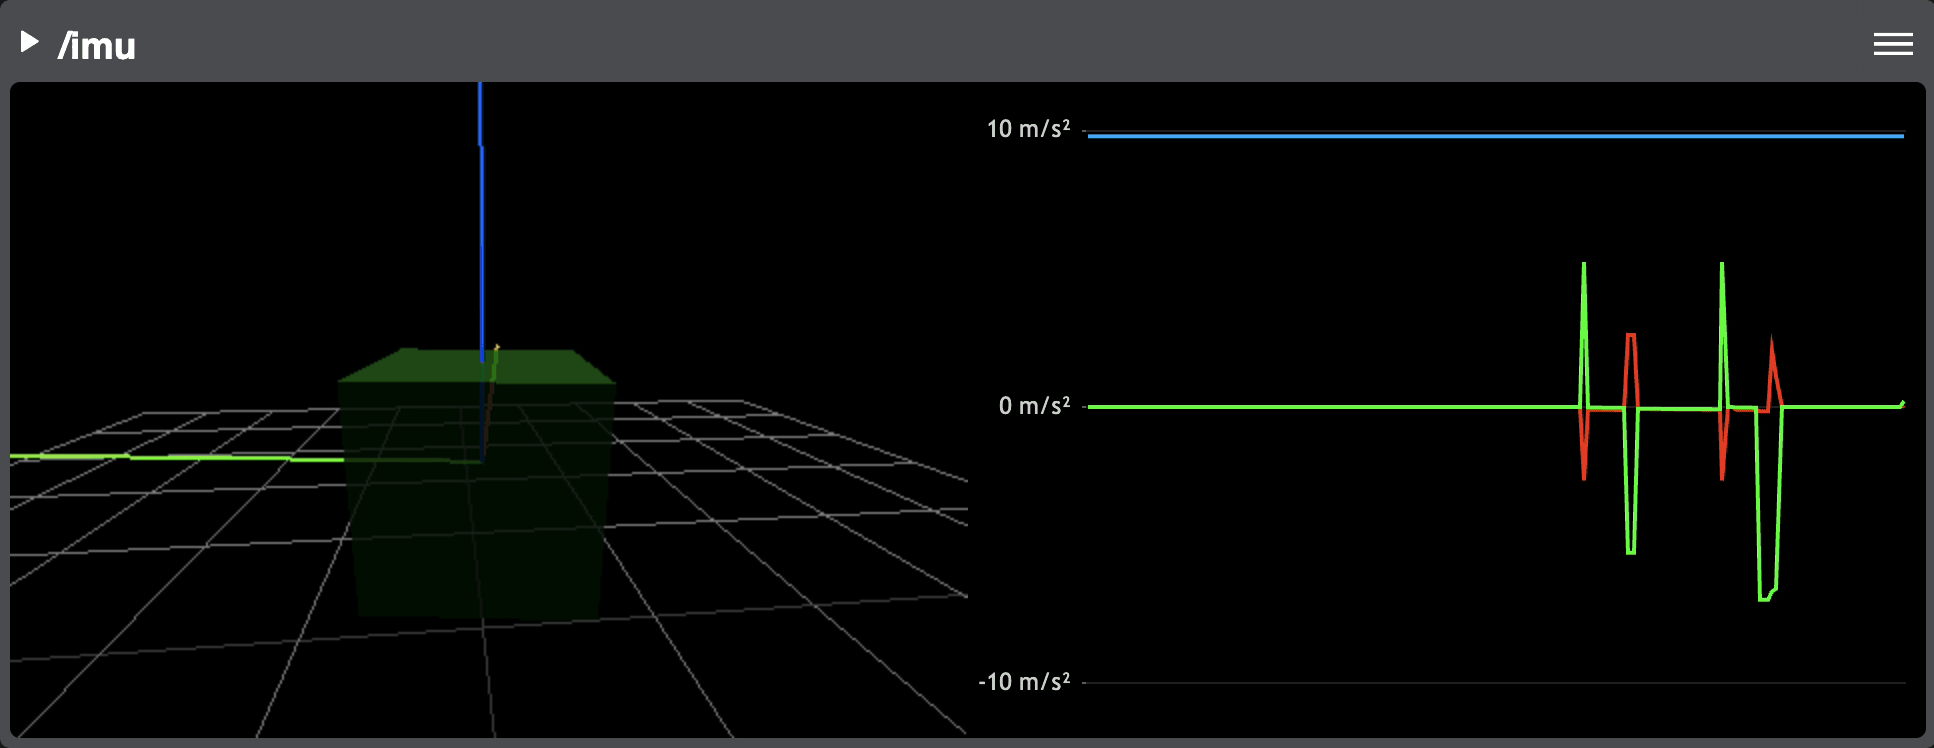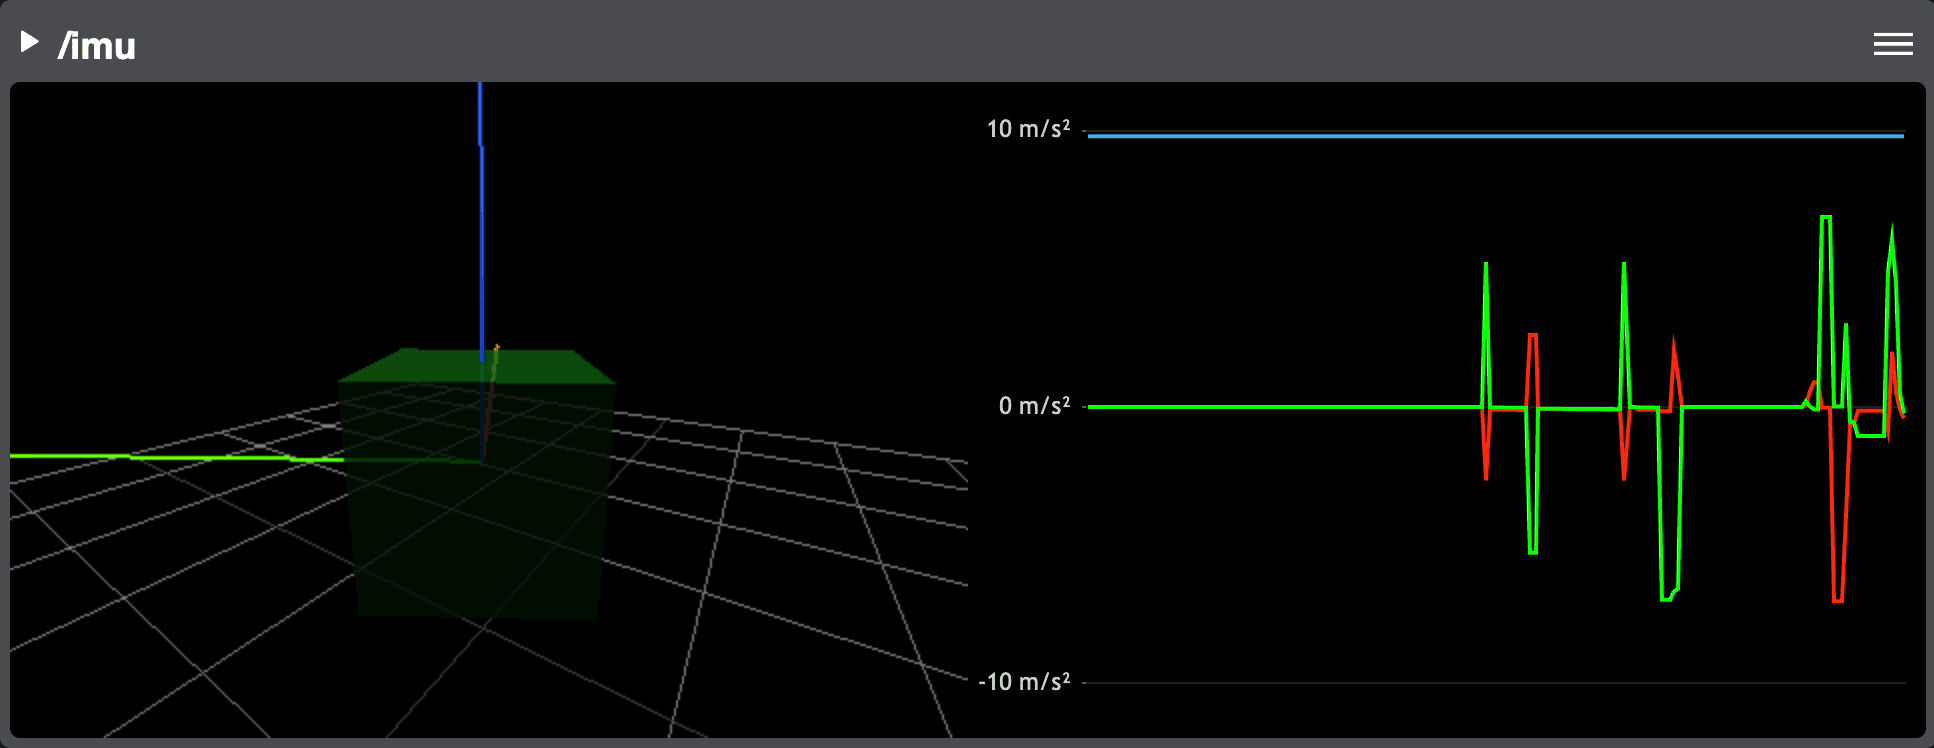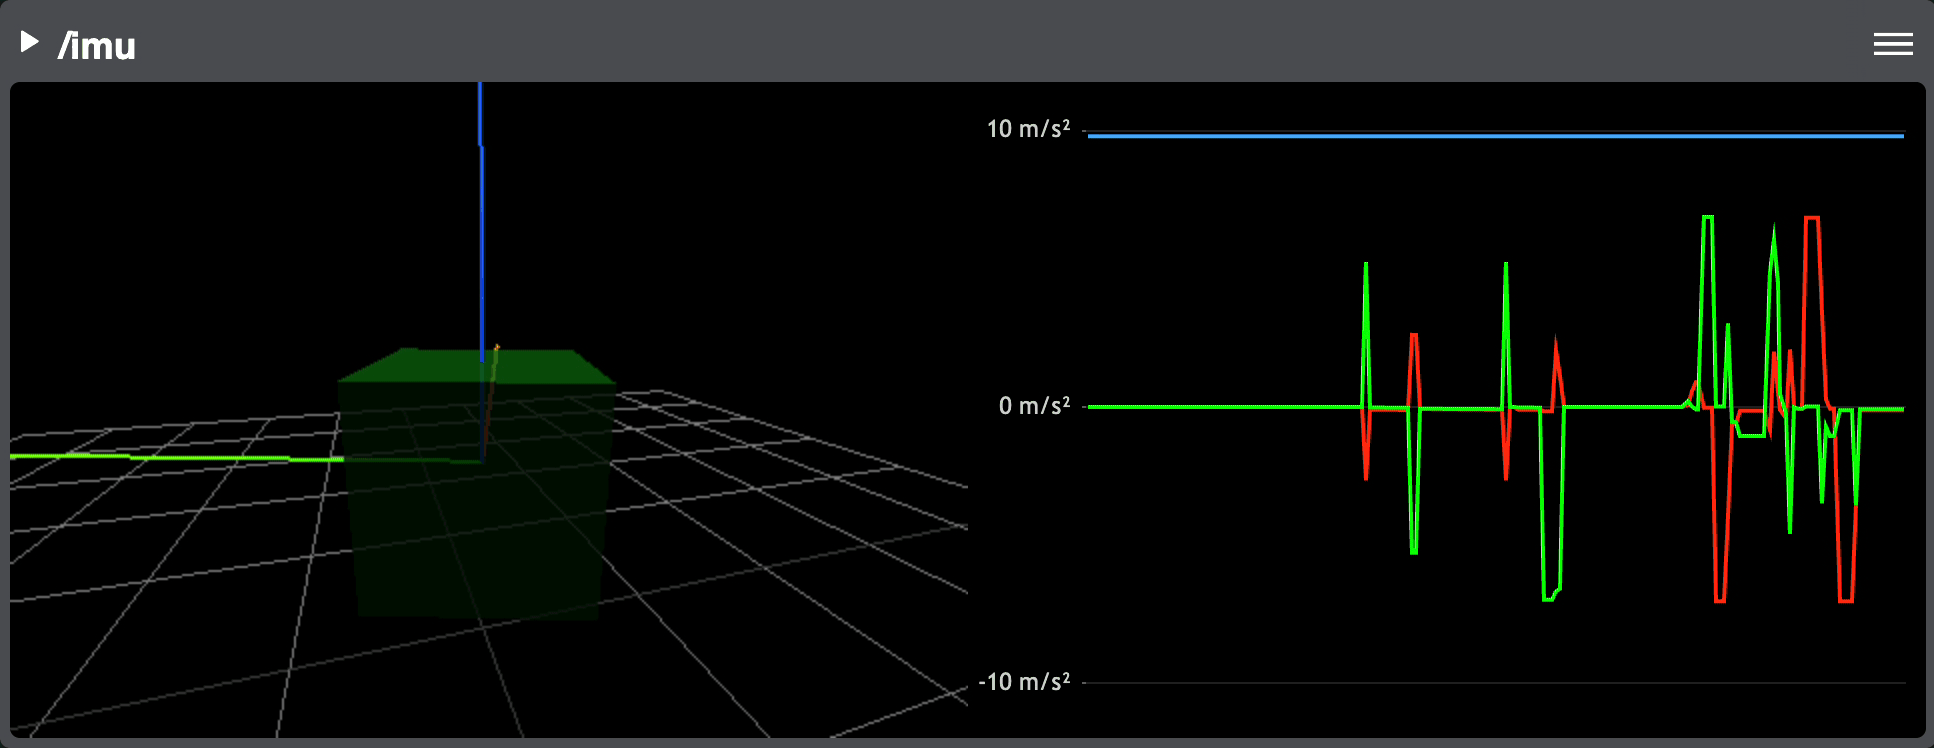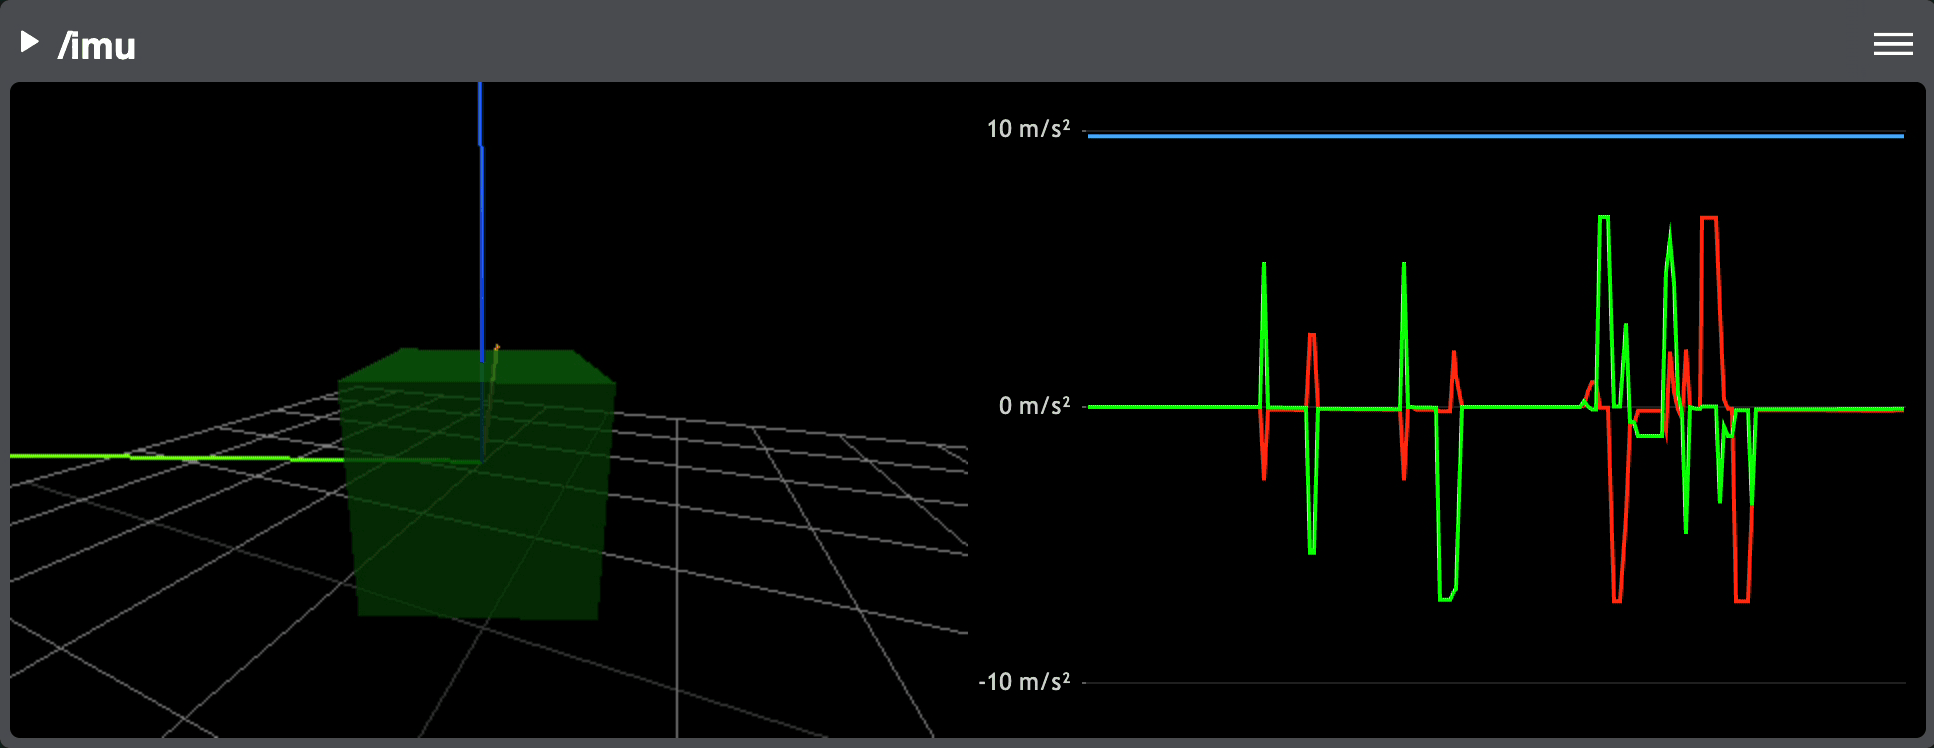
Imu / PHNTM Bridge Documentation
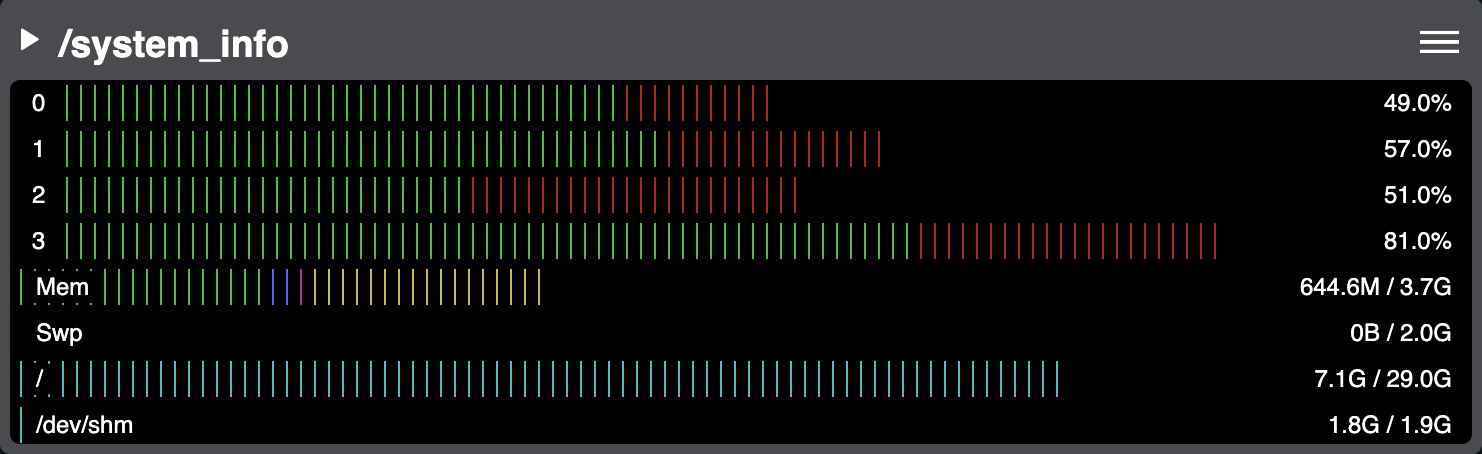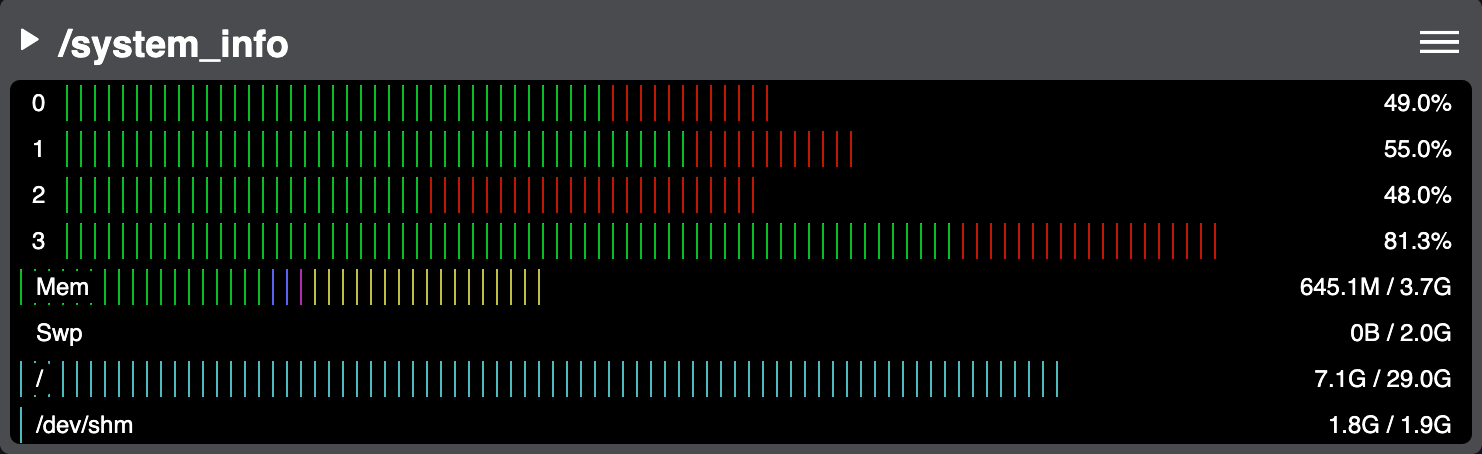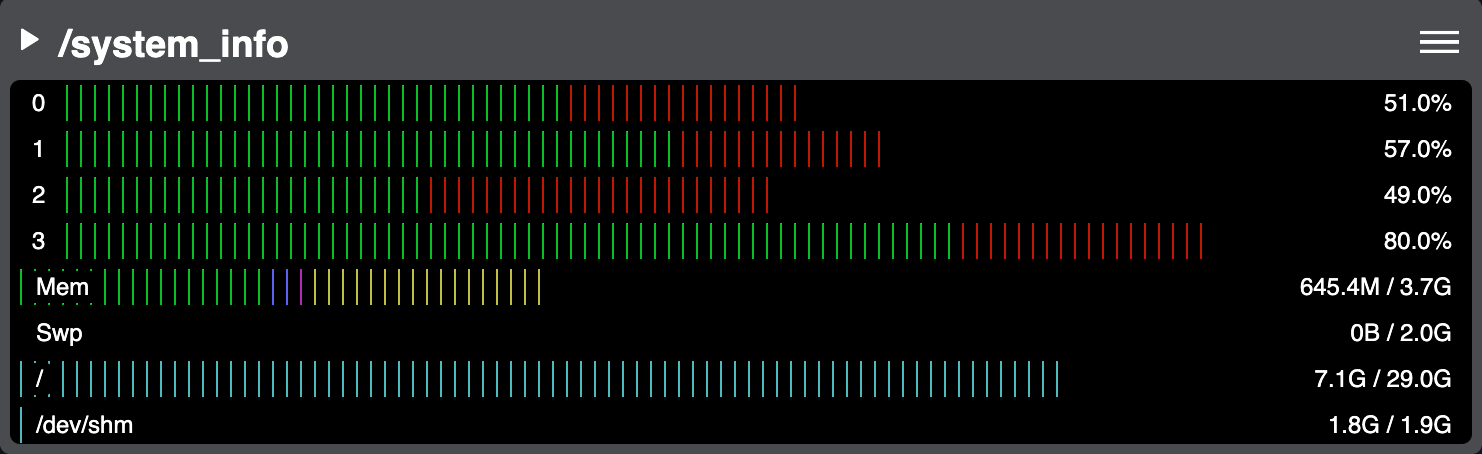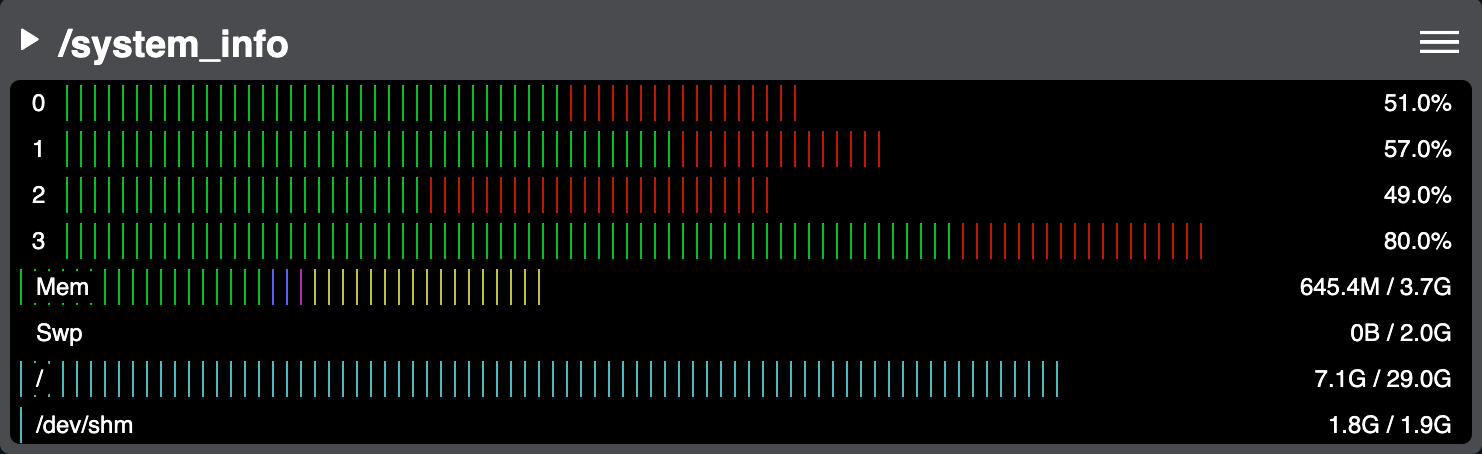
System Info / PHNTM Bridge Documentation

Configuration / PHNTM Bridge Documentation
Advertisement Space (300x250)

Documentation about ROS Bridge - #4 by TeresaC - Isaac Sim - NVIDIA ...
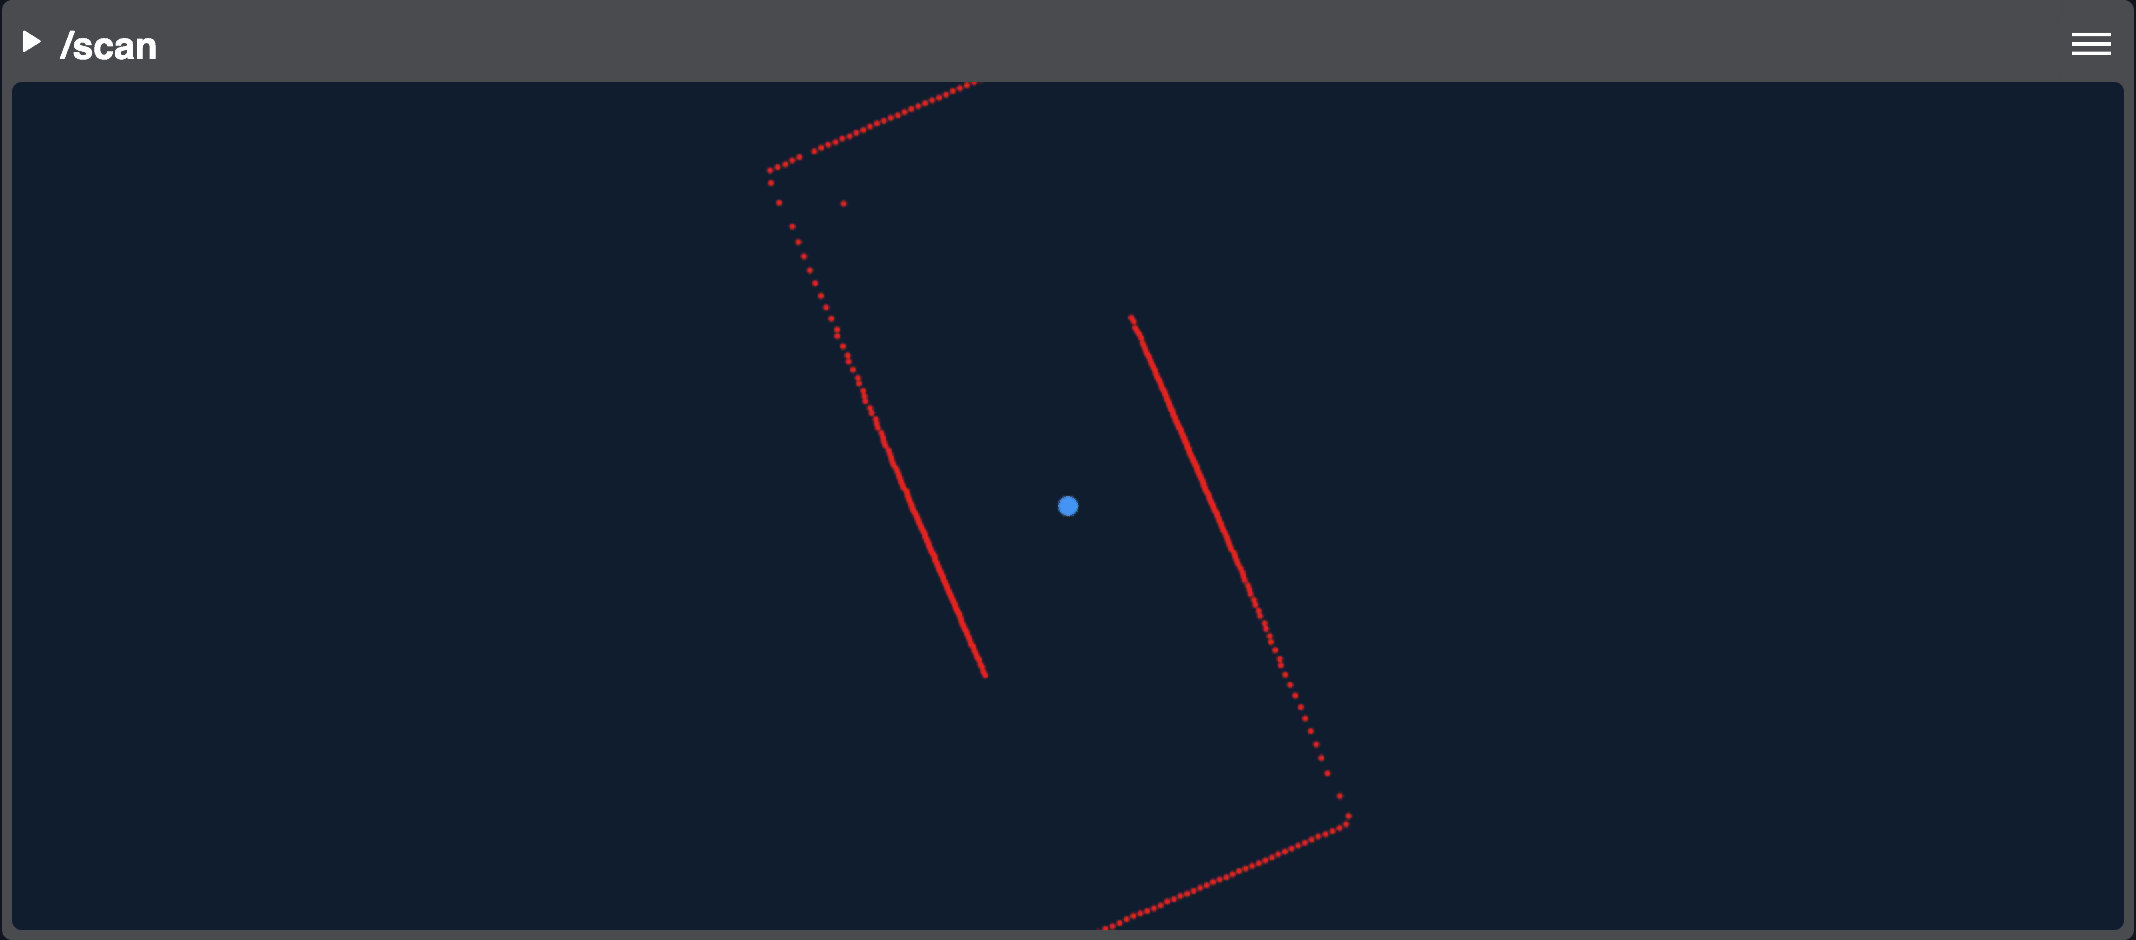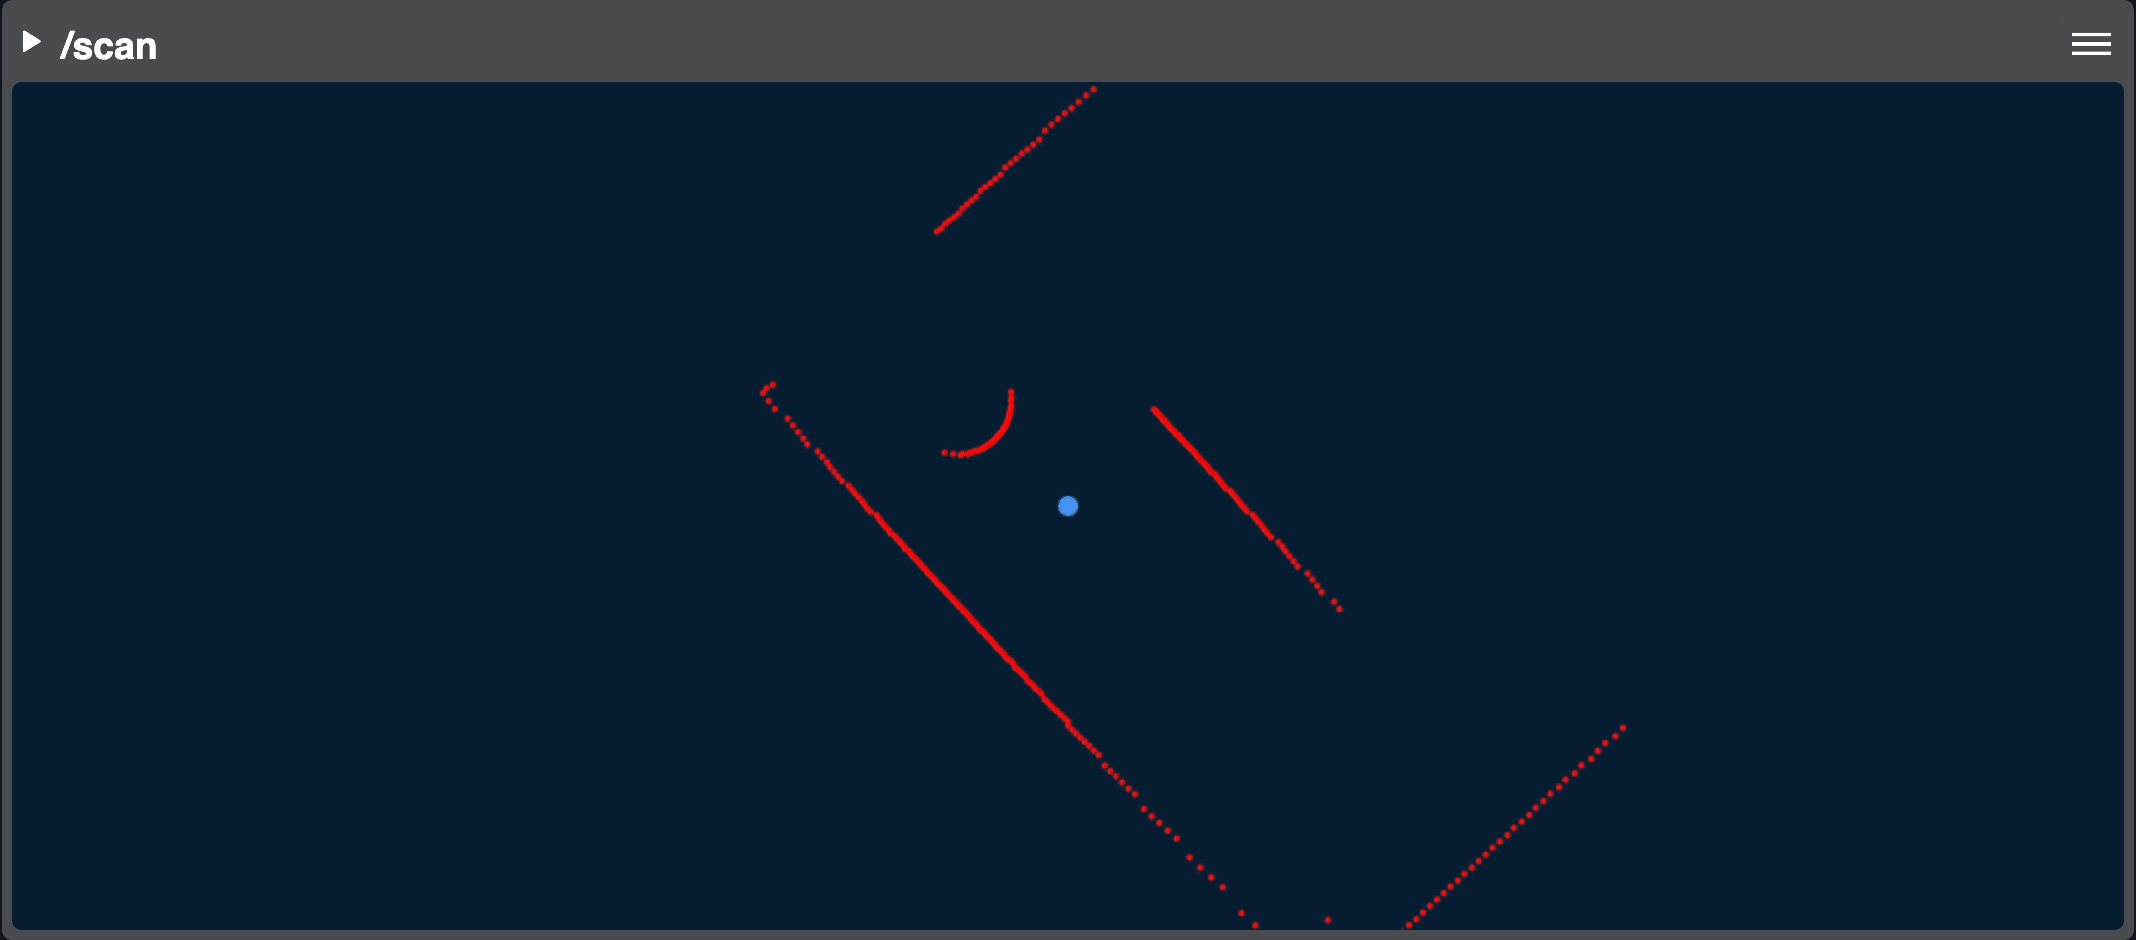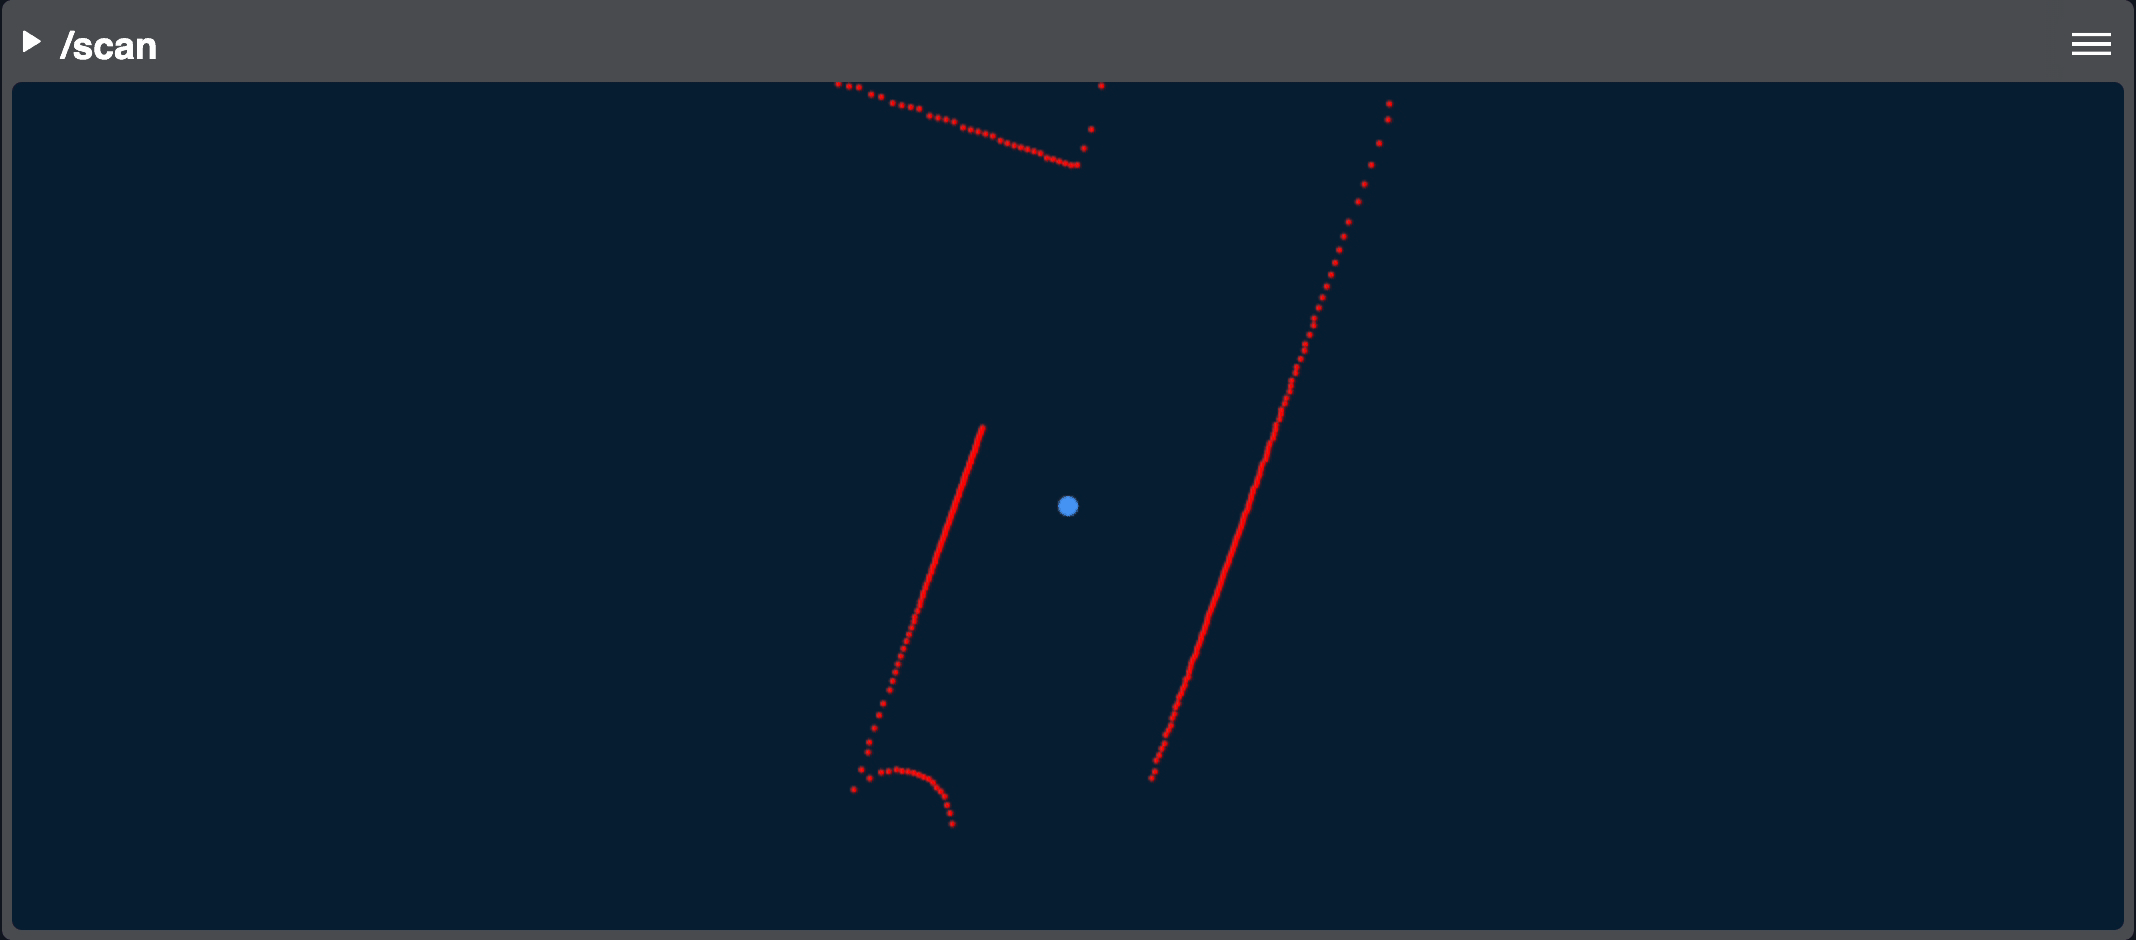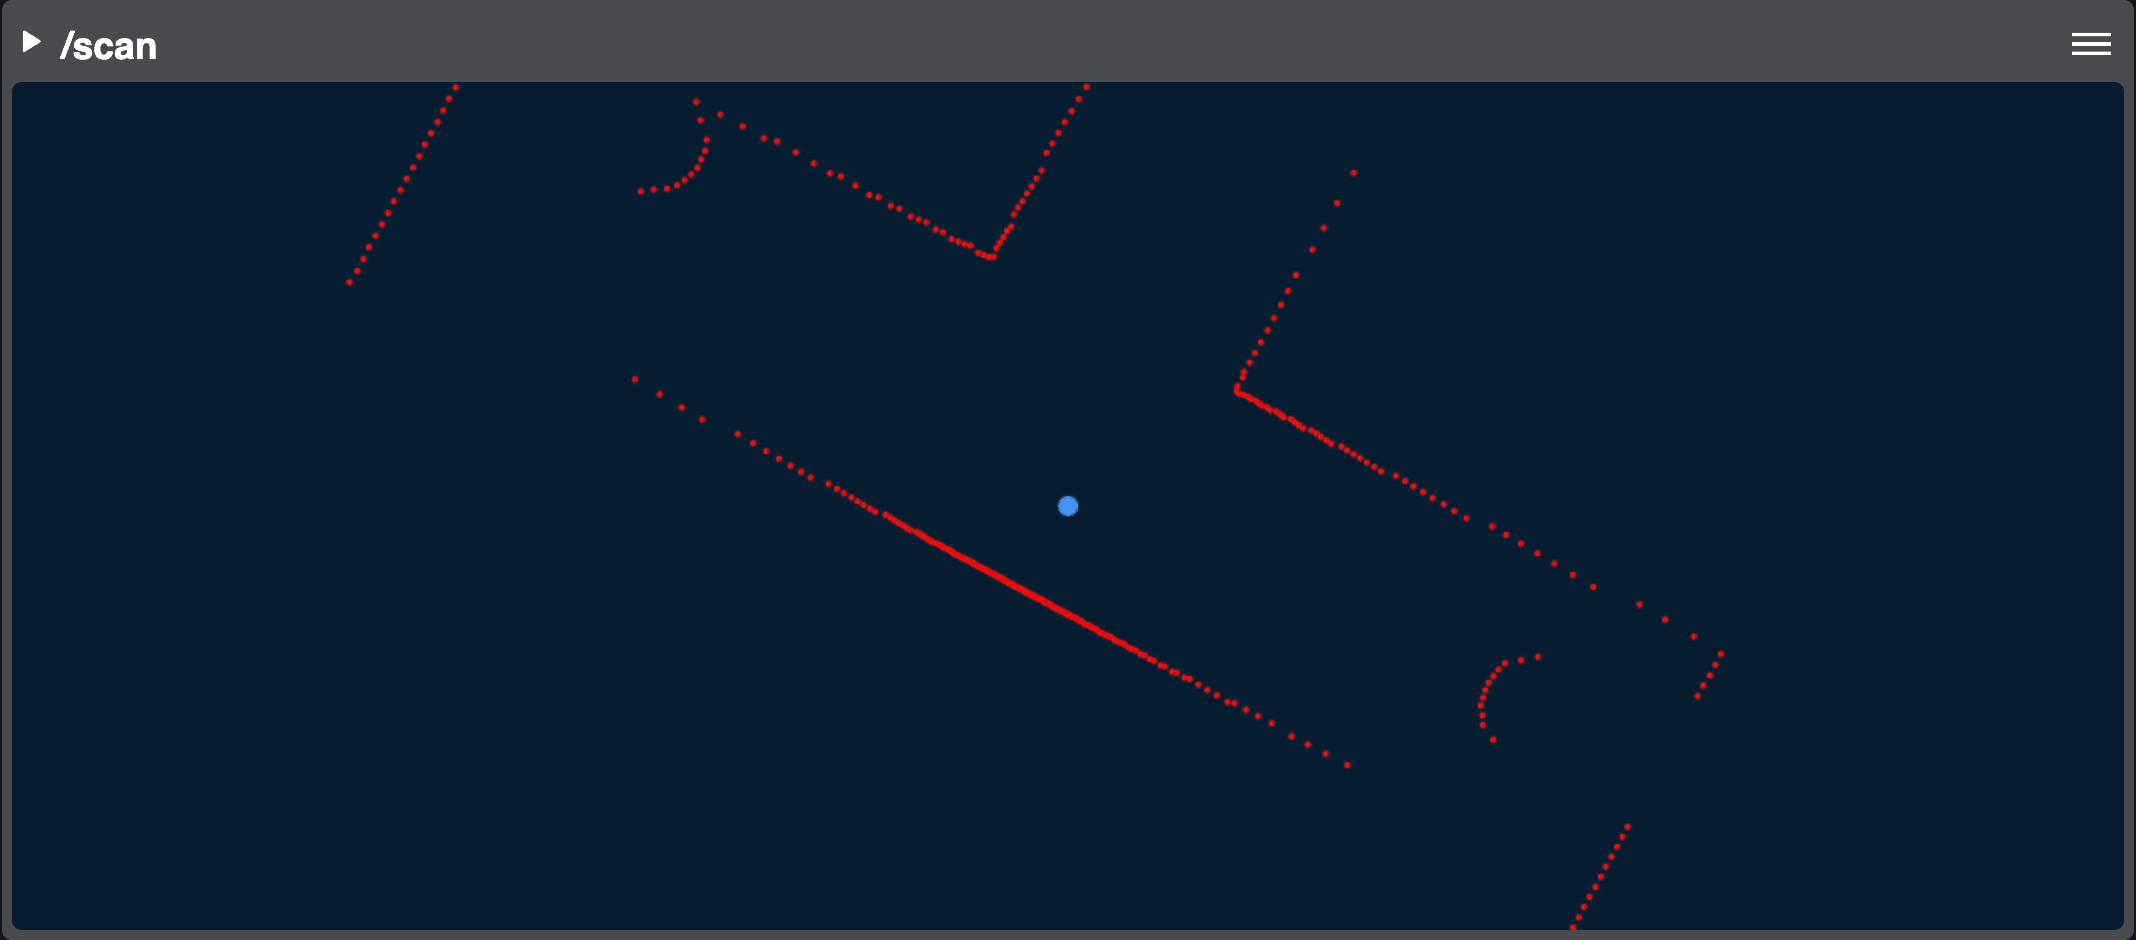
Laser Scan / PHNTM Bridge Documentation

Re-enable runtime configuration of key parameters · Issue #956 · ros ...
Bool (Single-topic Example) / PHNTM Bridge Documentation
Range / PHNTM Bridge Documentation
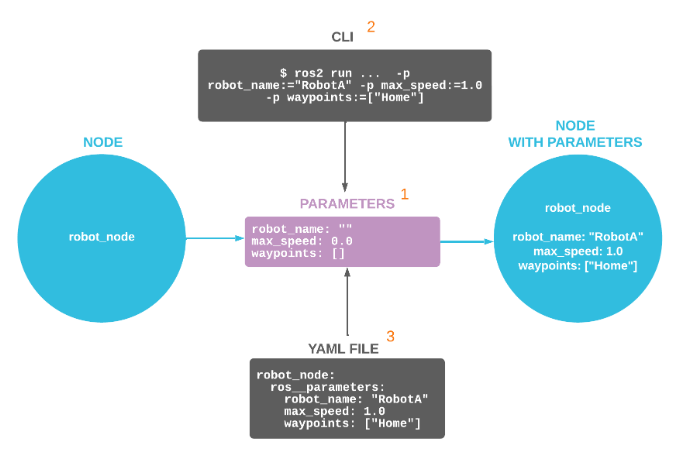
Parameters — Robotics and AI manuals 18.11.2023 documentation
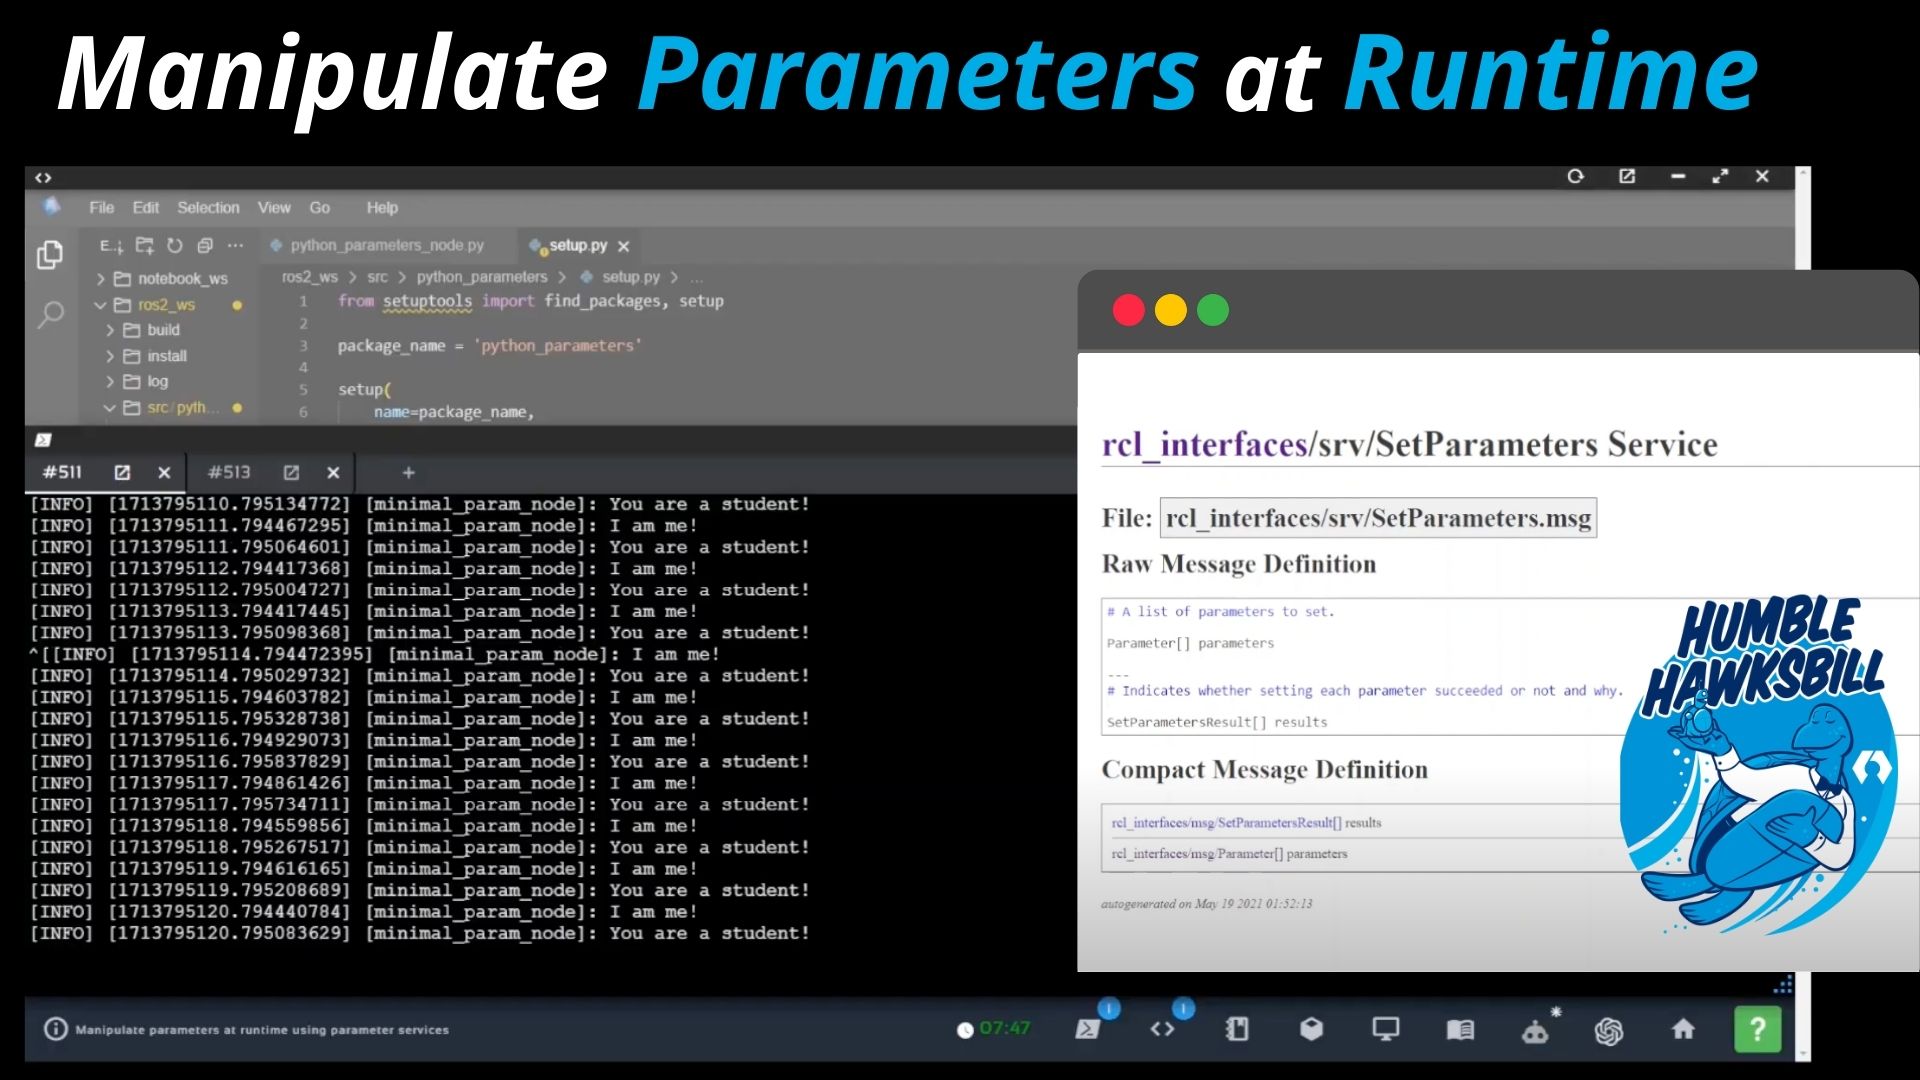
How to manipulate parameters at runtime | ROS2 Humble Python Tutorial ...

ROS bridge | Rerun

Use ROS Bridge to Establish Communication Between ROS and ROS 2 ...
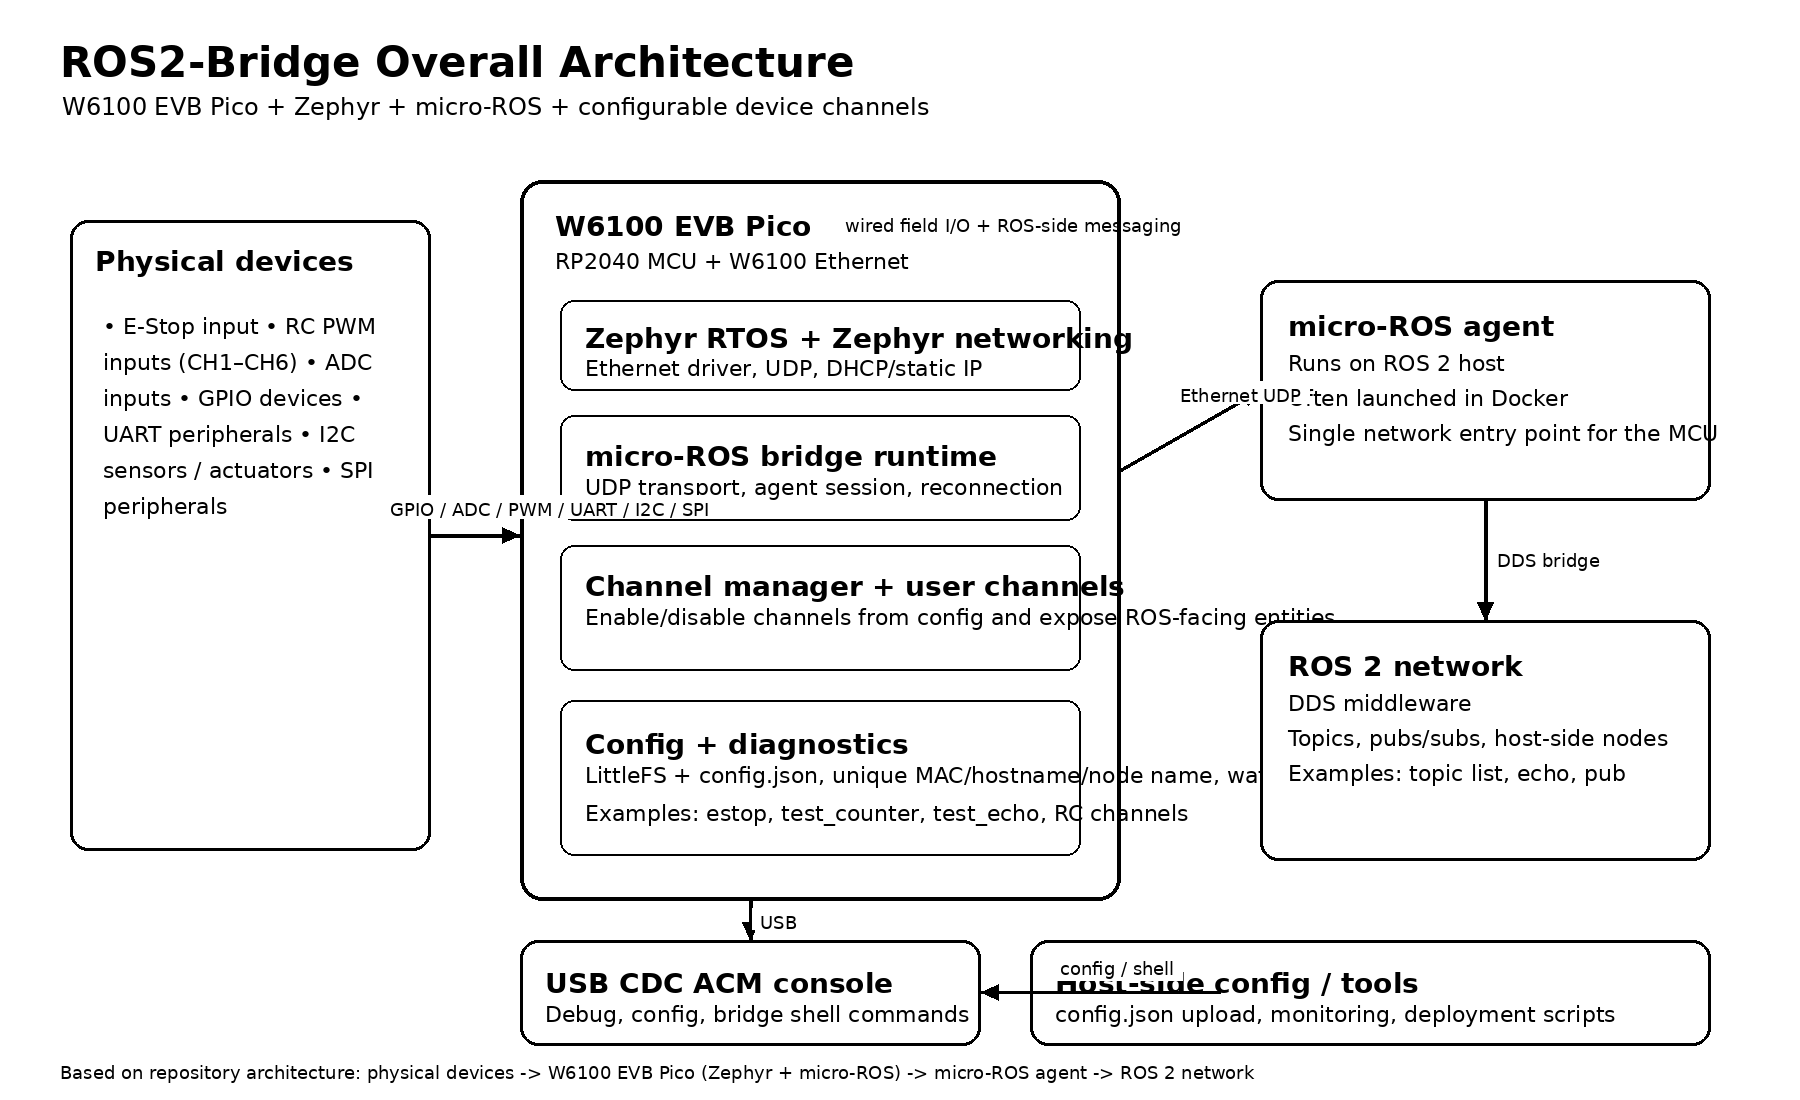
How to Bridge Physical I/O into ROS 2 with W6100 on RP2040?
Advertisement Space (336x280)
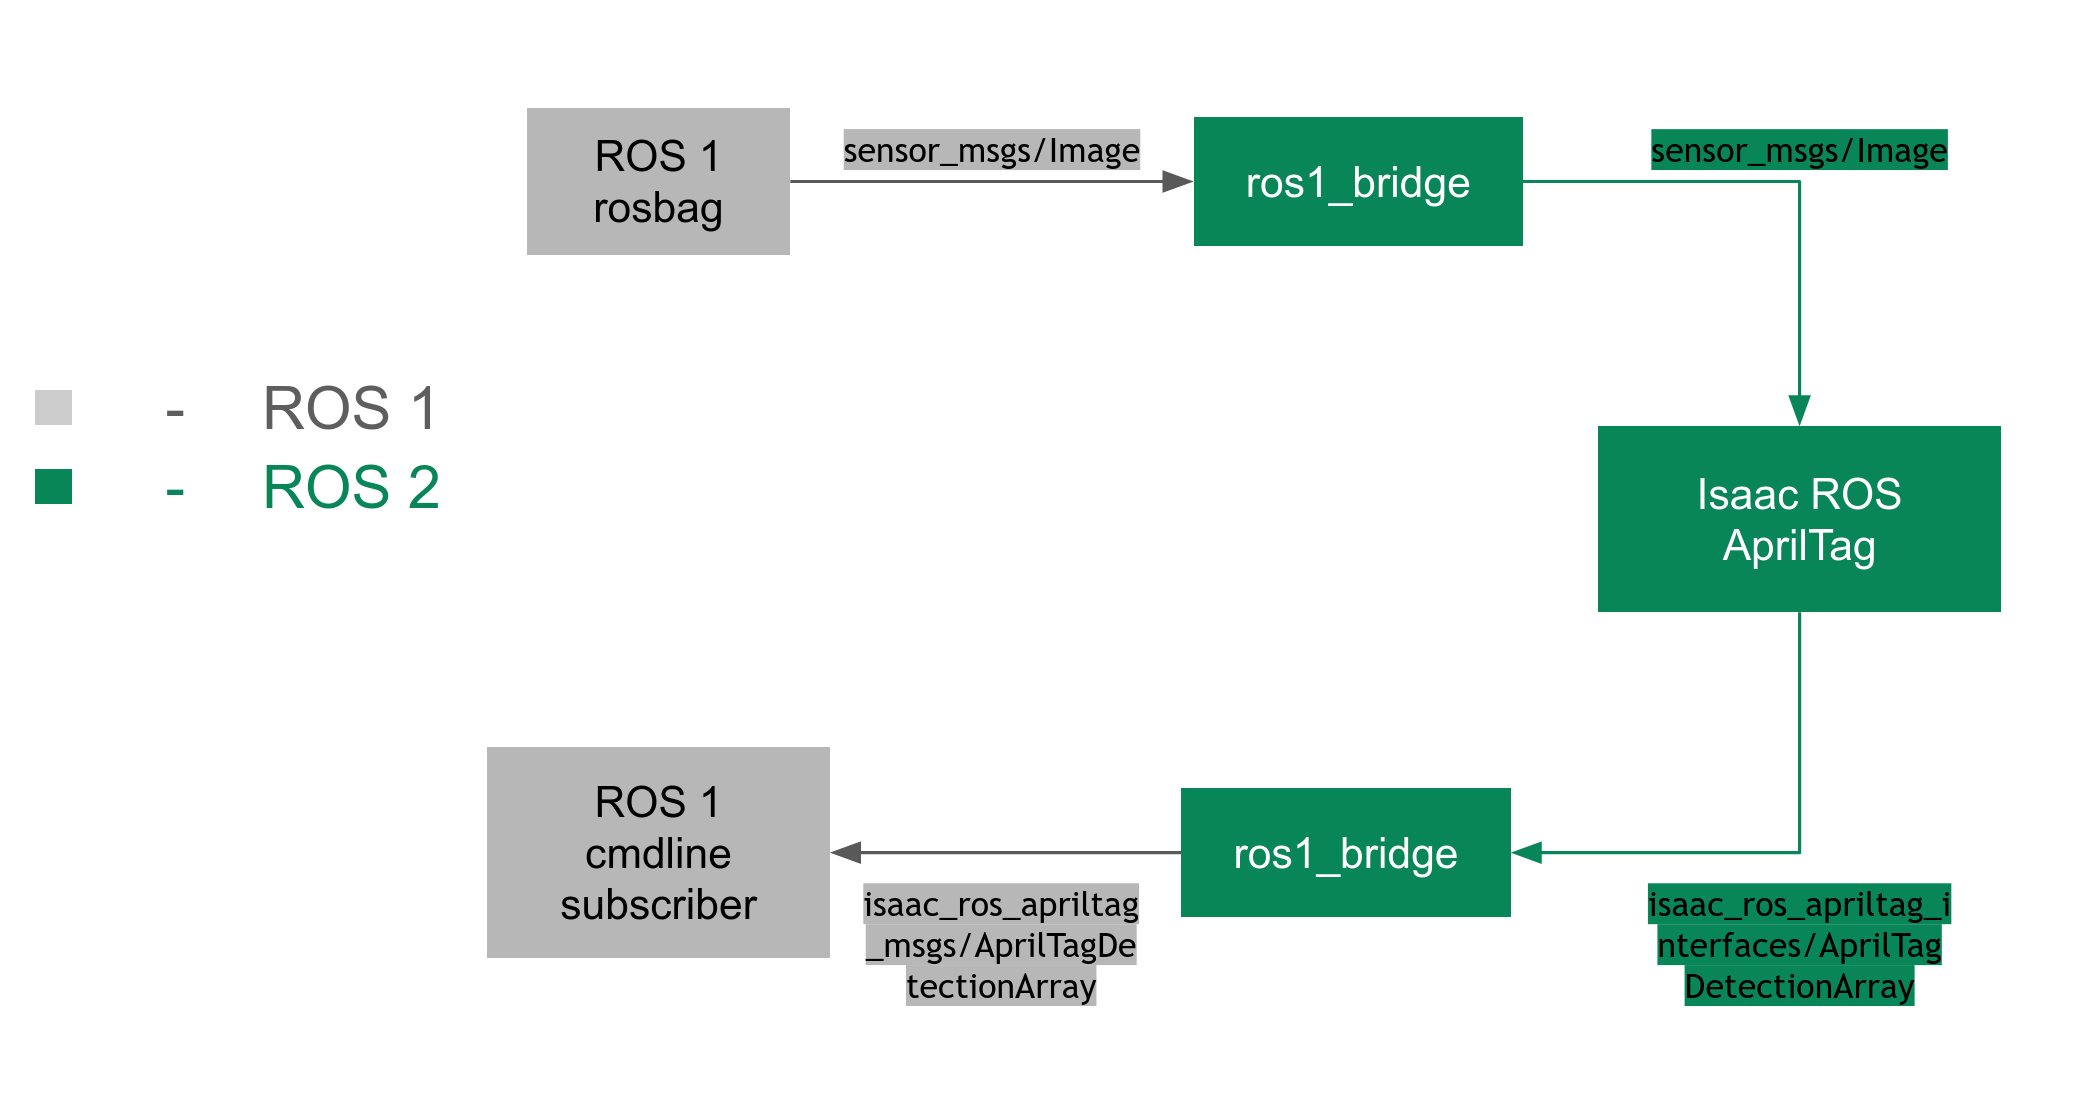
Isaac ROS AprilTag ros1_bridge Tutorial — isaac_ros_docs documentation
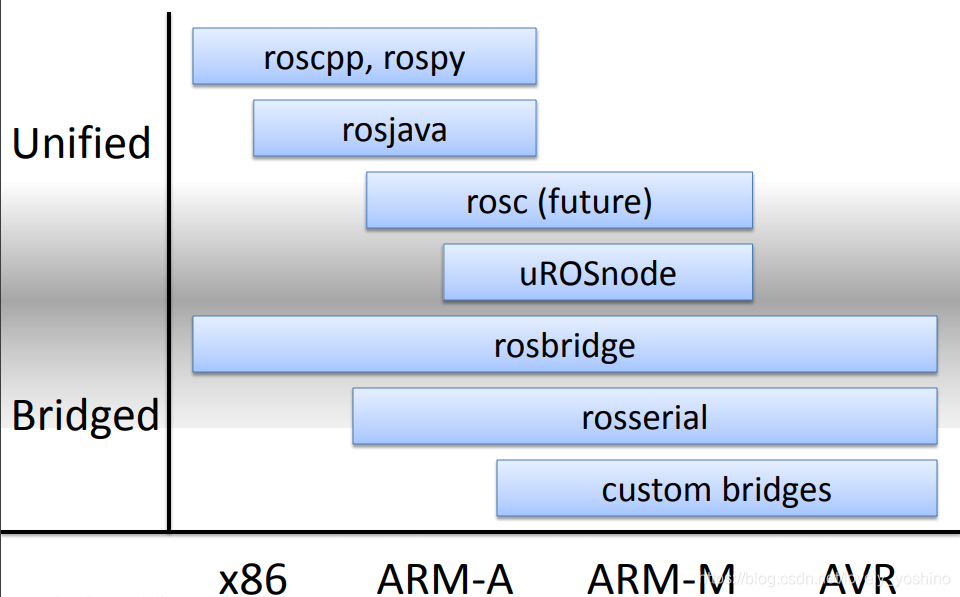
ROS Bridge 进行数据传输实战-CSDN博客

ROS 2 machine runtime - peaq

Gazebo ROS 2 Runtime Suite for Harmonic: model import, bridge, and ros2 ...

How to Use ROS 2 Parameters
Configure a ROS 2 node using parameters - Myzhar & MyzharBot — Robotics ...

ROS 2 Publish Real Time Factor (RTF) — Isaac Sim Documentation
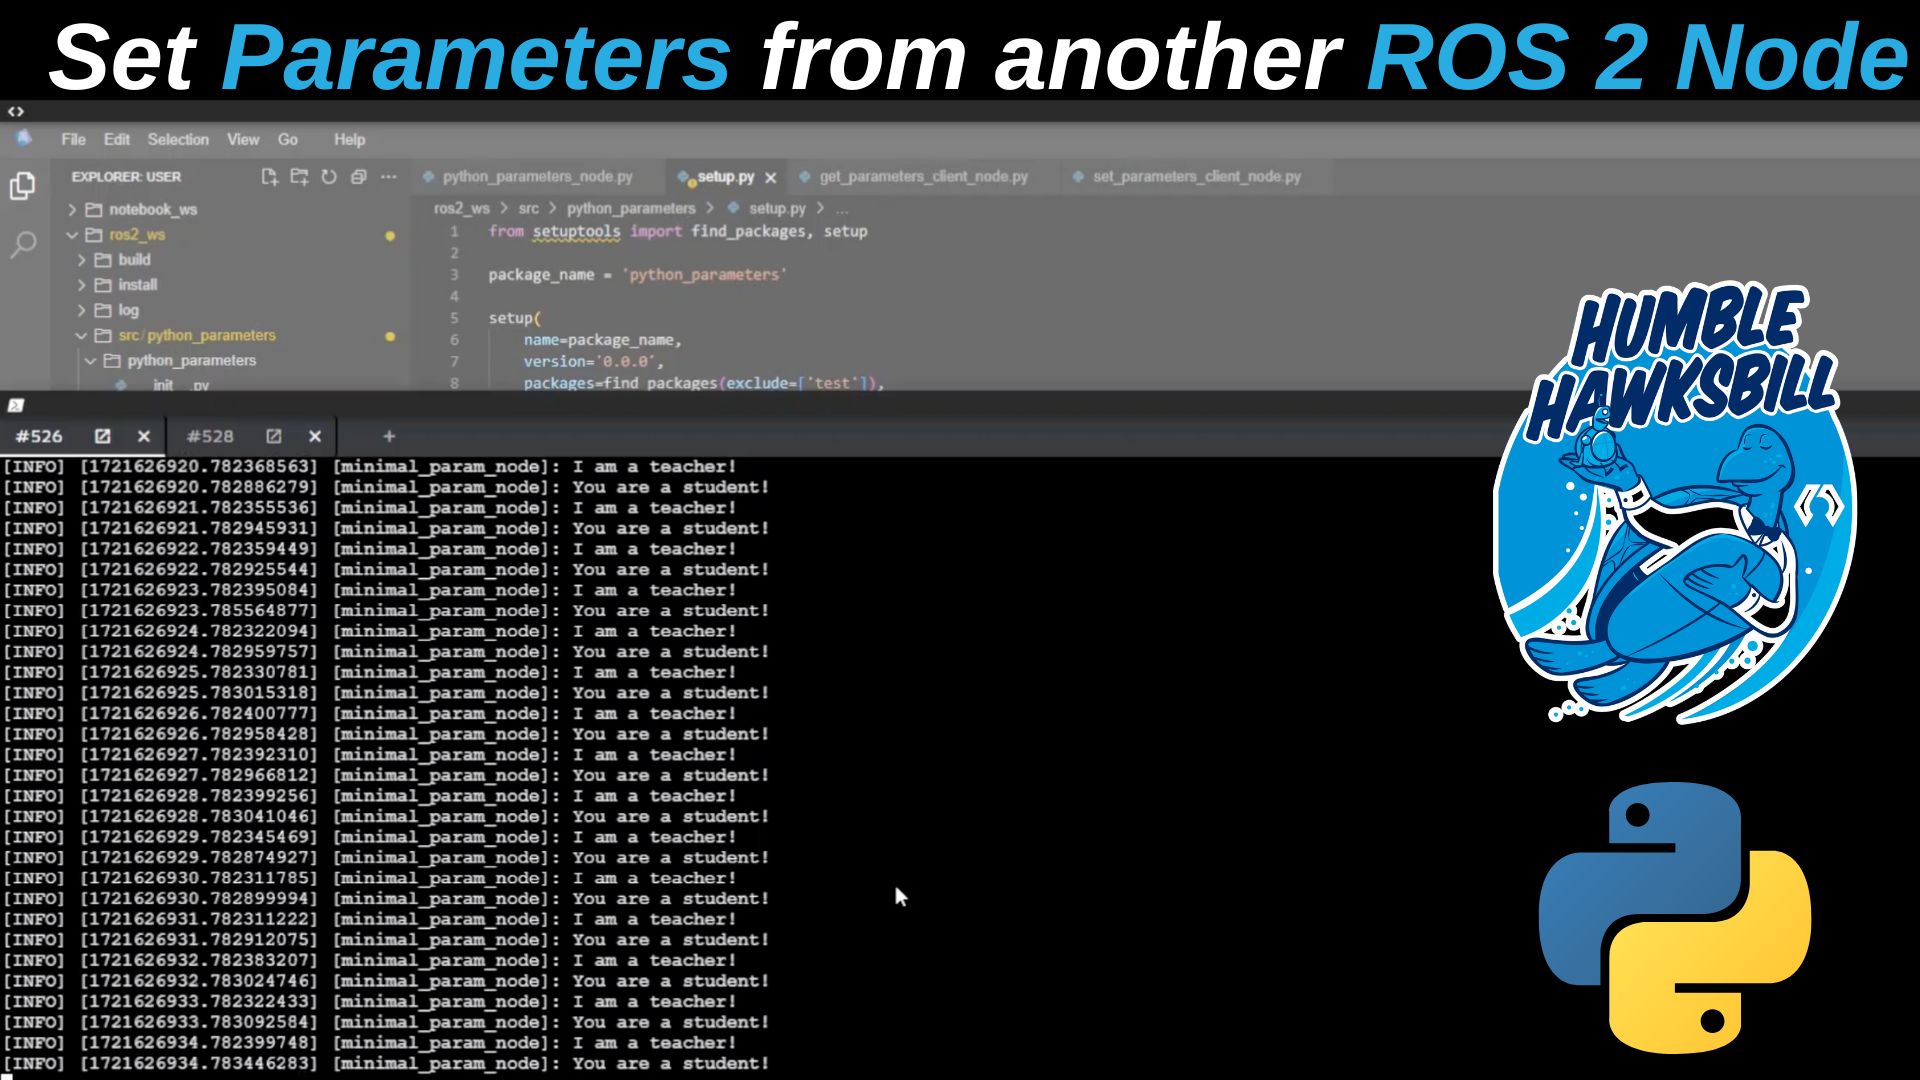
How to manipulate parameters at runtime | ROS2 Humble Python Tutorial ...
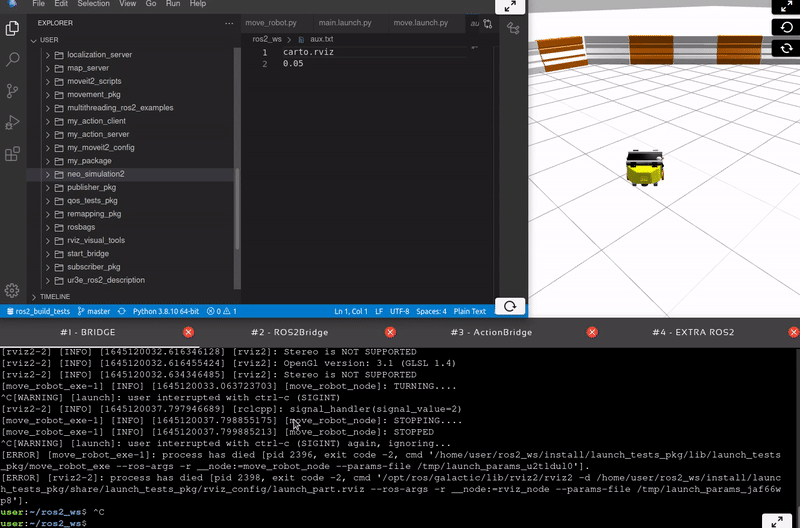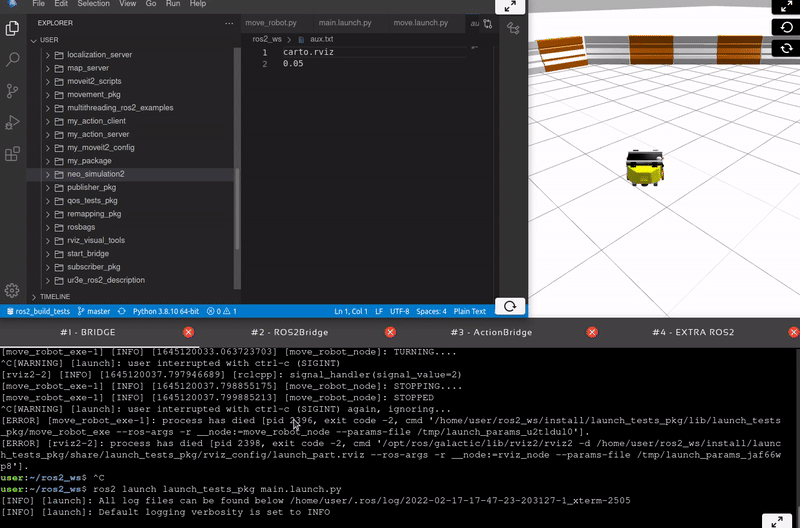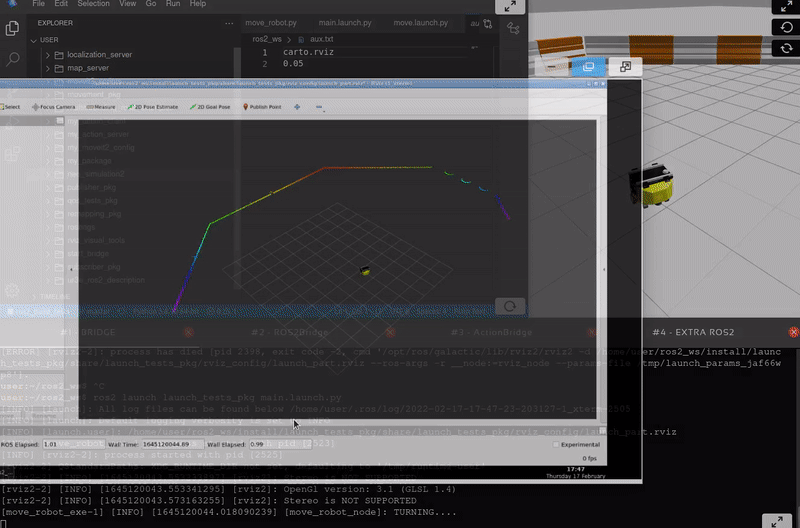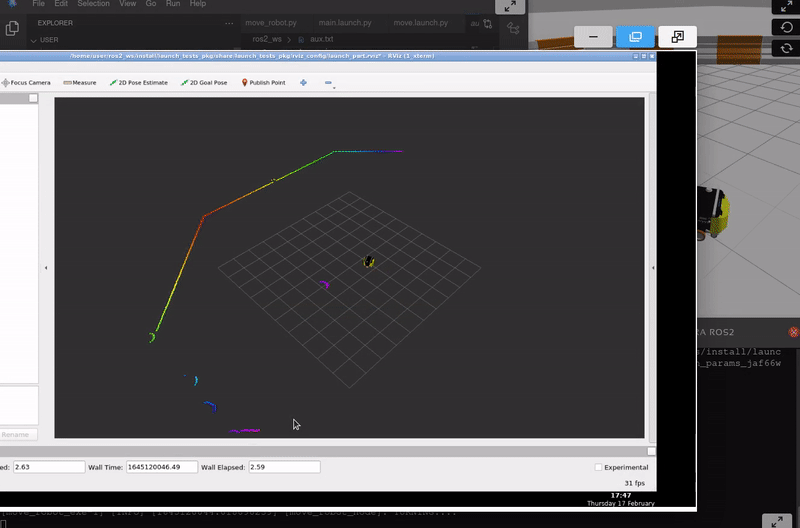
How to manipulate parameters at runtime | ROS2 Humble Python Tutorial ...

(PDF) ROSMonitoring 2.0: Extending ROS Runtime Verification to Services ...
Advertisement Space (336x280)

Use ROS Bridge to Establish Communication Between ROS and ROS 2 ...
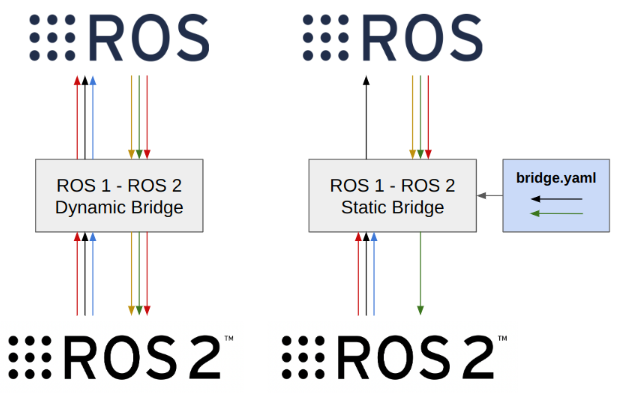
ROS bridge
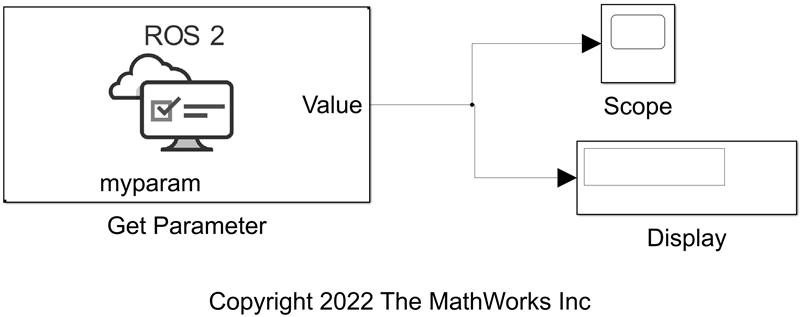
Get and Set ROS 2 Parameters in Simulink - MATLAB & Simulink
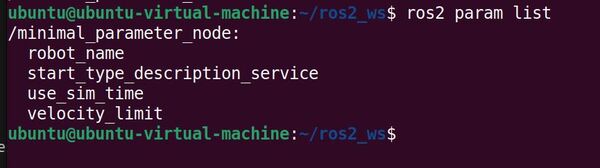
The Complete Guide to Parameters – ROS 2 Python
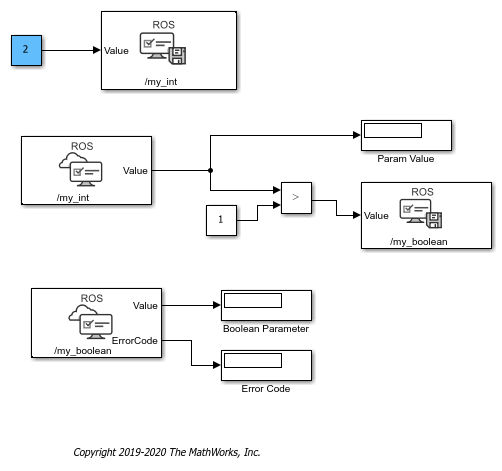
ROS Parameters in Simulink - MATLAB & Simulink

ROS 1 Platform — PercipioDC V 2.6.36 documentation