
Simulation Case Ii Initial Planned Path And Executed Motion Dynamic

Simulation Case II: Initial planned path and executed motion (dynamic ...

Path planned when target is dynamic Case Study 3: User defined initial ...

4th Degree Motion Path -(a) The motion planned path, and initial and ...

Path planned for user defined initial position Case Study 4: Dynamic ...

Path planned for user defined initial position Case Study 4: Dynamic ...

2nd Degree Motion Path -(a) The motion planned path, and initial and ...

2nd Degree Motion Path -(a) The motion planned path, and initial and ...

a The initial planned path (black) and final planned path (blue); b The ...

Example of a planned path and its executed trajectories. In blue is the ...

Evolution of the robot location and its planned path in the dynamic ...
Advertisement Space (300x250)

Planned path and realized motion for an underactuated robot using the ...
Planned path (in black) and real executed path captured by the DGPS (in ...

Interactive Path Editing and Simulation System for Motion Planning and ...

Evolution of the robot location and its planned path in the dynamic ...
Simulation results of path planning and motion tracking control: (a ...

The motion utilized in simulation is the motion planned in Figs. 20 and ...

The simulation about path correction using the planned trajectory 2 and ...
Dissonance between the planned path in blue and the trajectory executed ...

Environment Setup and Planned Path. (a) shows the robot's initial state ...

Figure 1 from An NMPC-ECBF Framework for Dynamic Motion Planning and ...
Advertisement Space (336x280)

7: Actual executed path for case 2 along with the assigned plane of ...

Figure 1 from A Motion Constraint Dynamic Path Planning Algorithm for ...

Figure 4 from An NMPC-ECBF Framework for Dynamic Motion Planning and ...

Planned path and its real execution. | Download Scientific Diagram

Figure 2 from A Motion Constraint Dynamic Path Planning Algorithm for ...

Motion and Path Planning - MATLAB & Simulink

The Dynamic Path Planning of Autonomous Vehicles on Icy and Snowy Roads ...

(a) Comparison of planned path and actual path. The actual path ...

An NMPC-ECBF Framework for Dynamic Motion Planning and Execution in ...

Reactive task and motion planning for robust whole-body dynamic ...
Advertisement Space (336x280)

Simulation results under case two. (a) and (b) are the desired ...

An NMPC-ECBF Framework for Dynamic Motion Planning and Execution in ...

Principle of motion simulation for a) planned trajectory without ...
Diagram of the planned path (blue) and trajectory (red) at some ...

Comparative results of planned path for case two. | Download Scientific ...
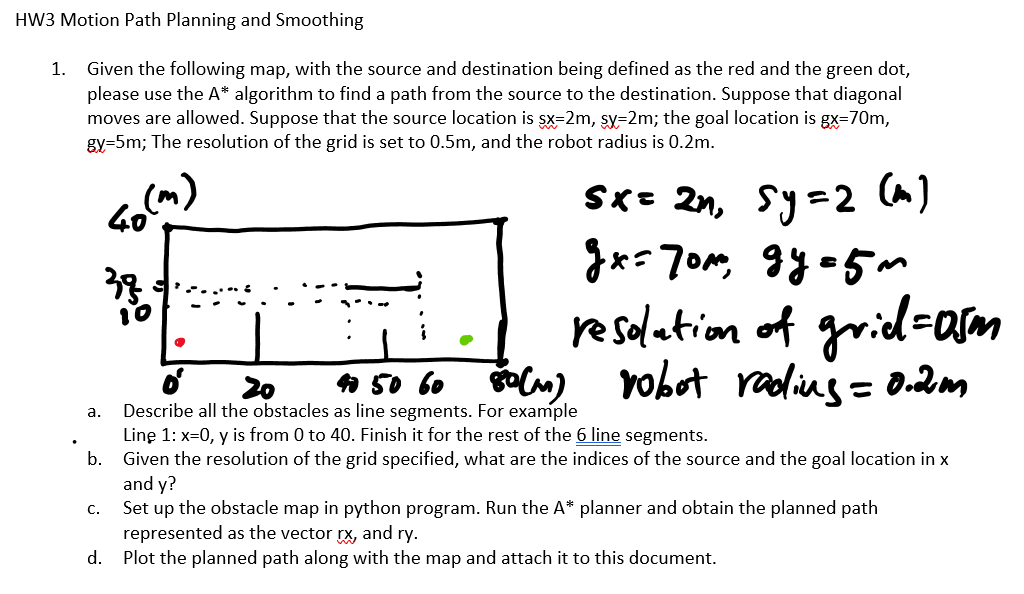
13 Motion Path Planning and Smoothing 1. Given the | Chegg.com