
Tetrapod Project Singlelegcontroller Class Reference
Tetrapod Project: SingleLegController Class Reference
Tetrapod Project: Controller Class Reference
Tetrapod Project: GaitController Class Reference
Tetrapod Project: GaitController Class Reference

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC
2010 Robotics – Tetrapod Project – NagyCNC
Advertisement Space (300x250)

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

2010 Robotics – Tetrapod Project – NagyCNC

Typical examples of tripod (above) and tetrapod (below) gait (redrawn ...

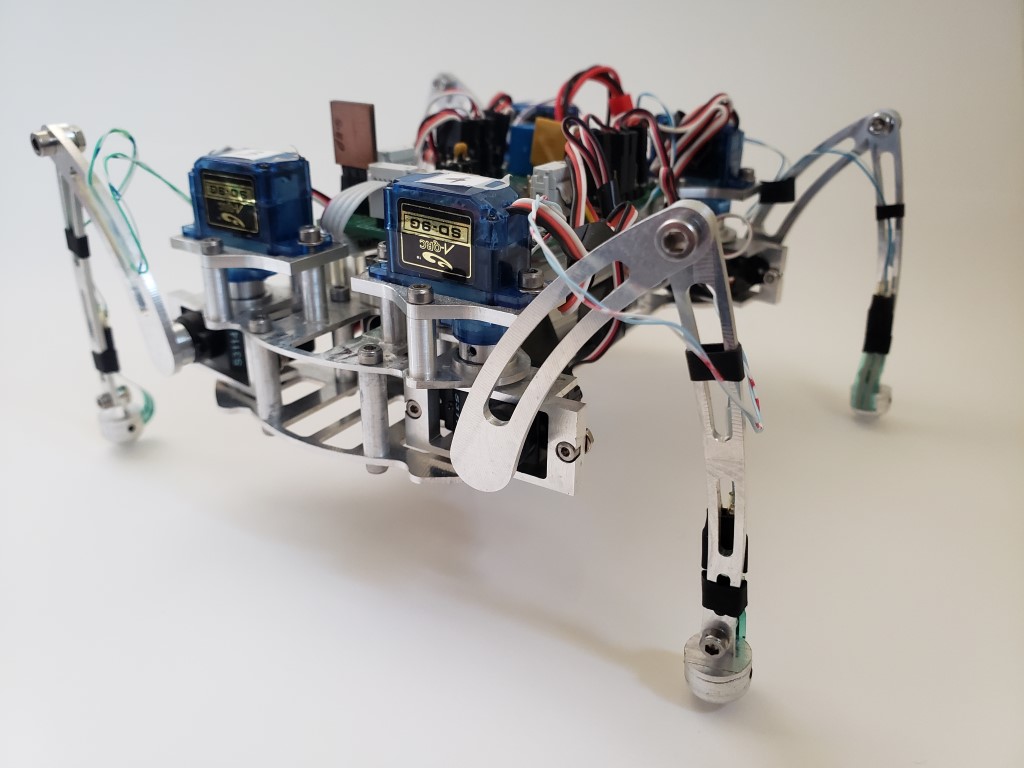
A,B) Overview picture of the developed tetrapod robot, where each leg ...
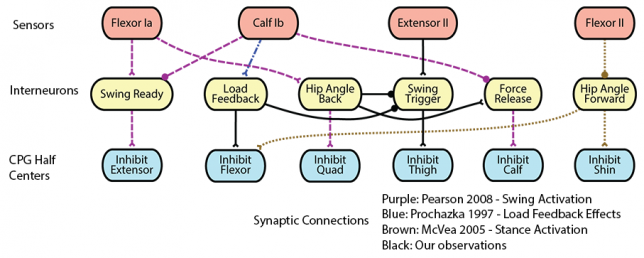
Tetrapod Intra-Leg Control | Case School of Engineering
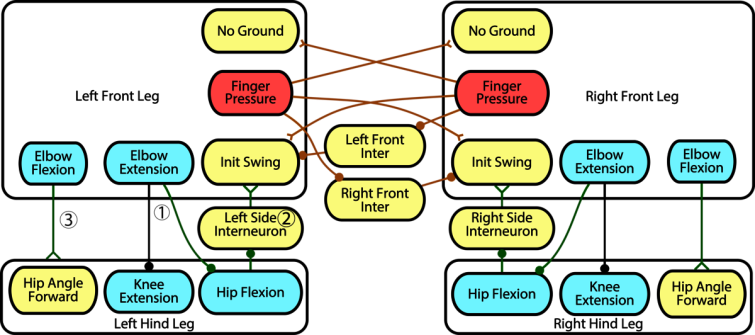
Tetrapod Intra-Leg Control | Case School of Engineering
Advertisement Space (336x280)

Tutorial Inventor - 272 TETRAPOD - YouTube
T7T Tetrapod Legs - Download Free 3D model by ~Drift~ (@QuickDriftVR ...

Body size of the single actuator eight-legged tetrapod walking spider ...

tetrapod on Behance

Body size of the single actuator eight-legged tetrapod walking spider ...

(a) Schematic structure of a SiC tetrapod with a 3C-core surrounded by ...
ASSEMBLY TETRAPOD LG-033M VERRILL m PART INFO Tetrapod leg option ...

Modeling Tetrapod Legs and Gait Animations

A three-leg model producing tetrapod and tripod coordination patterns ...

Schematic representation of the synthesis process of aero-ZnS tetrapod ...
Advertisement Space (336x280)

A three-leg model producing tetrapod and tripod coordination patterns ...

Examples of tetrapod (left) and tripod (right) coordination patterns ...
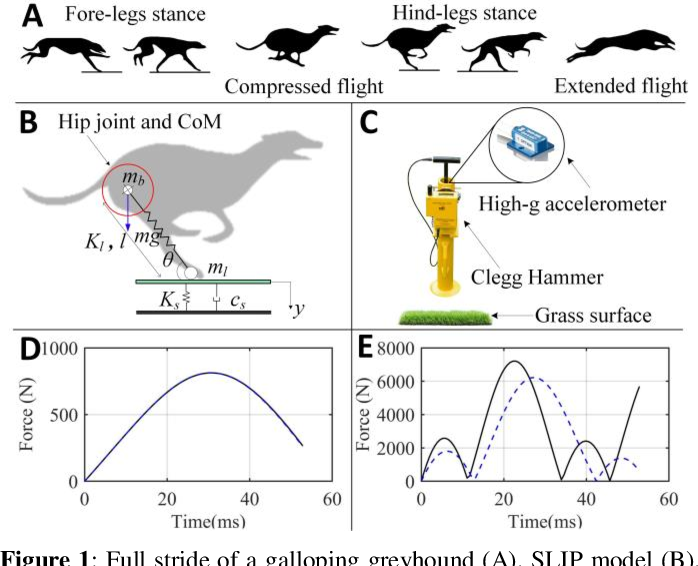
Figure 1 from A SLIP Model to predict the dynamics of rapid tetrapod ...

Armored Core 6 leg types: Bipedal, reverse-joint, treads, and tetrapod ...
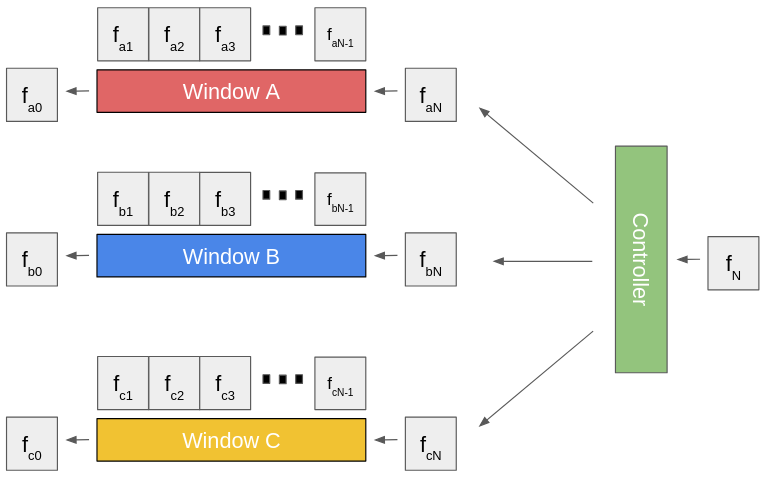
Controller — Project HAL documentation

Single support phase of a bipedal robot with reference to the right leg ...