
The Orbits Of Error States A E 1 X T 1 X T

The orbits of error states: (a) e 1 = X ( t - τ ) - ϵ 1 x ( t ...

The orbits of error states: (a) e 1 = δ 1 x m ( t ) - ϵ 1 x s ( t ...

The orbits of error states: (a) e 1 = X ( t - τ ) - ϵ 1 x ( t ...

The curve of error e ( t ) between the state x ( t ) and its estimate x ...

History of the error states e 1 , e 2 , e 3 | Download Scientific Diagram

Trajectories of position states x i, β i x i and the error e i of ...

Trajectories of position states x i, β i x i and the error e i of ...

Type-1 T-S observation error e of state x 1 and x 2 with disturbances ...

The absolute error (a) E 1 (x, t) and (b) E 2 (x, t) of problem (3.6 ...

The absolute error (a) E 1 (x, t) and (b) E 2 (x, t) of problem (3.1 ...
Advertisement Space (300x250)

Trajectories of position states error e i of agents (a) T = 1.6 + 2 π ...

Dynamical behavior of the error e 1 (t, x). | Download Scientific Diagram

The absolute error (a) E 1 (x, t) and (b) E 2 (x, t) of problem (3.1 ...

The error state curves of e 1 (t ) and e 2 (t ) with initial value e(0 ...

Error signals: (a) e 1 ( t ), (b) e 2 ( t ) in Example 1 | Download ...

Trajectories of position states error e i of agents (a) T = 1.6 + 2 π ...

The orbits of Eqs. 1 in (x,y) space. a 0.005 the disordered chaos ...

(a) Orbits of x 1 (t) for Example 4.2. (b) Orbits of x 2 (t) for ...

The evolution of the errors system (e 1 (t), e 2 (t), e 3 (t ...

The absolute error E 1 (x,t) for example 1 at N = 12. | Download ...
Advertisement Space (336x280)

Trajectory of error state e 1 ( k ) . | Download Scientific Diagram

Error states ei(t) of multi‐agent systems in Example 1 | Download ...

The absolute error E 1 (x,t) for example 1 at N = 12. | Download ...

Panels (a-c) show the orbits of the system for µ = 0.15, F = 0.3, ω = 1 ...

(a) State trajectories of errors system (e 1 (t), e 2 (t), e 3 (t)) and ...

The orbital error EO after t=1 as a function of the initial energy δH0 ...

(a) State trajectories of errors system (e 1 (t), e 2 (t), e 3 (t)) and ...

Stellar orbits in a galaxy, Example 5.1. The absolute error in the ...

States of the error system (55) (a) Error X~(t), (b) Error u~(x,t ...
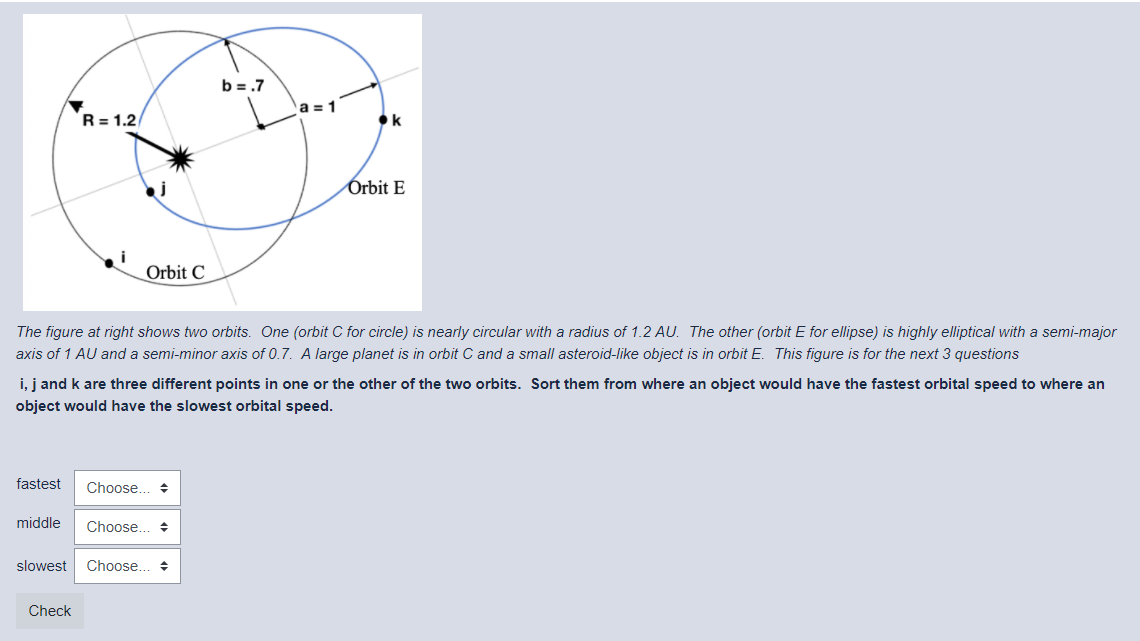
Solved b = .7 a = 1 R = 1.2 k j Orbit E Orbit C If orbit E | Chegg.com
Advertisement Space (336x280)

3 Errors of orbits due to the effect of ERP error | Download Scientific ...

The comparison of the error states of x(t) by adding the controller ...
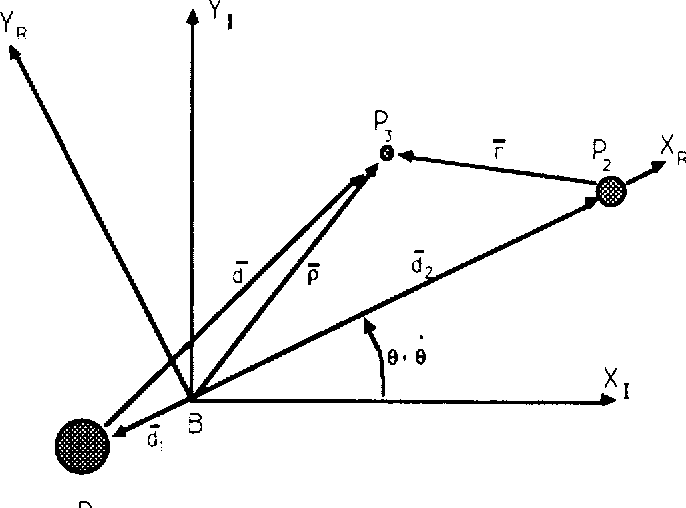
Figure 1 from Orbit determination error analysis and comparison of ...

Trajectories of the error states... | Download Scientific Diagram

The time response of error states, with a=1 and b=0.25. | Download ...

Response curves of error dynamic states e1t and e2t when ωt≠0 ...