
The Transformation Between The World Frame X W Y W Z W And The

The transformation between the World Frame (X w , Y w , Z w ) and the ...
Goal information with respect to the world frame (X W , Y W ) and agent ...

The coordinate systems for the world {W ; x w , y w , z w }, the eye ...

(a) Reference frames fixed to the world XY Z W , the body XY Z B and ...

A schematics representing the world frame W , the body frame B and the ...

Solved Question: The world coordinate frame W (x, y, z) and | Chegg.com
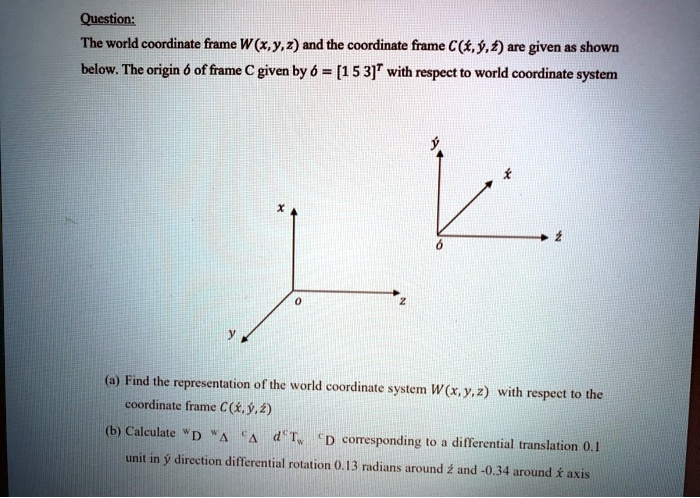
SOLVED: Question: The world coordinate frame W (x,Y,2) and the ...

A schematics representing the world frame W , the body frame B and the ...

Trajectory of the head origin frame in the x w –z w world fixed frame ...

The world frame W = {ê 1 , ˆ e 2 , ˆ e 3 }, in which the position and ...
Advertisement Space (300x250)

Computation of the translation in horizontal X w , Z w world space with ...

4: Computation of the translation in horizontal 2D X w , Z w world ...

The image depicts the world frame W = {ê 1 , ˆ e 2 , ˆ e 3 } in which ...
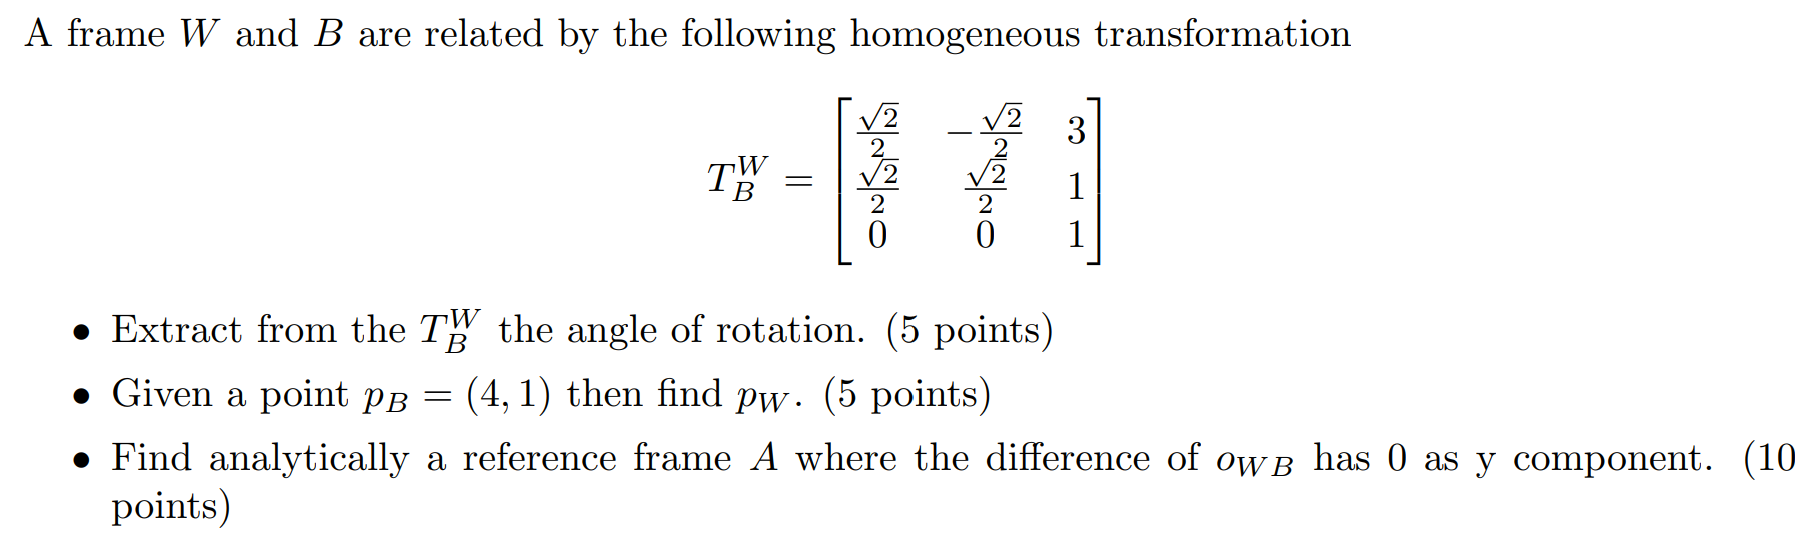
Solved A frame W and B are related by the following | Chegg.com

Relationship between the frames. { } W is the world frame; { } B is the ...

Transformation steps between frame x a y a z a and x b y b z b ...

The relationship between the image frame and the world frame is shown ...

Transformation steps between frame x a y a z a and x b y b z b ...
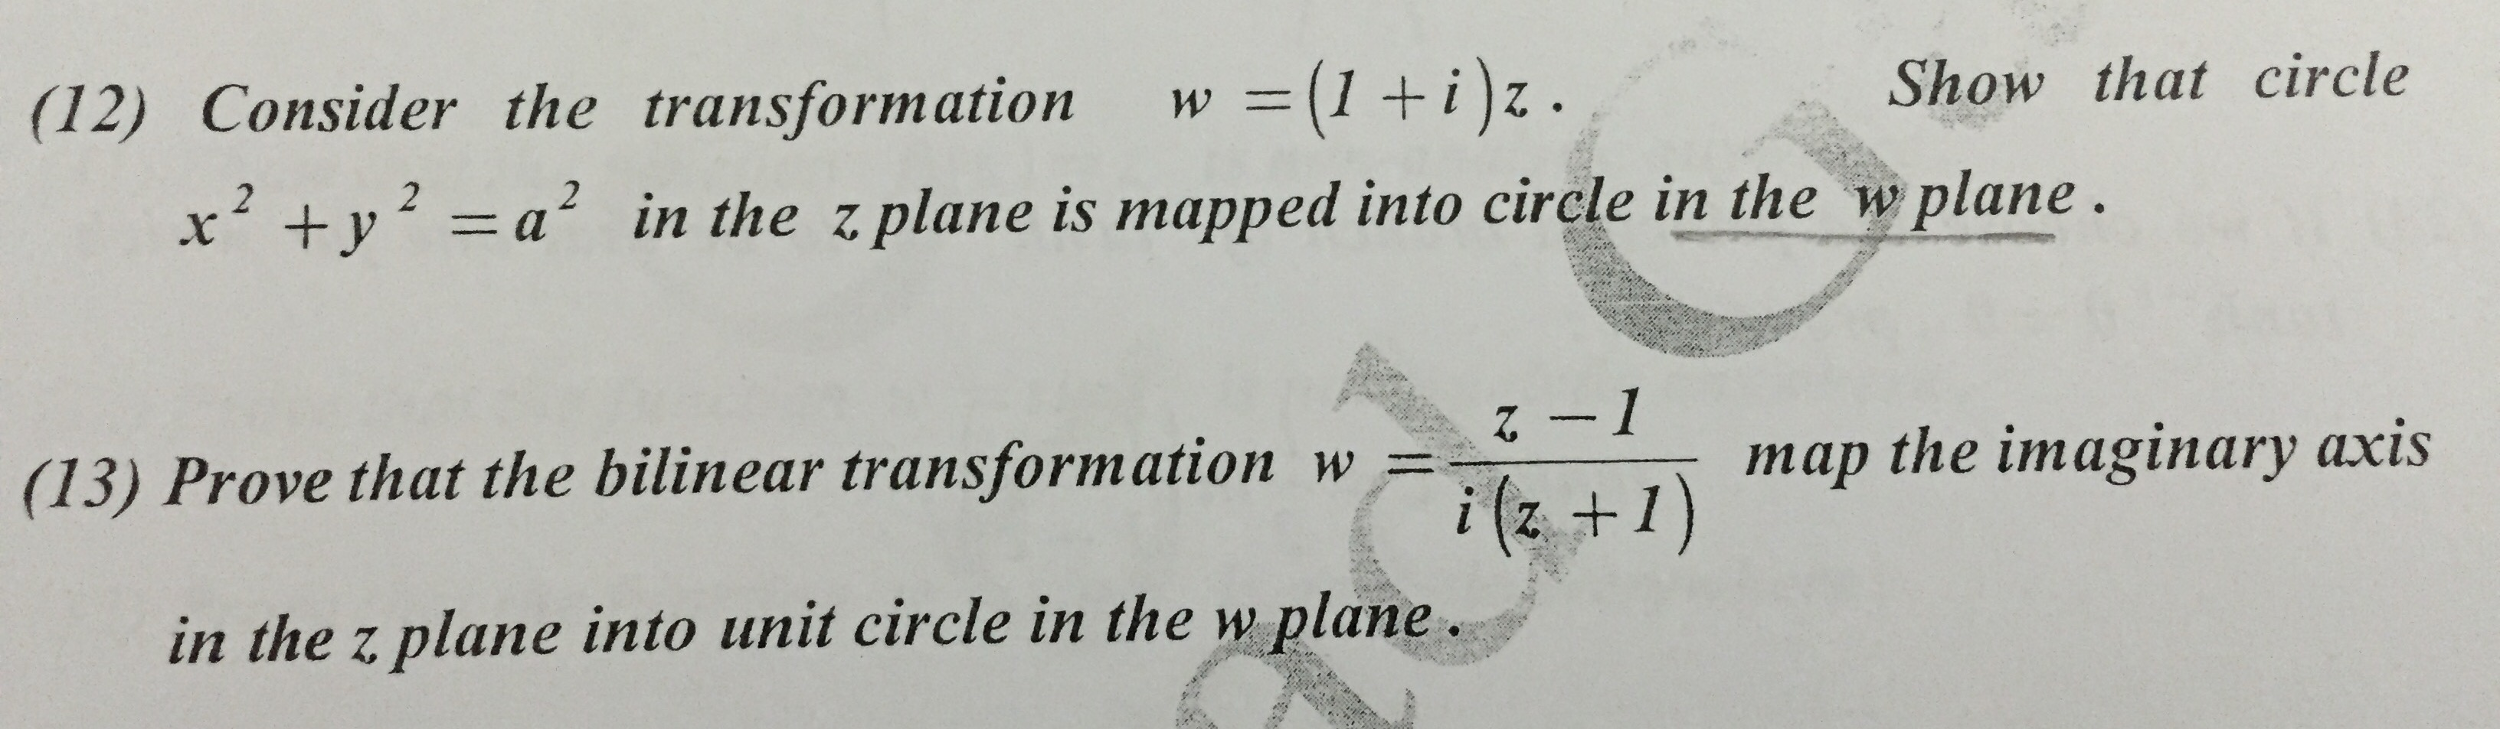
Solved (12) Consider the transformation w = (1 + i)z . Show | Chegg.com

MAV body (x b , y b , z b ) and world (x w , y w , z w ) coordinate ...
Advertisement Space (336x280)

Solved 4. a) Show that the transformation w = f(x) = z'+maps | Chegg.com

MAV body (x b , y b , z b ) and world (x w , y w , z w ) coordinate ...

Solved Question: The world coordinate frame W(x,y,z) and the | Chegg.com

Camera frame transformations relative to the world frame and other ...

Camera frame transformations relative to the world frame and other ...

Solved Question: The world coordinate frame W(x, y, z) and | Chegg.com
Camera frame transformations relative to the world frame and other ...

Camera frame transformations relative to the world frame and other ...
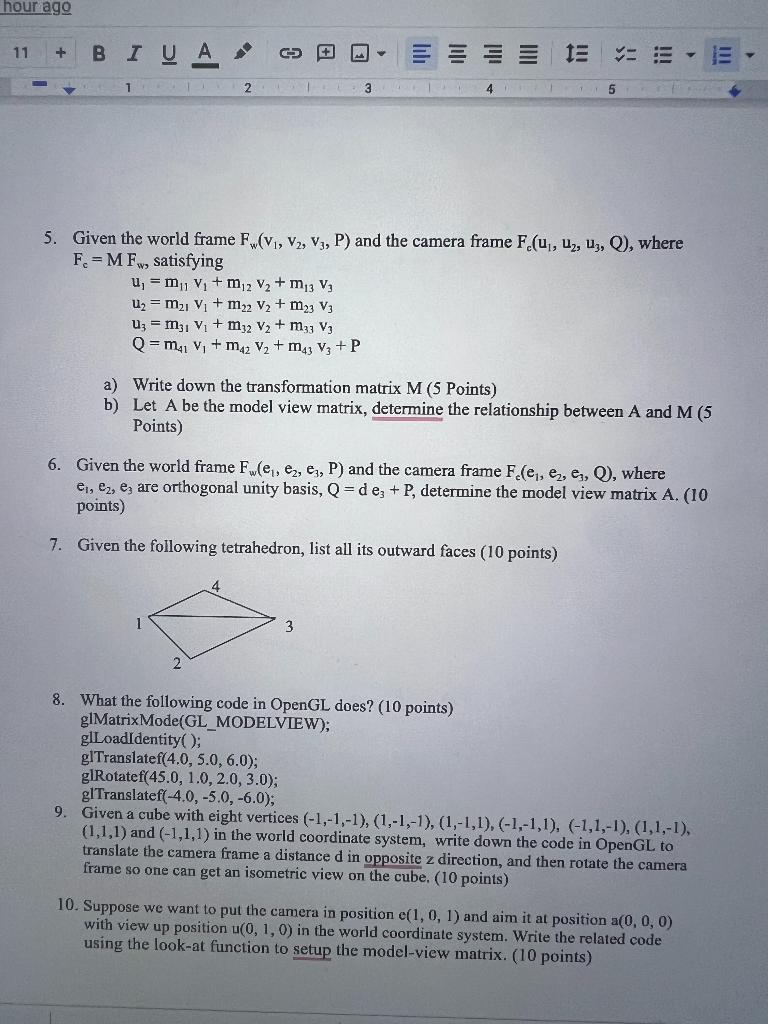
Solved hour ago 5. Given the world frame Fw(v1,v2,v3,P) and | Chegg.com

Transformation from the space-fixed frame (X, Y, Z ) to the body-fixed ...
Advertisement Space (336x280)
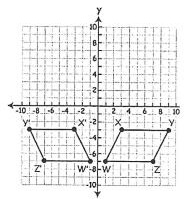
Identify and explain the specific transformation that maps XYWZ onto X ...
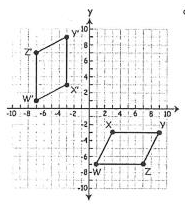
Identify and explain the specific transformation that maps XYWZ onto X ...
Body (X B , Y B , Z B ) and Wind (X W , Y W , Z W ) reference frames ...

Body (X B , Y B , Z B ) and wind (X W , Y W , Z W ) reference frames ...

Solved Use the image below, how to rotate the world frame | Chegg.com

Transformation from the world coordinate system (X, Y, Z) to the ...