
Unable To Convert Call Argument To Python Object When Using Ros2 Topic
Unable to convert call argument to Python object when using ros2 topic ...
Evaluation error: Unable to convert R object to Python type · Issue #68 ...

Unable to call service using asynchronous service client Rosject task 2 ...
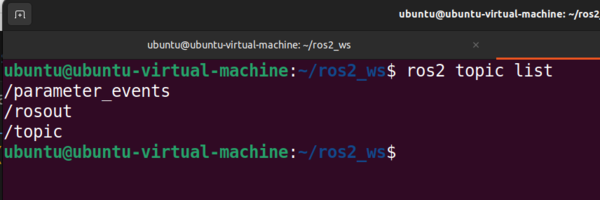
How to Create a ROS2 Python Publisher – Iron

Using call to Make Objects Callable - Arashtad
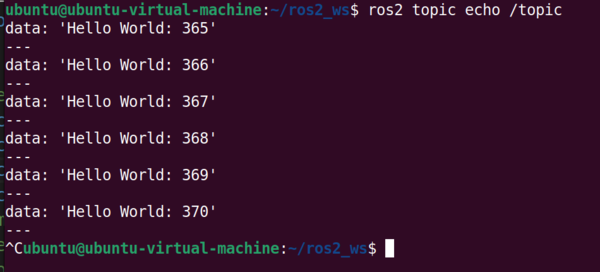
How to Create a ROS2 Python Publisher – Iron
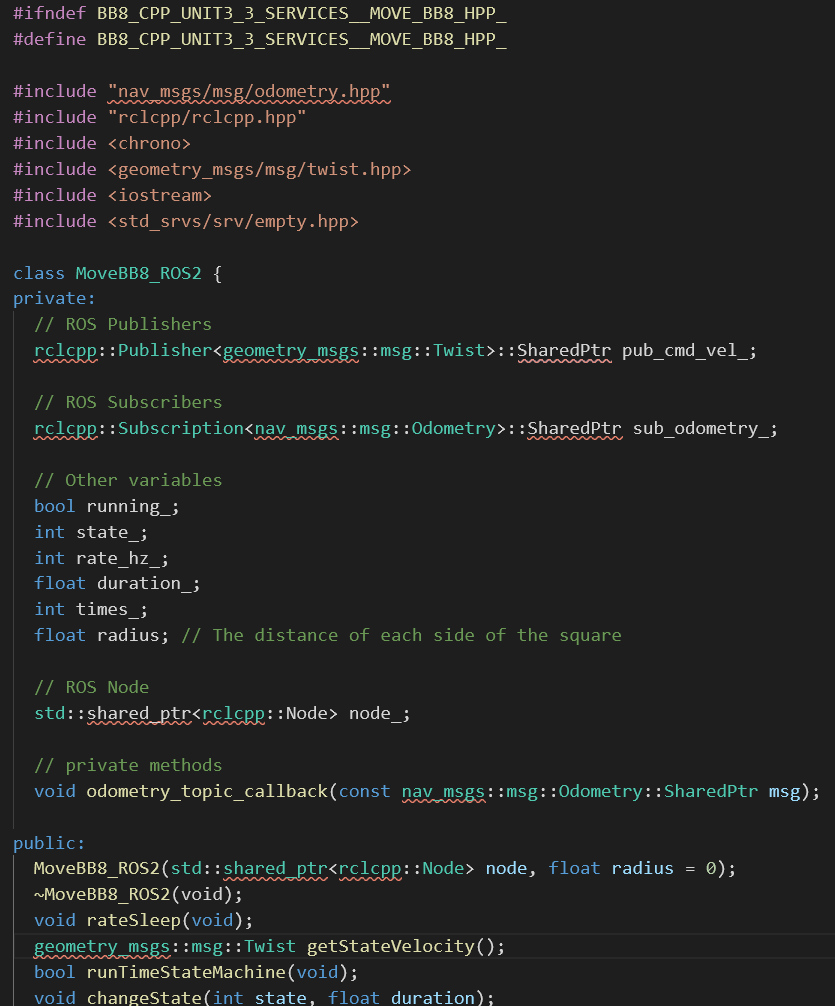
How to link callback function to a subscription - ROS2 In 5 Days Python ...
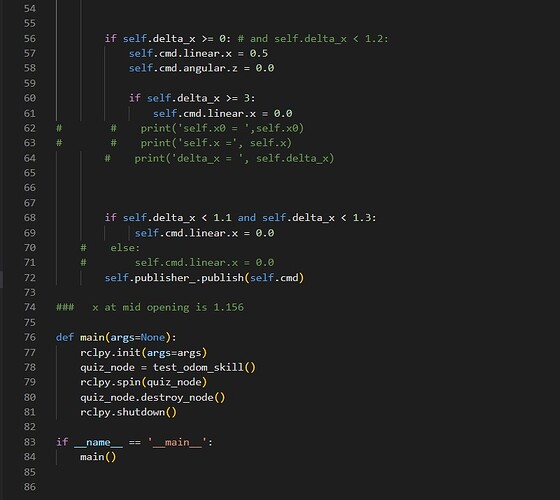
Unable to understand error message and make robot turn - ROS2 Basics in ...
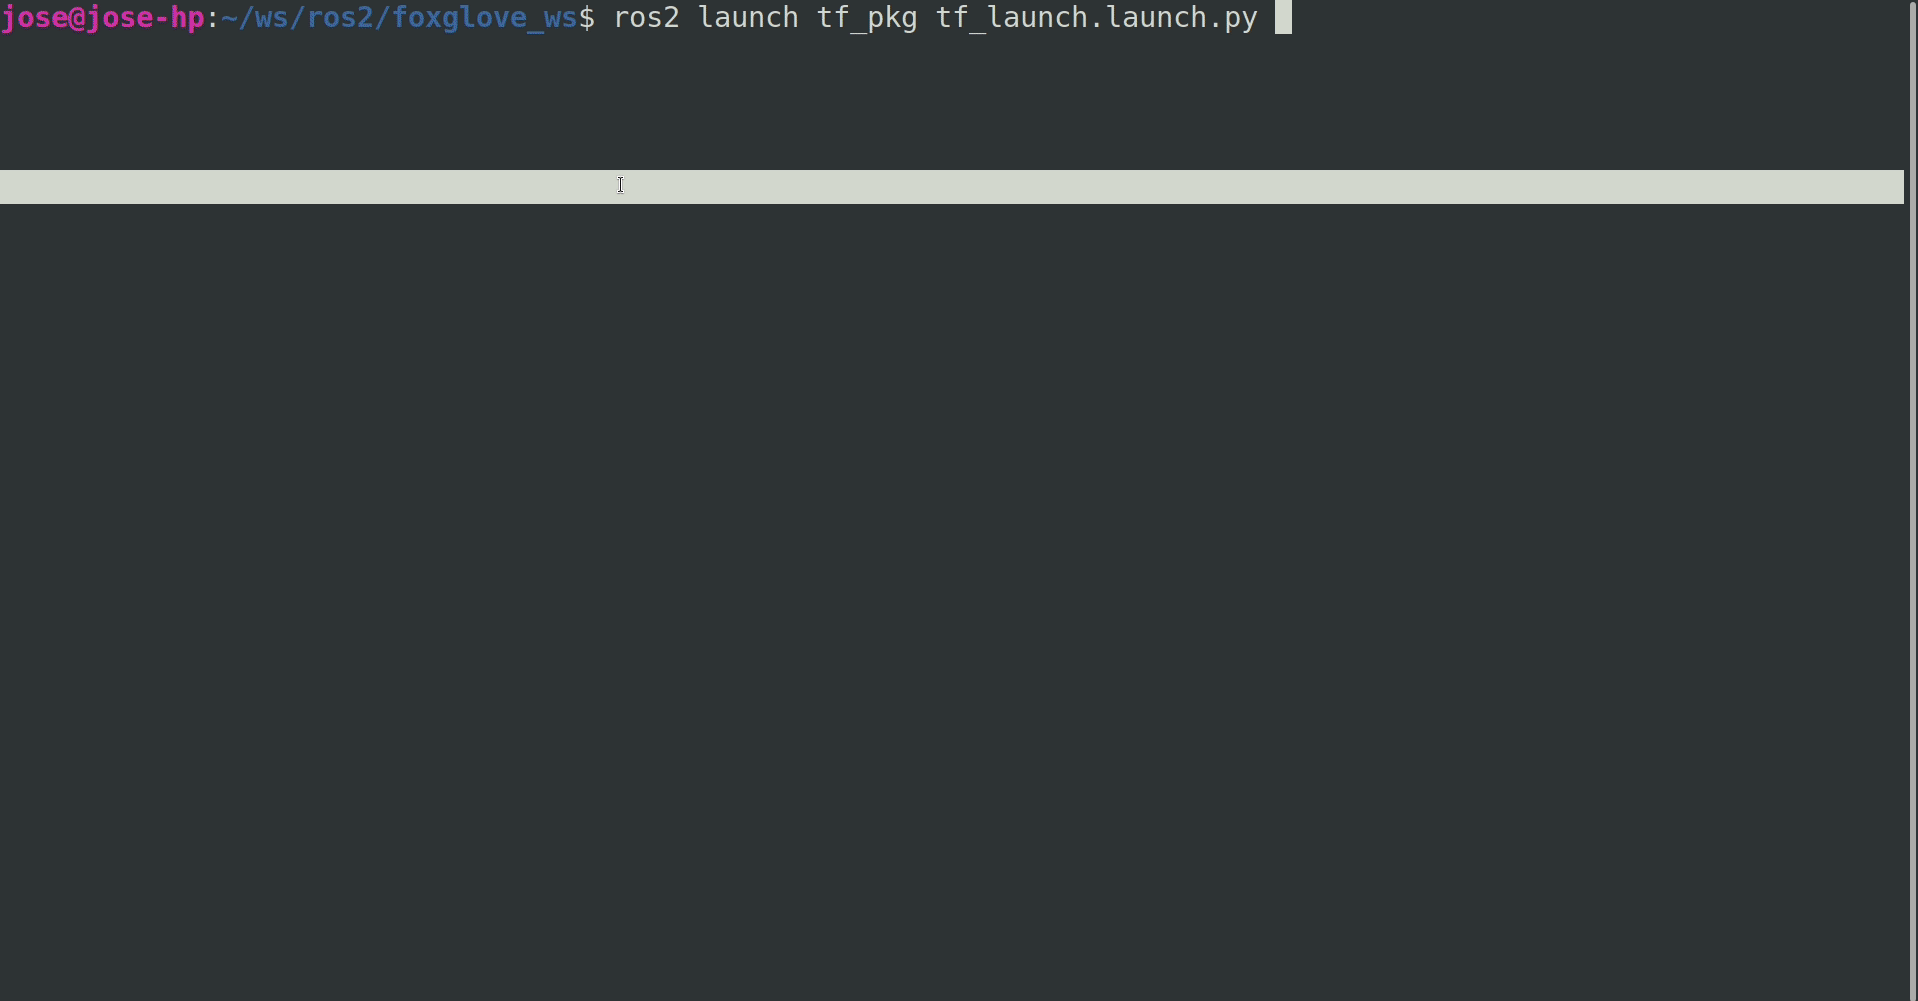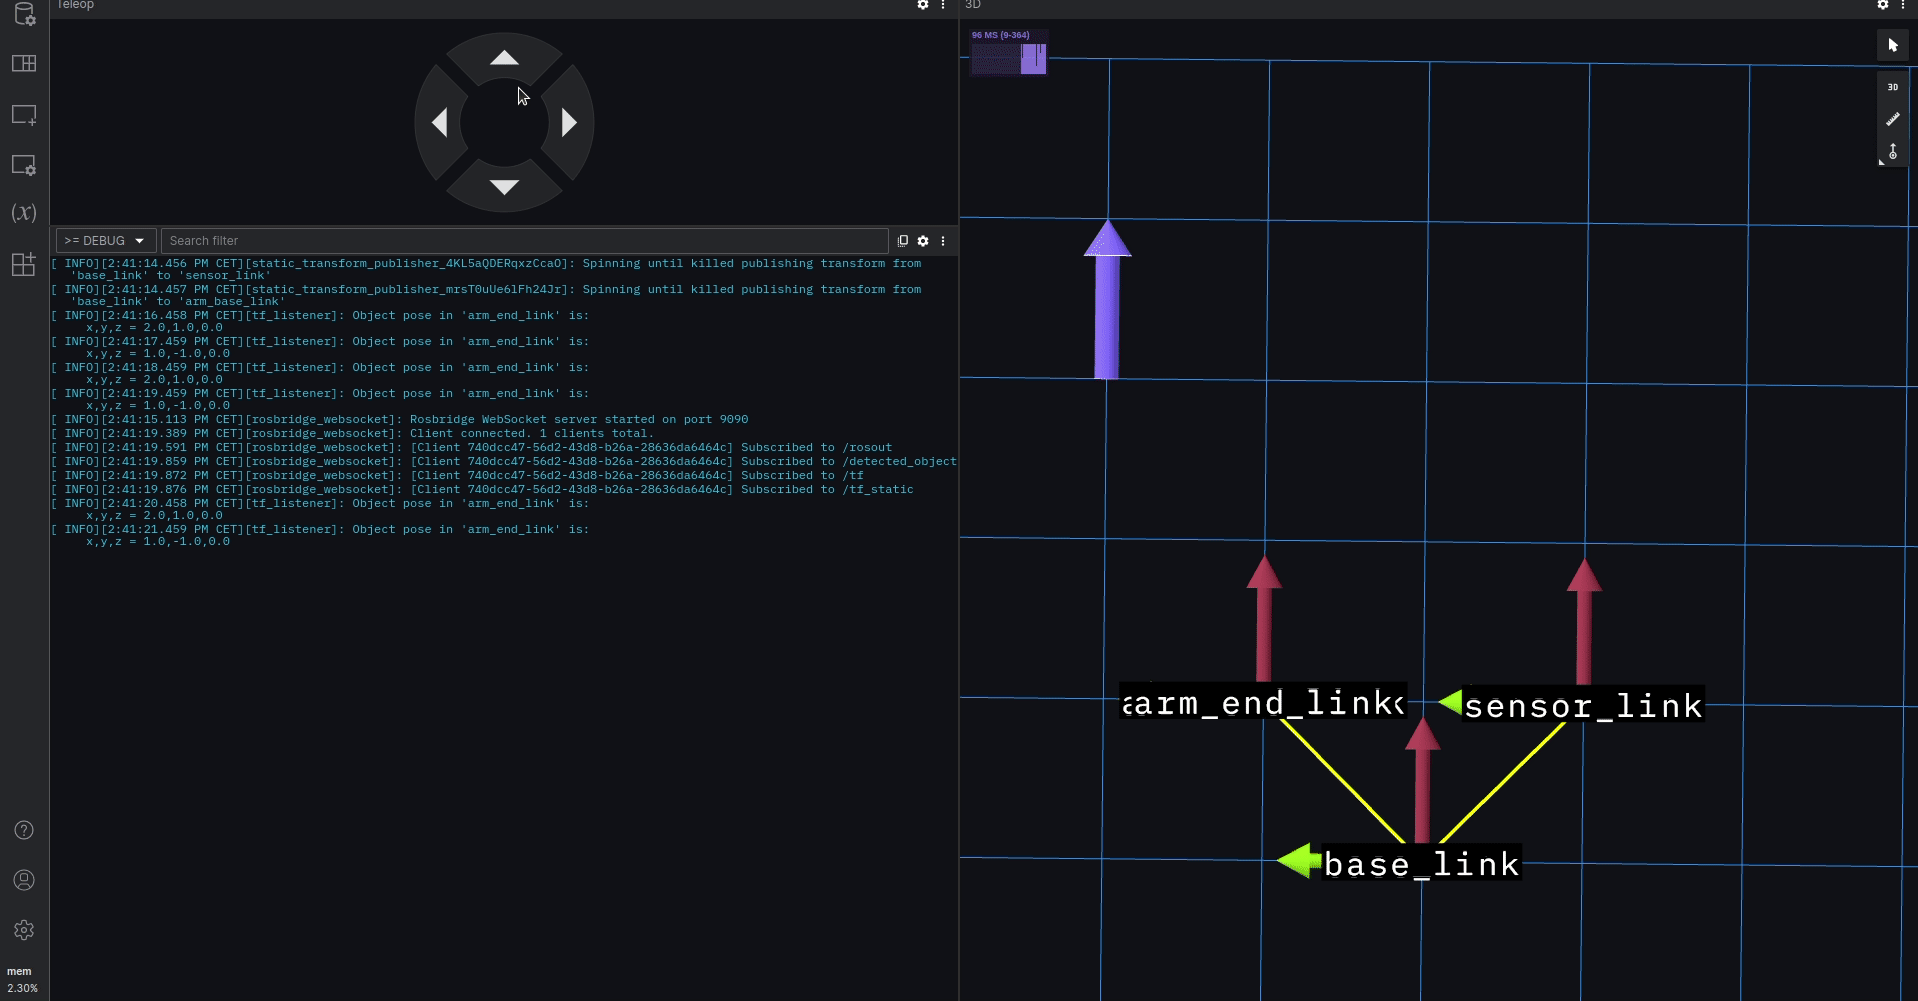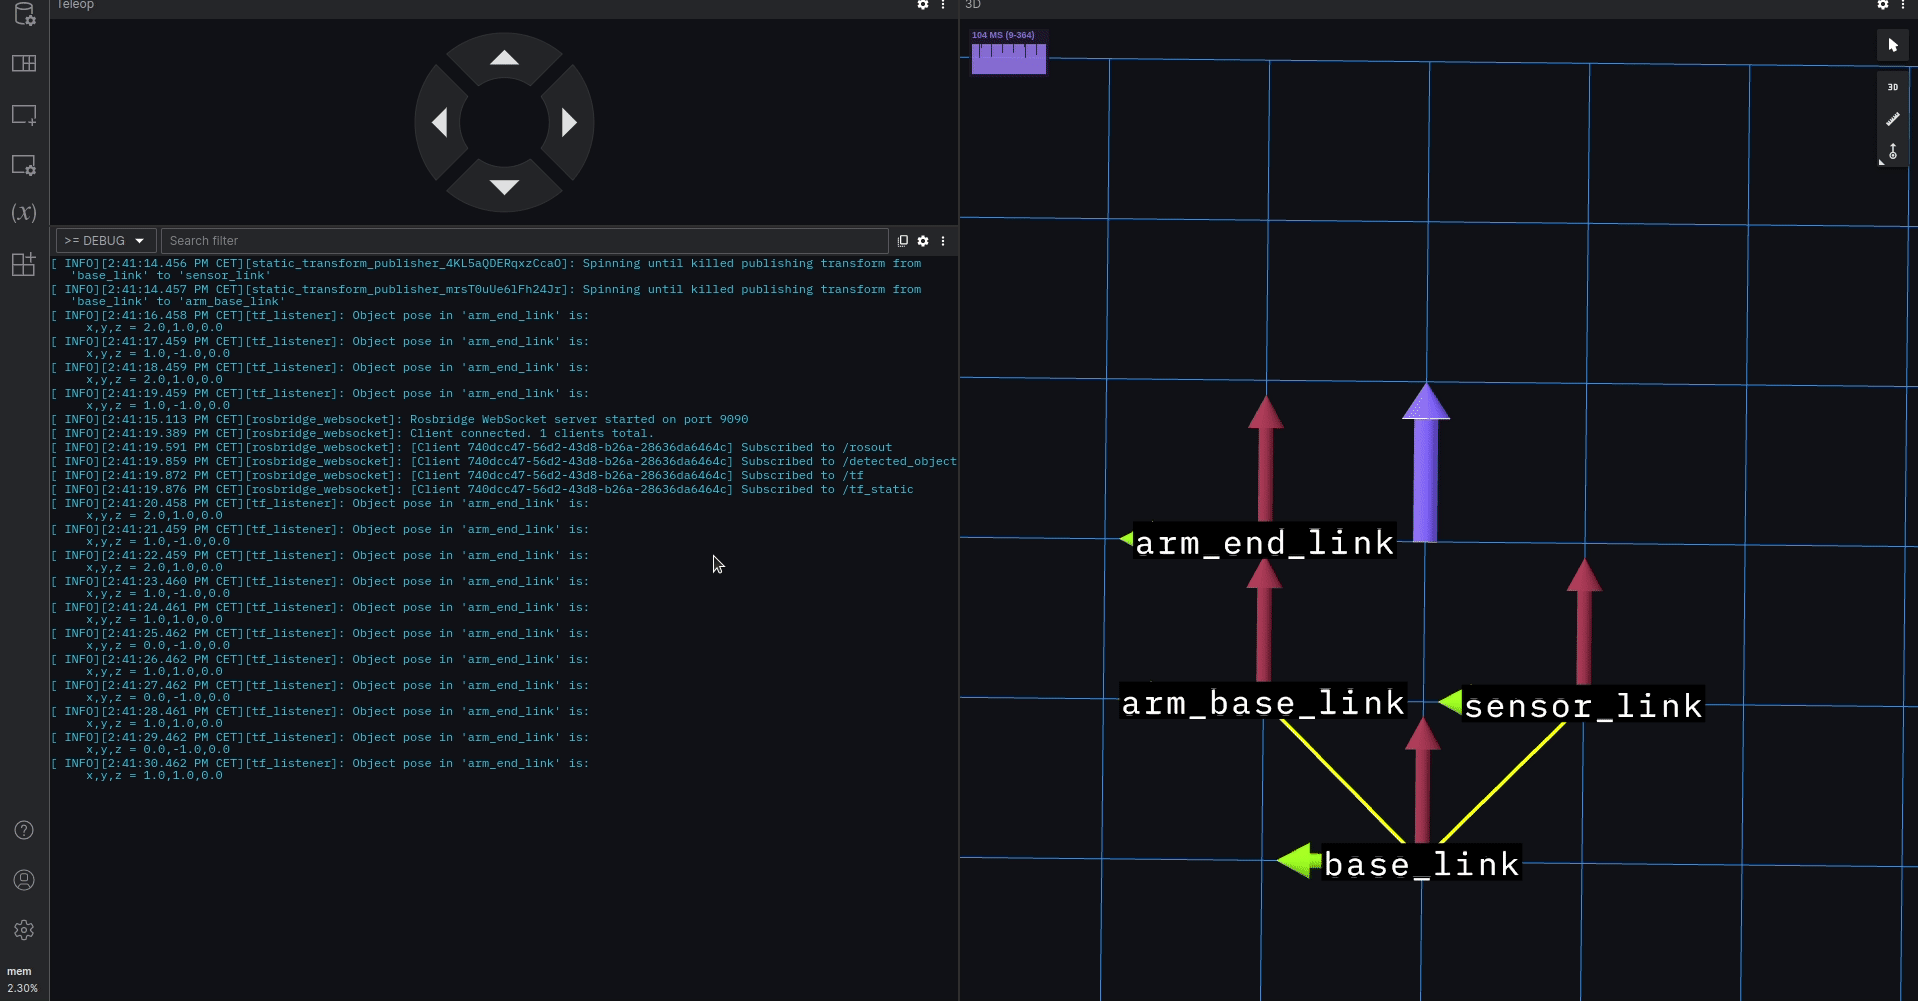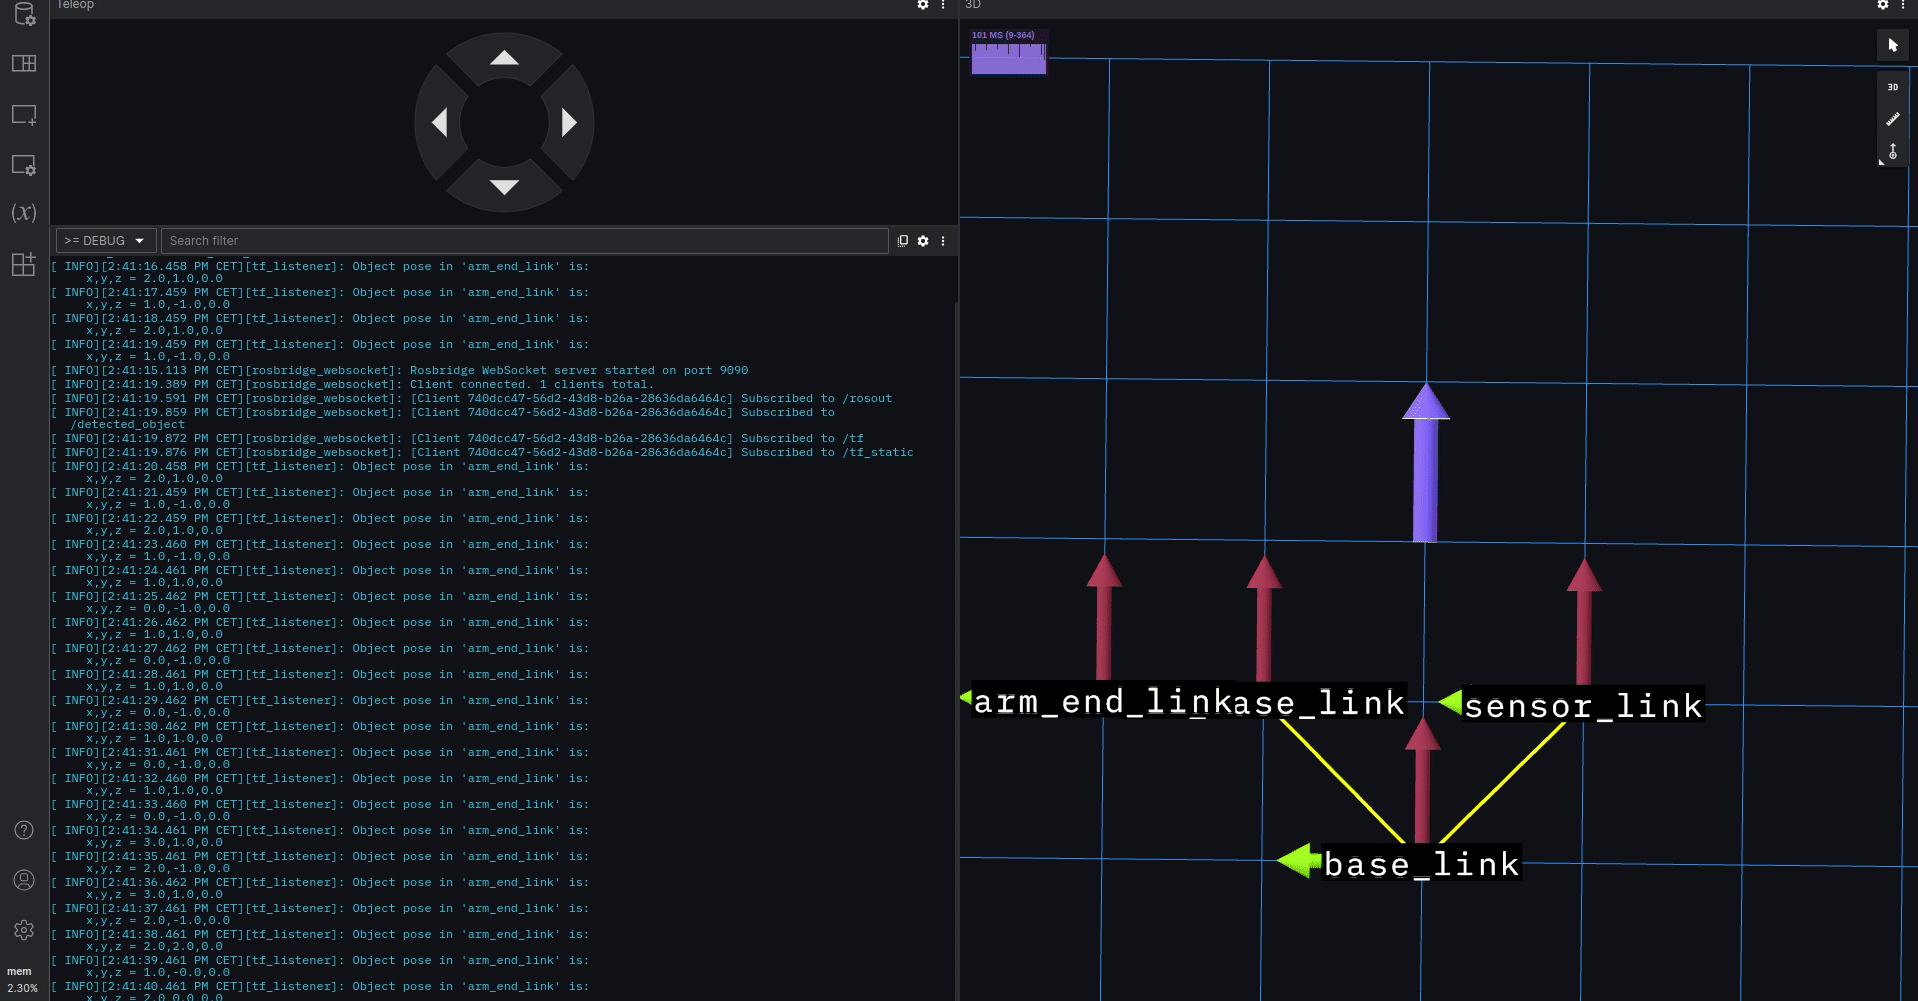
Using ROS 2 Transforms to Calculate Object Positions | Foxglove
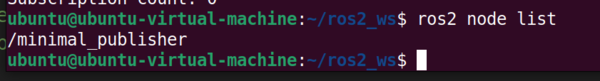
How to Create a ROS2 Python Publisher – Iron
Advertisement Space (300x250)
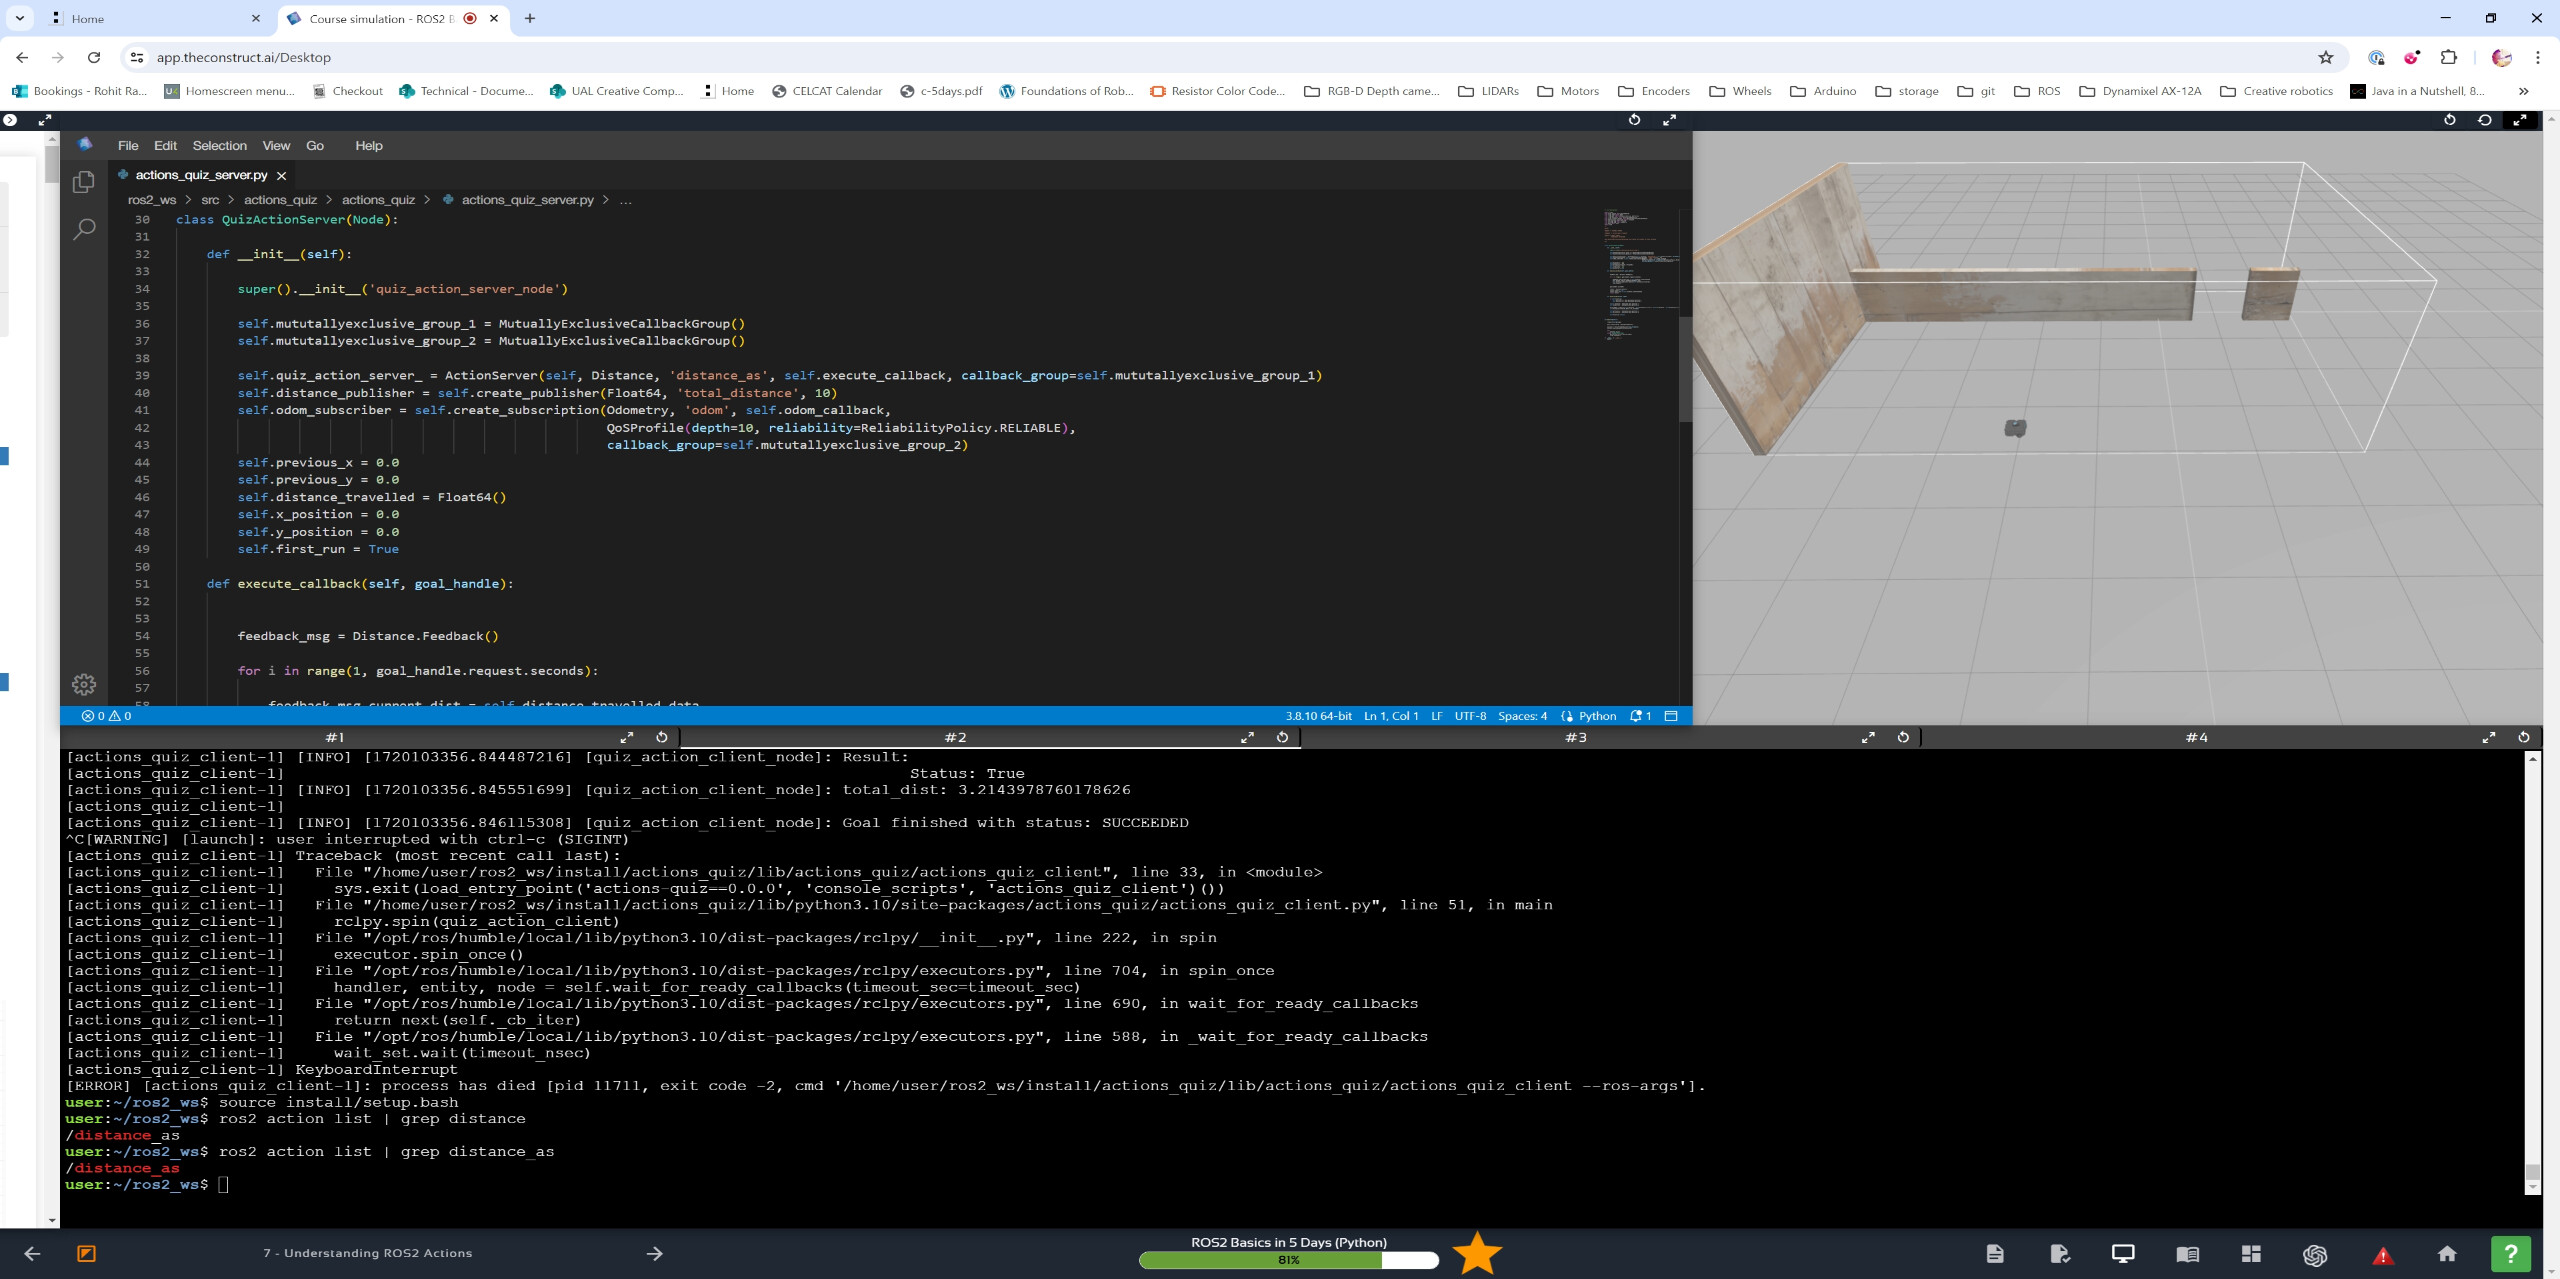
[Bug] Gradebot unable to find /distance_as action - ROS2 Basics in 5 ...

Unable to launch my launch file - ROS2 Basics in 5 Days Humble (Python ...
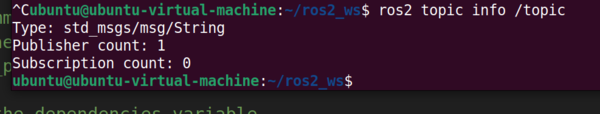
How to Create a ROS2 Python Publisher – Iron
How to Fix: Positional Argument Follows Keyword Argument in Python
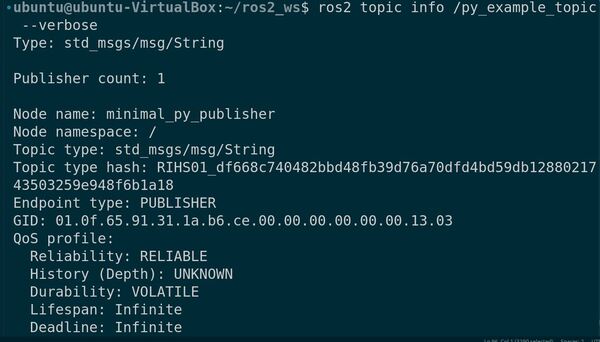
How to Create a ROS 2 Python Publisher – Jazzy
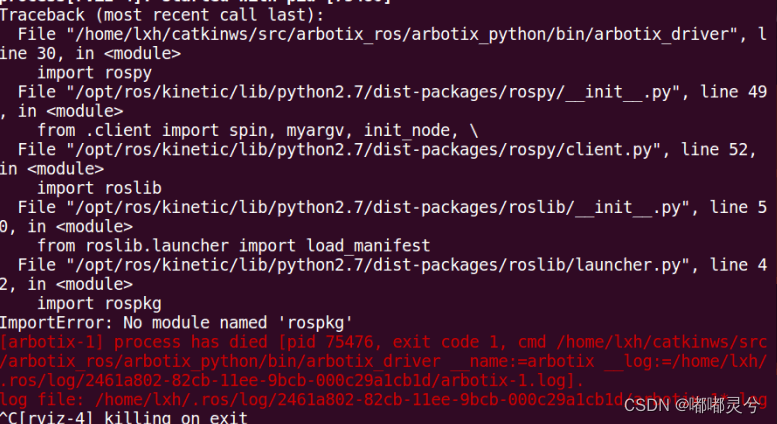
ROS问题记录_error: incompatible arguments to call service: not-CSDN博客
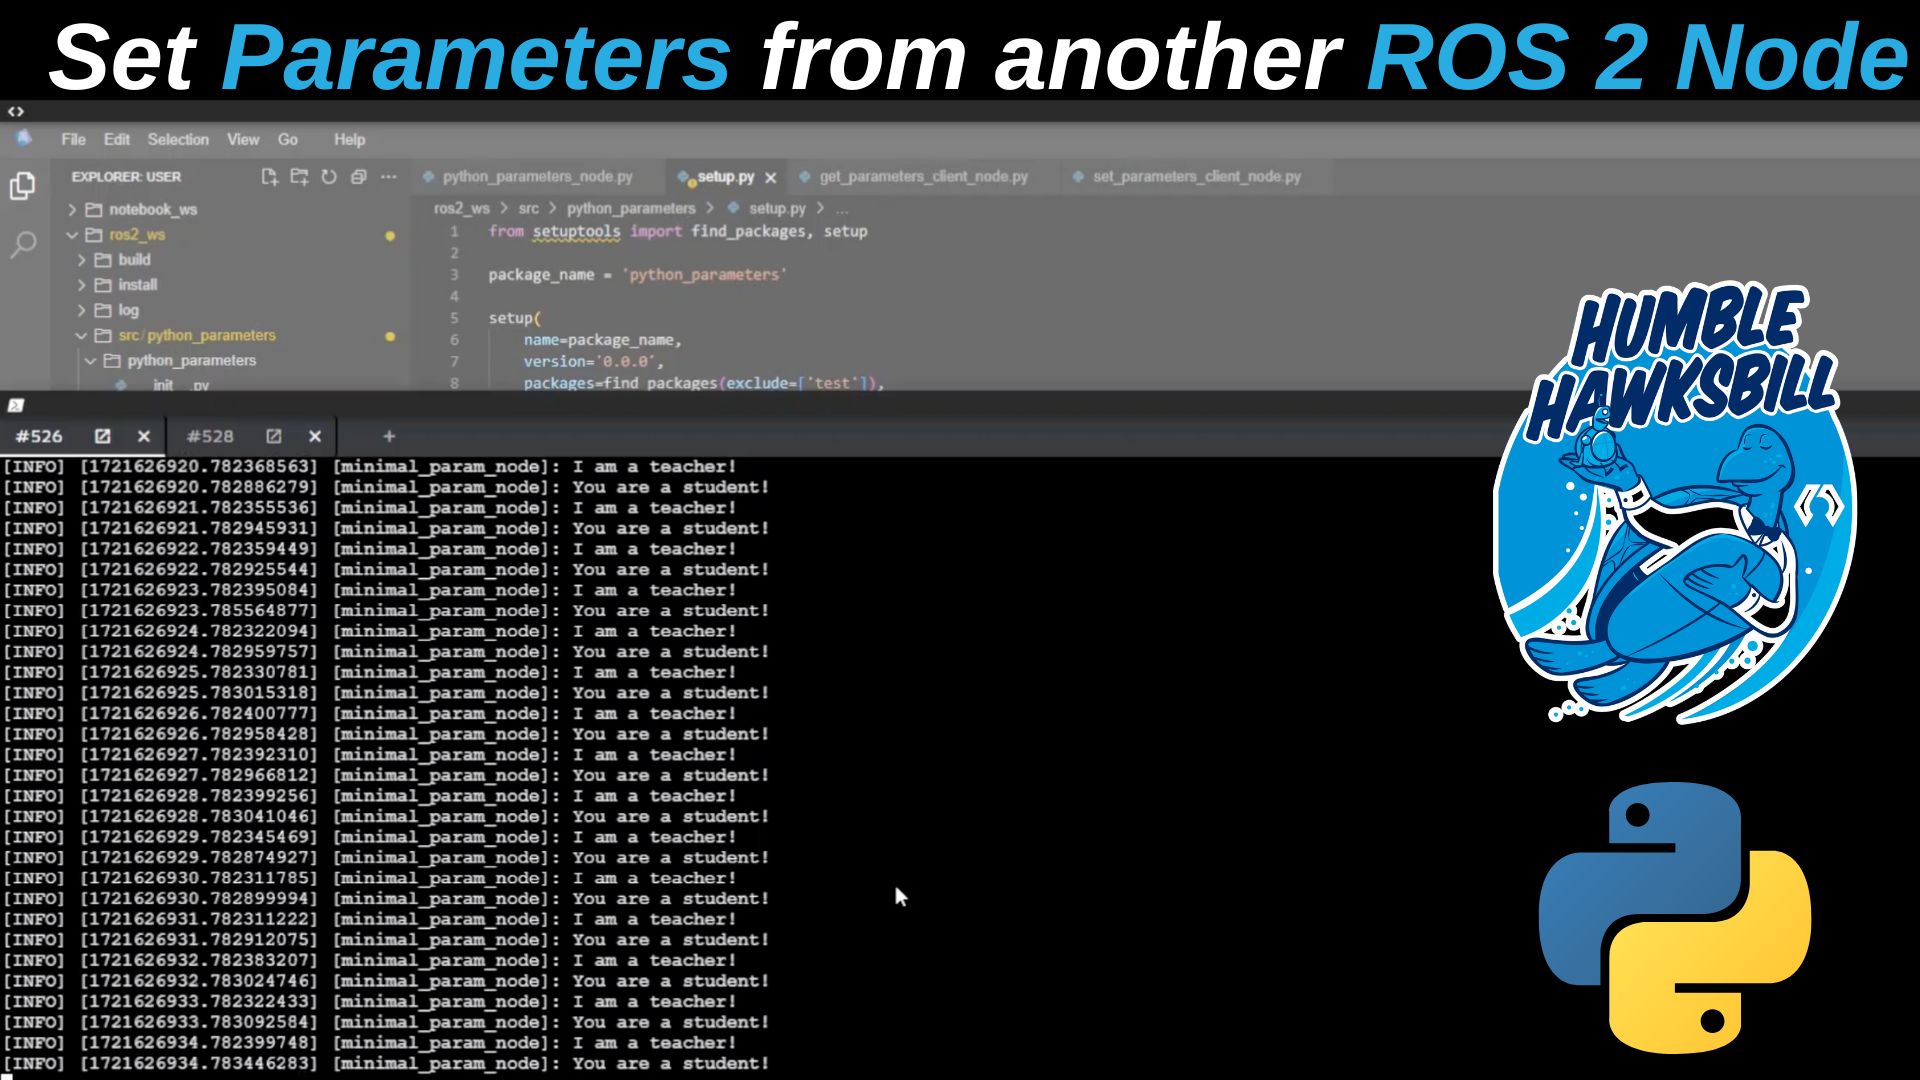
How to set/get parameters from another node | ROS 2 Humble Python ...
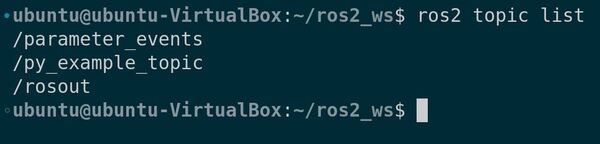
How to Create a ROS 2 Python Publisher – Jazzy
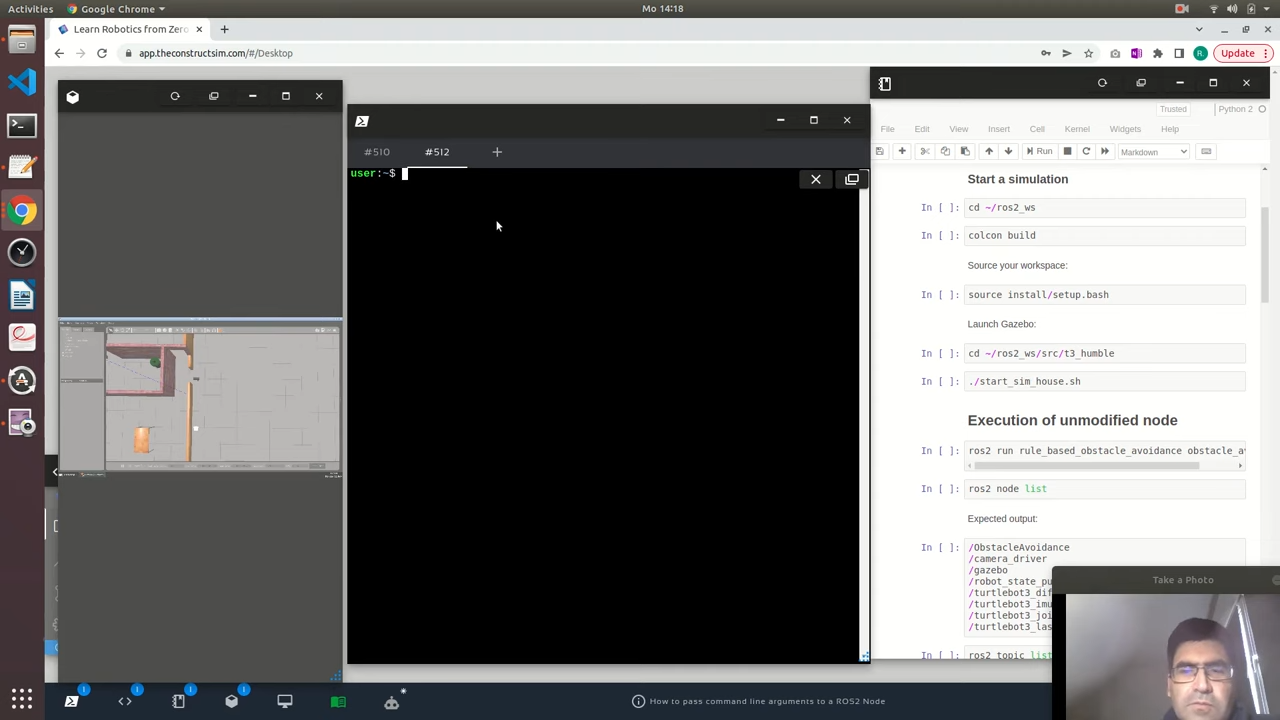
Passing arguments to ROS 2 Nodes using -ros-arg - The Construct

Intro to ROS Part 5: Services, Requests, and Responses with Python
Advertisement Space (336x280)

How to import custom Python3 modules in a ROS2 package | ROS2 Humble ...
Passing arguments to ROS 2 Nodes using -ros-arg - The Construct
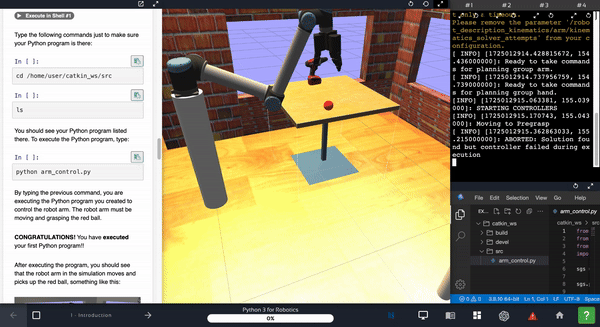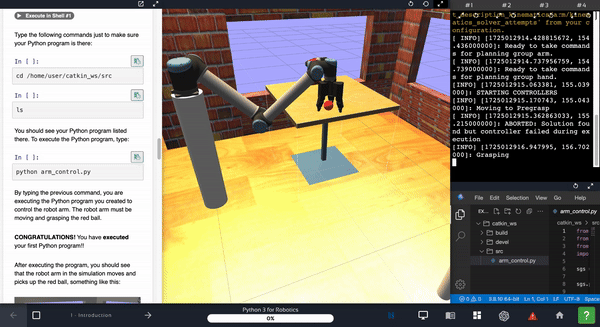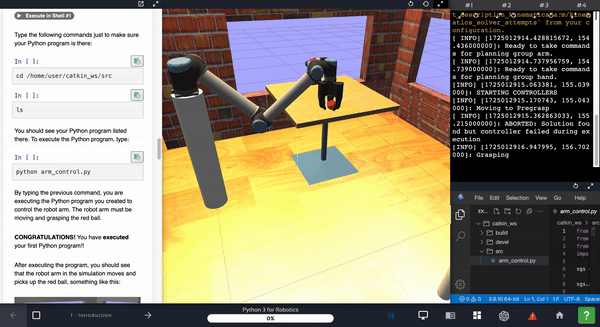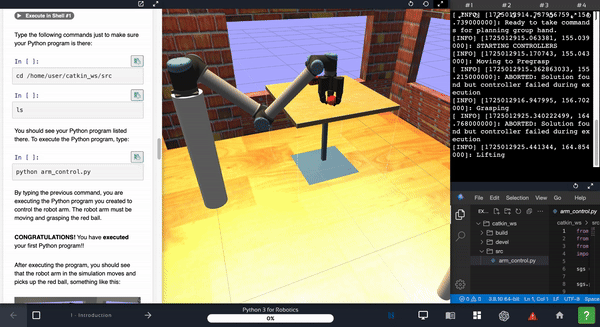
ROS2 Programming Basics Using Python | The Construct

exception - Call C++ function using Python ctypes with py_object ...
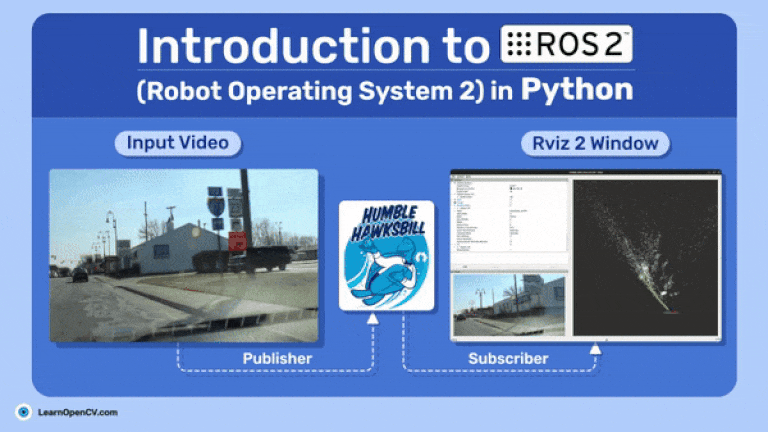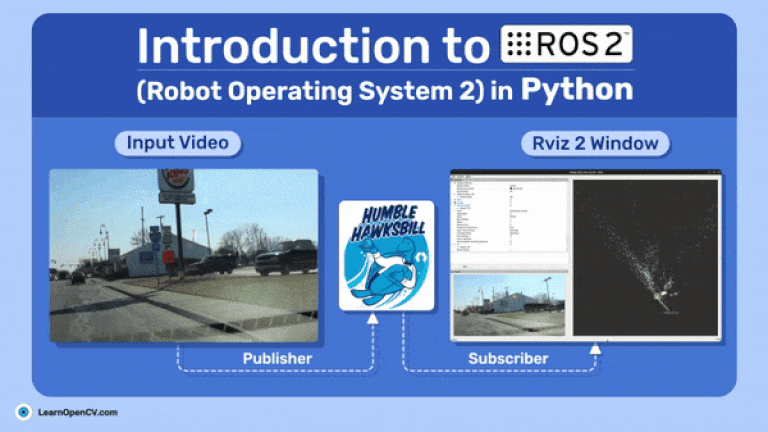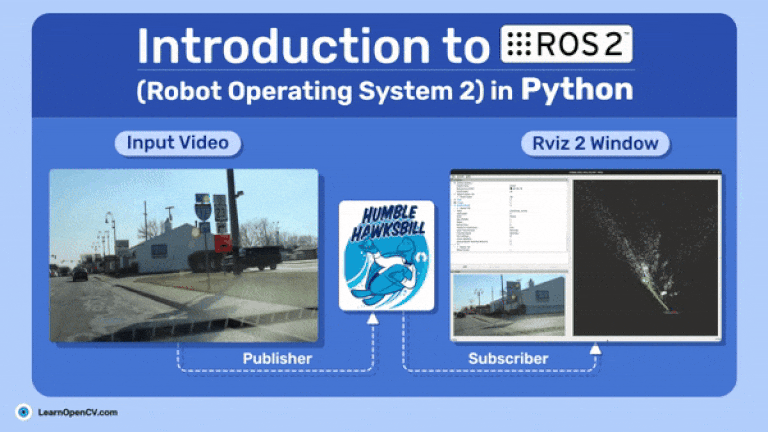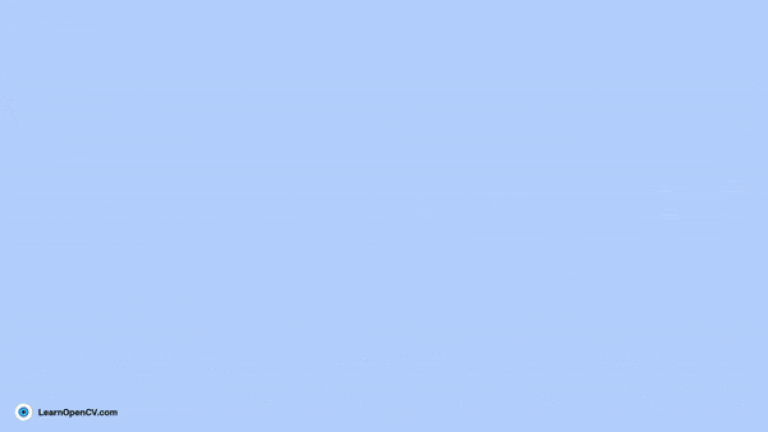
Introduction to ROS 2 (Robot Operating System 2) in Python
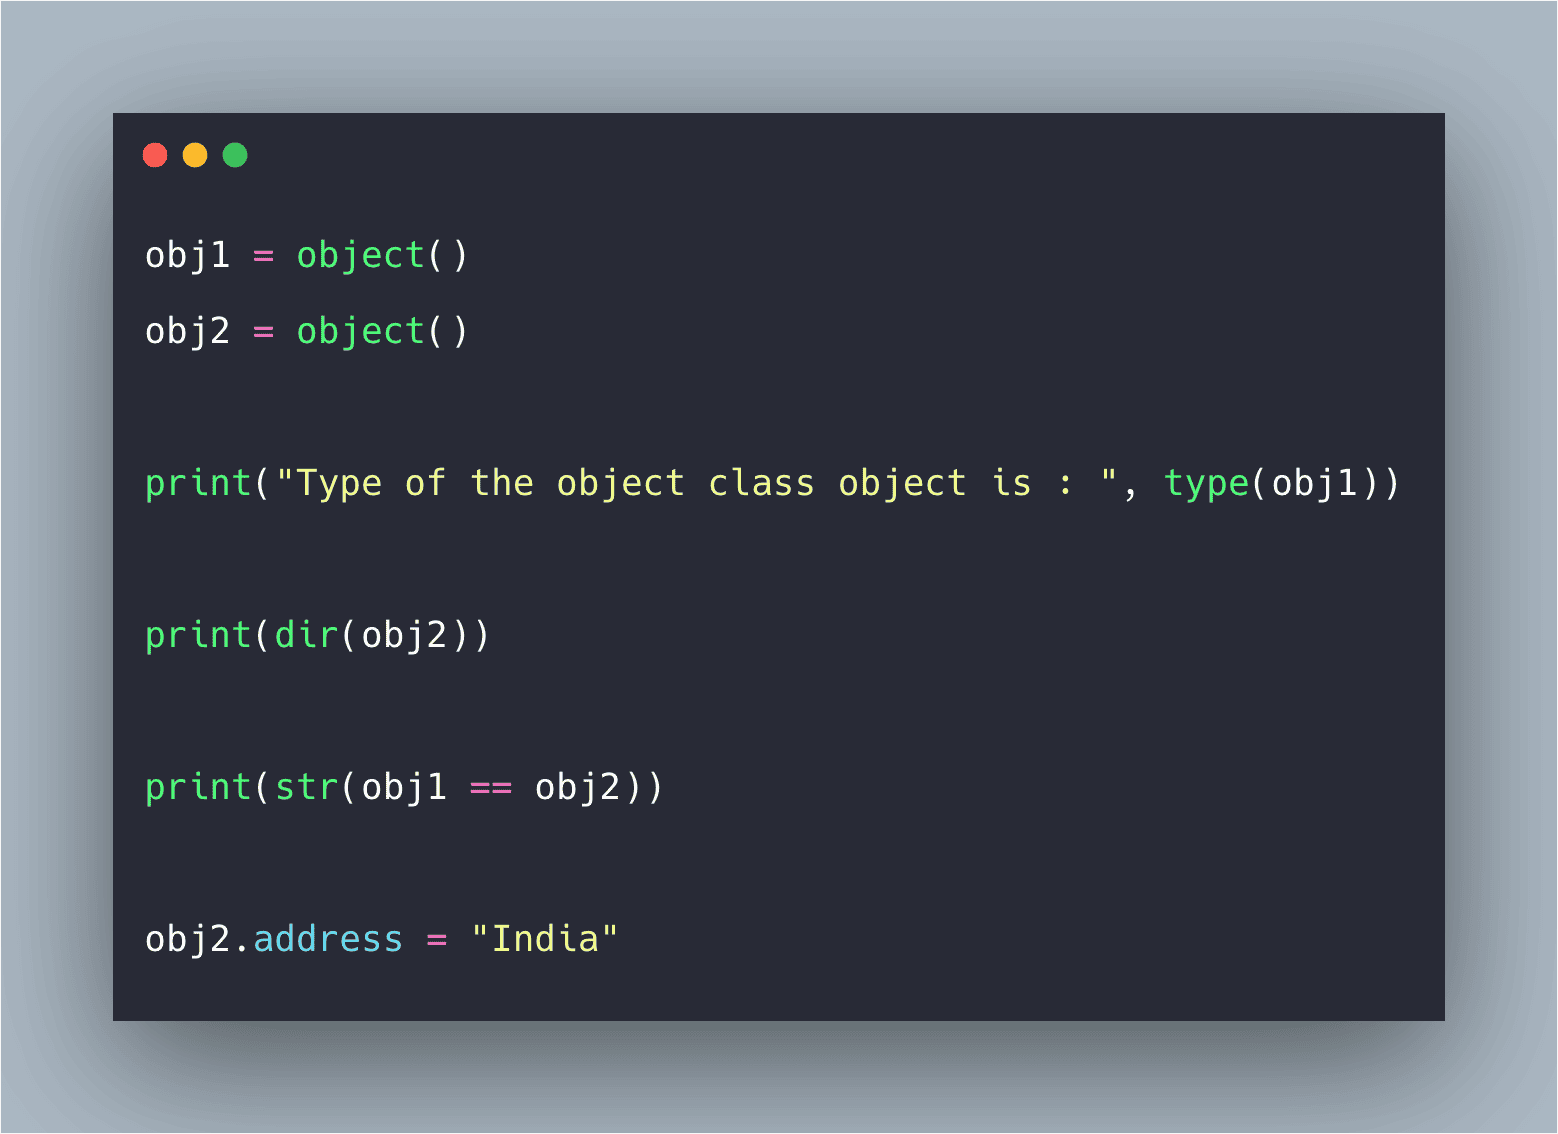
Call Class Function Using A List Of Class Objects Python – LKBJ
ROS2 Programming Basics Using Python | The Construct

Arduino-ROS Interface with Python – Send Messages From Python/ROS to ...
ROS2 Daemon fails to respond · Issue #702 · ros2/ros2cli · GitHub
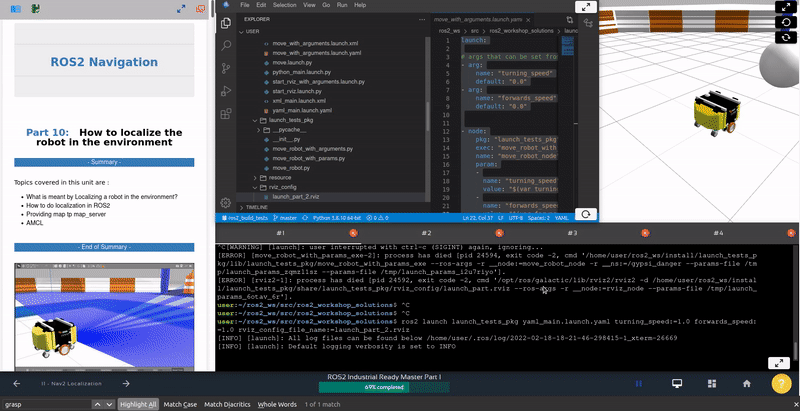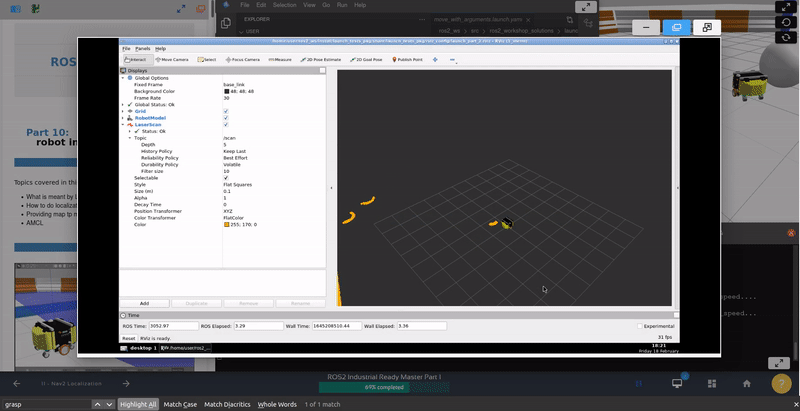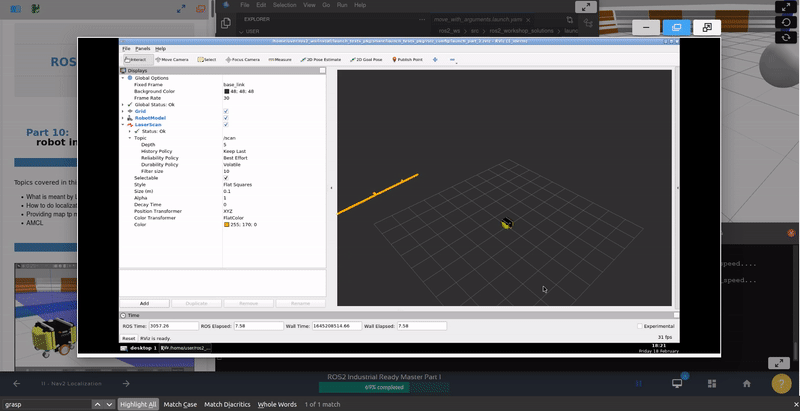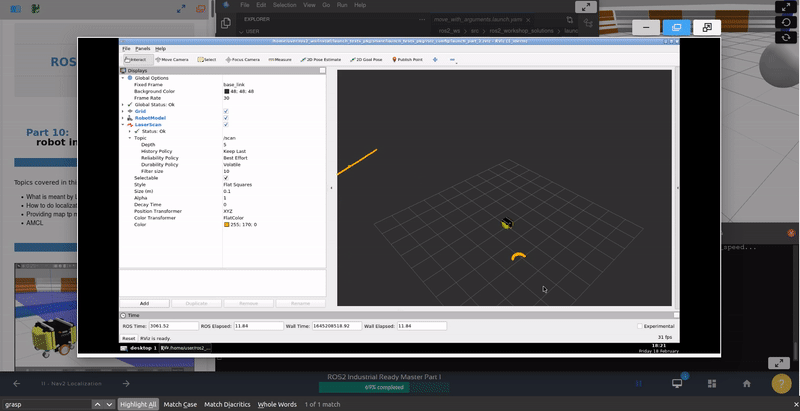
How to use C++ and Python in the same ROS 2 package - English ROS 2 ...
Advertisement Space (336x280)

ros kinetic - How to get the data from Subscribers message with python ...

Use default argument if argument is None on python method call - YouTube

passed to lookupTransform argument t arget_frame does not exist · Issue ...

PYTHON : Call a function with argument list in python - YouTube
GitHub - yousif20121/example_ros2: Example ROS2 nodes using Python ...
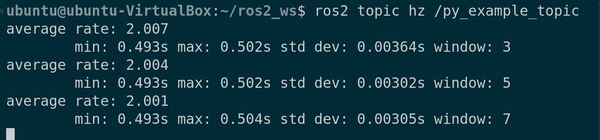
How to Create a ROS 2 Python Publisher – Jazzy