
Universal Robot With Ros How To Get Your End Effector Orientation And

Universal Robot with ROS - How to get your end effector orientation and ...

How to Get your Robot End Effector Orientation in Quaternions using ROS ...

Universal Robot with ROS - How to simulate UR5 in Gazebo and code ...

How to set Position and Orientation of your Robot in ROS2 | Run Inverse ...

Universal Robot with ROS - How UR5 package is made and program inverse ...
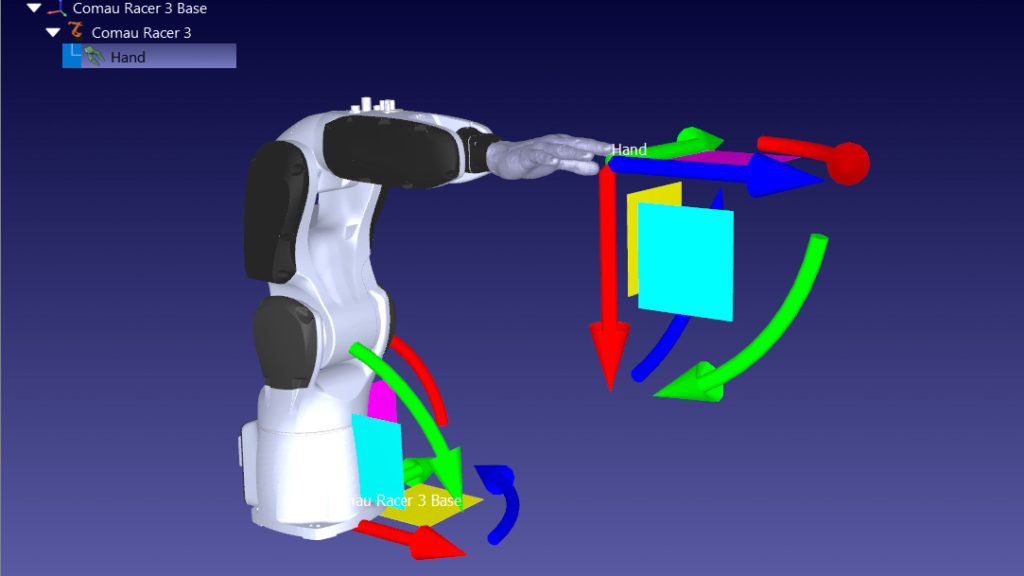
How to Program Any End Effector with RoboDK - RoboDK blog

Setting up a new Universal Robot with ROS | by NightFury | Robots And ...

Study of Orientation Error on Robot End Effector and Volumetric Error ...
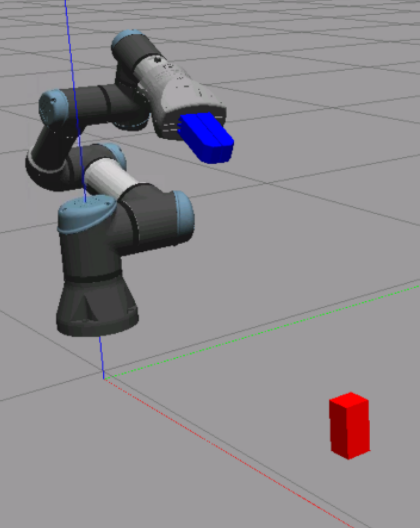
How to change end effector for UR5? - General Support - The Construct ...

(a) Current orientation and position vectors for the end effector of a ...
Advertisement Space (300x250)

(a) Current orientation and position vectors for the end effector of a ...

Robot End Effector Orientation Control - YouTube

Connecting The Robot To Ros | ROS Interface for Universal Robots – MPZJ

(a) Robot base coordinate, end effector coordinate, and camera ...
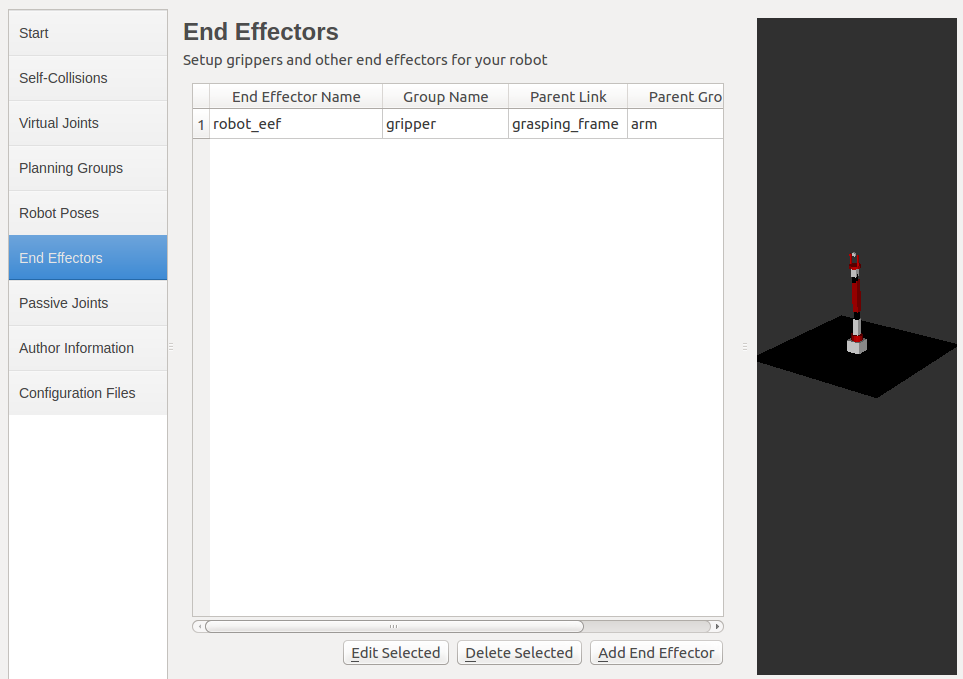
Step 6 – Setting up the robot end effector - Mastering ROS for Robotics ...
Connecting The Robot To Ros | ROS Interface for Universal Robots – MPZJ
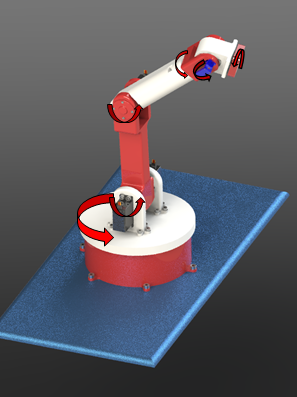
Simulate your CAD model of the Robot in ROS | Hackaday.io

End effector direction - URScript - Universal Robots Forum
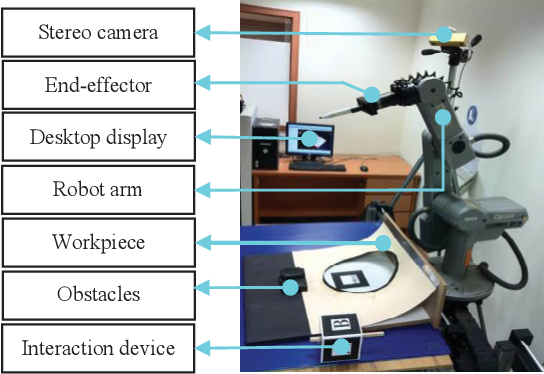
Figure 1 from Robot Path and End-Effector Orientation Planning Using ...

Dual-Criteria Robot Control: Optimization with End-Effector Orientation ...
Advertisement Space (336x280)

According to obtained joint angles, the end effector position of the ...
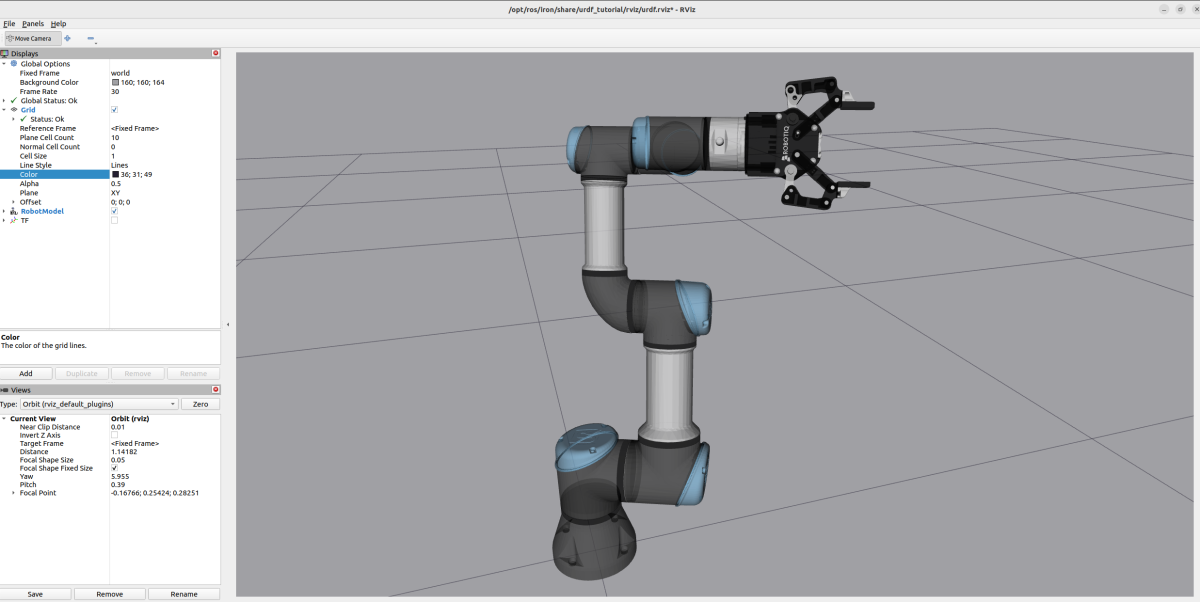
How to Create a URDF File of the UR3e Robotic Arm – ROS 2

The goal is to drive the robot end-effector to the target position and ...

Constrain path planned simulation, keeping the end effector orientation ...

Getting Started with Standalone ROS Node Generation for Universal ...
How to Control Two Universal Robots (UR-5) in the same Simulation ...
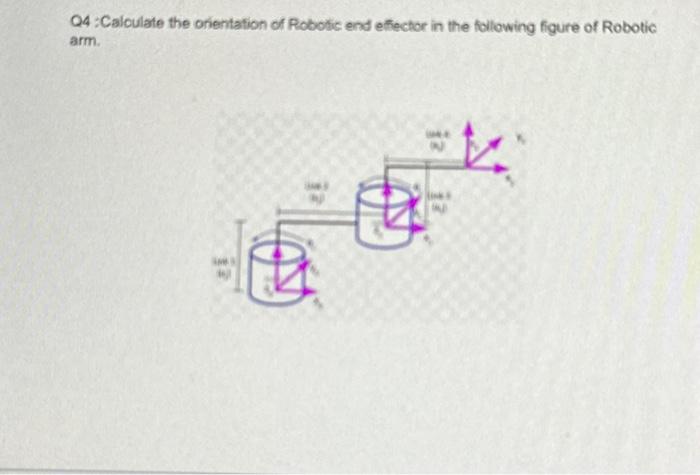
Solved 04:Calculate the orientation of Robotic end effector | Chegg.com
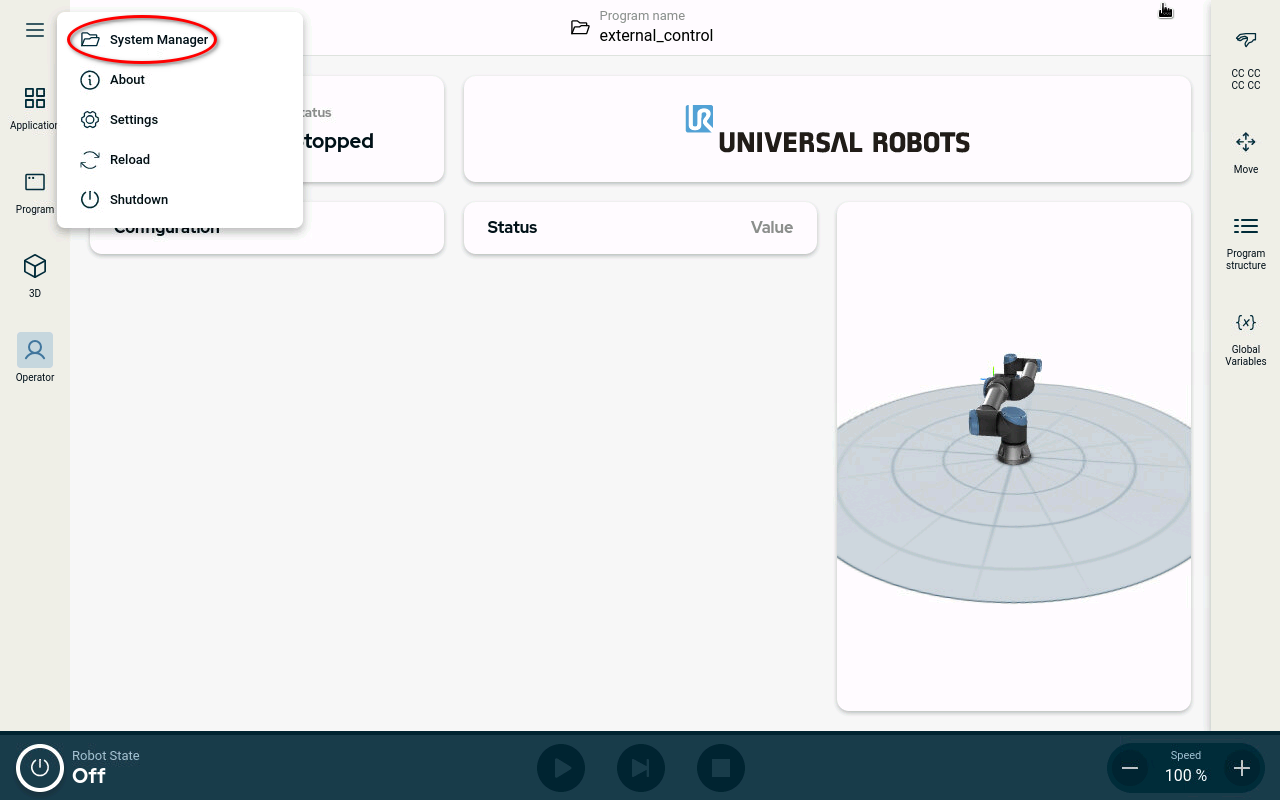
Robot setup — Universal Robots ROS 2 Driver Documentation 0.1 documentation

Develop Universal Robot (UR) in ROS: From Install to Demo_universal ...
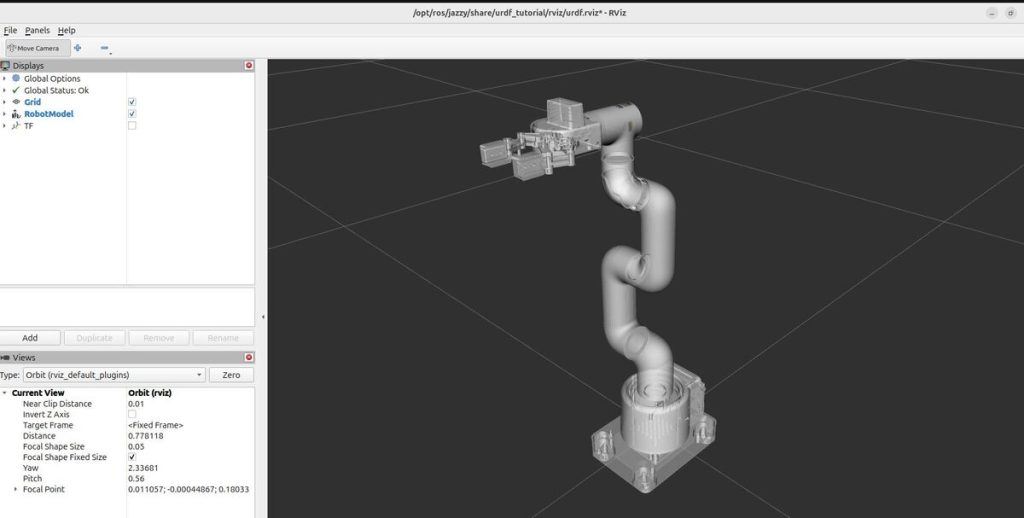
Create and Visualize a Robotic Arm with URDF – ROS 2 Jazzy
Advertisement Space (336x280)
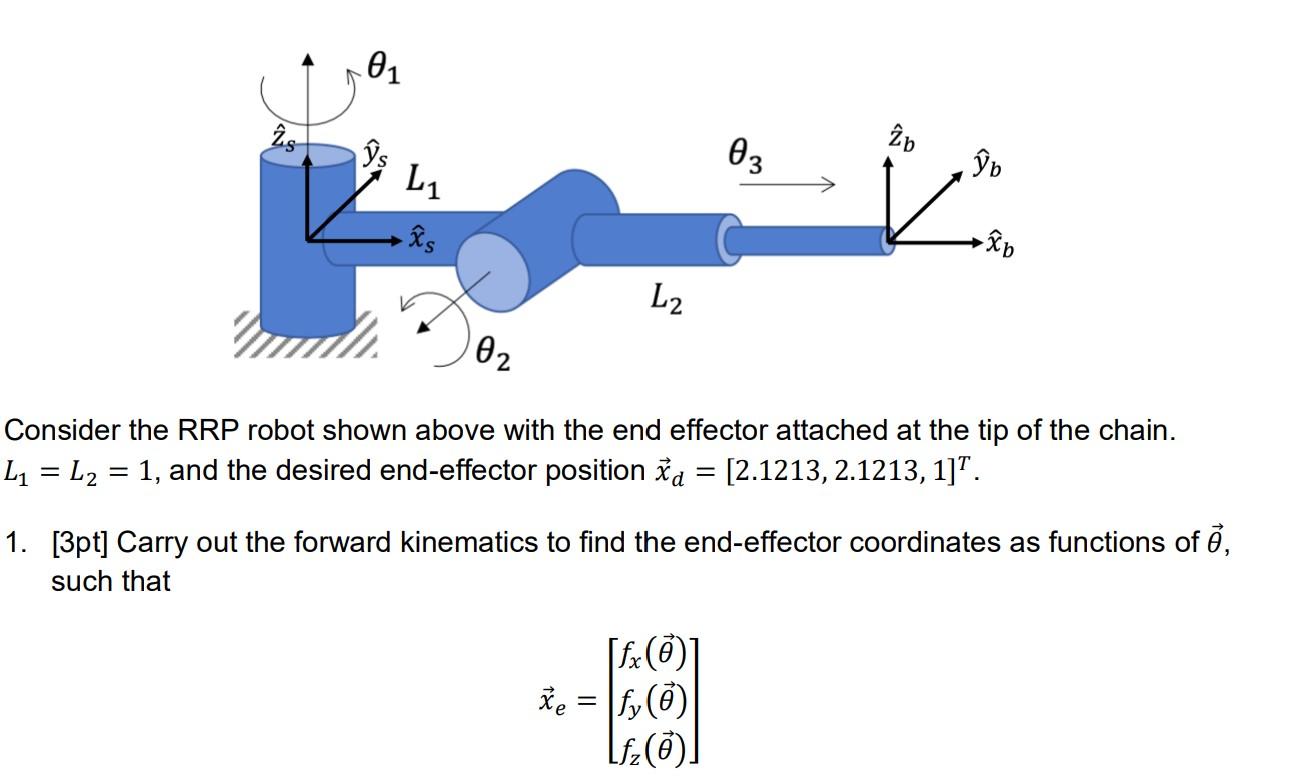
Consider the RRP robot shown above with the end | Chegg.com

Robot End Effector – Benefits Of Using The Right Robot End Effector On ...
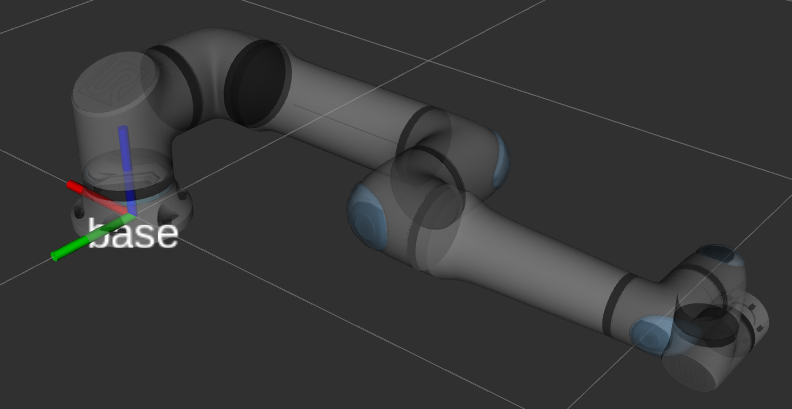
Robot Frames — Universal Robots ROS 2 Driver Documentation 0.1 ...
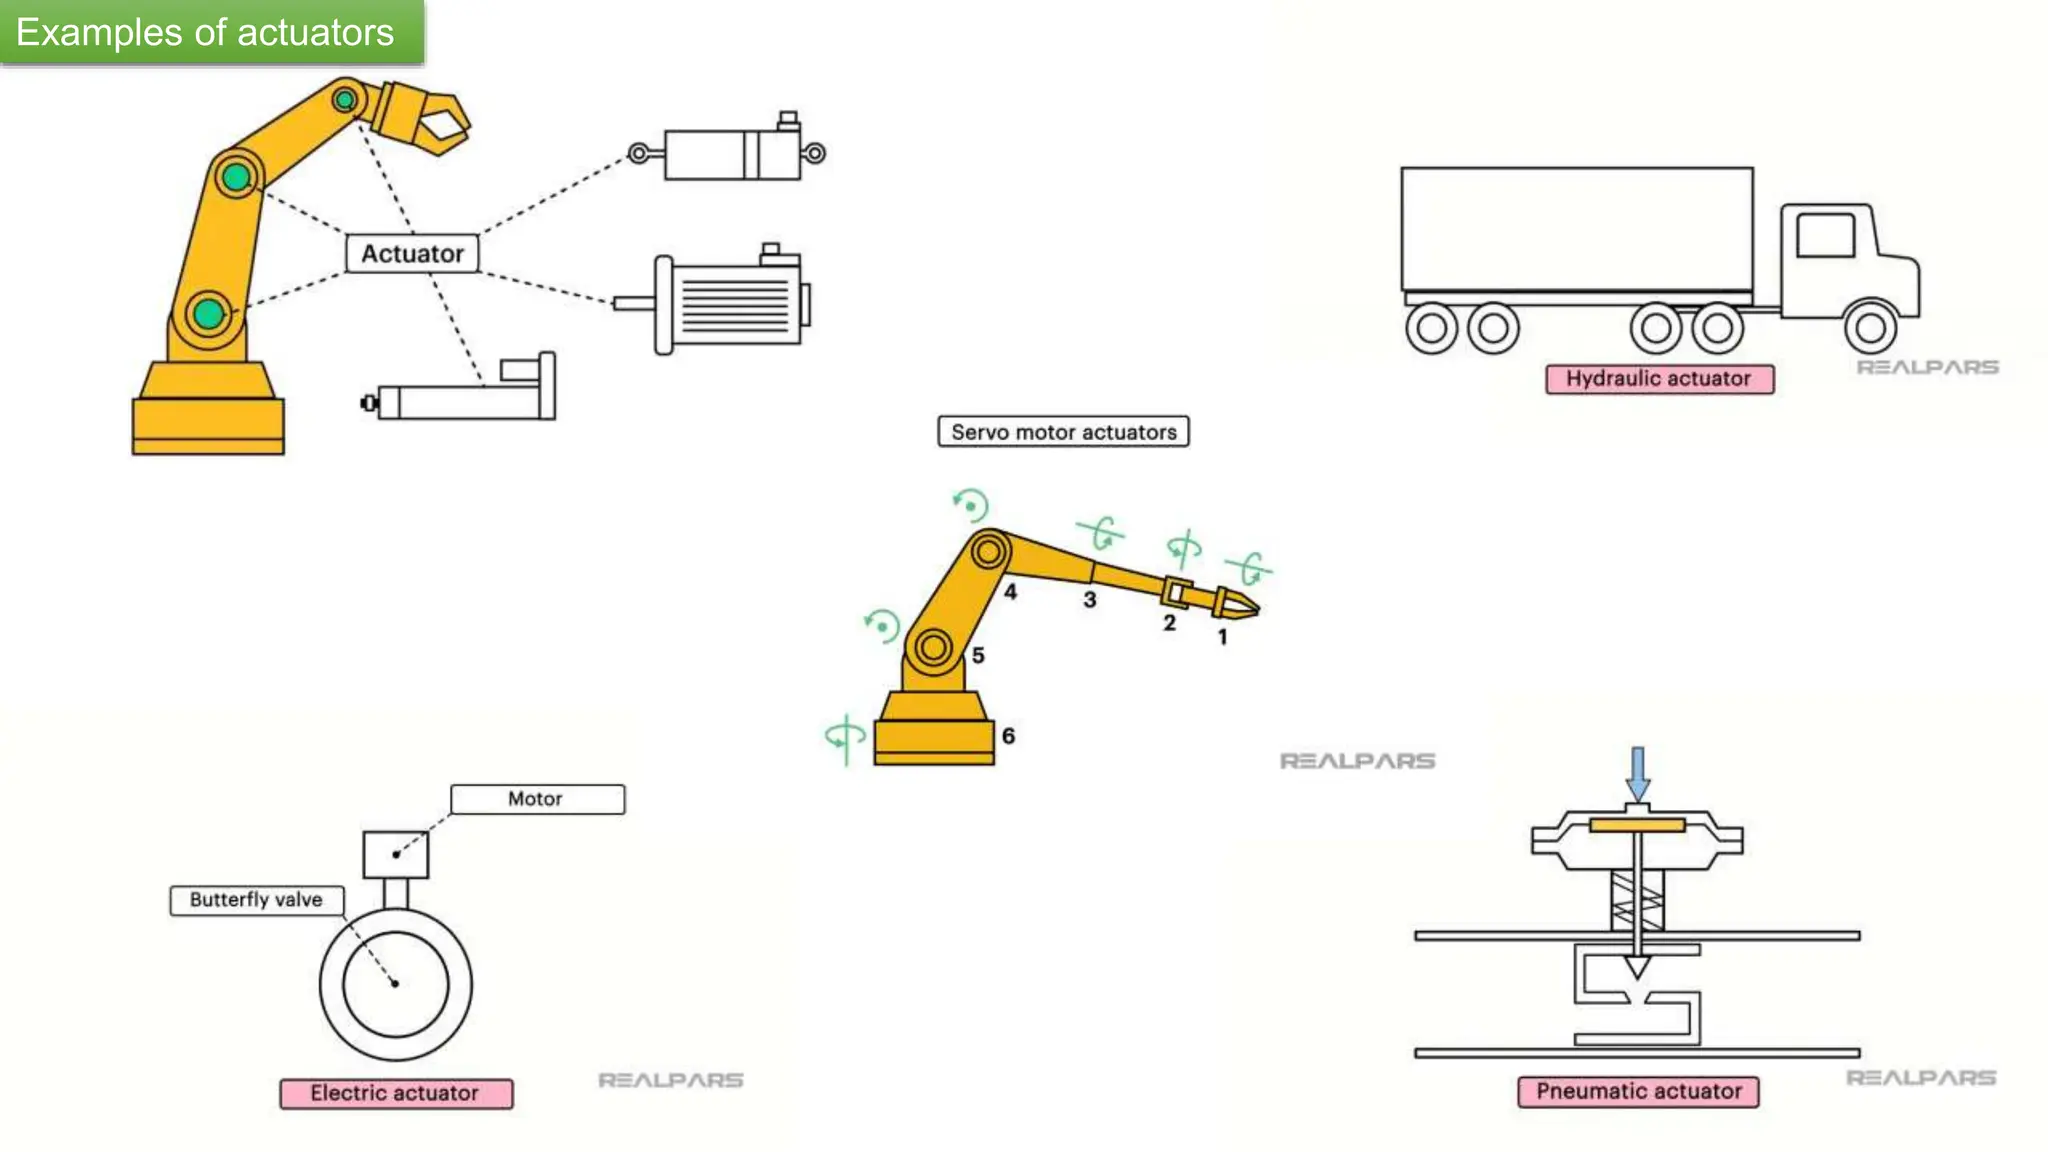
Robot Drives And End Effectors.pptx

URKinematics solver doesn't use set end effector as end effector link ...

ros2 - Adding a customized End-effector to an UR Robot - Robotics Stack ...