
Figure 1 From Minimum Energy Trajectory Planning For Biped Robots
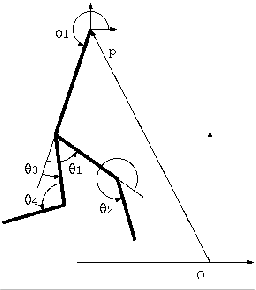
Figure 1 from Minimum Energy Trajectory Planning for Biped Robots ...
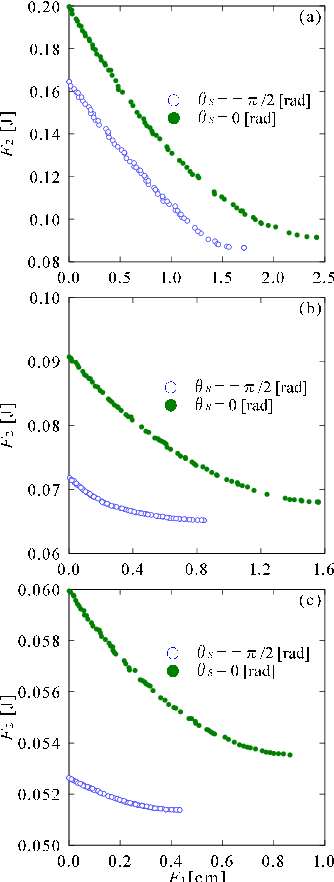
Figure 1 from Minimum energy trajectory planning method for robot ...
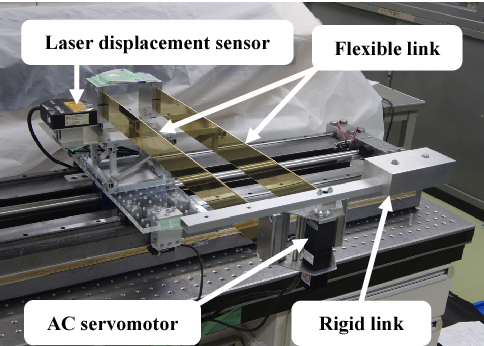
Figure 1 from Minimum energy trajectory planning method for robot ...
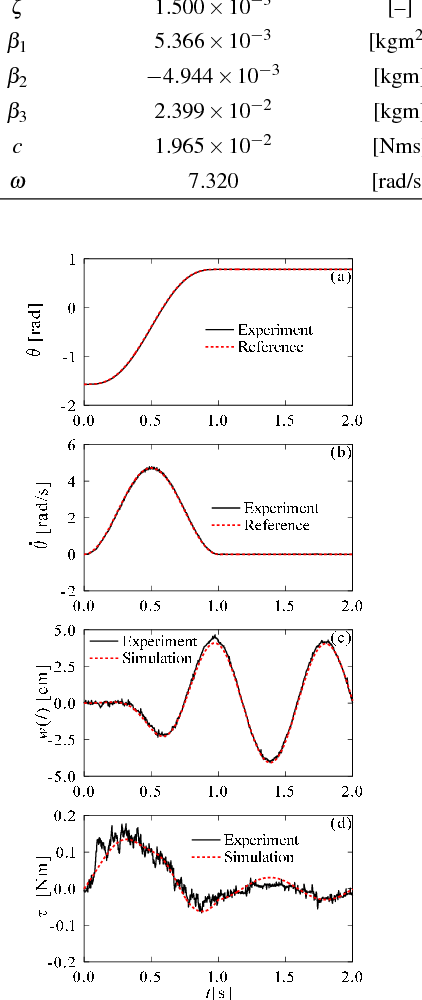
Figure 1 from Minimum energy trajectory planning method for robot ...
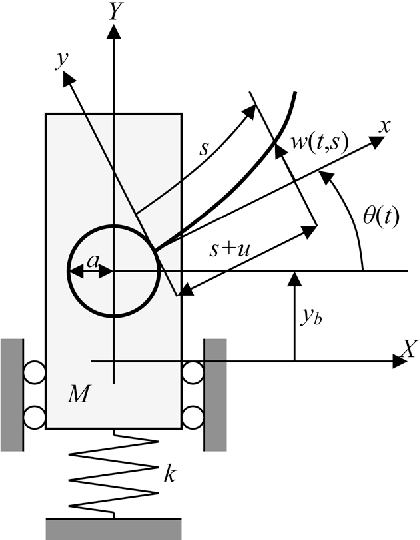
Figure 1 from G1000106 Minimum Energy Trajectory Planning Method for ...
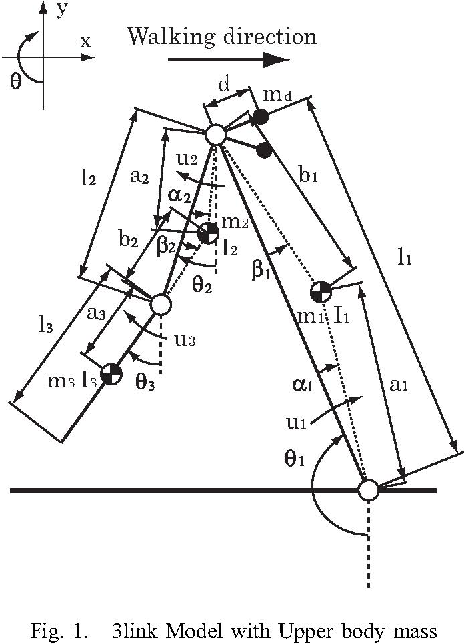
Figure 1 from Energy-Efficient Trajectory Planning for Biped Walking ...
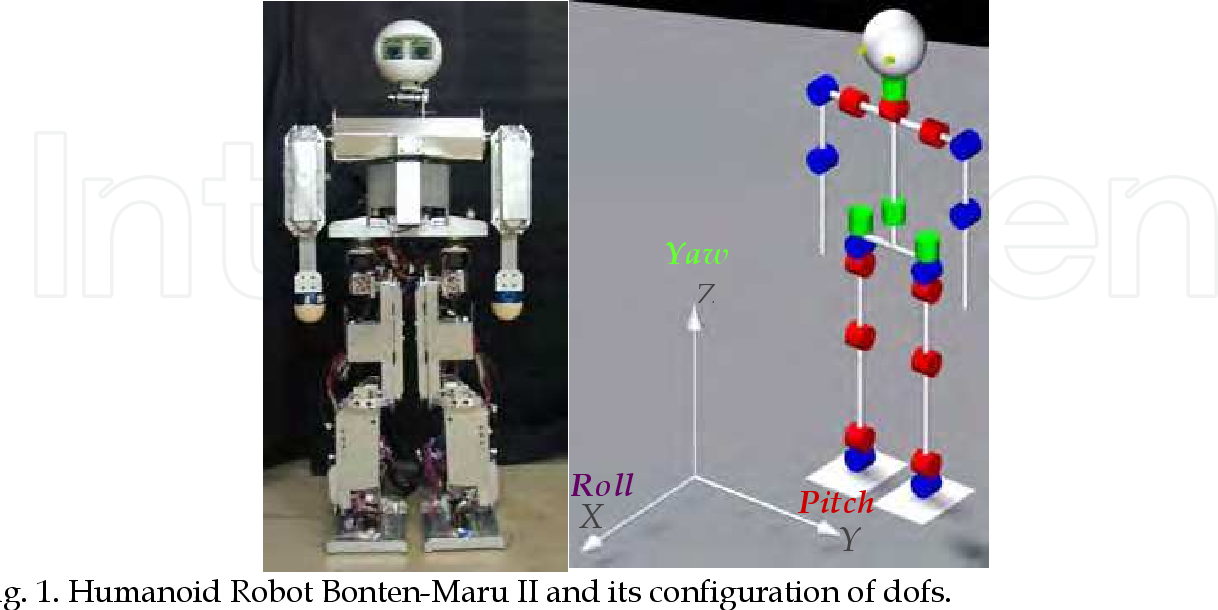
Figure 1 from Optimum Biped Trajectory Planning for Humanoid Robot ...
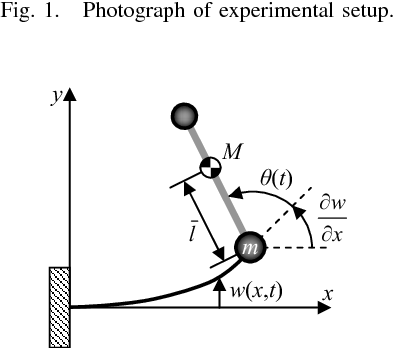
Figure 2 from Minimum energy trajectory planning method for robot ...

Figure 1 from Trajectory generation method for biped robots to climb up ...
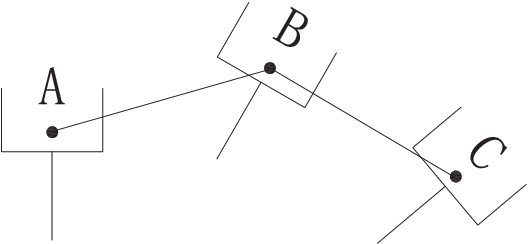
Figure 1 from Motion Trajectory Planning of Biped Robots | Semantic Scholar
Advertisement Space (300x250)

Figure 1 from Planning walking patterns for a biped robot | Semantic ...
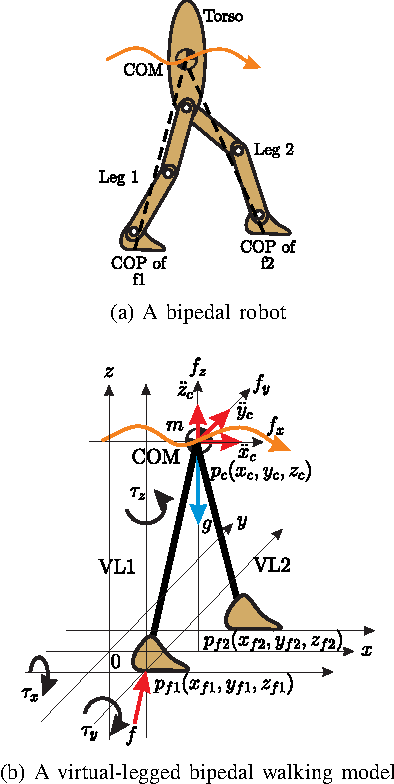
Figure 1 from Falling-based optimal foot trajectory planning for 3D ...
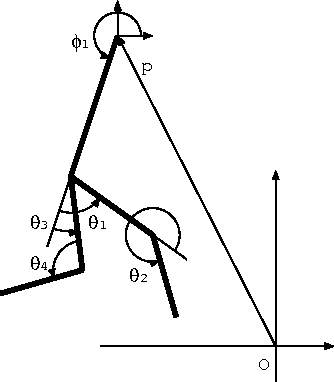
Figure 1 from Trajectory generation of biped running robot with minimum ...
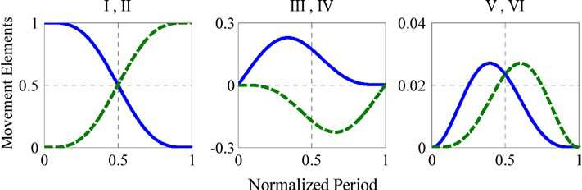
Figure 1 from An energy efficient gait trajectory planning algorithm ...

Figure 1 from ZMP Reference Trajectory Generation for Biped Robot with ...

Figure 1 from An energy efficient gait trajectory planning algorithm ...
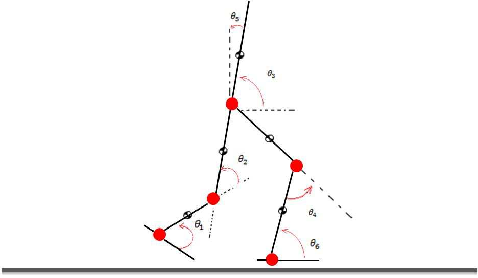
Figure 1 from An energy efficient gait trajectory planning algorithm ...

Figure 1 from Minimum-energy trajectory planning on a tangent for ...
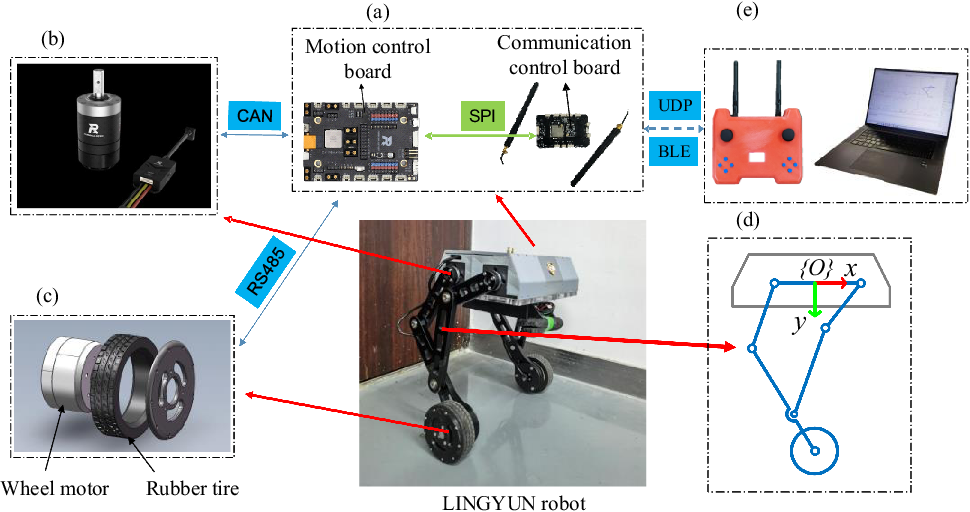
Figure 1 from Trajectory Planning for Jumping and Soft Landing With a ...
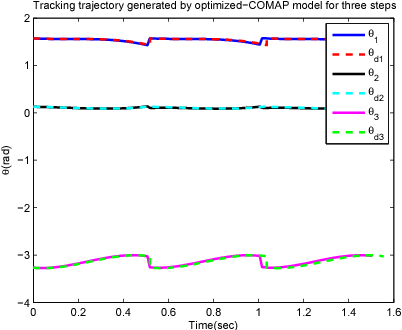
Figure 1 from An energy efficient gait trajectory planning algorithm ...
Advertisement Space (336x280)
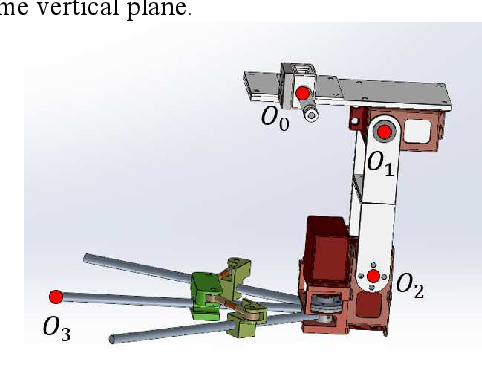
Figure 1 from Trajectory Planning for Bipedal Locomotion of a Duck ...
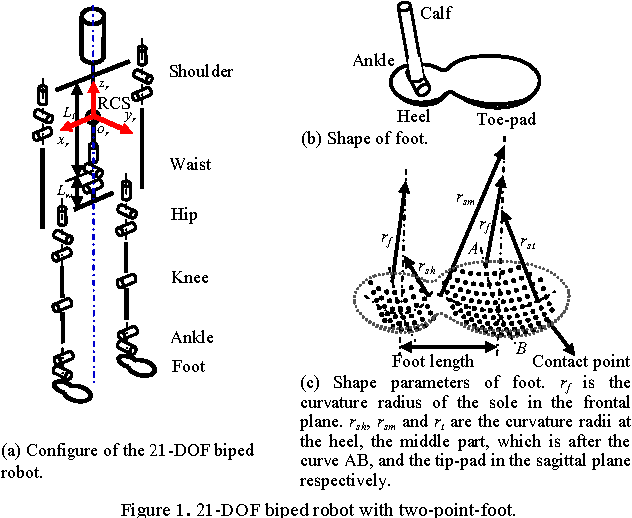
Figure 1 from Planning and control of biped robots with upper body ...

Figure 1 from Gait Planning for Biped Robot Based on Variable Center-of ...
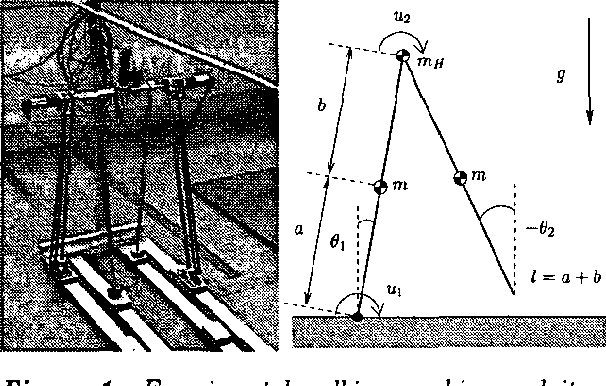
Figure 1 from A novel gait generation for biped walking robots based on ...

Figure 1 from Learning Energy-Efficient Trajectory Planning for Robotic ...

Figure 1 from Trajectory generation of biped robots using Linear ...
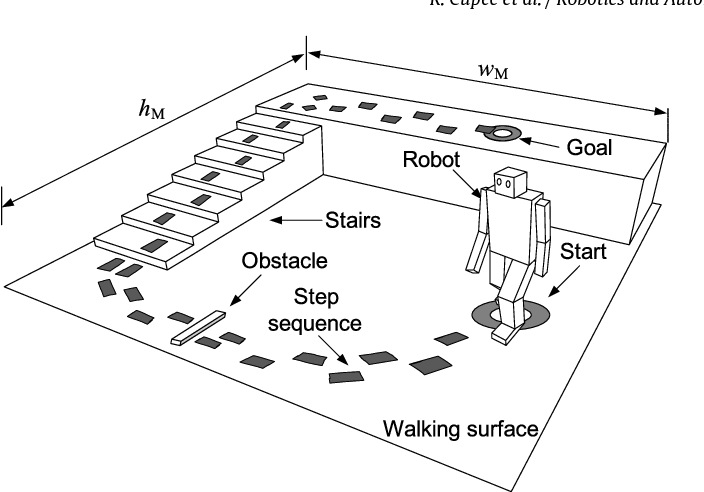
Figure 1 from Step sequence planning for a biped robot by means of a ...

Figure 1 from A modified gait planning method for biped robot based on ...

Figure 1 from Planning walking patterns of a biped robot with uDEAS ...
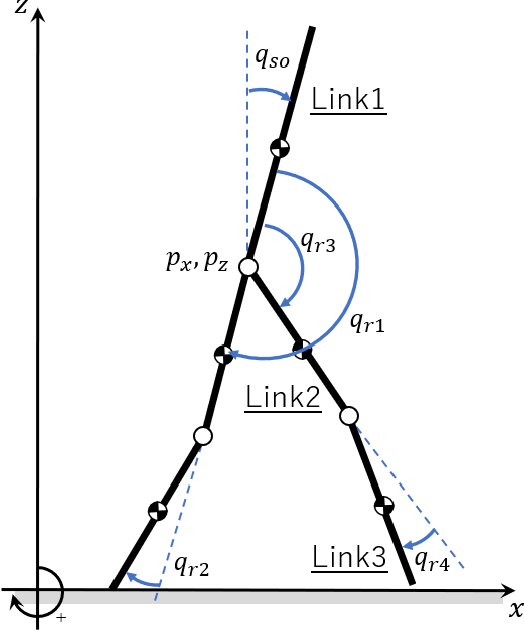
Figure 1 from Periodic Trajectory Planning and Robust Output Zeroing ...
Advertisement Space (336x280)
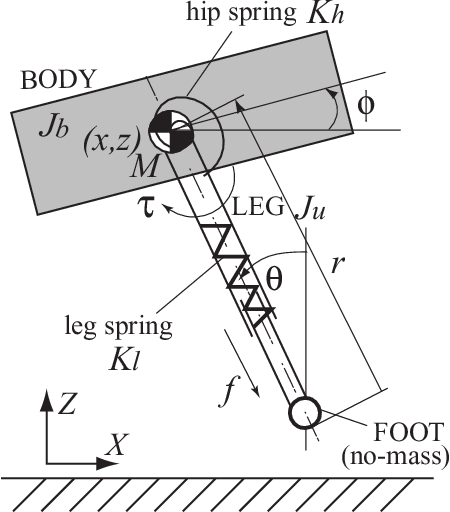
Figure 1 from Running control of a planar biped robot based on energy ...

Figure 1 from Dynamic Walking of Biped Robots with Obstacles Using ...
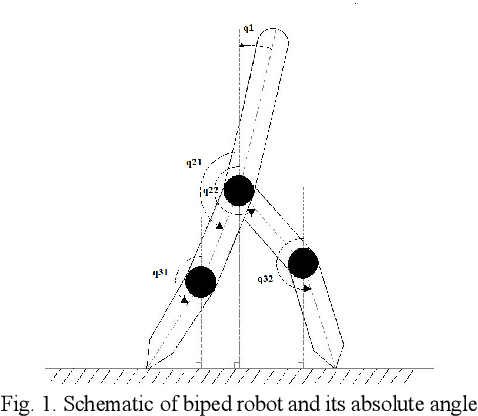
Figure 1 from Energy Consumption Analysis for the Limit Cycle Walking ...

Figure 1 from Natural ZMP Trajectories for Biped Robot Reference ...

Figure 1 from A ‘ ZMP ’ management scheme for trajectory control of ...

Trajectory Planning of Flexible Walking for Biped Robots Using Linear ...