
Figure 1 From Robust Compliant Motion For Manipulators Part Ii Design
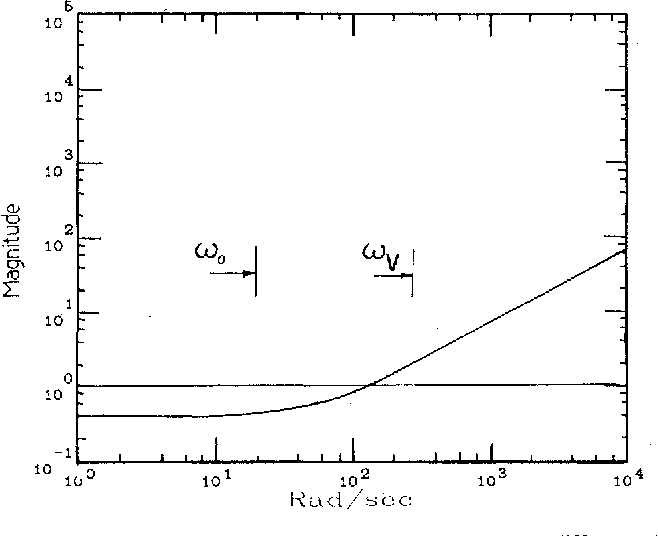
Figure 1 from Robust compliant motion for manipulators, part II: Design ...
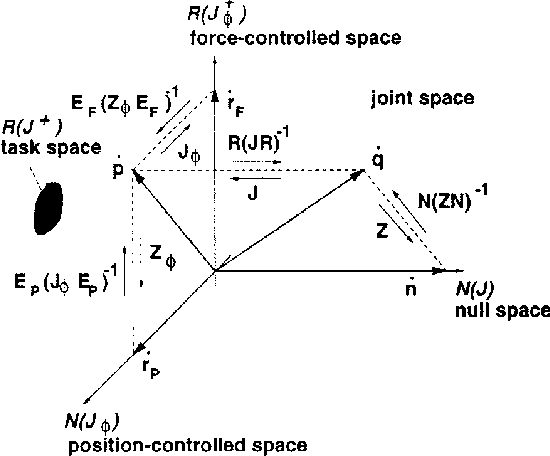
Figure 1 from Design of compliant motion controllers for kinematically ...

Figure 1 from Compliant Motion Control for Robot Manipulators (Input ...

(PDF) Robust Compliant Motion for Manipulators, Part II: Design Method

Figure 1 from A joint space formulation for compliant motion control of ...

Figure 1 from A structure design method for compliant parallel ...

Figure 1 from Robust Object Grasping using Force Compliant Motion ...

Figure 1 from A joint space formulation for compliant motion control of ...
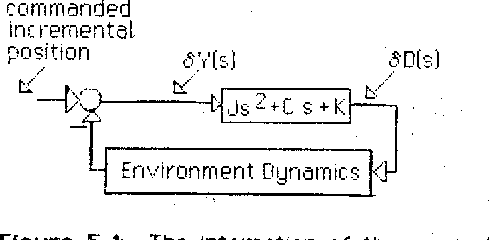
Figure 5-1 from The fundamental concepts of robust compliant motion for ...
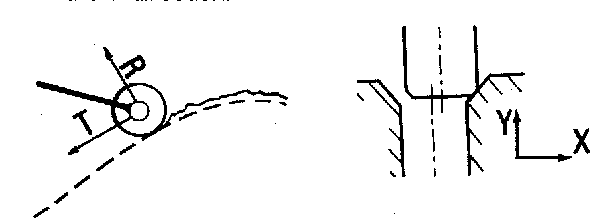
Figure 4-1 from The fundamental concepts of robust compliant motion for ...
Advertisement Space (300x250)

Figure 1 from HCDR-based motion planning for mobile manipulators with ...
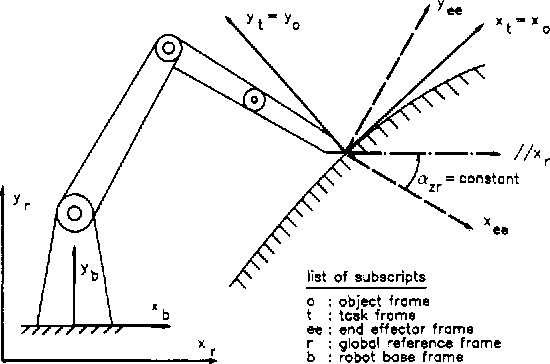
Figure 1 from A methodology for specifying and controlling compliant ...
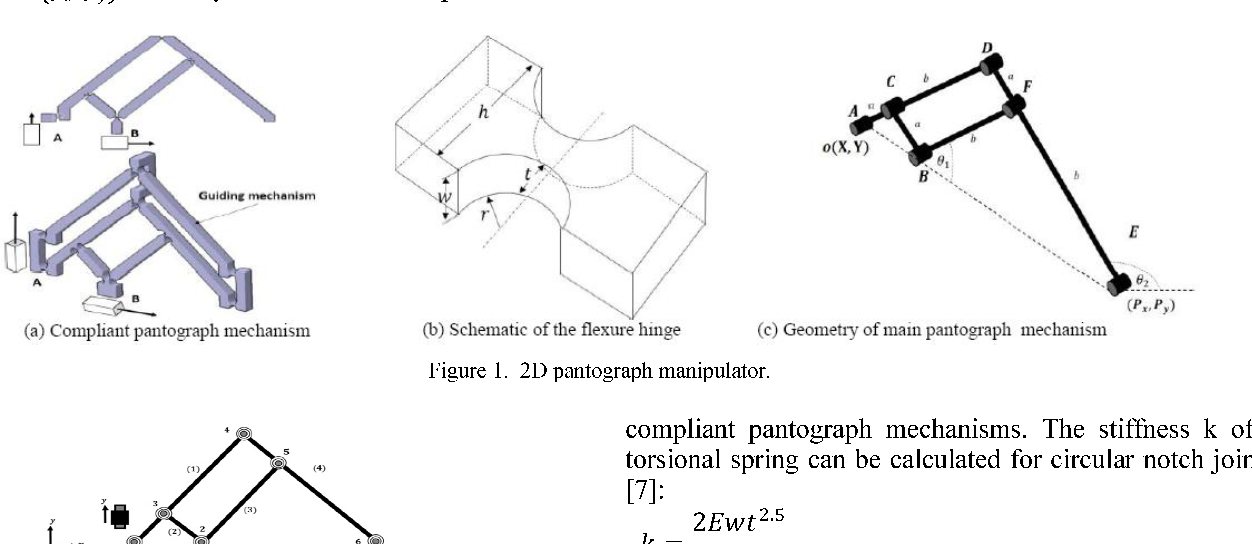
Figure 1 from Dynamic modeling and robust motion control of a 2D ...
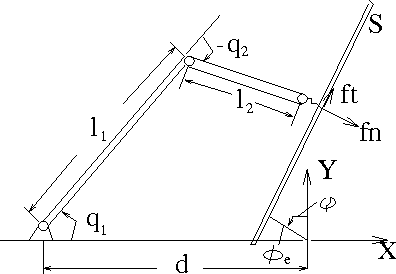
Figure 1 from Adaptive Robust Motion and Force Tracking Control of ...
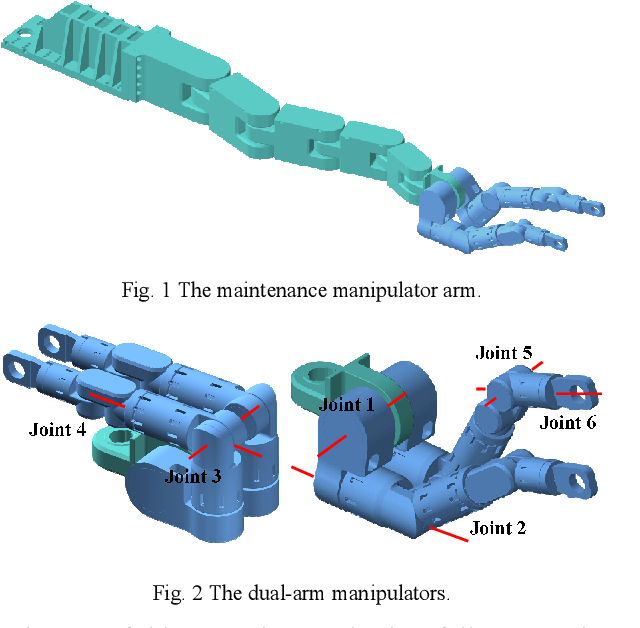
Figure 1 from Constraints Analysis and Motion Planning for Coordinated ...
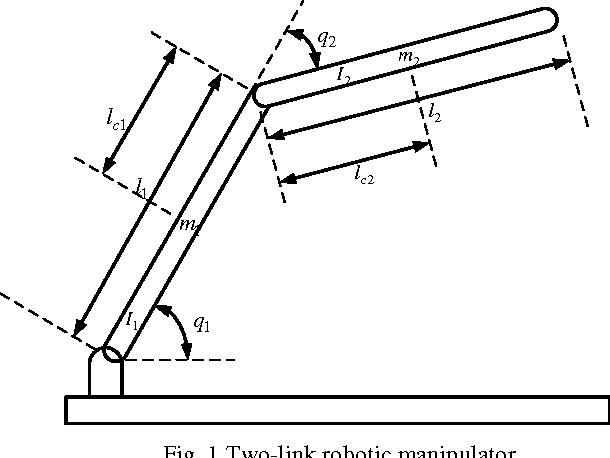
Figure 1 from Design of Adaptive Sliding Mode Controller for Robotic ...

Figure 1 from RRT-Based Path Planning for Follow-the-Leader Motion of ...
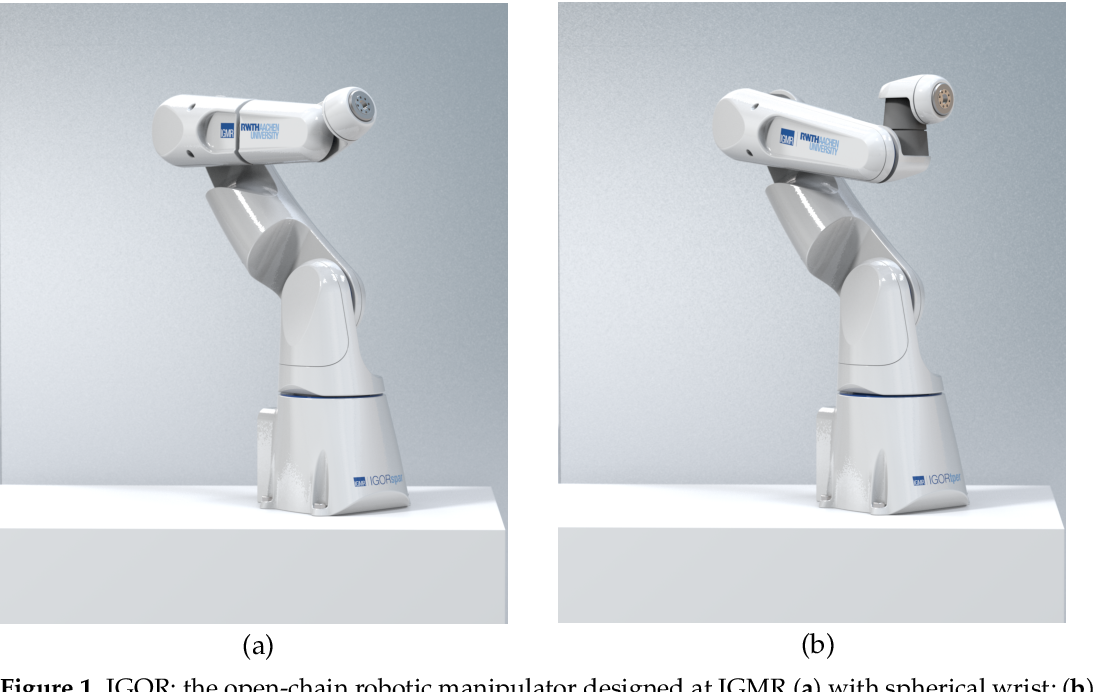
Figure 1 from Kinematic Graph for Motion Planning of Robotic ...
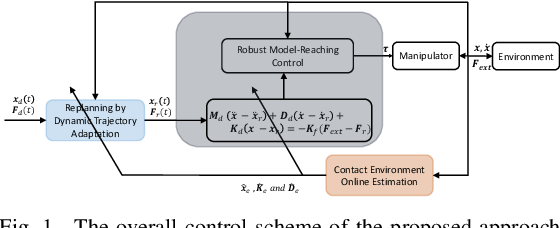
Figure 1 from Unified Motion/Force/Impedance Control for Manipulators ...
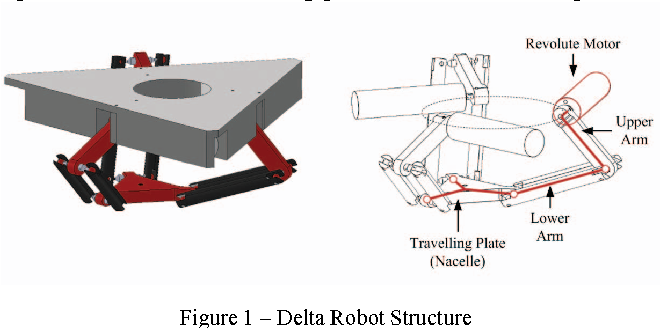
Figure 1 from Miniaturized modular manipulator design for high ...
Advertisement Space (336x280)
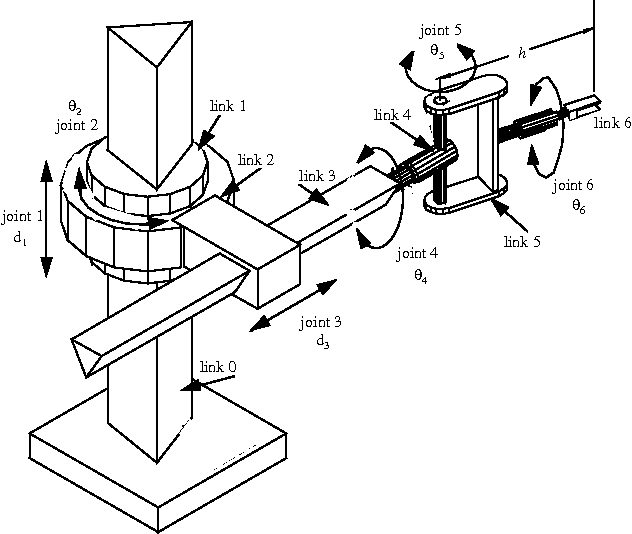
Figure 1 from Criteria for the design of manipulator arms for a high ...
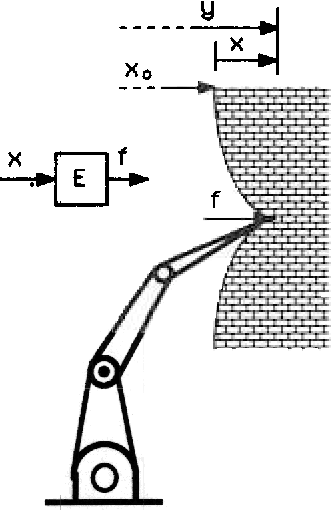
Figure 2 from ICompliant motion control for robot manipulators ...

Figure 2 from Robust Motion Control for Fully Actuated Robots Using ...
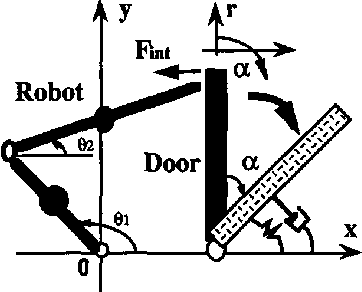
Figure 2 from Control design of robot for compliant manipulation on ...
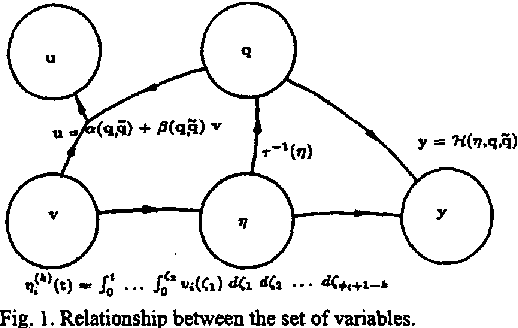
Figure 1 from Trajectories generation for robot manipulators under ...
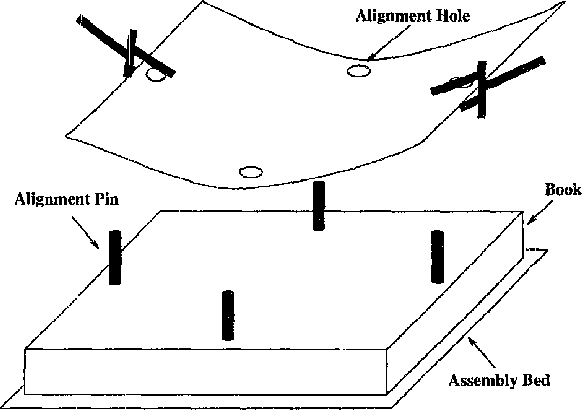
Figure 1 from Trajectory planning for two manipulators to deform ...
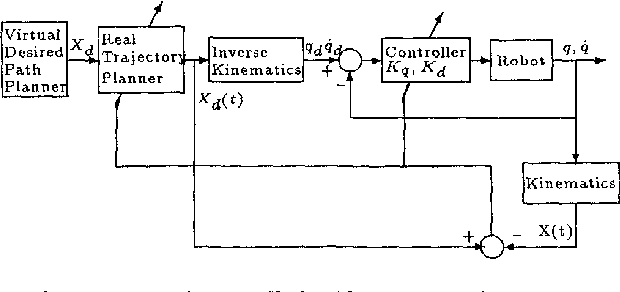
Figure 1 from A compliance control strategy for robot manipulators ...

Figure 2 from HCDR-based motion planning for mobile manipulators with ...

Figure 1 from On generating the motion of industrial robot manipulators ...

Figure 1 from Whole-Body Integrated Motion Planning for Aerial ...
Advertisement Space (336x280)

Figure 1 from Adaptive robust precision motion control of a flexible ...
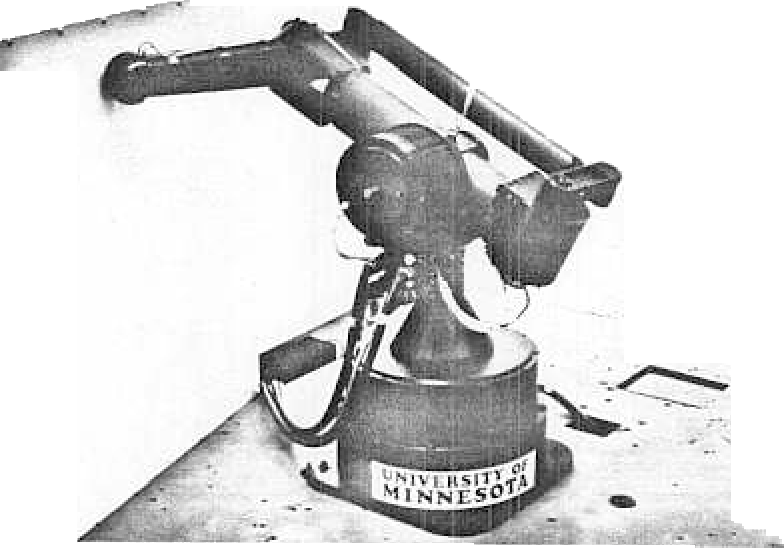
Figure 1 from COMPLIANT MOTION CONTROL OF A ST A TIC ALL Y BALANCED ...
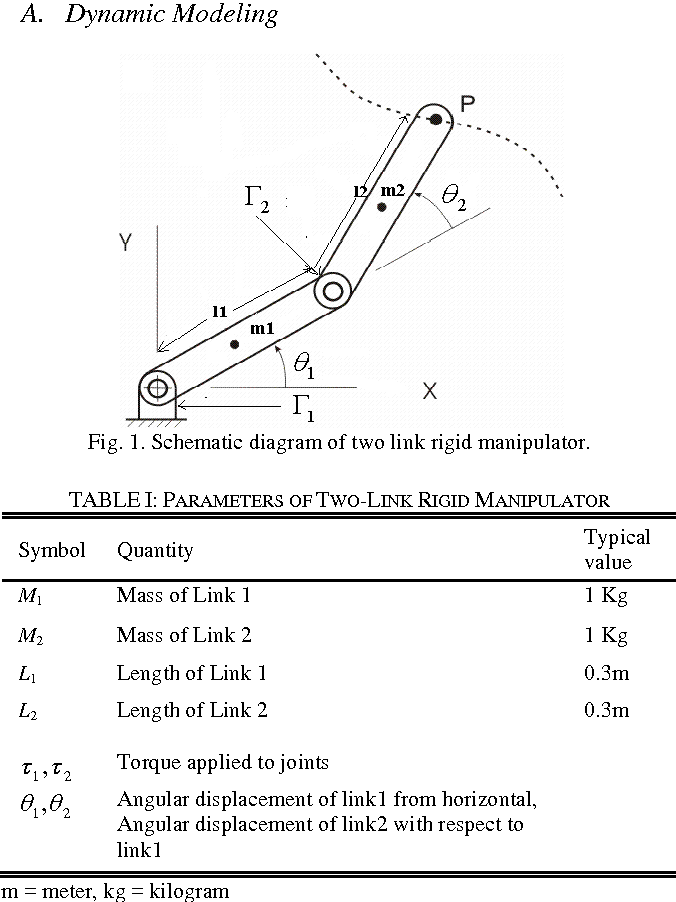
Figure 1 from Robust Control of Two Link Rigid Manipulator | Semantic ...

Figure 1 from Adaptive compliant force-motion control of coordinated ...
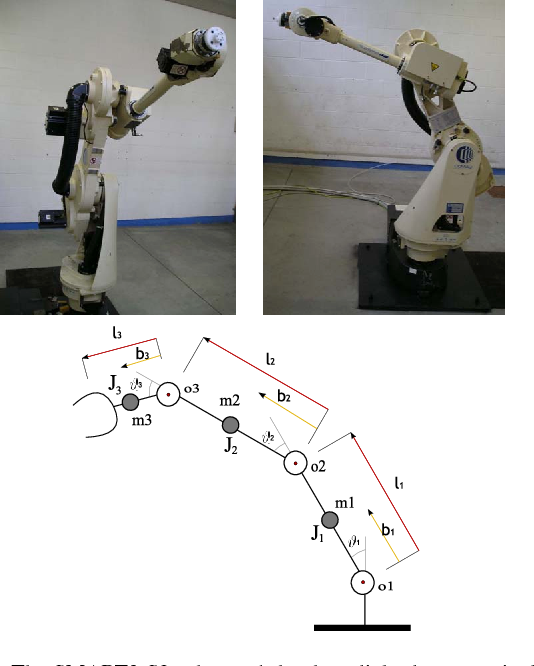
Figure 1 from Second order sliding mode motion control of rigid robot ...

Figure 1 from Robust Anthropomorphic Robotic Manipulation through ...