
Figure 2 From An Extended Virtual Proxy Haptic Algorithm For Dexterous

Figure 2 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 1 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 3 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 13 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 6 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 2 from Continuous Collision Detection for Virtual Proxy Haptic ...
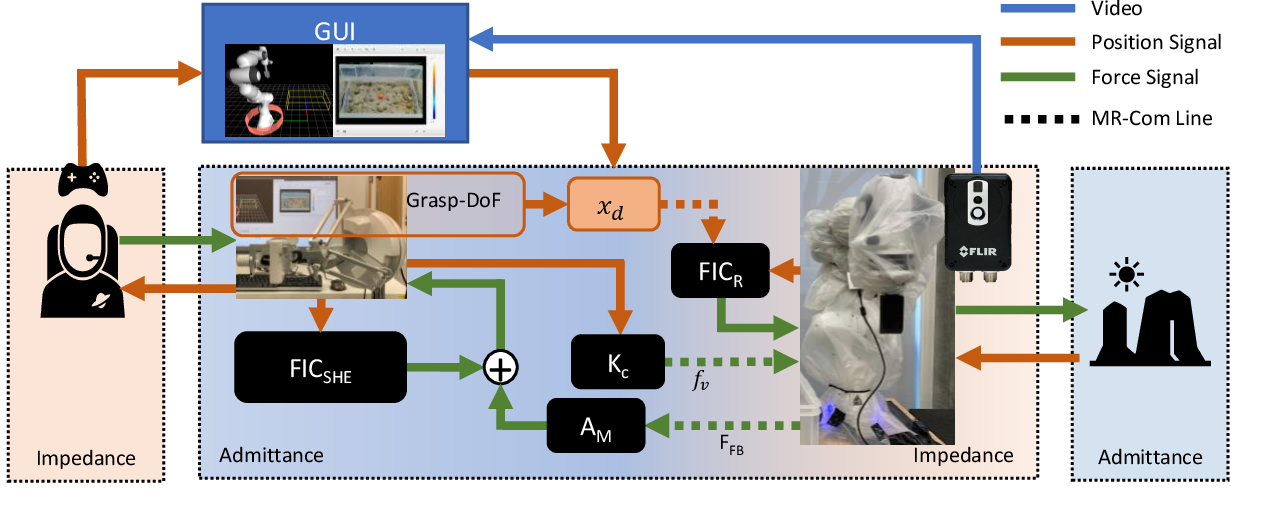
Figure 2 from Robust High-Transparency Haptic Exploration for Dexterous ...
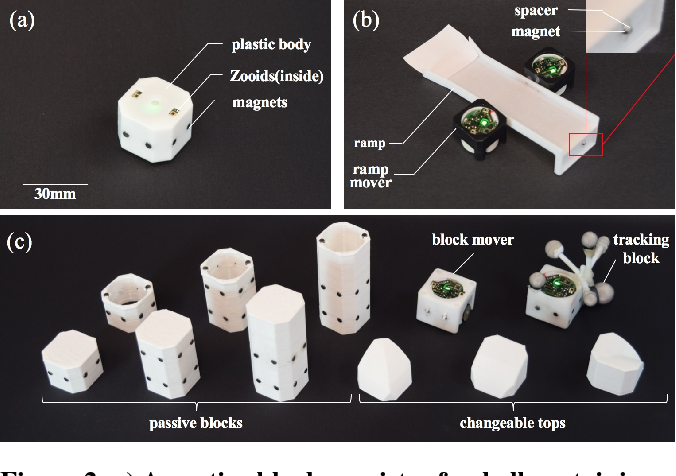
Figure 2 from Robotic Assembly of Haptic Proxy Objects for Tangible ...

Figure 2 from A novel haptic interface and control algorithm for ...

Figure 1 from Remote Operation with Haptic Force and Virtual Proxy for ...
Advertisement Space (300x250)

Figure 1 from Continuous Collision Detection for Virtual Proxy Haptic ...

Figure 2 from Development of a multi-modal haptic feedback system for ...

Figure 2 from A Framework for Developing Haptics Based Virtual ...
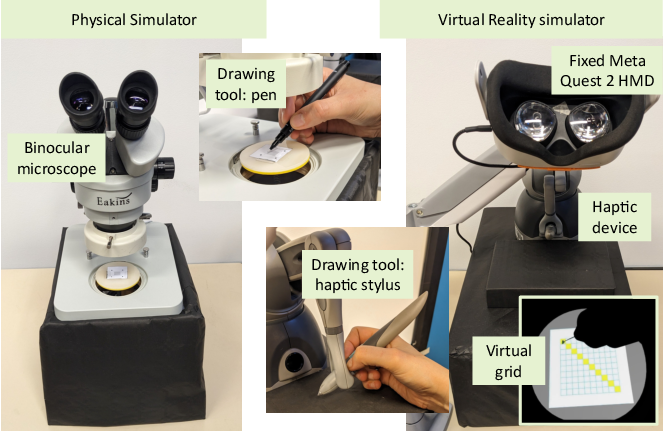
Figure 2 from The Effect of Haptic Feedback in an Immersive ...

Figure 1 from An Adaptive Grasping Strategy for Dexterous Hands Based ...
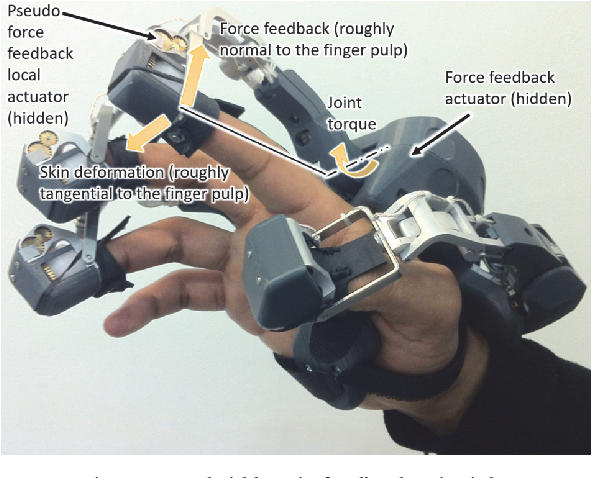
Figure 2 from Design and Integration of a Dexterous Interface with ...
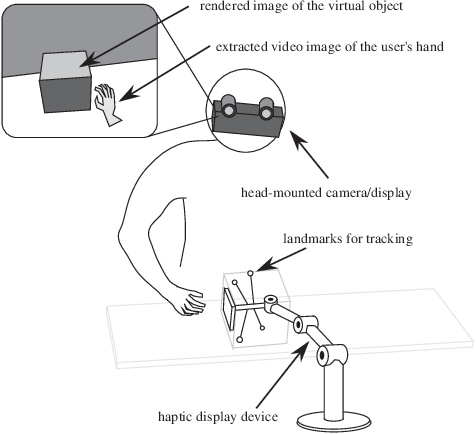
Figure 2 from A visual/haptic interface to virtual environment (WYSIWYF ...
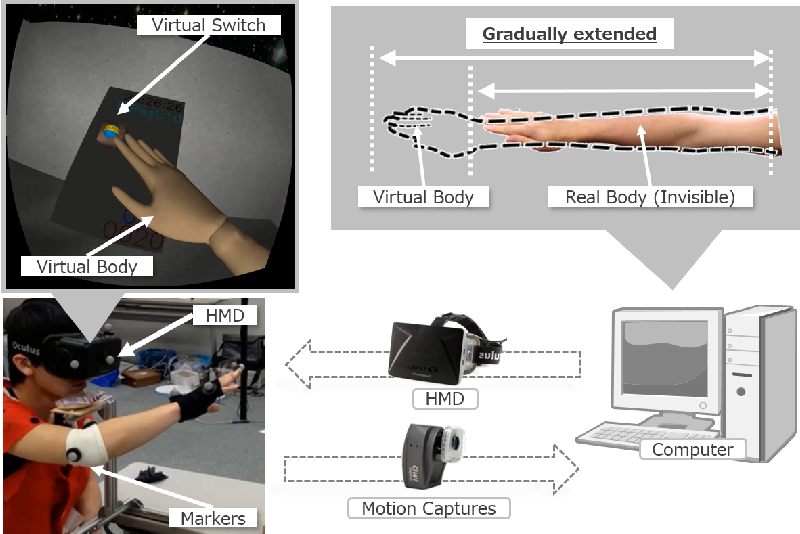
Figure 2 from The effect of haptic feedback on body scheme calibration ...

Figure 2 from Haptic-go-round: A Surrounding Platform for Encounter ...

Figure 1 from Exodex Adam—A Reconfigurable Dexterous Haptic User ...
Advertisement Space (336x280)
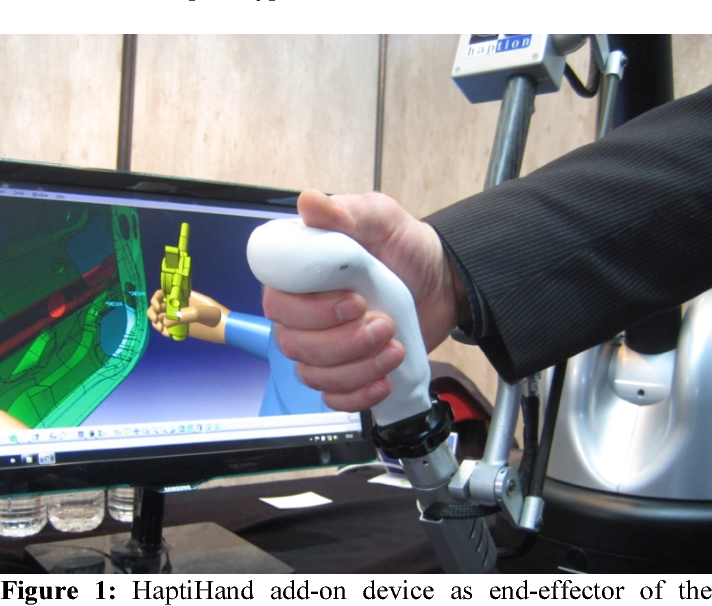
Figure 1 from An Add-On Device to Perform Dexterous Grasping Tasks With ...

Tangible Twins: A Haptic Proxy and Digital Twin Framework for Virtual ...
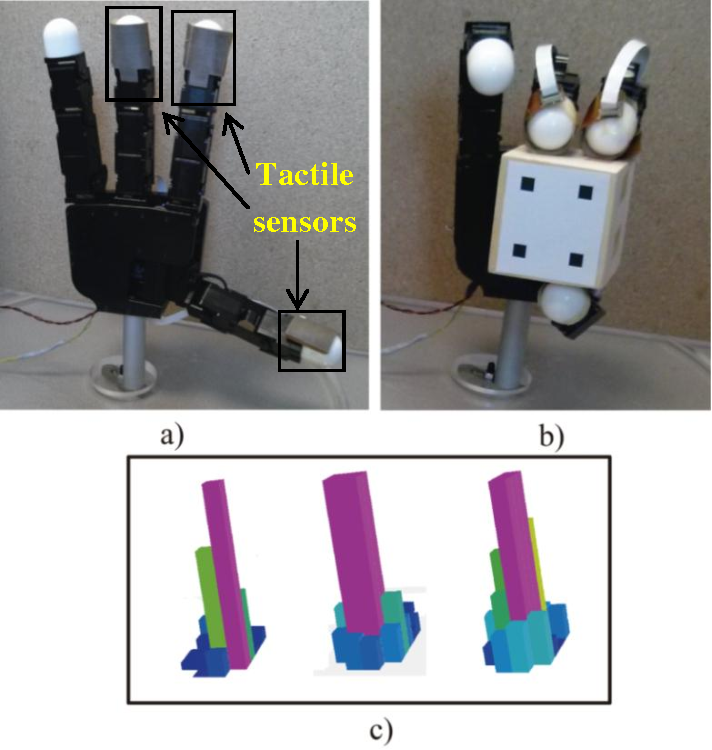
Figure 1 from Control Framework for Dexterous Manipulation Using ...

Figure 2 from The "Bubble" technique: interacting with large virtual ...

DexHand: dexterous hand manipulation motion synthesis for virtual ...
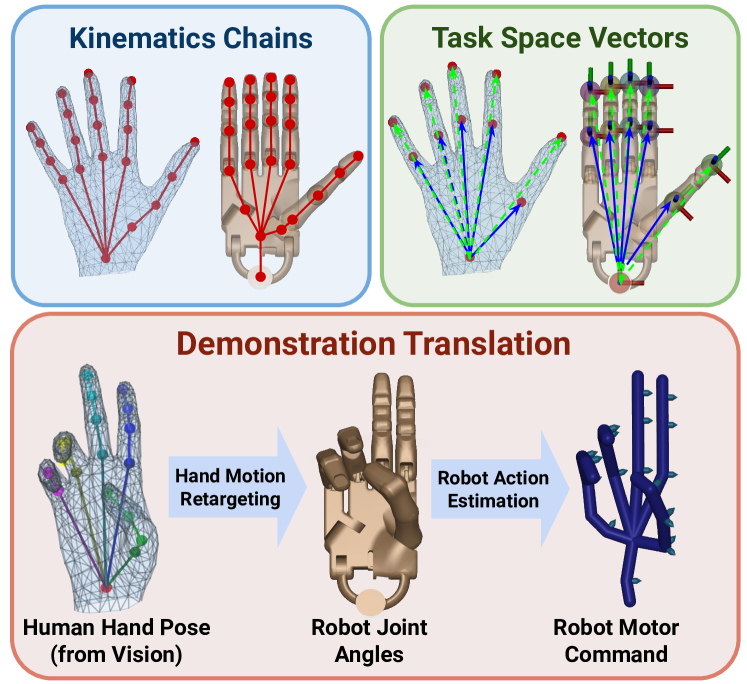
[2108.05877] DexMV: Imitation Learning for Dexterous Manipulation from ...

Figure 1 from Bi-directional Momentum-based Haptic Feedback and Control ...
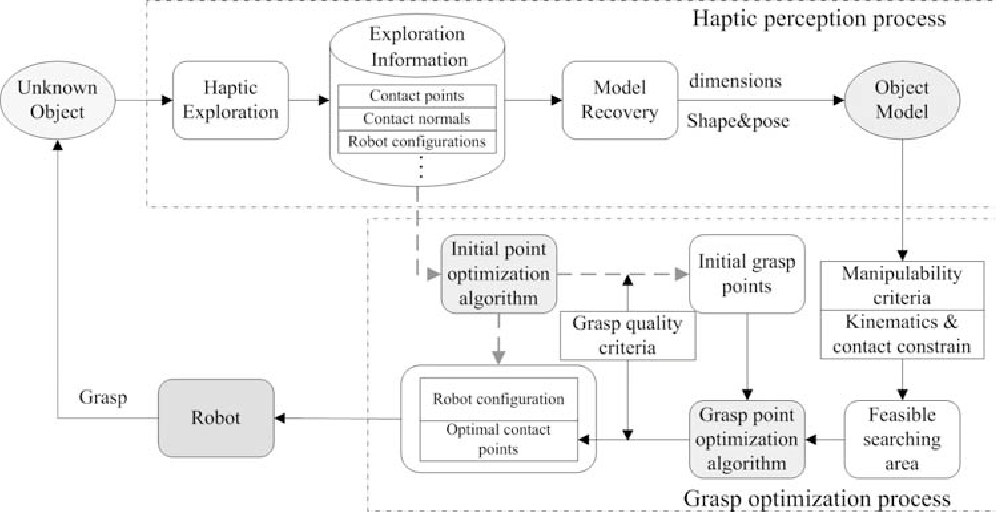
Figure 1 from Grasp Configurations Optimization of Dexterous Robotic ...

Figure 1 from Design and Development of a Dexterous Bilateral Robotic ...

Figure 1 from Design and Development of a Dexterous Bilateral Robotic ...
Advertisement Space (336x280)

Figure 5 from Design and Integration of a Dexterous Interface with ...
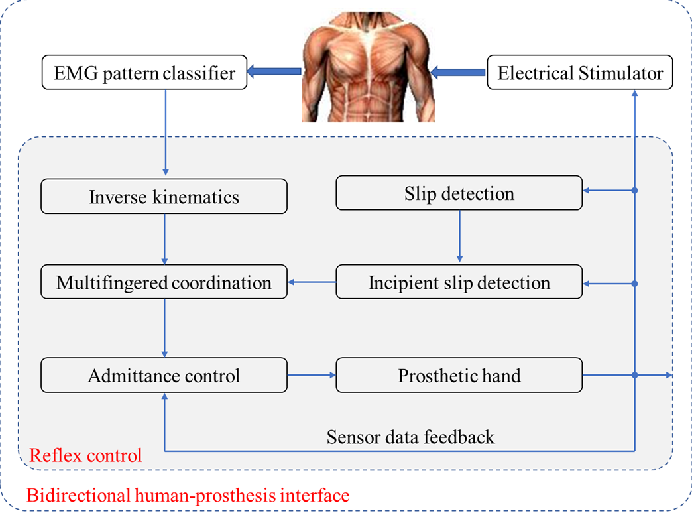
Figure 2 from Design and Experimental Evaluation of a Sensorimotor ...

Hand-as-a-prop: using the hand as a haptic proxy for manipulation in ...

DexHand: dexterous hand manipulation motion synthesis for virtual ...
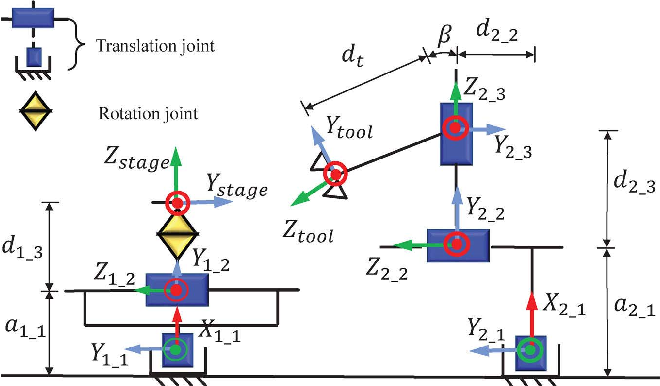
Figure 5 from Design and Development of a Dexterous Bilateral Robotic ...

Figure 8 from Design and Development of a Dexterous Bilateral Robotic ...