
Figure 3 From An Extended Virtual Proxy Haptic Algorithm For Dexterous

Figure 3 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 1 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 2 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 6 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 13 from An Extended Virtual Proxy Haptic Algorithm for Dexterous ...

Figure 1 from Remote Operation with Haptic Force and Virtual Proxy for ...

Figure 1 from Continuous Collision Detection for Virtual Proxy Haptic ...
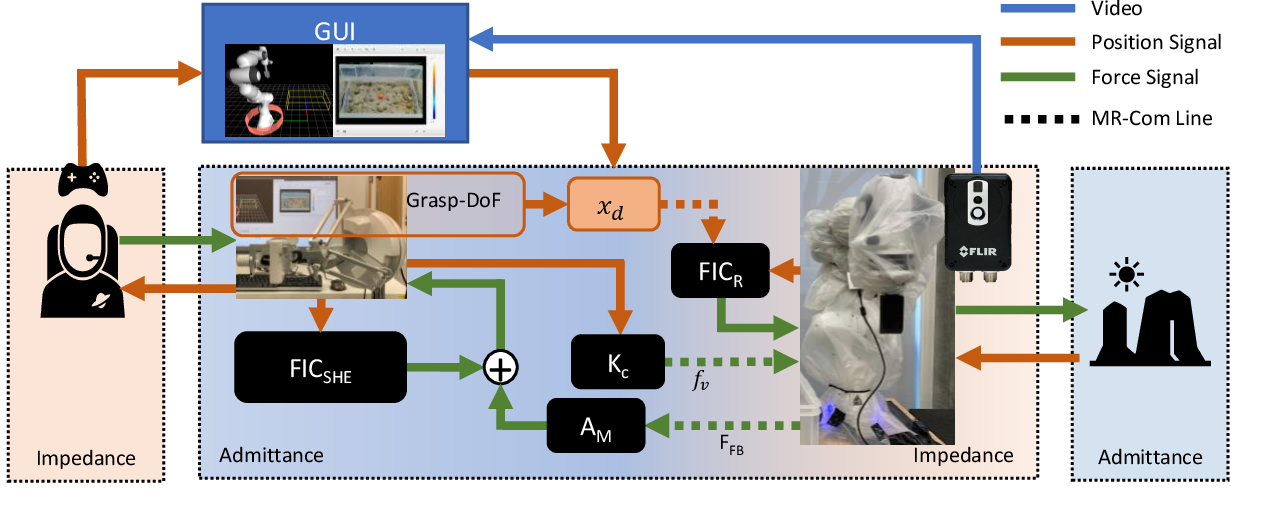
Figure 2 from Robust High-Transparency Haptic Exploration for Dexterous ...

Figure 3 from Comparison of Algorithms for Haptic Interaction With ...

Figure 1 from An Adaptive Grasping Strategy for Dexterous Hands Based ...
Advertisement Space (300x250)

Figure 1 from A Virtual Hand Based Manipulation Learning Framework for ...

Figure 3 from Design and Development of a Dexterous Bilateral Robotic ...

Figure 1 from Exodex Adam—A Reconfigurable Dexterous Haptic User ...
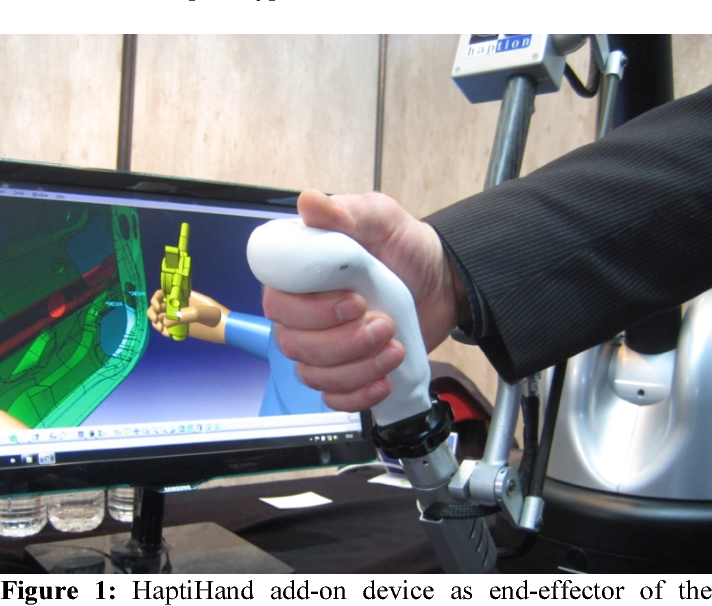
Figure 1 from An Add-On Device to Perform Dexterous Grasping Tasks With ...

Figure 3 from Design of a fully modular and backdrivable dexterous hand ...
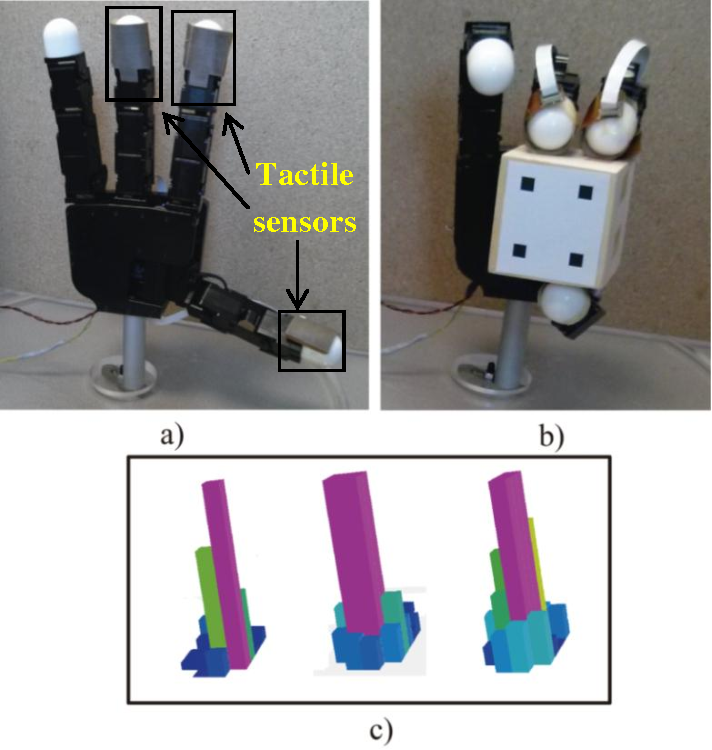
Figure 1 from Control Framework for Dexterous Manipulation Using ...
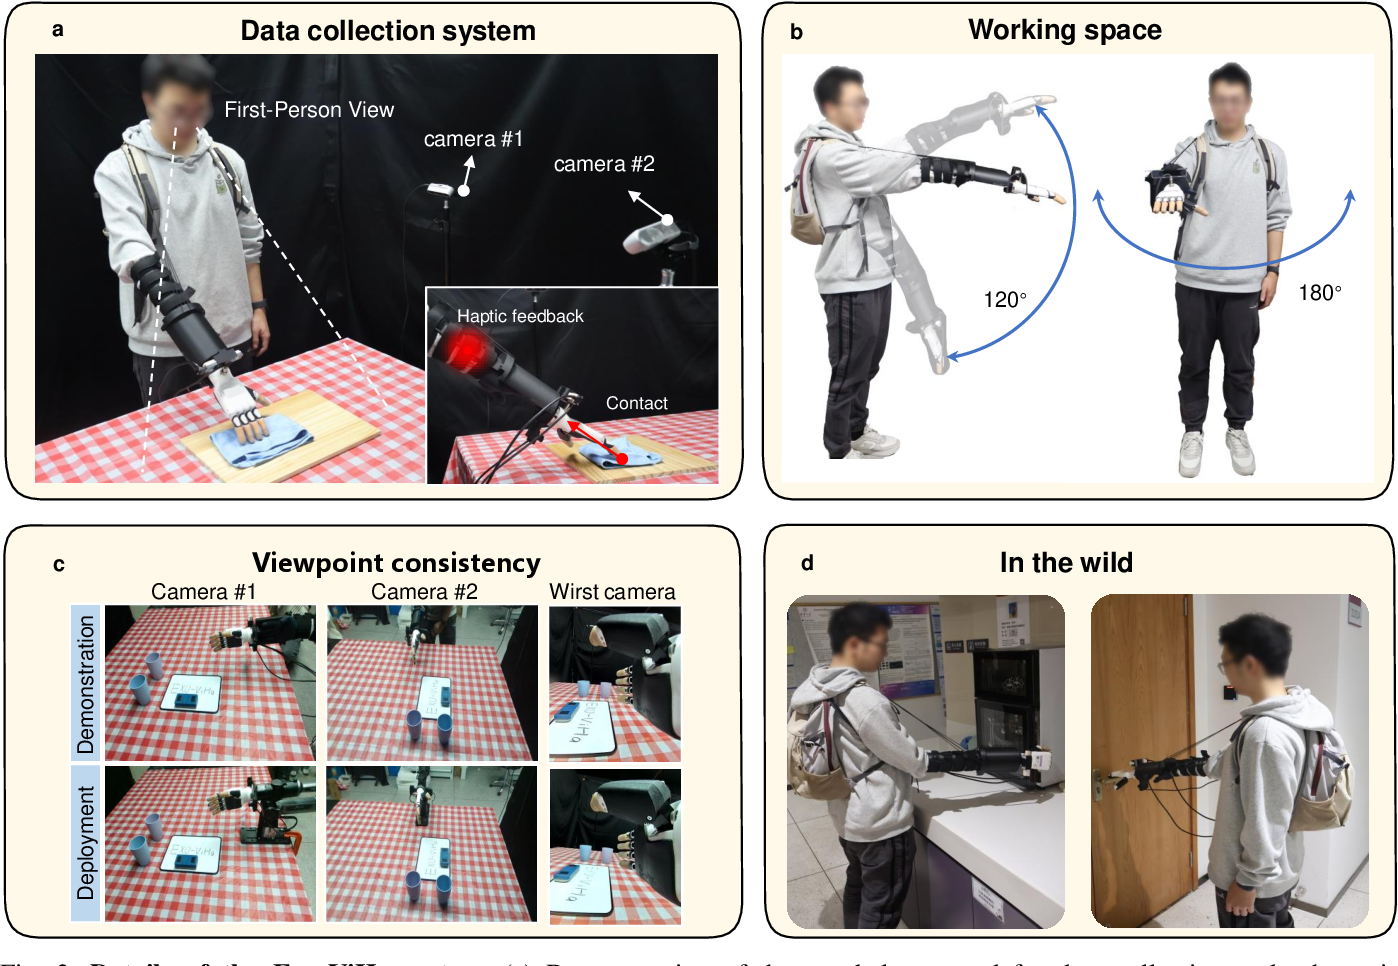
Figure 3 from Exo-ViHa: A Cross-Platform Exoskeleton System with Visual ...
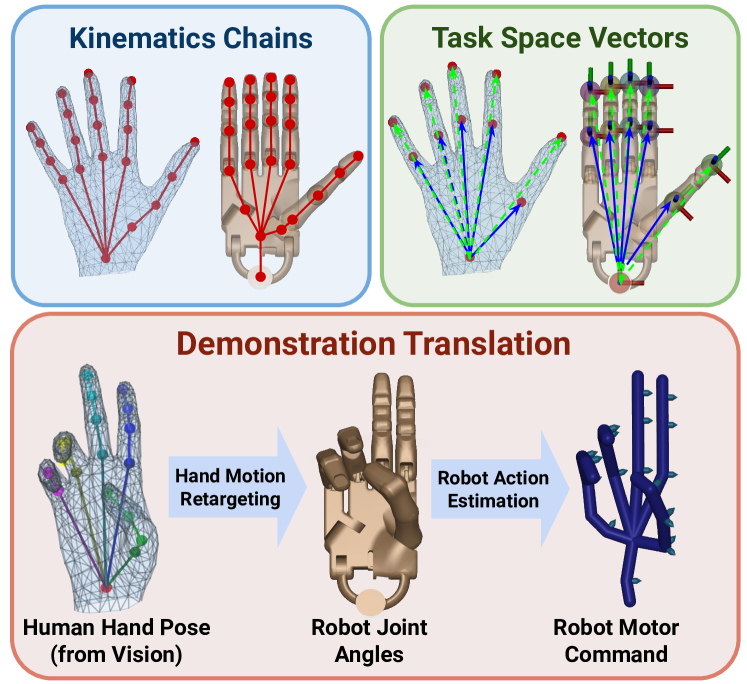
[2108.05877] DexMV: Imitation Learning for Dexterous Manipulation from ...

Figure 1 from Development of a Virtual Object Weight Recognition ...

Figure 1 from Bi-directional Momentum-based Haptic Feedback and Control ...
Advertisement Space (336x280)

DexHand: dexterous hand manipulation motion synthesis for virtual ...

Figure 2 from DextrAH-G: Pixels-to-Action Dexterous Arm-Hand Grasping ...
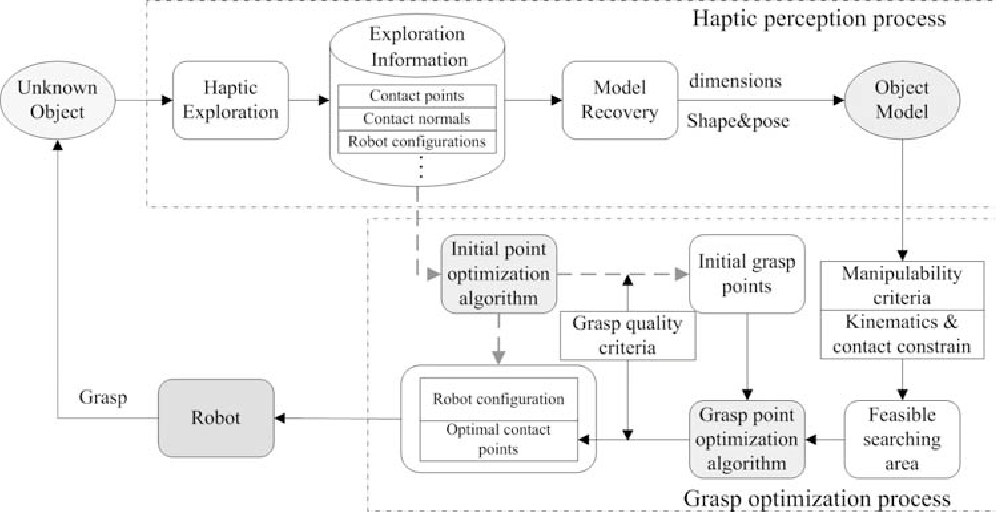
Figure 1 from Grasp Configurations Optimization of Dexterous Robotic ...

Figure 1 from Design and Development of a Dexterous Bilateral Robotic ...

Figure 1 from Design and Development of a Dexterous Bilateral Robotic ...
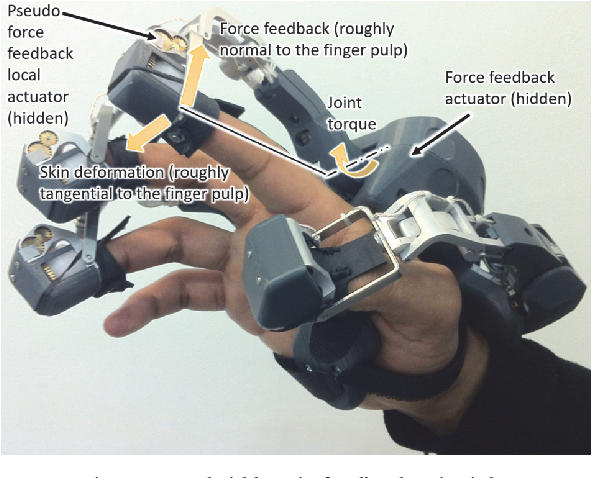
Figure 2 from Design and Integration of a Dexterous Interface with ...

Figure 5 from Design and Integration of a Dexterous Interface with ...

Hand-as-a-prop: using the hand as a haptic proxy for manipulation in ...

DexHand: dexterous hand manipulation motion synthesis for virtual ...
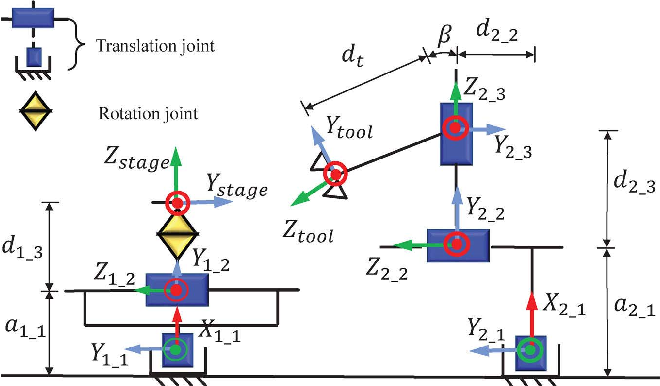
Figure 5 from Design and Development of a Dexterous Bilateral Robotic ...
Advertisement Space (336x280)

Figure 8 from Design and Development of a Dexterous Bilateral Robotic ...

Figure 5 from Multi-fingered exoskeleton haptic device using passive ...

Figure 7 from Design and Development of a Dexterous Bilateral Robotic ...
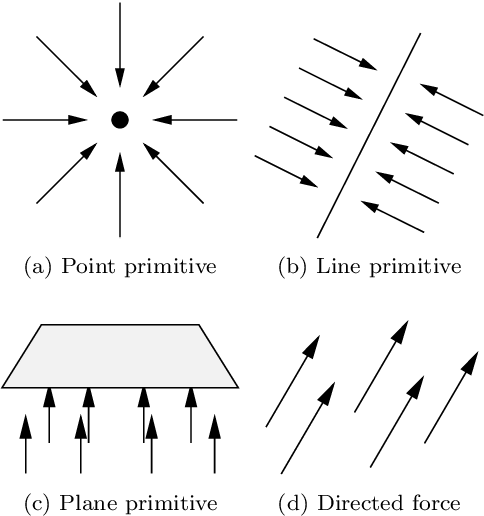
Figure 3 from The Orthogonal Constraints Problem with the Constraint ...

Figure 4 from Design and Development of a Dexterous Bilateral Robotic ...

Proxy-based haptic volume rendering. The proxy is moved from p q−1 to p ...