
Movebaseflextutorialsbehaviourtreesformovebaseflex Ros Wiki
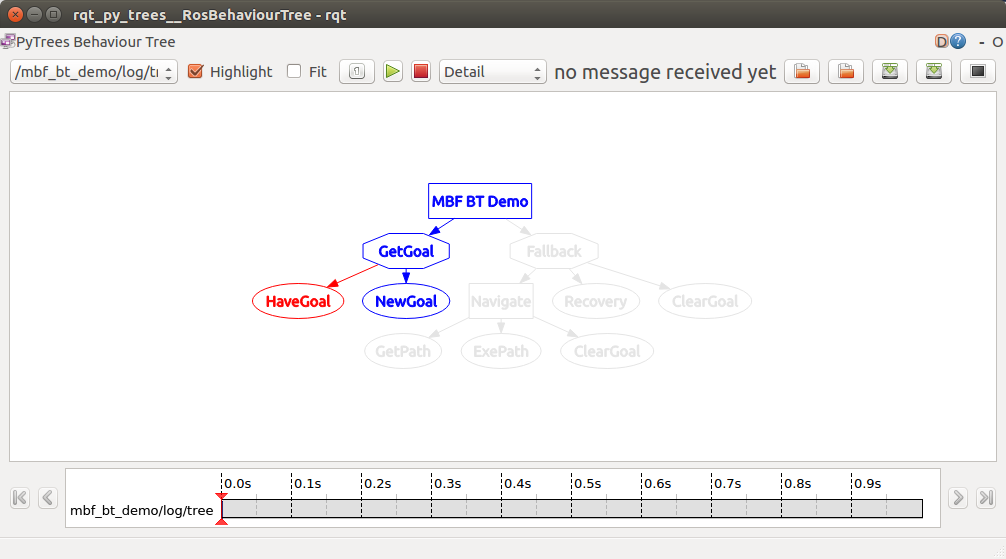
move_base_flex/Tutorials/BehaviourTreesForMoveBaseFlex - ROS Wiki
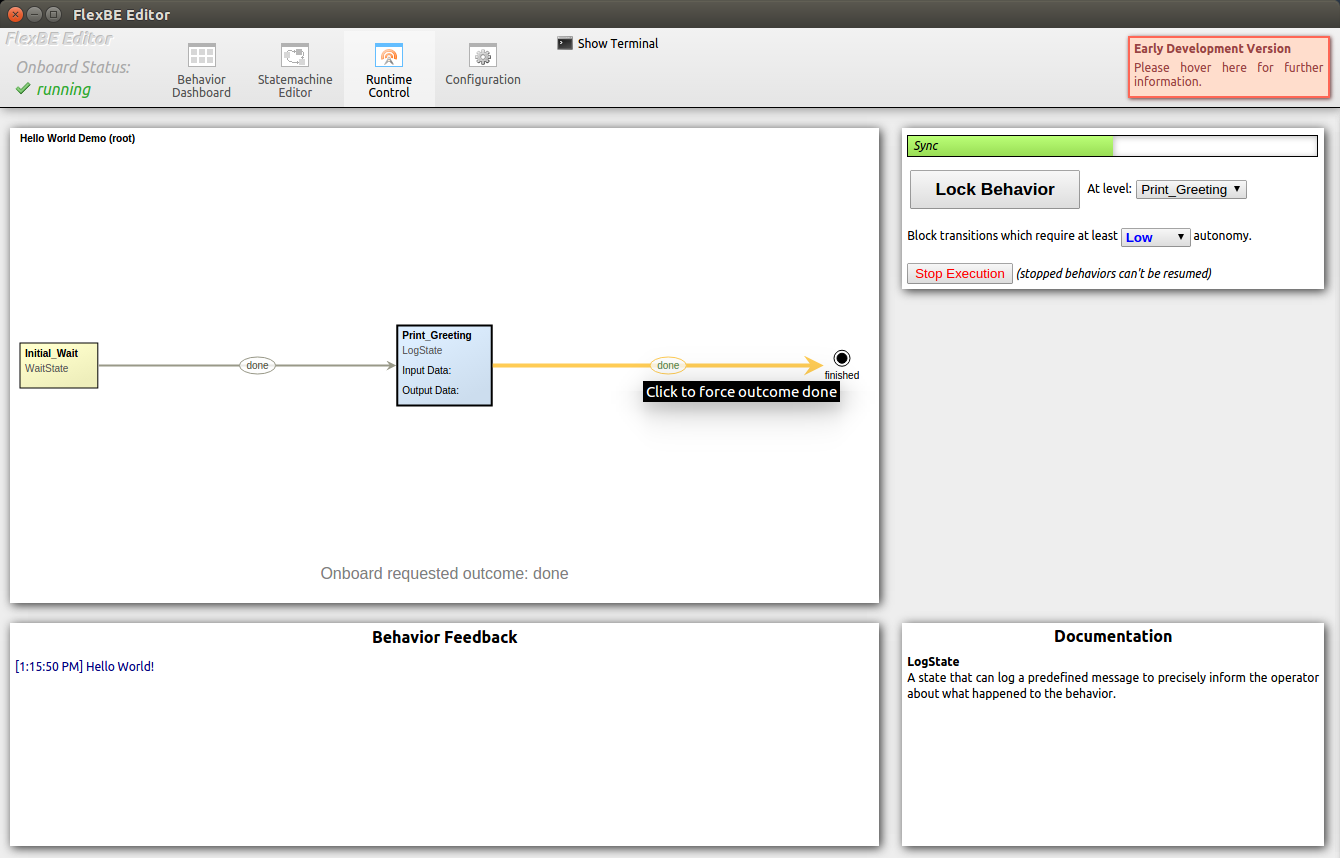
flexbe/Tutorials/Execution of a Behavior - ROS Wiki

move_base_flex/Tutorials/SimpleSmachForMoveBaseFlex - ROS Wiki

move_base_to_manip - ROS Wiki

move_base_to_manip - ROS Wiki

move_basic - ROS Wiki

3 ROS Tutorials Navigating The Filesystem - ROS Wiki - Note: This ...
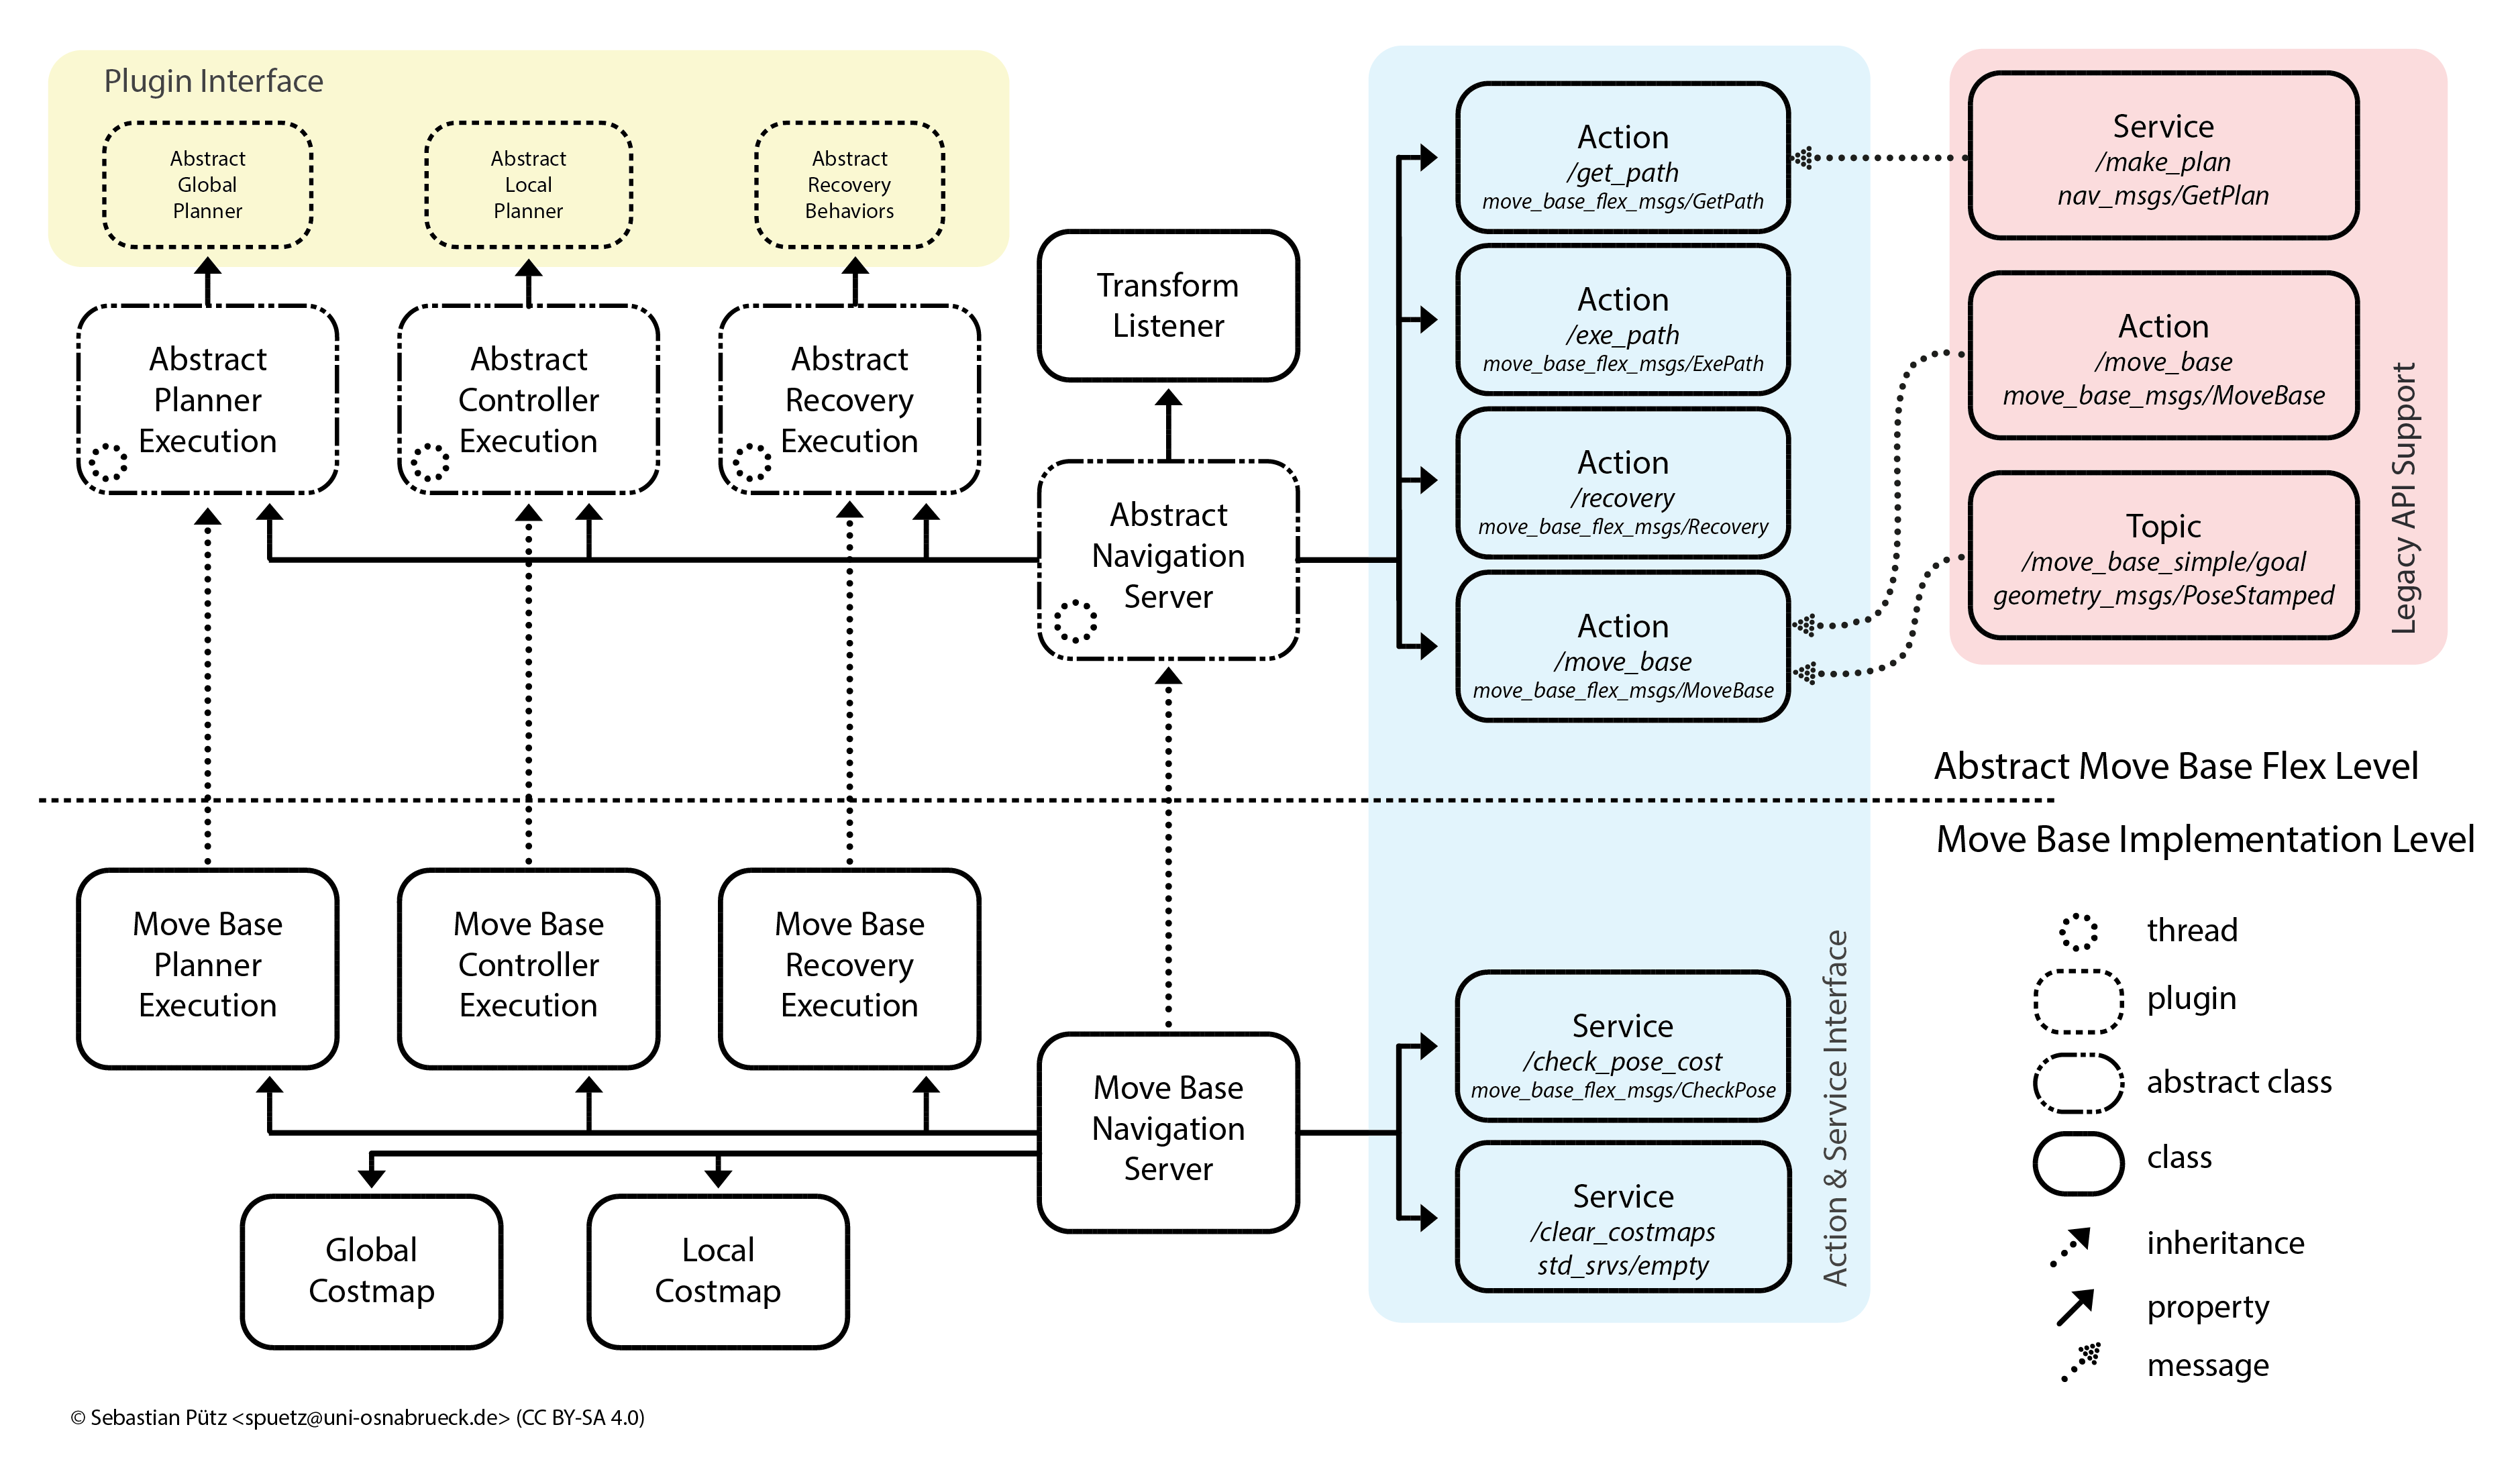
move_base_flex - ROS Repository Overview
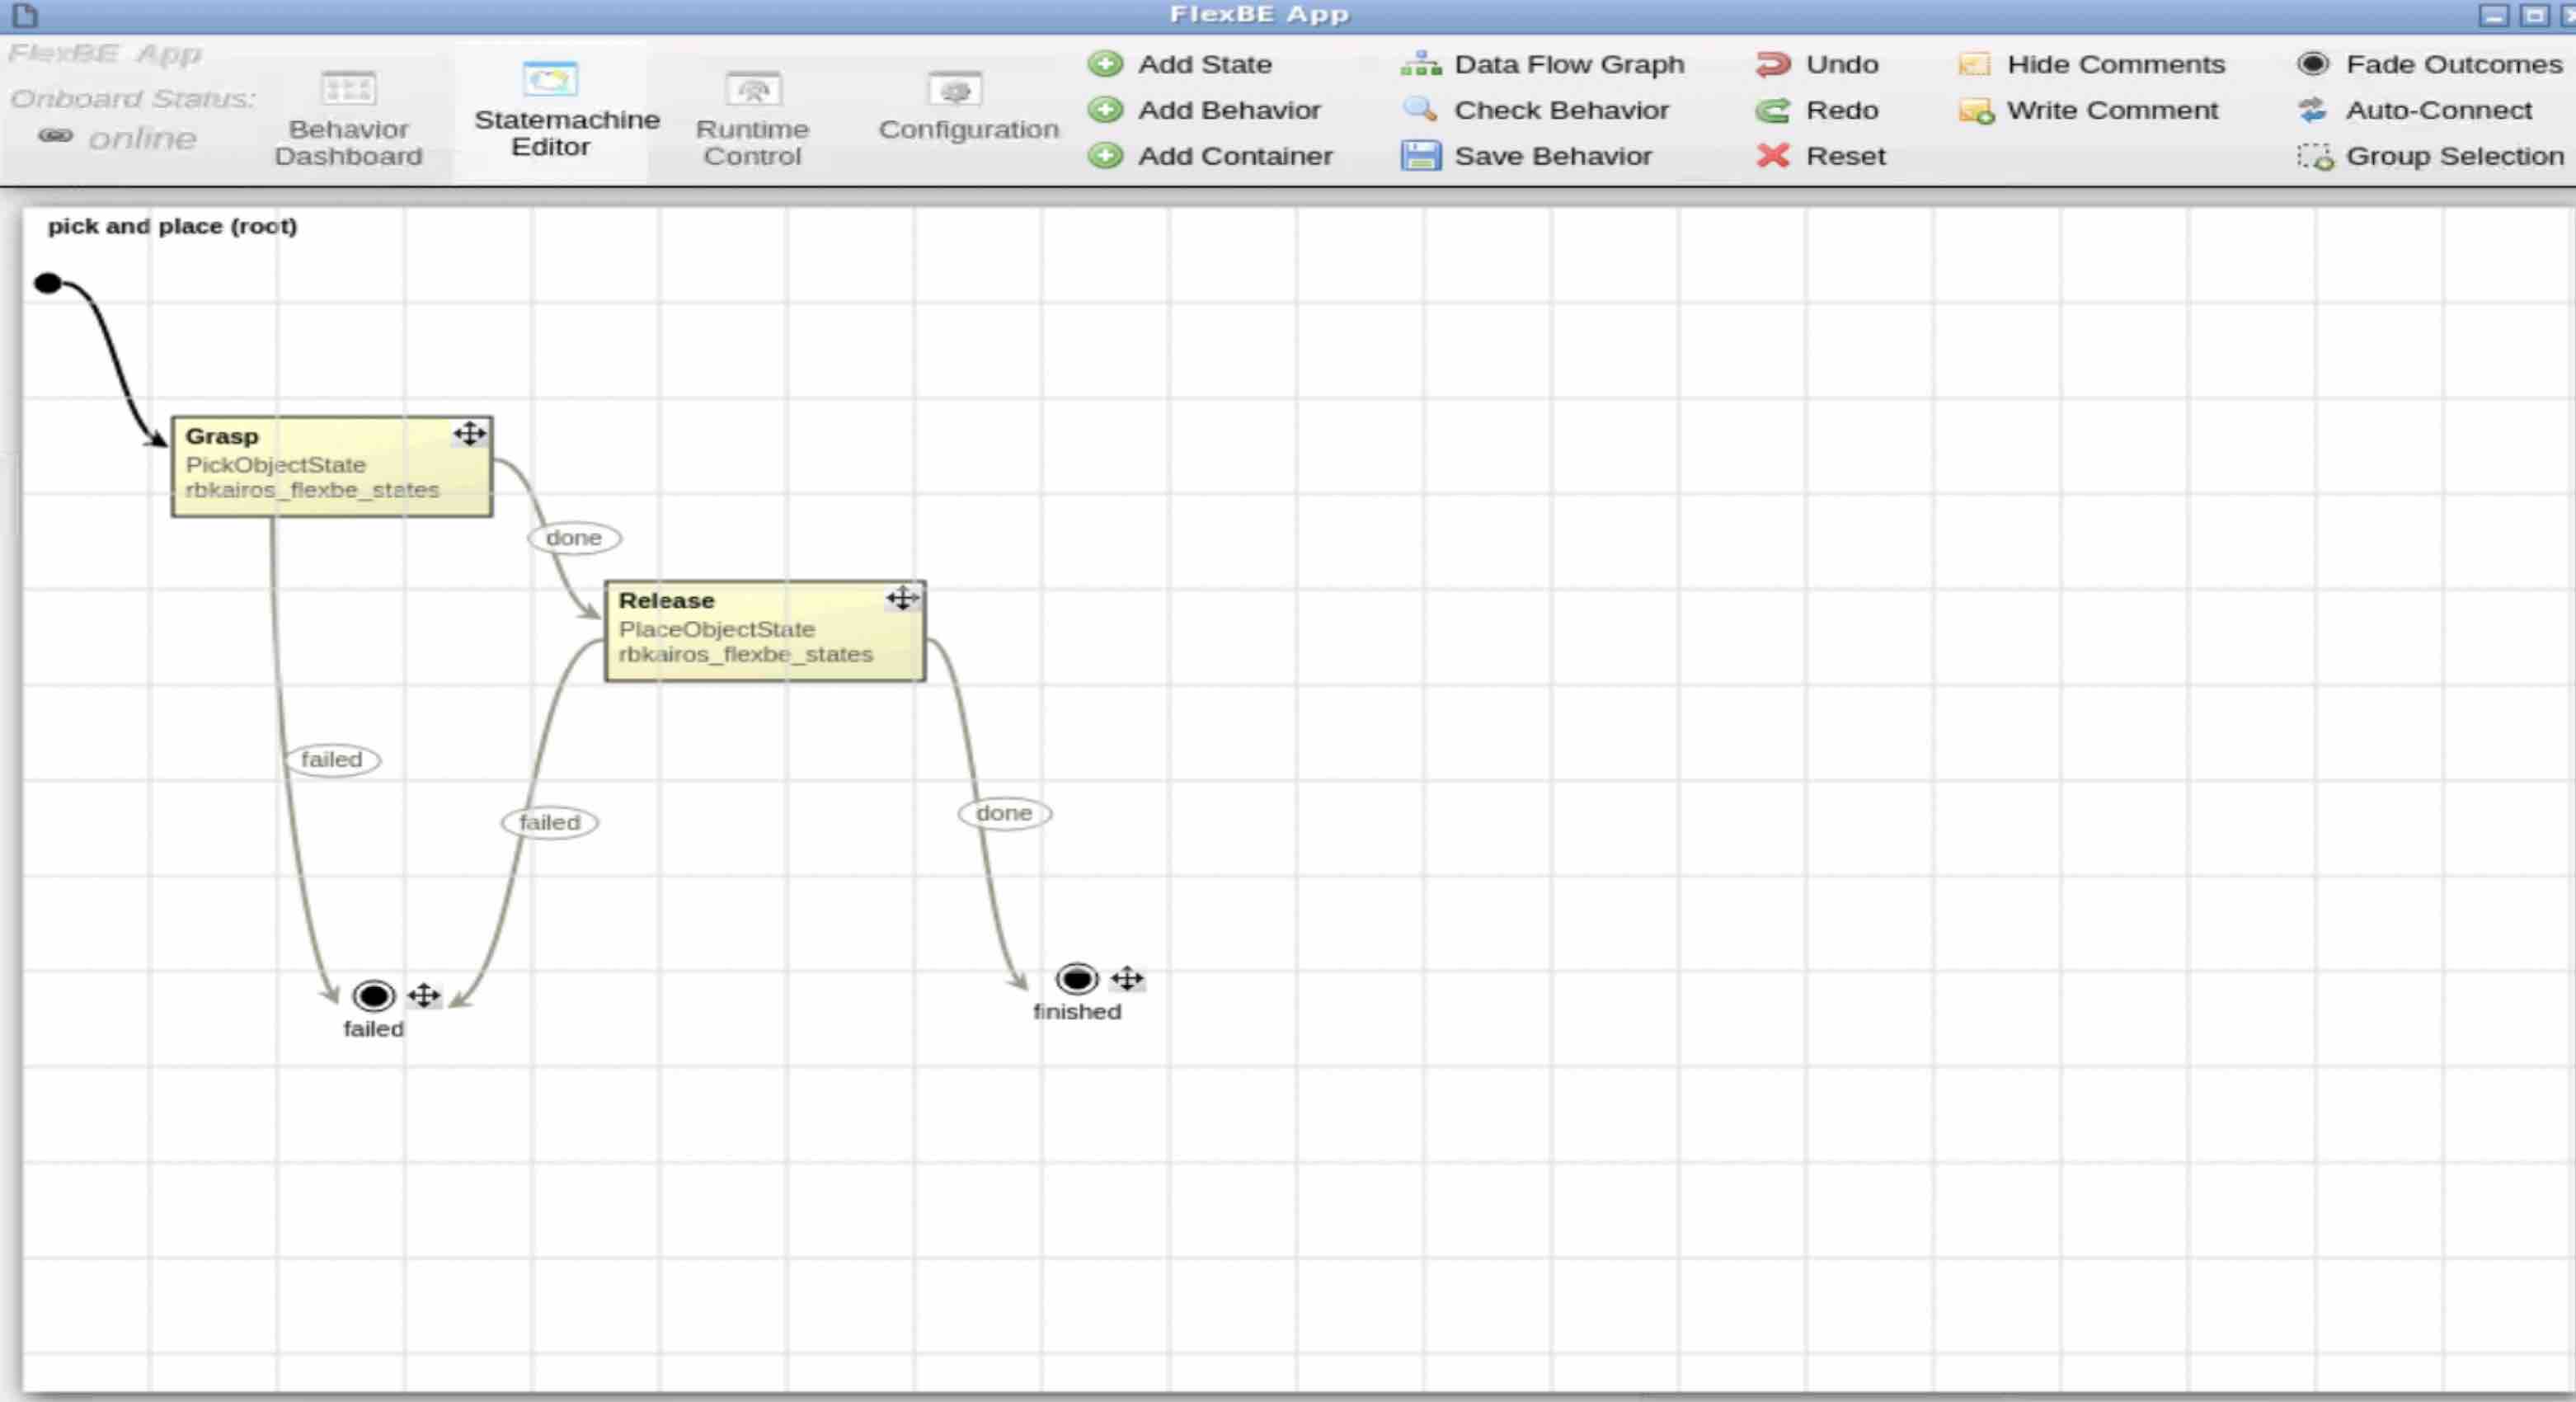
ROS Mobile Manipulators Training | The Construct

motion planning - Advise on ROS move_base costmap footprint not ...
Advertisement Space (300x250)

GitHub - aliy98/ros-gmapping-movebase: This ROS package provides three ...

ros - move_base start position is off the global costmap - Robotics ...
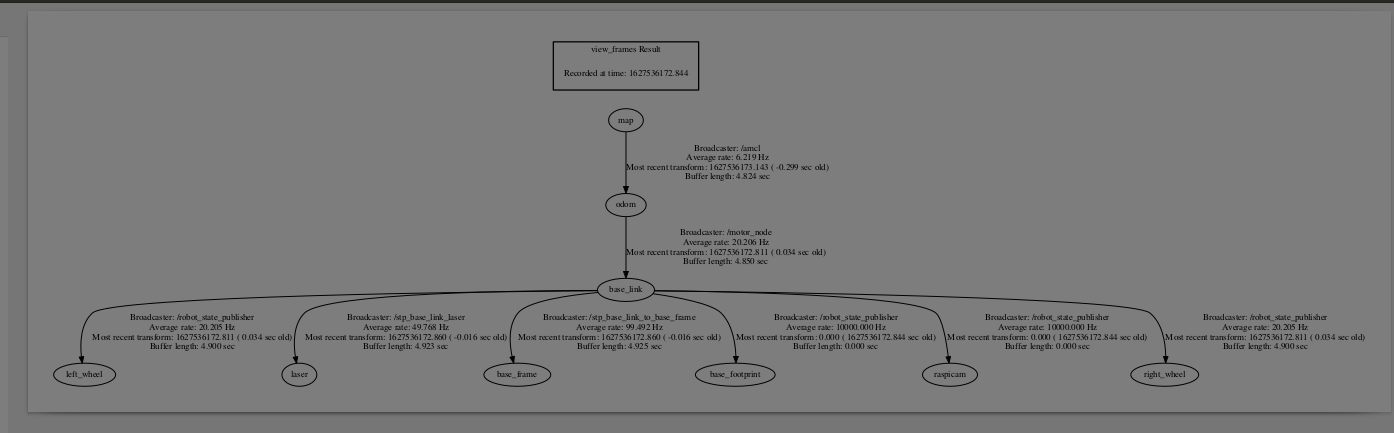
Move base error query - General Support - The Construct ROS Community

ros - Move_base/dwa parameters for a large robot with rotation center ...

How to view move_base/action_topics ? - ROS Answers archive
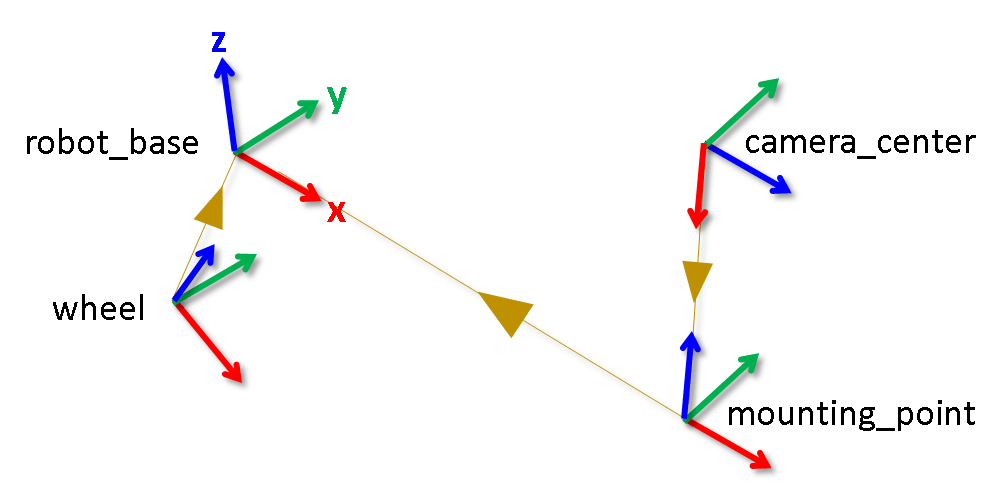
ROS 2 Network Access - MATLAB & Simulink

ros - TF transformation with move_base - Robotics Stack Exchange

ros - specifying base_link frame for the Transformation tree - Robotics ...

ros - specifying base_link frame for the Transformation tree - Robotics ...

Unable to send UTM move base goals to Rover - ROS Answers archive
Advertisement Space (336x280)

move_base_sequence - ROS Package Overview

ros - Problem with static transform publisher - Robotics Stack Exchange

ros - Gazebo and move_base problem - Robotics Stack Exchange

ROS actions provide preemptible client-server communications ...
Paquete ROS move_base [11]. | Download Scientific Diagram

ros - Could not obtain transform from base_footprint to base_link ...

ros - Sensor doesn't move from an initial pose for navigation stack ...

ROS : Navigation - move_base 功能包源码分析_ros navigation move base 功能包源码分析 ...

ros - move_base generating path in unknown space - Robotics Stack Exchange

ros kinetic - How can I change transform from "frame A" to "frame B ...
Advertisement Space (336x280)

ros - What link move_group get current pose refers to? - Robotics Stack ...
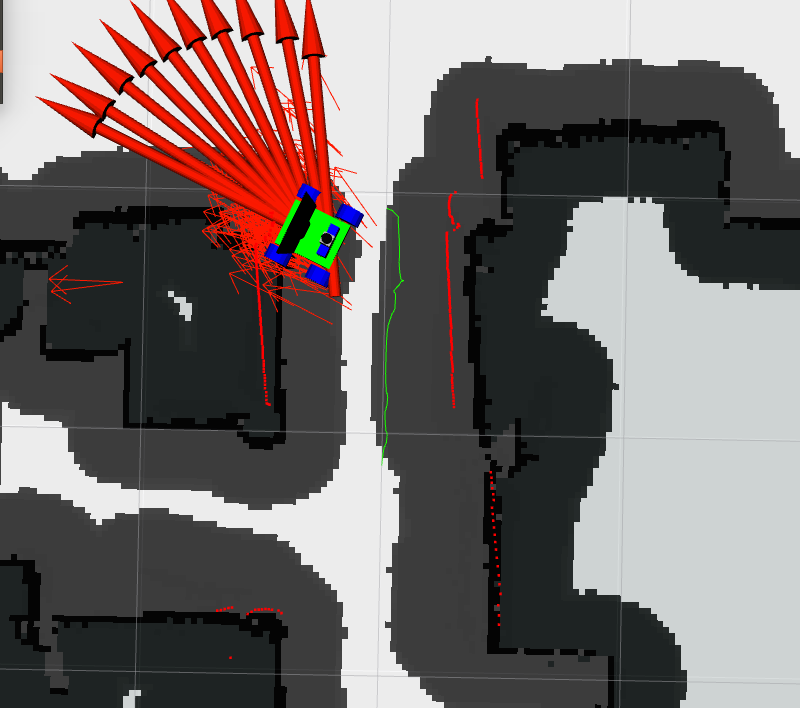
Robot doesn't avoid obstacles Move Base - ROS Navigation In 5 Days ...
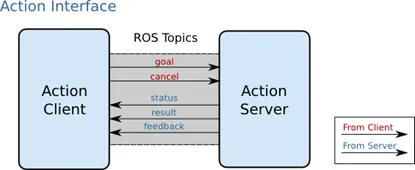
ROS 使用 move_base 做4个点循环跑的导航 - YOLOのBLOG

Path Planning ROS | Move Turtlebot to goal | Actionlib -CPP | Move Base ...

ros - move_base action server doesn't come up with a real robot ...

ros - Obstacle avoidance in move_base package - Robotics Stack Exchange