
Orbslam2ros G2ooptimizationalgorithmdogleg Class Reference

orb_slam2_ros: g2o::OptimizationAlgorithmDogleg Class Reference

orb_slam2_ros: g2o::OptimizationAlgorithm Class Reference

orb_slam2_ros: g2o::Solver Class Reference

orb_slam2_ros: DBoW2::BowVector Class Reference

Geant4: G4Orb Class Reference

orb_slam2_ros: optimizable_graph.h File Reference

orb_slam2_ros: optimizable_graph.h File Reference
orb_slam2_ros: optimization_algorithm_factory.h File Reference
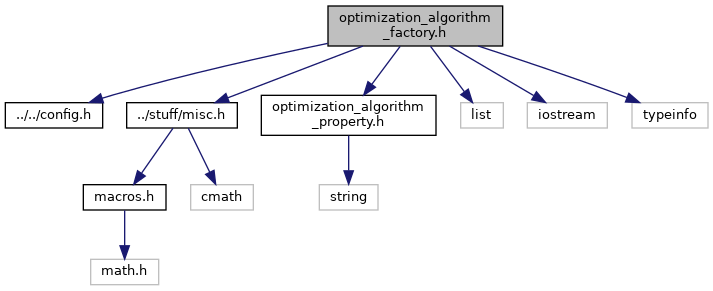
orb_slam2_ros: optimization_algorithm_factory.h File Reference

orb_slam2_ros: types_six_dof_expmap.h File Reference
Advertisement Space (300x250)

orb_slam2_ros: sim3.h File Reference
orb_slam2_ros: ScoringObject.h File Reference

orb_slam2_ros: openmp_mutex.h File Reference

orb_slam2_ros: sim3.h File Reference

orb_slam2_ros: hyper_graph.h File Reference

orb_slam2_ros: hyper_graph.h File Reference

orb_slam2_ros: types_six_dof_expmap.h File Reference

orb_slam2_ros: ScoringObject.h File Reference

orb_slam2_ros: openmp_mutex.h File Reference

orb_slam2_ros: DBoW2 Directory Reference
Advertisement Space (336x280)

Block diagram of the ORB-SLAM2 algorithm. | Download Scientific Diagram
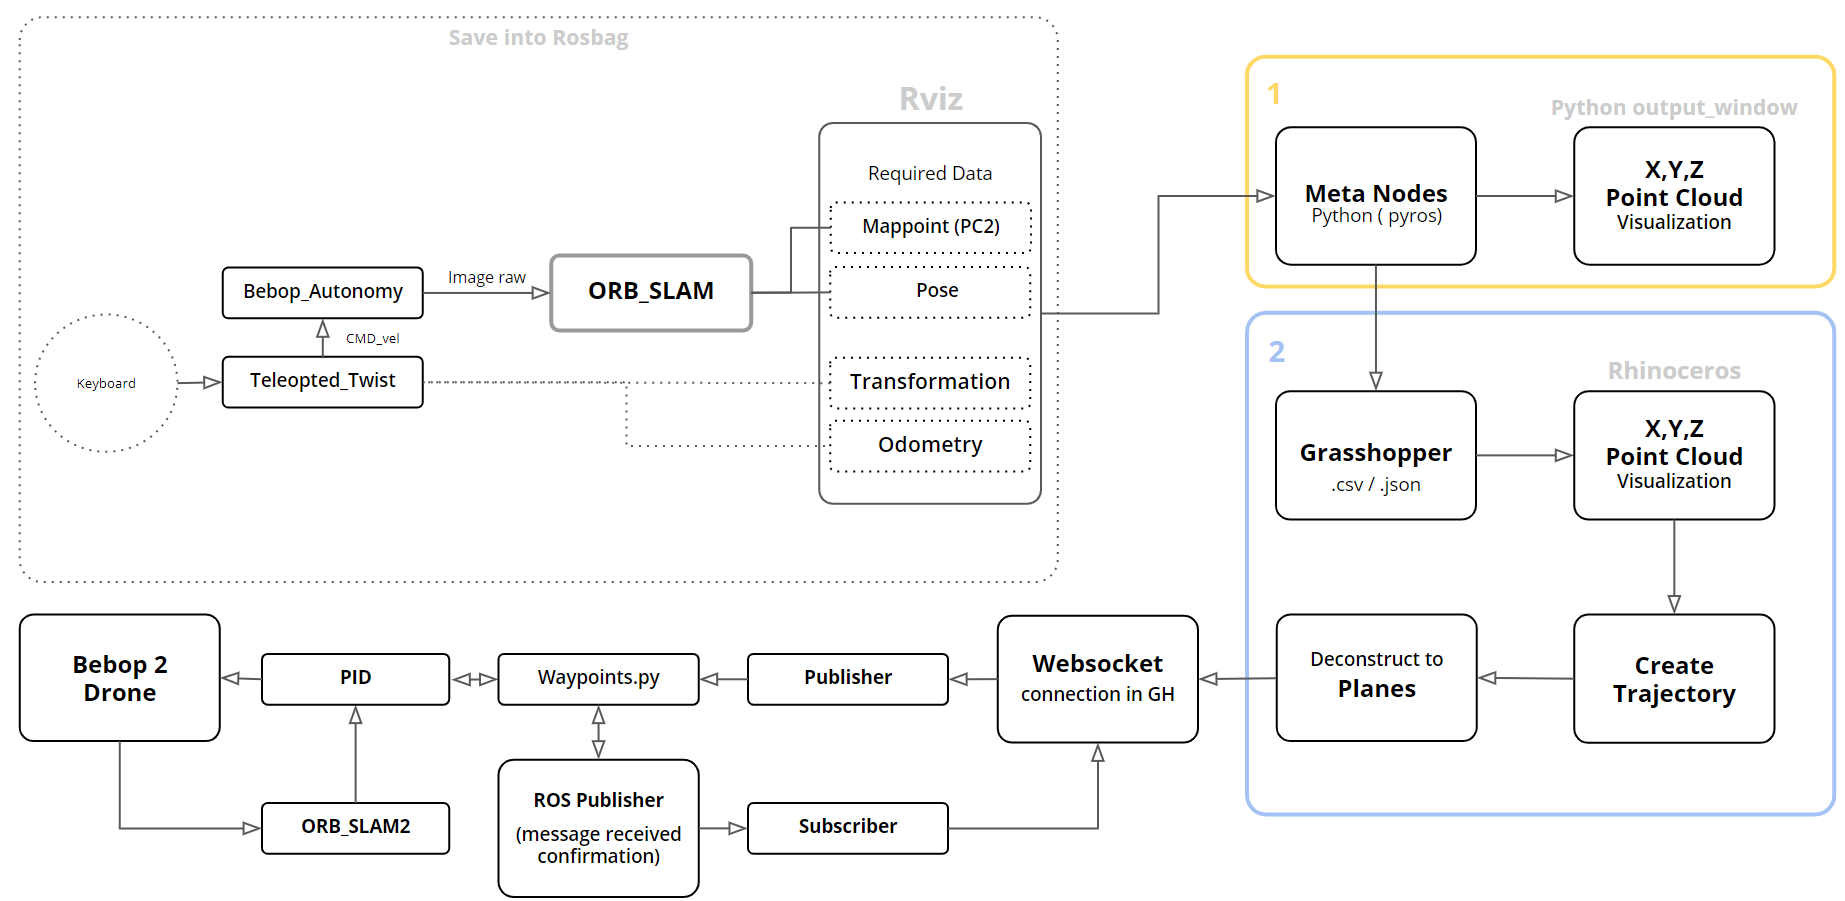
ROS, Grasshopper, Python, ORB SLAM2, Autonomous Navigation
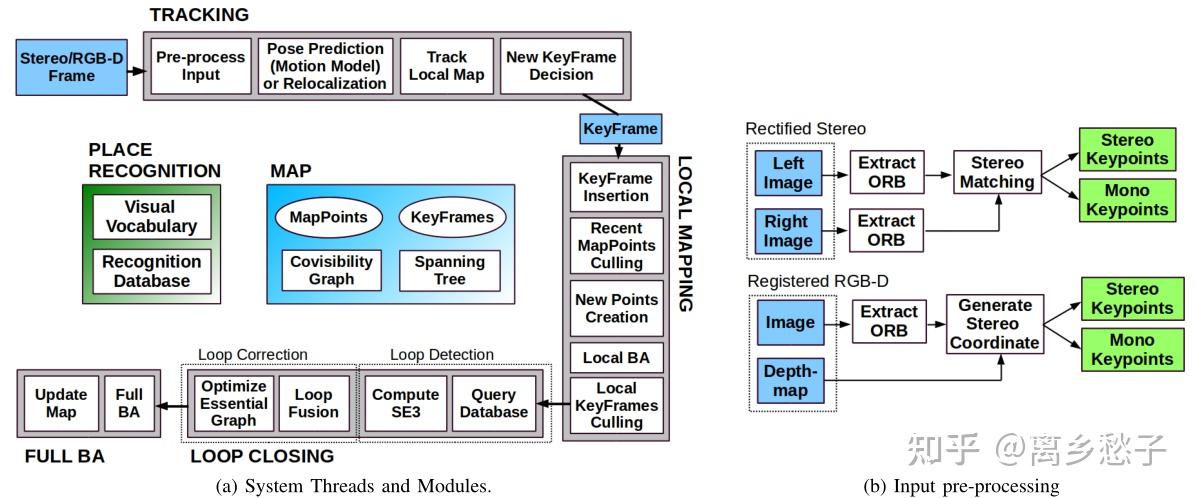
ORB-SLAM2 - 知乎

ORB-SLAM2原理分析-CSDN博客

Schematic of keyframe selection for traditional ORB-SLAM2 algorithm ...

1.4 ORB SLAM2算法框架详解 - YouTube

ORB-SLAM2原理分析-CSDN博客
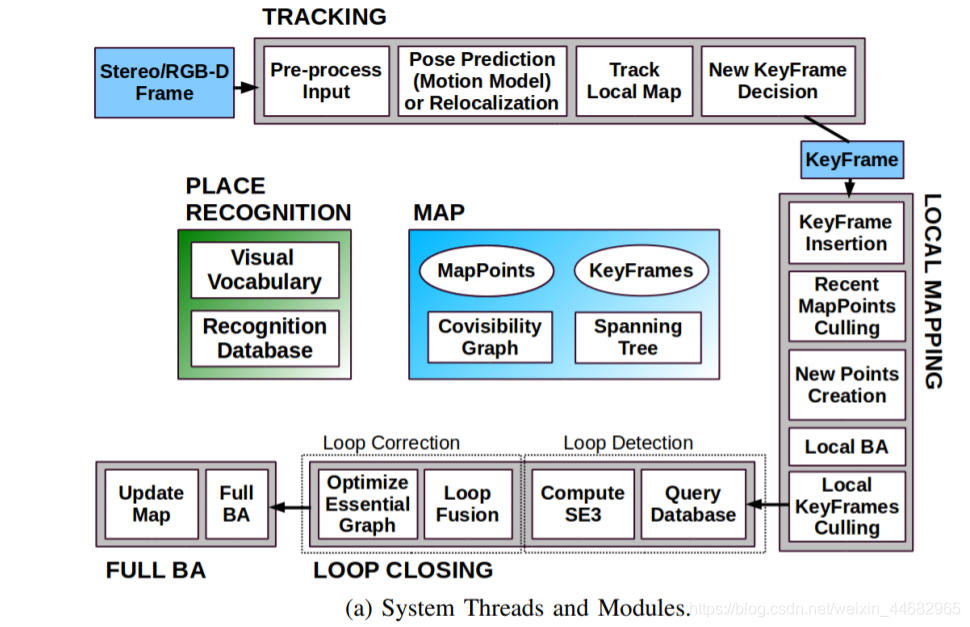
ORB-SLAM2论文详解_orbslam2-CSDN博客
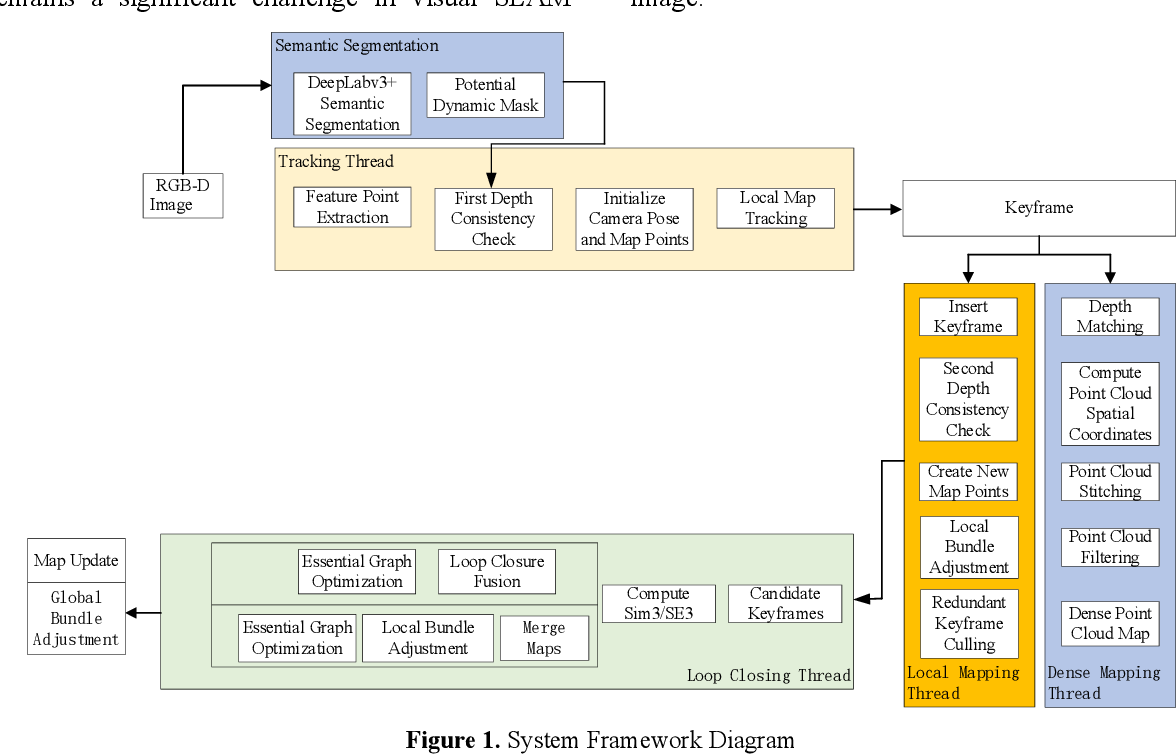
Figure 1 from A Method for Localization and Dense Mapping in Indoor ...
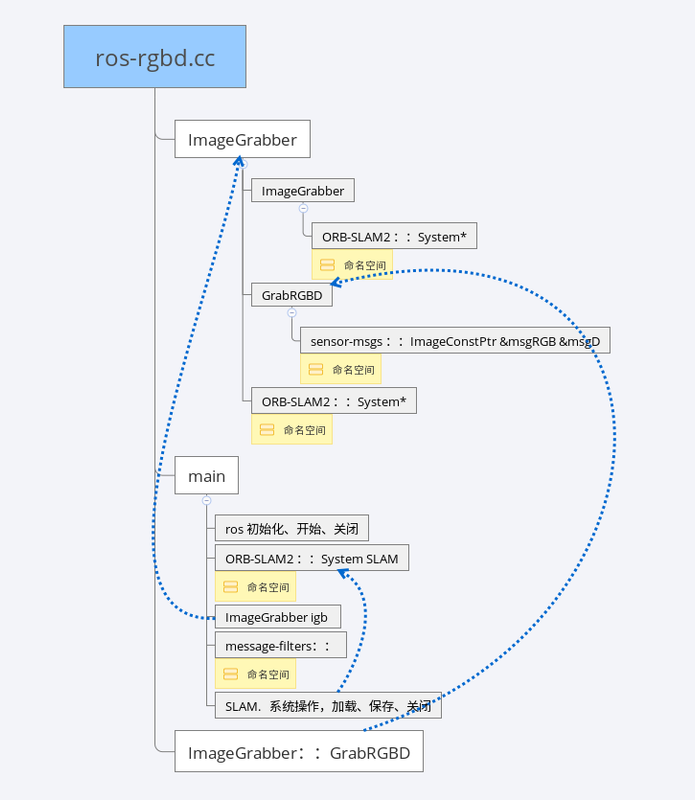
ORB_SLAM2 程序解读(1)-- 概述与ros_rgbd.cc | LDY_blog
Advertisement Space (336x280)
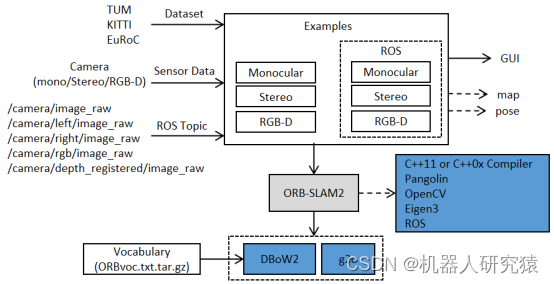
一起自学SLAM算法:9.1 ORB-SLAM2算法_orbslam算法_机器人研究猿的博客-CSDN博客
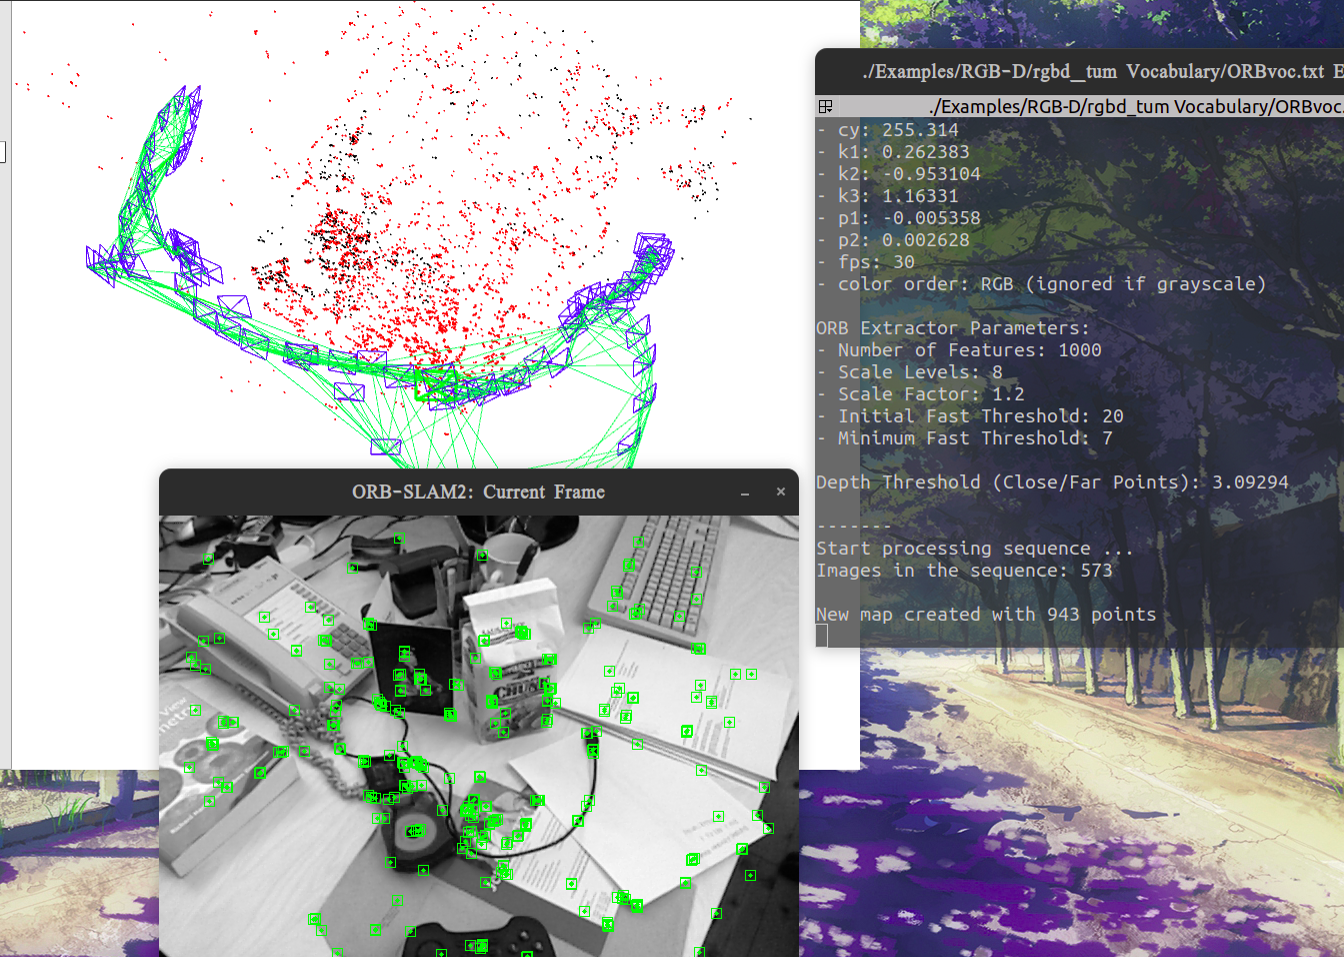
【记录】ORB_SLAM2 例程(README文件里的单双目RDB-D、ROS、AR、外接摄像头、点云)_orbslam2运行双目数据集-CSDN博客

ORB-SLAM2原理分析-CSDN博客

8. ORB_SLAM2 basics
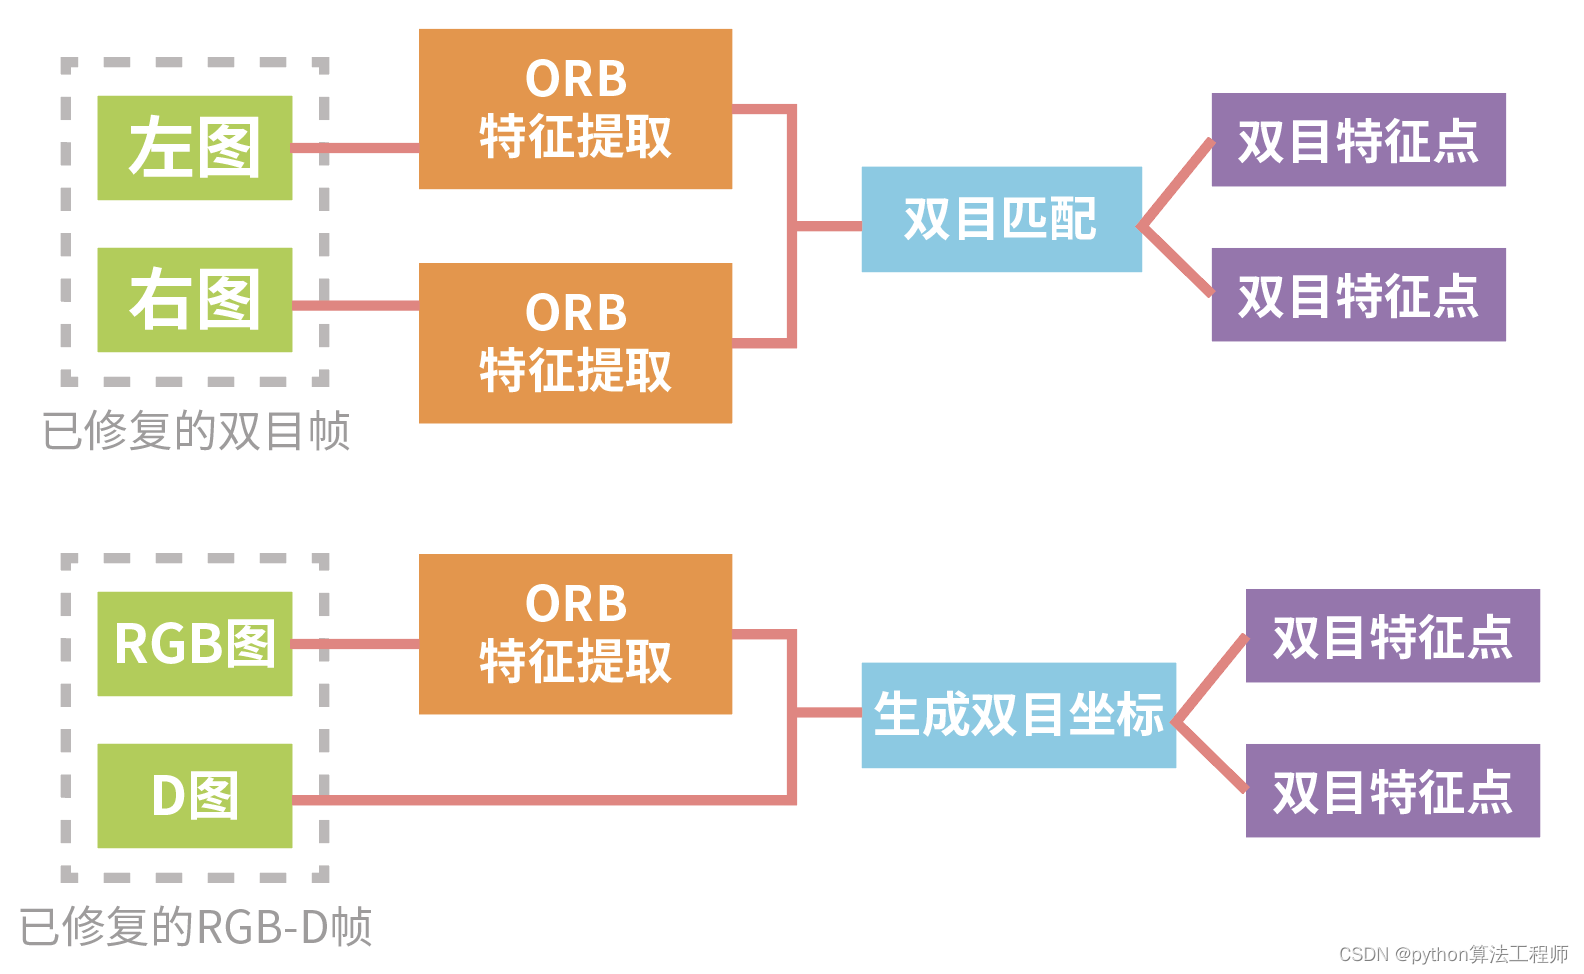
ORB-SLAM2原理分析_orbslam2-CSDN博客

SLAM算法与工程实践——SLAM基本库的安装与使用(6):g2o优化库(2)g2o编程框架_g2o dogleg-CSDN博客