
Orbslam2ros Sim3h File Reference

orb_slam2_ros: sim3.h File Reference

orb_slam2_ros: sim3.h File Reference
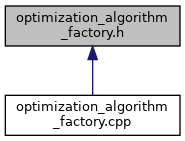
orb_slam2_ros: optimization_algorithm_factory.h File Reference

orb_slam2_ros: optimizable_graph.h File Reference
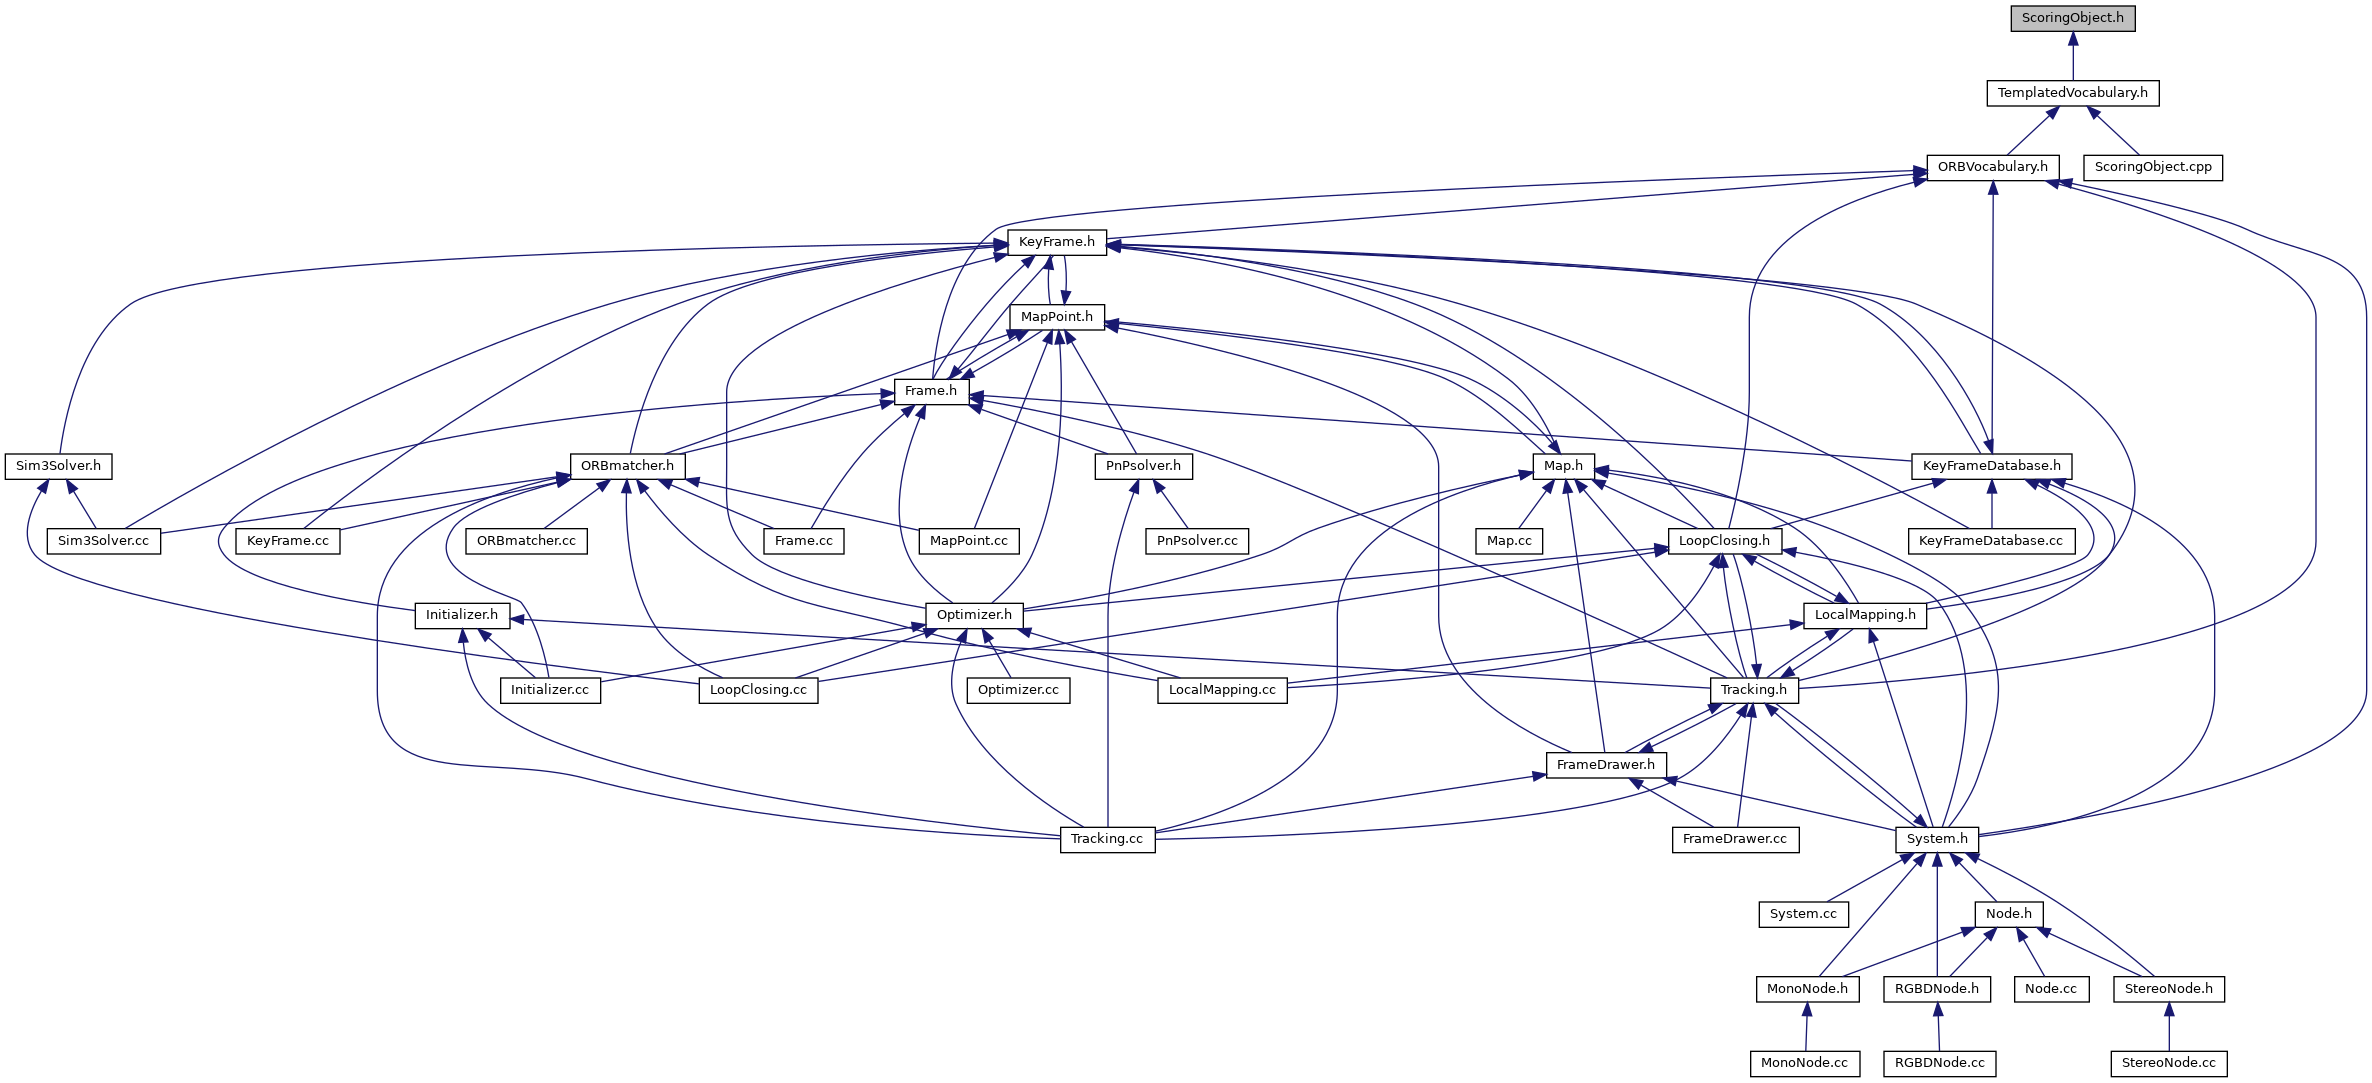
orb_slam2_ros: ScoringObject.h File Reference

orb_slam2_ros: hyper_graph.h File Reference

orb_slam2_ros: optimizable_graph.h File Reference

orb_slam2_ros: ScoringObject.h File Reference

orb_slam2_ros: types_six_dof_expmap.h File Reference

ROS下运行ORB-SLAM2双目Stereo(官方数据集)_ubuntu18运行orbslam2 ros运行数据集-CSDN博客
Advertisement Space (300x250)
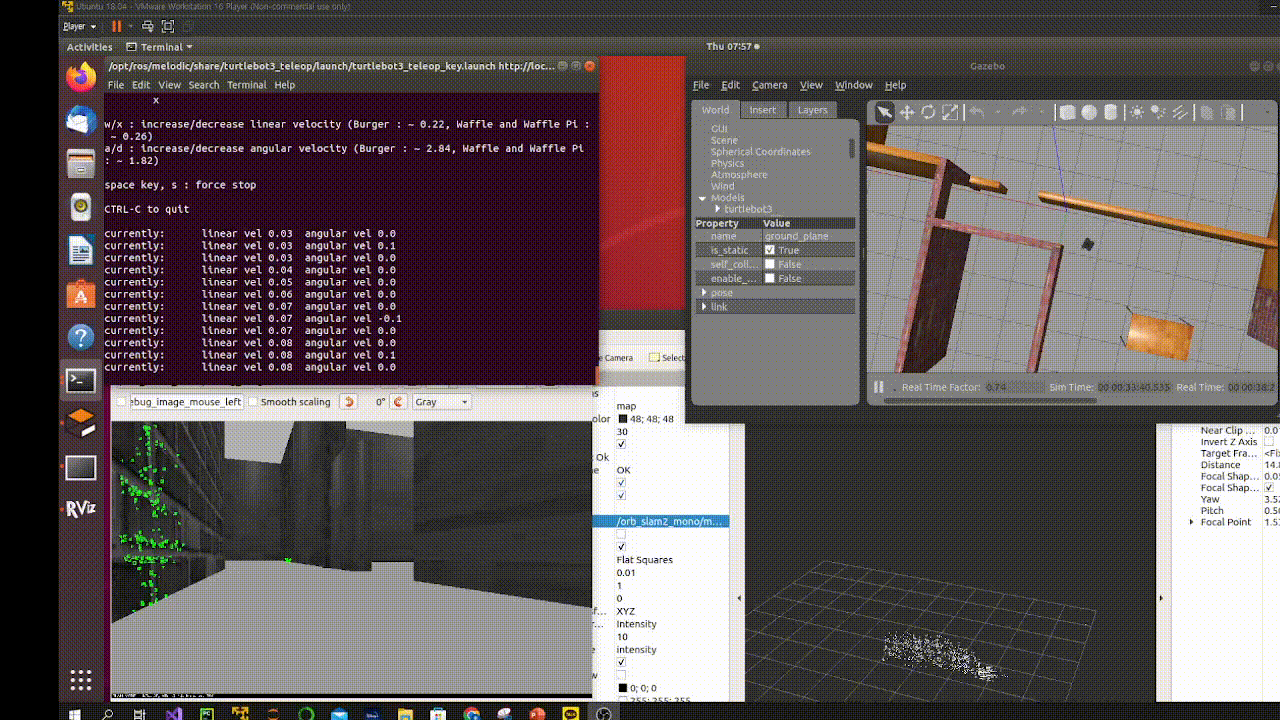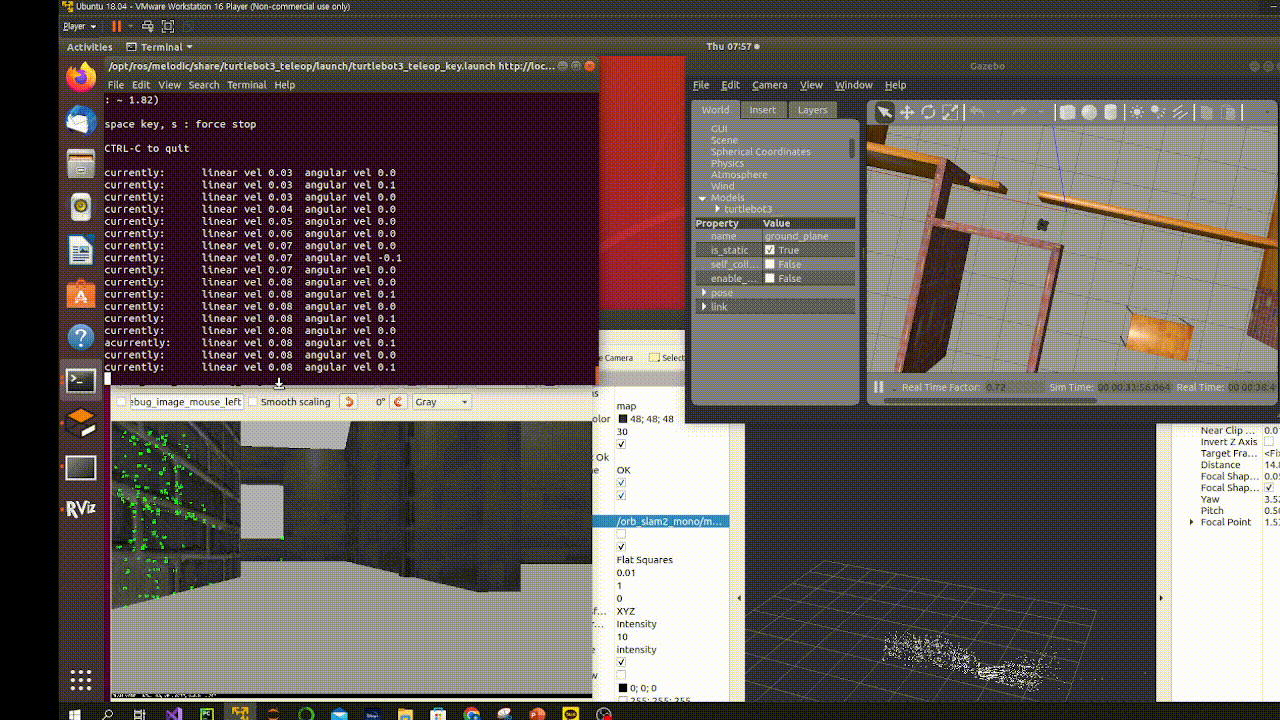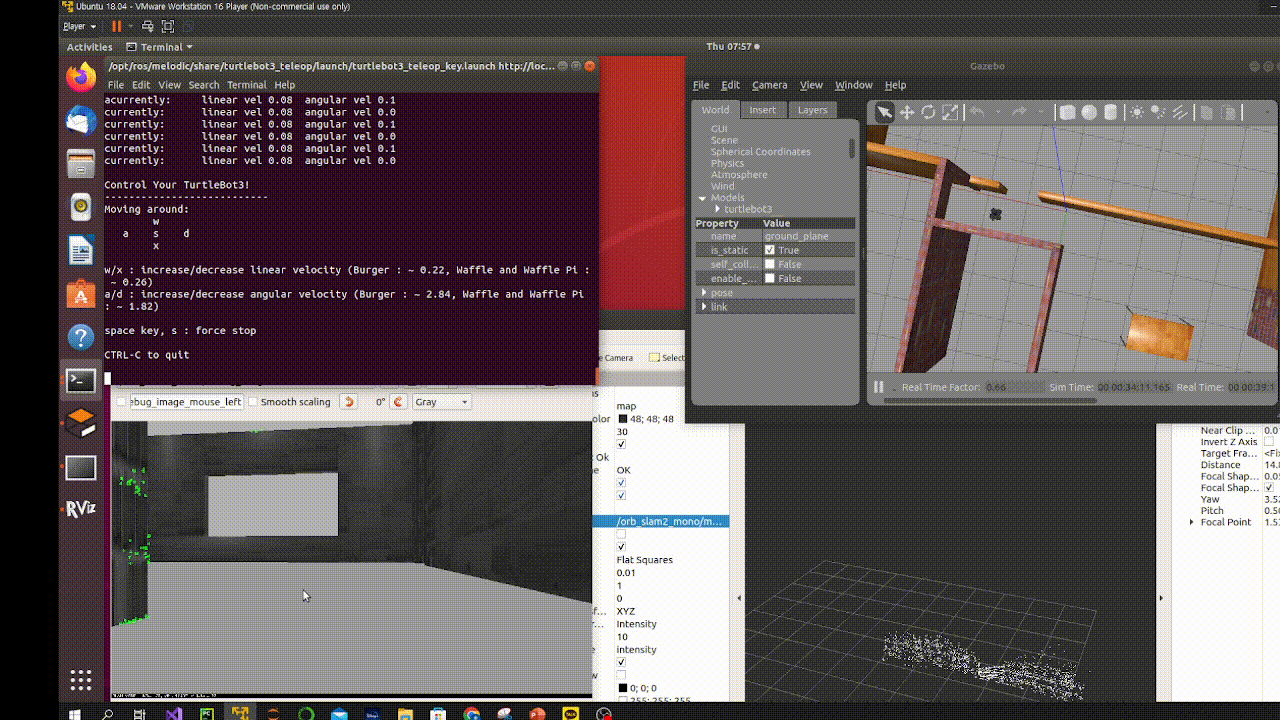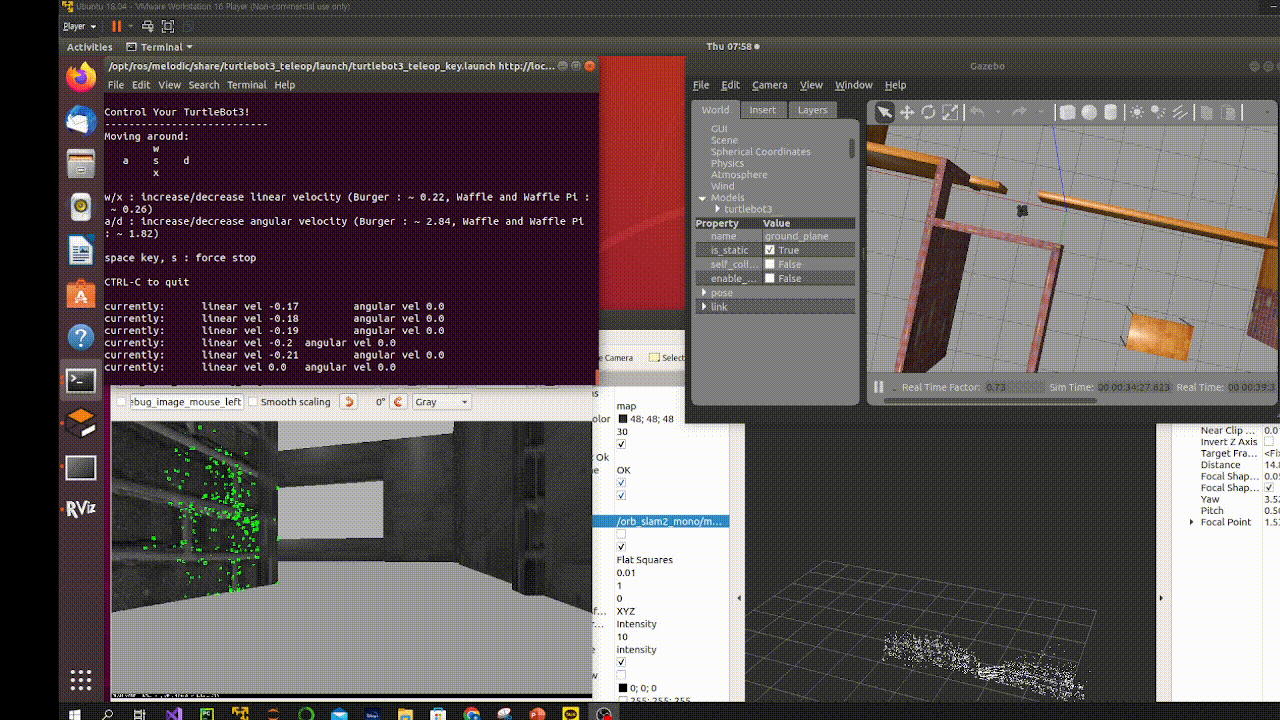
[ROS] ORB SLAM 실습
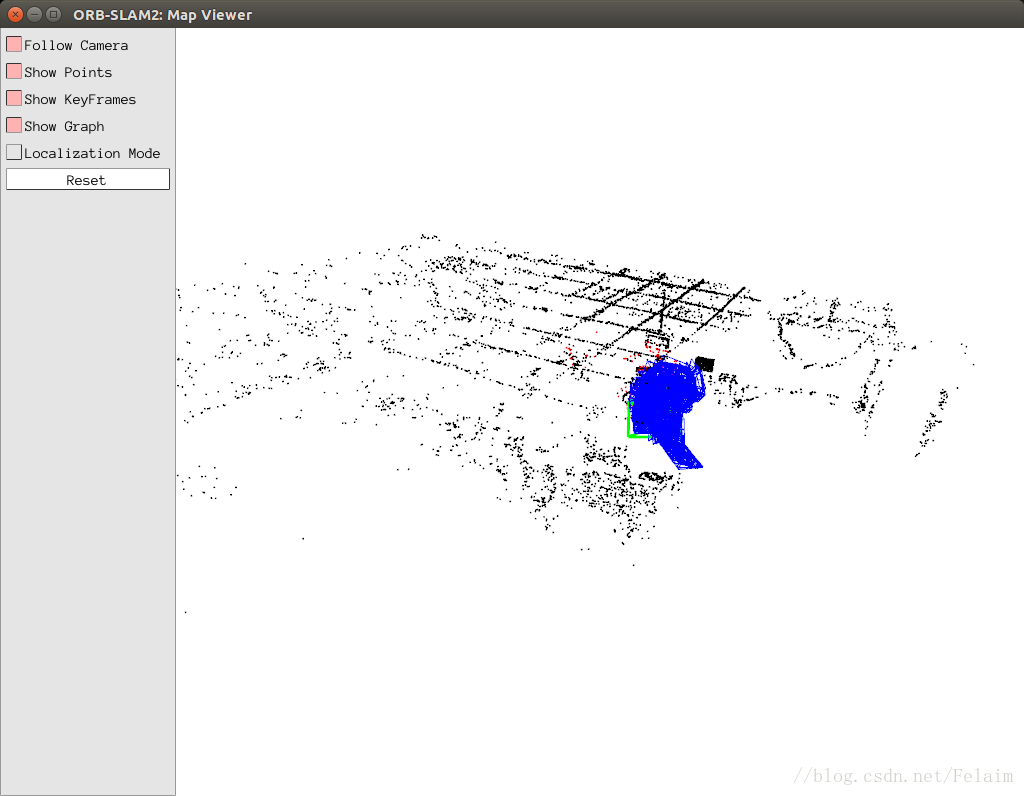
ROS(三):使用ROS跑通ORB_SLAM2_ros orbslam2-CSDN博客

ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)-腾讯云开发者社区-腾讯云
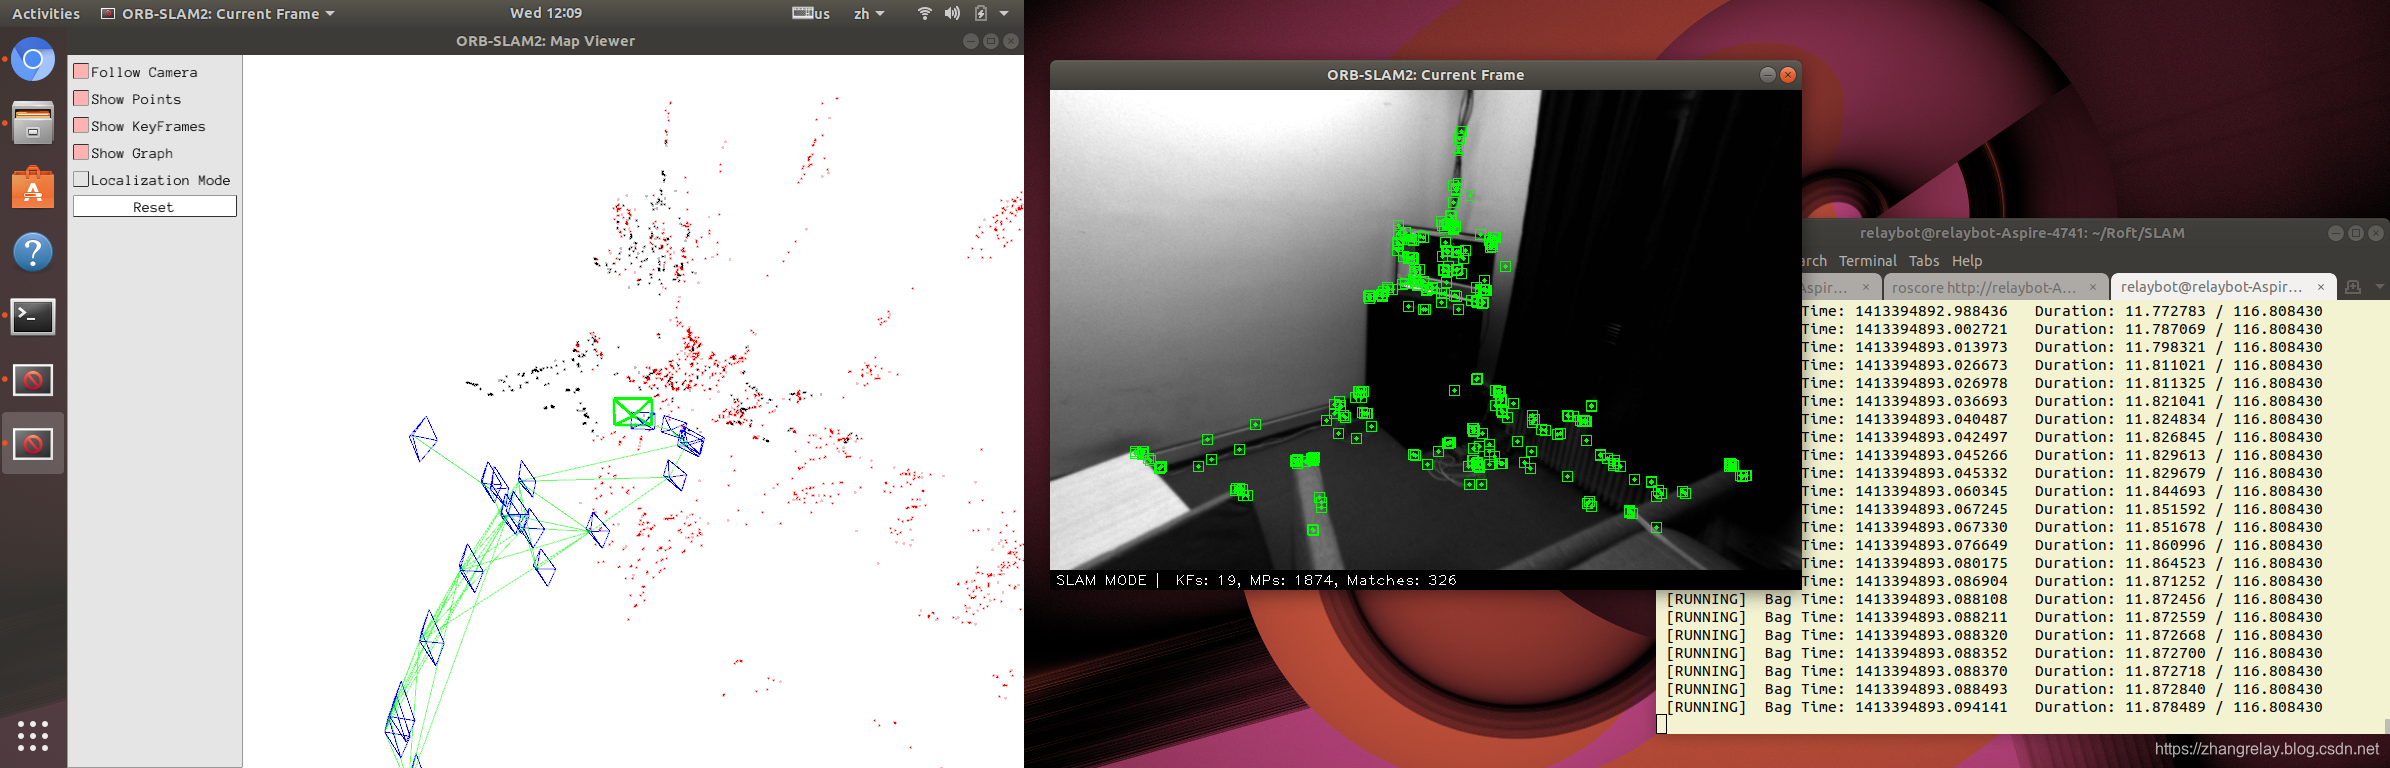
ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)_ros 2 slam 算法研究-CSDN博客
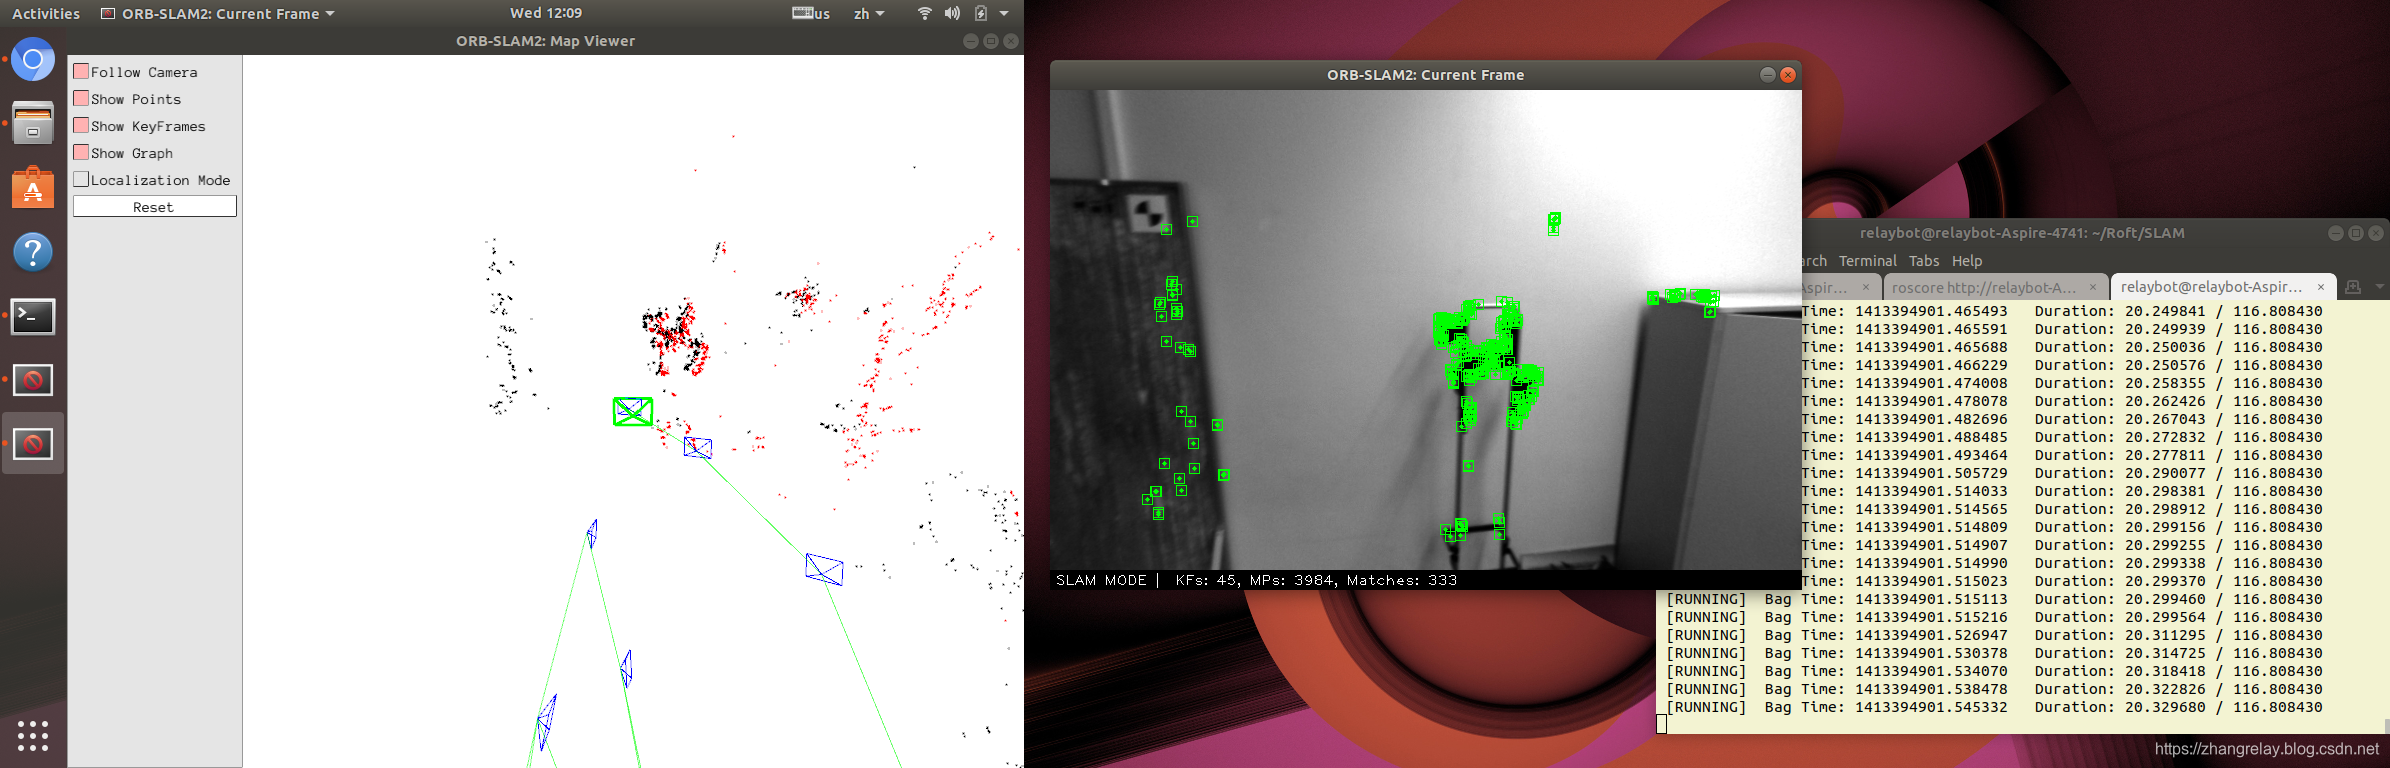
ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)_ros 2 slam 算法研究-CSDN博客

ORB-SLAM2和ORB-SLAM3环境配置及运行_orbslam2环境配置-CSDN博客

【记录】ORB_SLAM2 例程(README文件里的单双目RDB-D、ROS、AR、外接摄像头、点云)_orbslam2运行双目数据集-CSDN博客
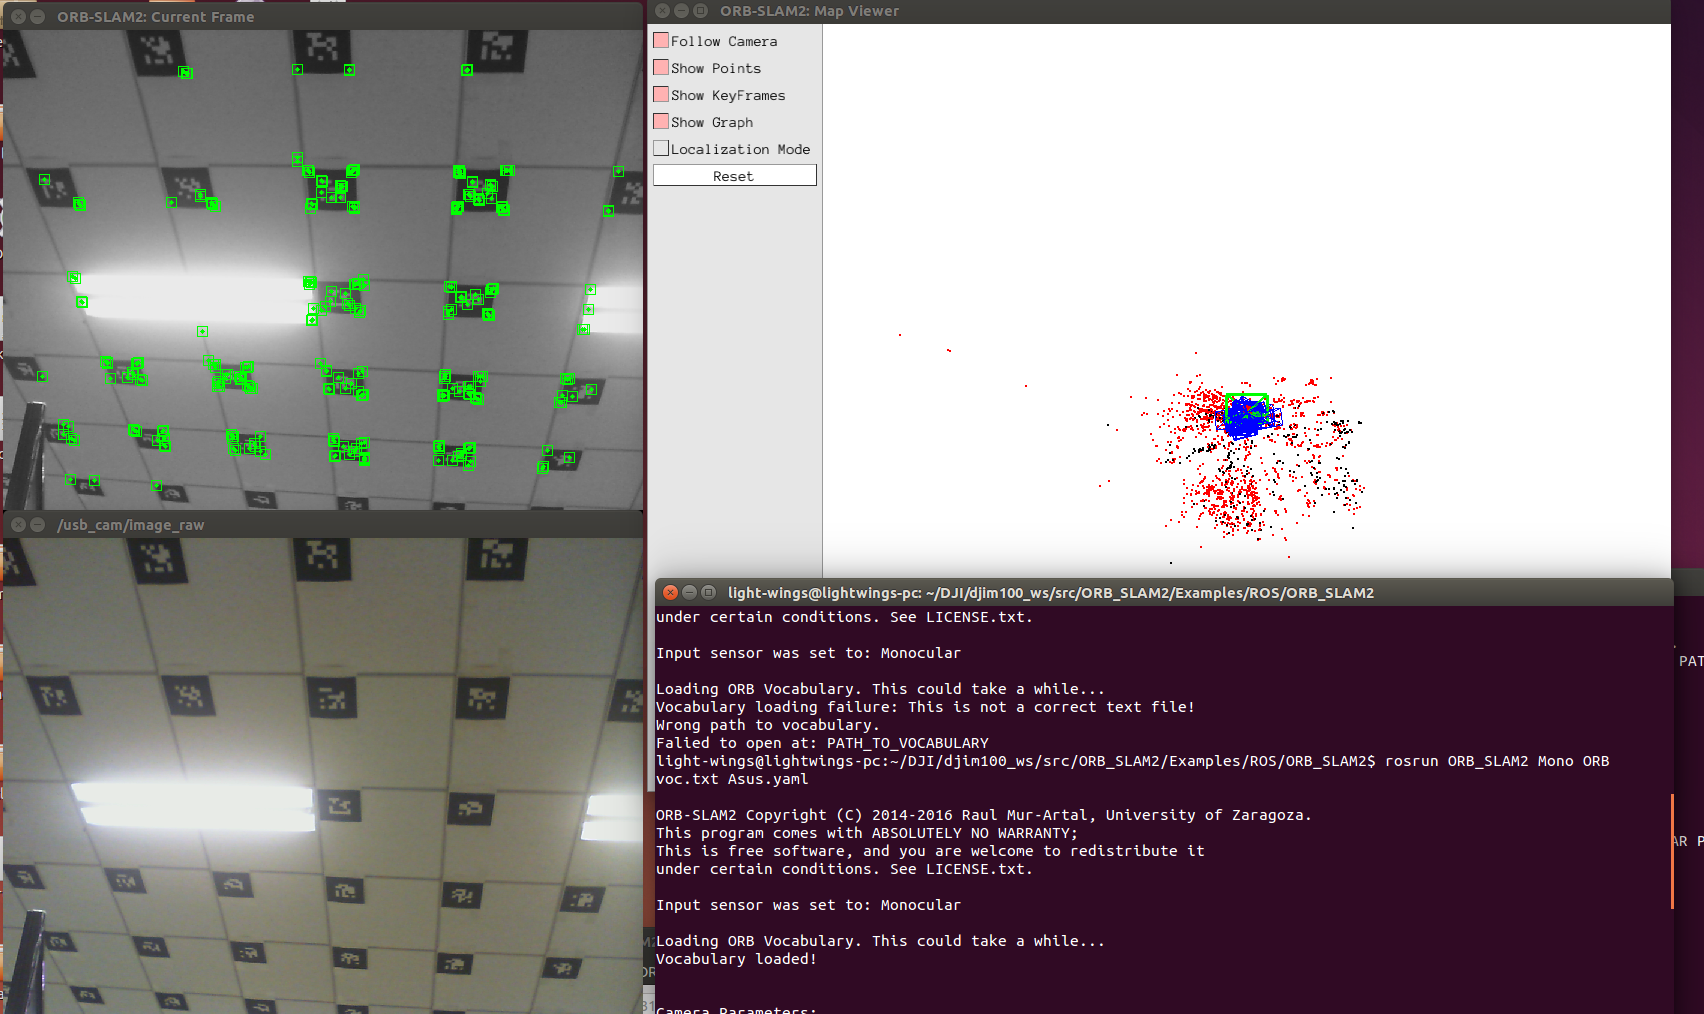
ORB-SLAM2(3) ROS下实时跑ORB_SLAM2_51CTO博客_orb slam

slam - Problem with Stereo ORB SLAM2 in ROS Creating Strange ...
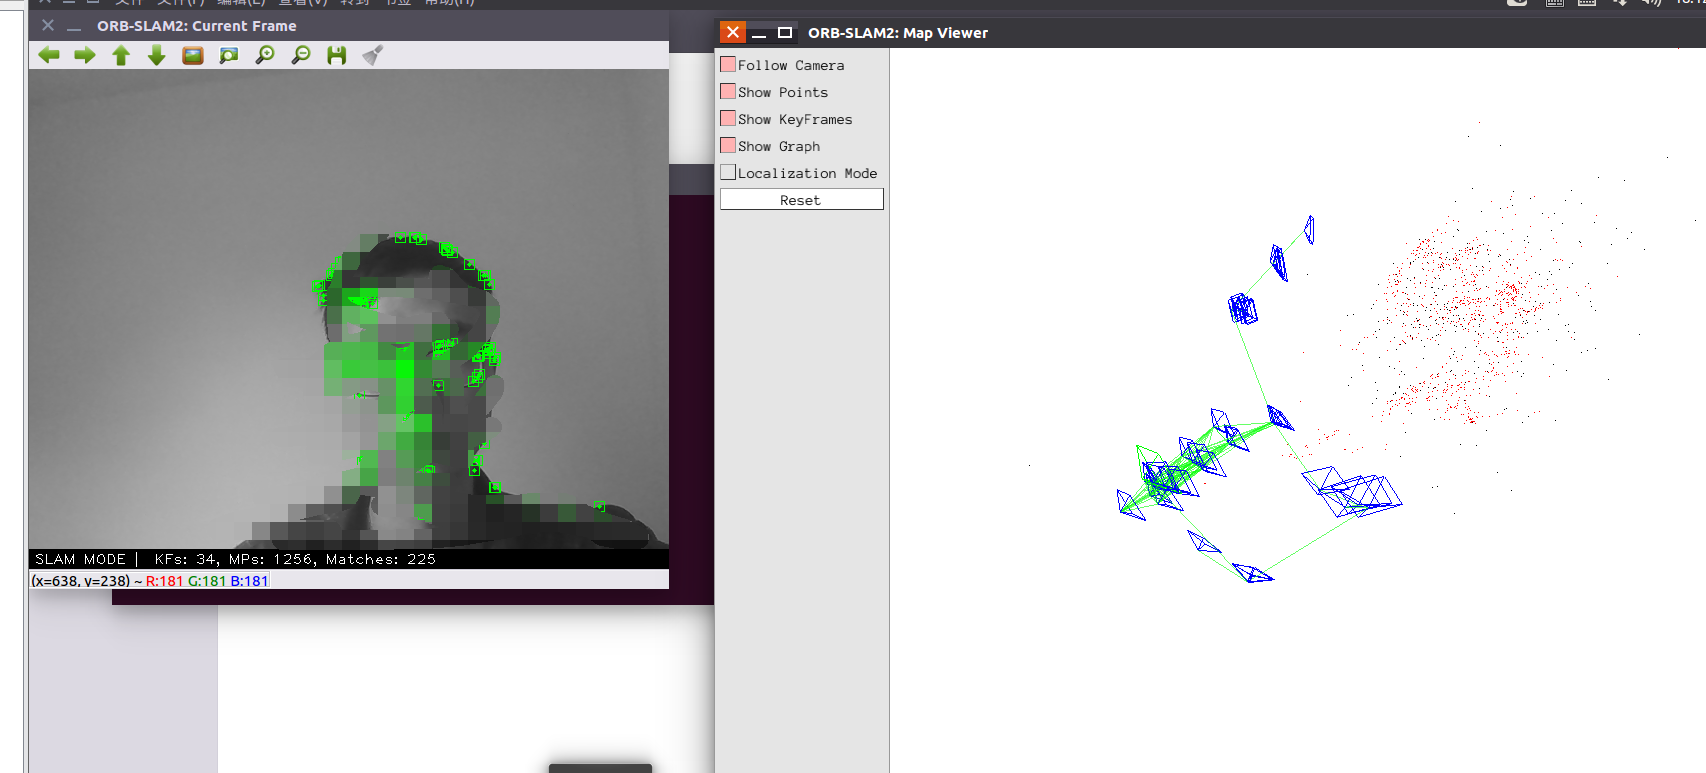
Run ORB-SLAM2 in real time under ROS - Programmer Sought
Advertisement Space (336x280)

8. ORB_SLAM2 basics

GitHub - HyeonJaeGil/orbslam2-ros: ready-to-use implementation of ORB ...
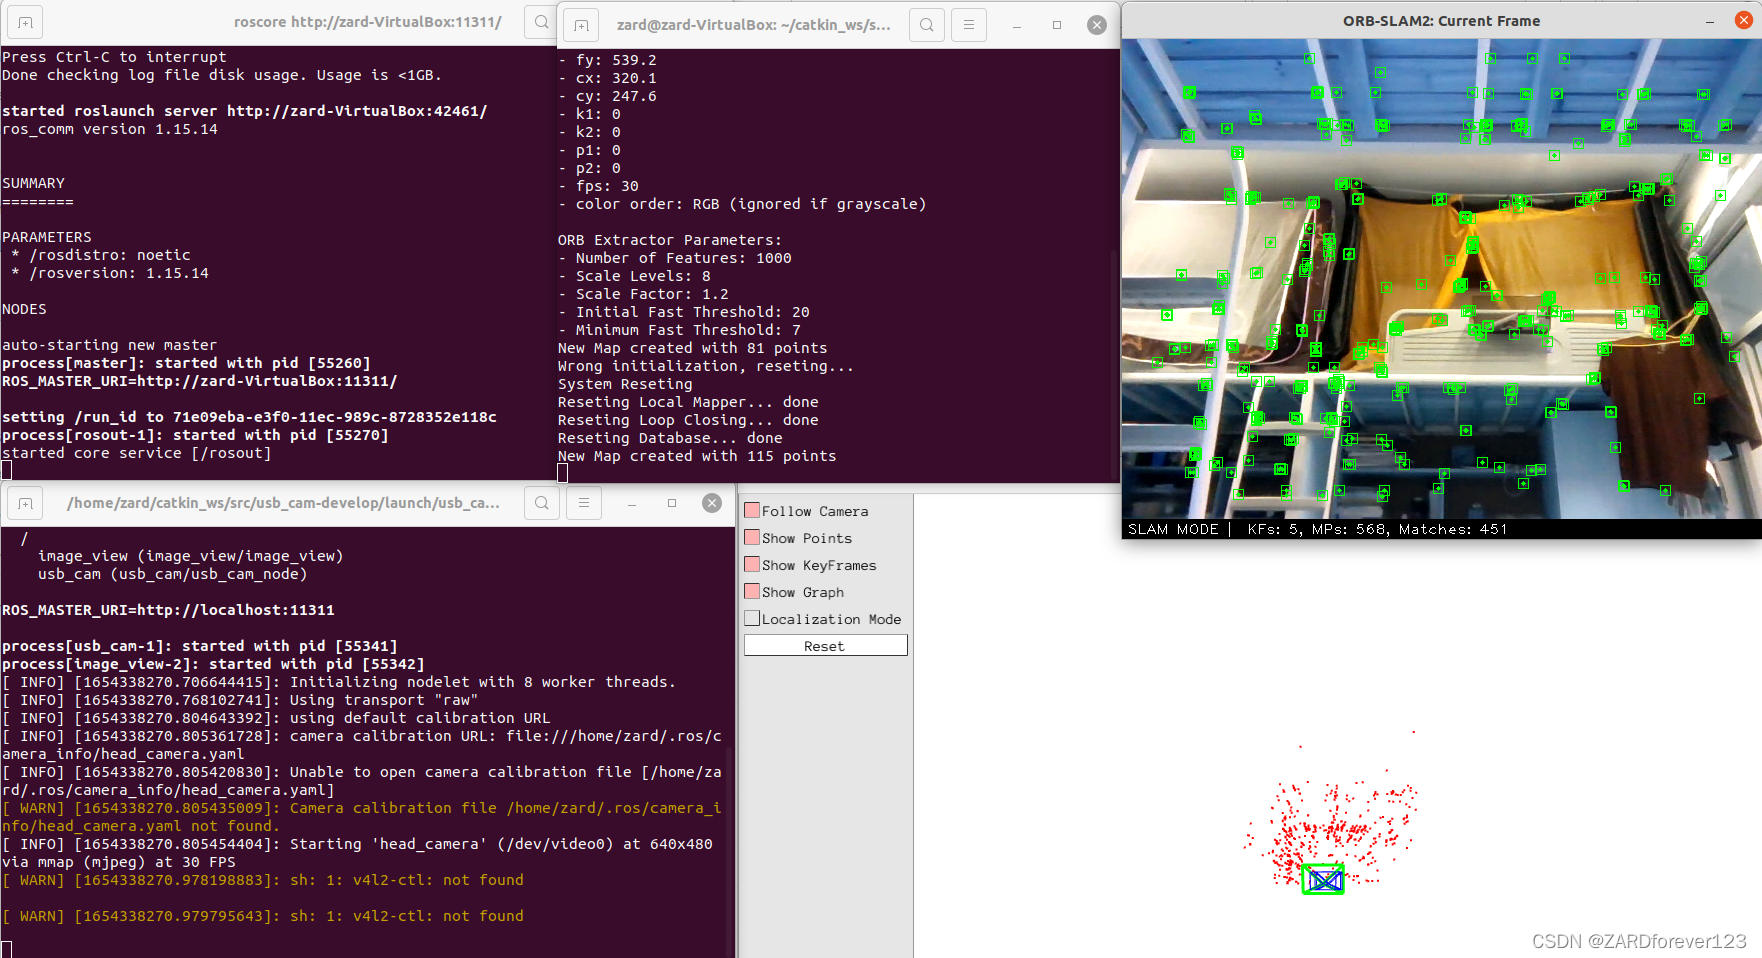
Ubuntu 20.04配置ORB-SLAM2和ORB-SLAM3运行环境+ROS实时运行ORB-SLAM+Gazebo仿真运行ORB ...
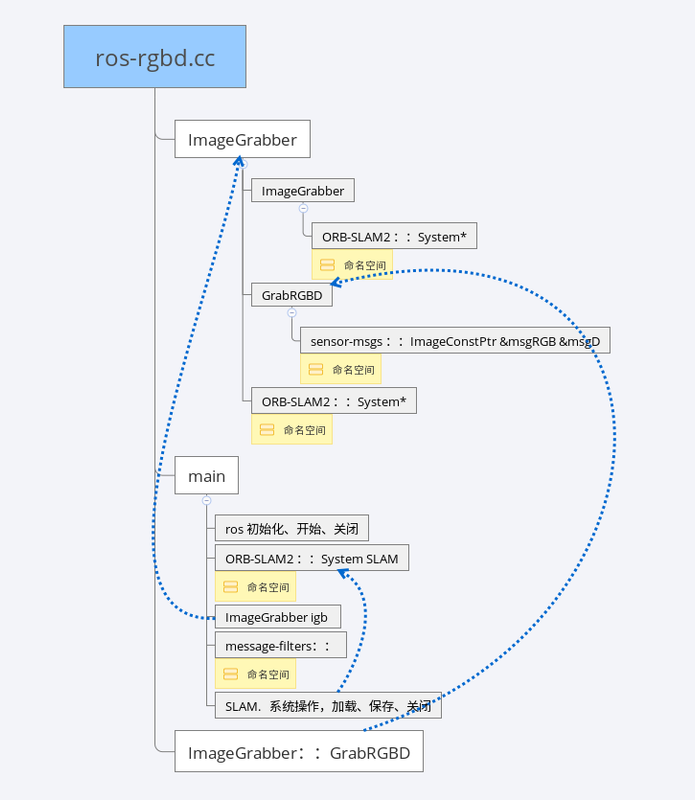
ORB_SLAM2 程序解读(1)-- 概述与ros_rgbd.cc | LDY_blog

ORB-SLAM2(3) ROS下实时跑ORB_SLAM2_51CTO博客_orb slam

Two screenshots of ORB-SLAM2 representation of the detected features ...

ORB_SLAM2 技术详解(3)Part II -- 编译并使用ROS ORB_SLAM2 Package_编译orb-slam2的ros包 ...
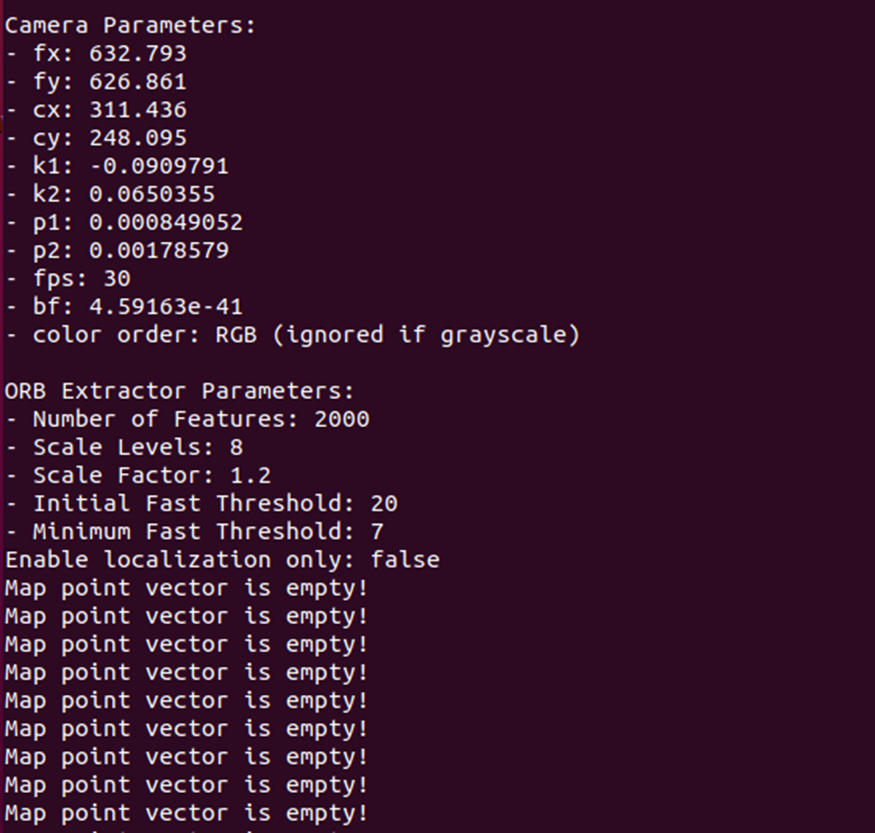
[ROS] ORB SLAM 실습
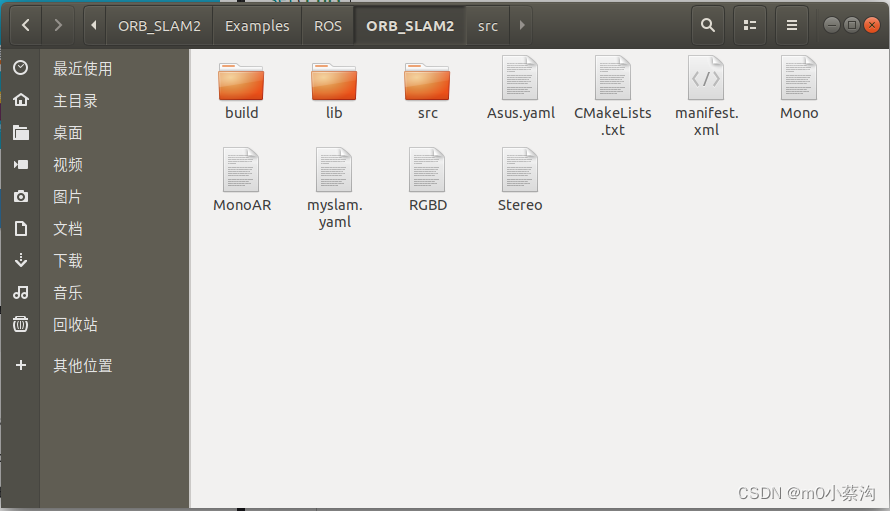
ORB_SLAM——ROS下运行记录_orb-slam ros-CSDN博客

使用奥比中光Orbbec Astra Pro在ROS下跑orb_slam2_设备号是2bc5:050f是什么摄像头-CSDN博客
Advertisement Space (336x280)

ORB-SLAM2 在线构建稠密点云(二)_orb-slam net-CSDN博客

Ubuntu 16.04 ORB_SLAM2+ROS+kinect1+AR+rgbd数据集+三维稀疏地图+rtabmap三维稠密地图_rgbd ...

Ubuntu 20.04配置ORB-SLAM2和ORB-SLAM3运行环境+ROS实时运行ORB-SLAM+Gazebo仿真运行ORB ...

编译 ORB_SLAM2 (一)-CSDN博客
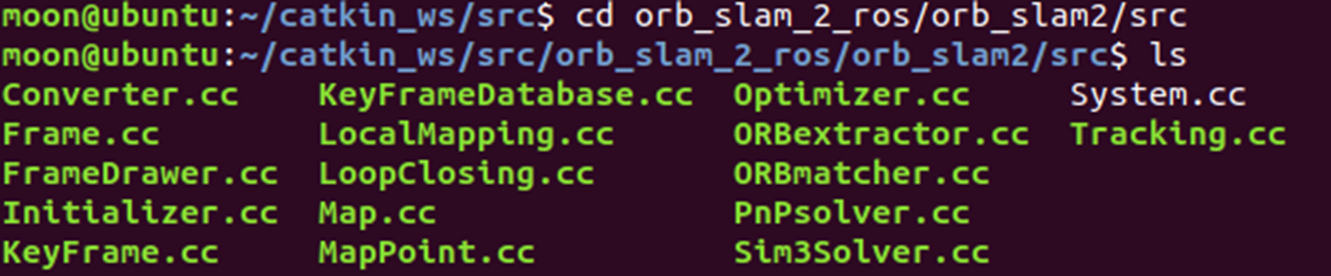
[ROS] ORB SLAM 실습

ROS下运行ORB-SLAM2双目Stereo(官方数据集)_ubuntu18运行orbslam2 ros运行数据集-CSDN博客