
Orbslam2ros Hypergraphh File Reference

orb_slam2_ros: hyper_graph.h File Reference

orb_slam2_ros: hyper_graph.h File Reference

orb_slam2_ros: sim3.h File Reference
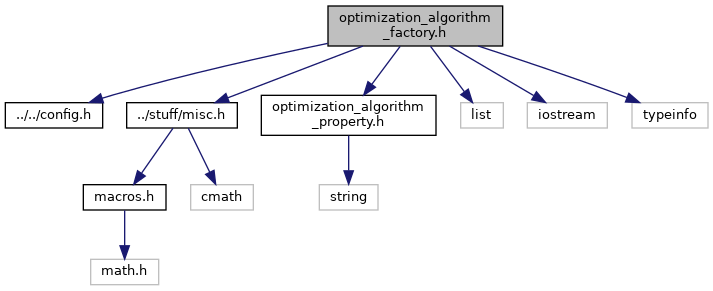
orb_slam2_ros: optimization_algorithm_factory.h File Reference

orb_slam2_ros: types_six_dof_expmap.h File Reference
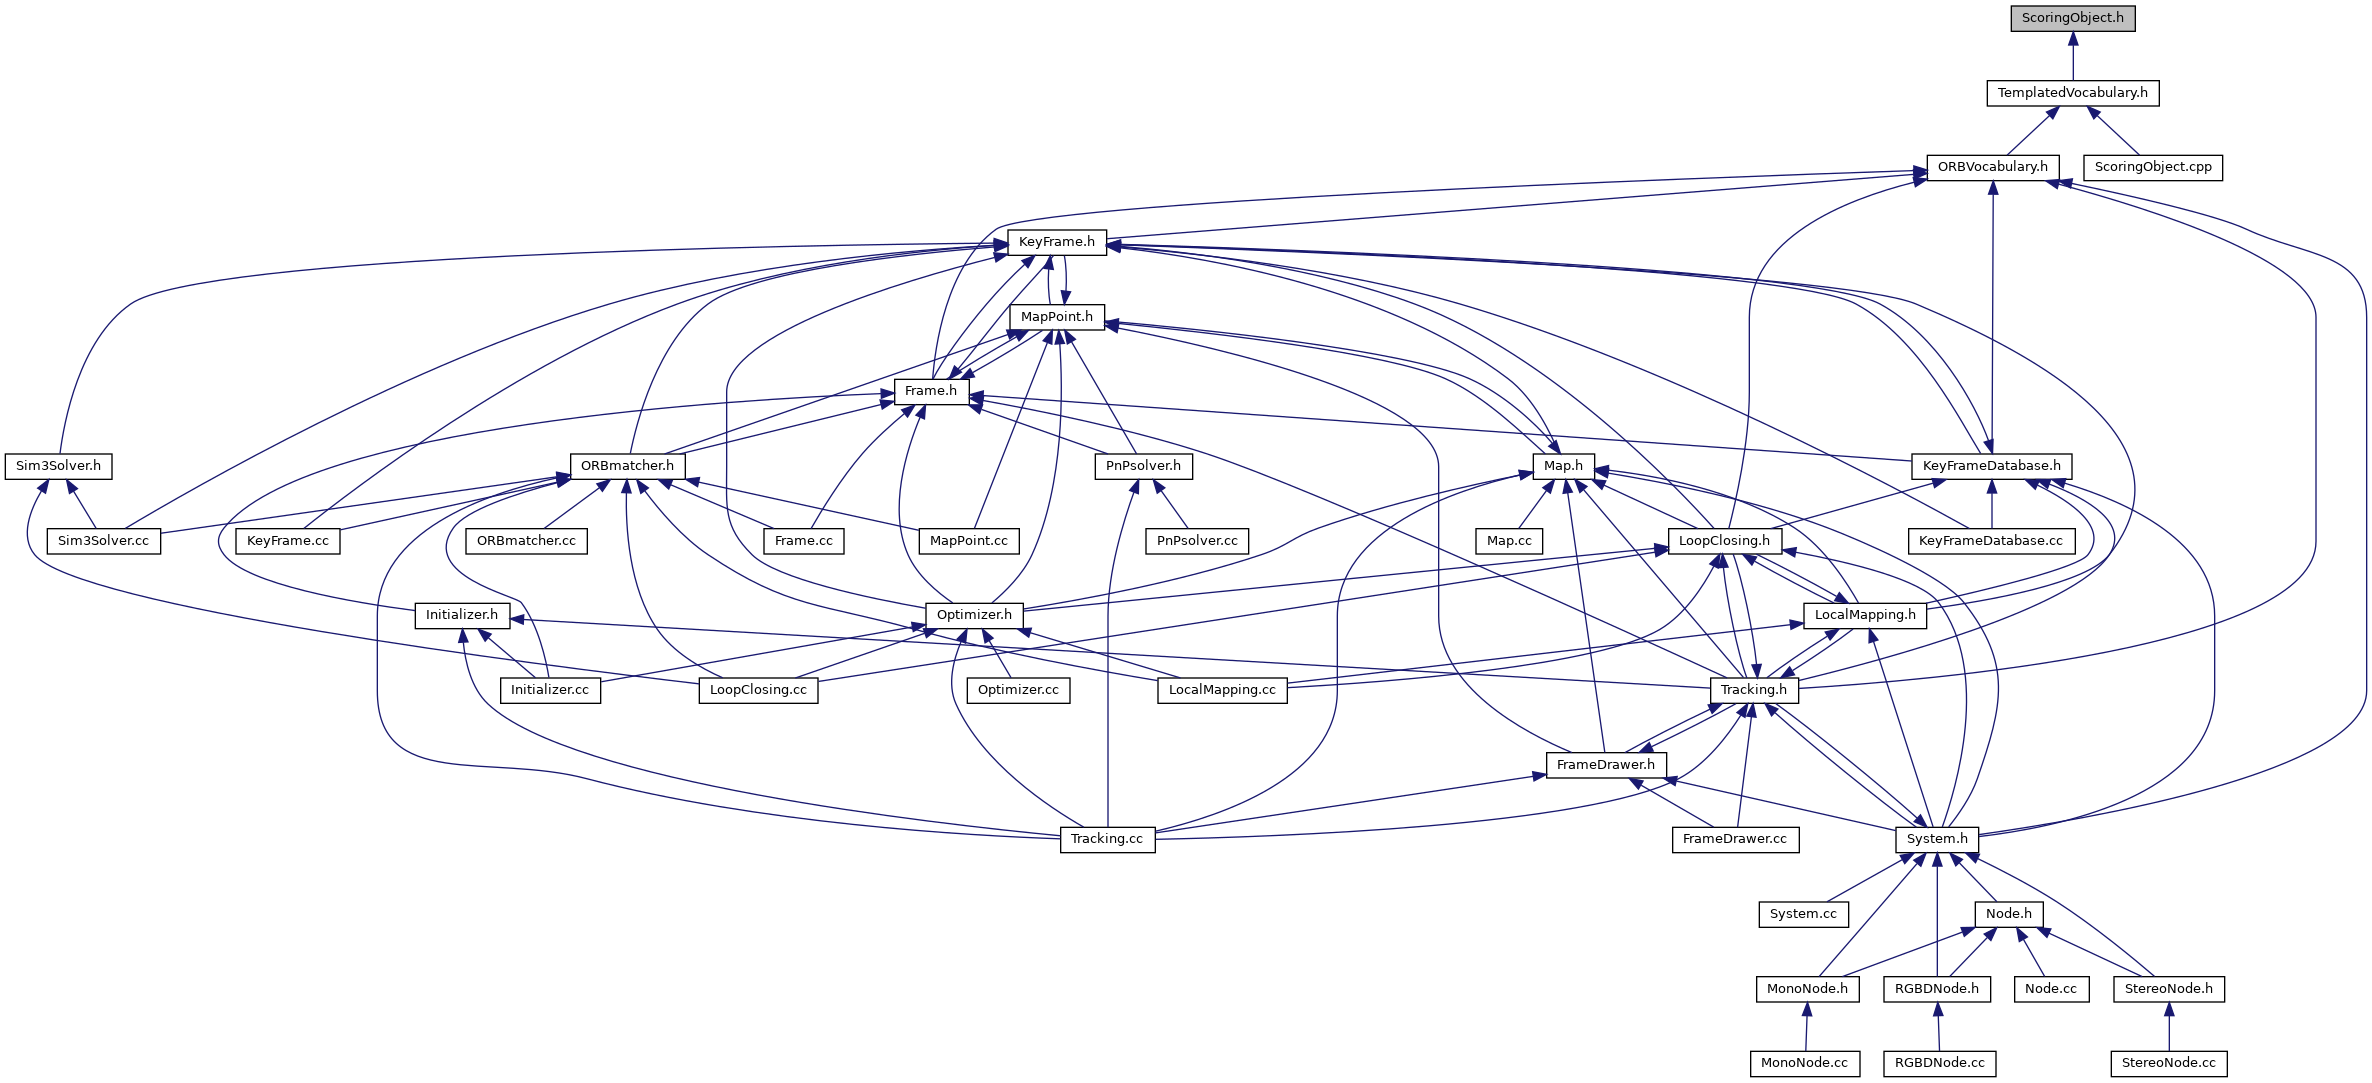
orb_slam2_ros: ScoringObject.h File Reference

orb_slam2_ros: openmp_mutex.h File Reference

orb_slam2_ros: g2o::OptimizationAlgorithmGaussNewton Class Reference

orb_slam2_ros: DBoW2::BowVector Class Reference
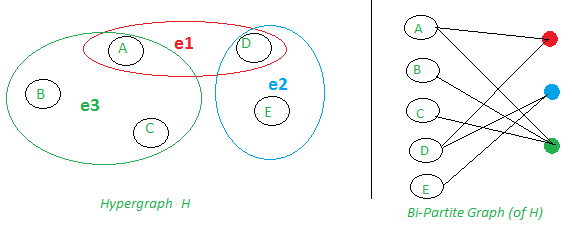
Hypergraph File Types | Hypergraph Tutorial – RPFZTW
Advertisement Space (300x250)

orb_slam2_ros: DBoW2 Directory Reference
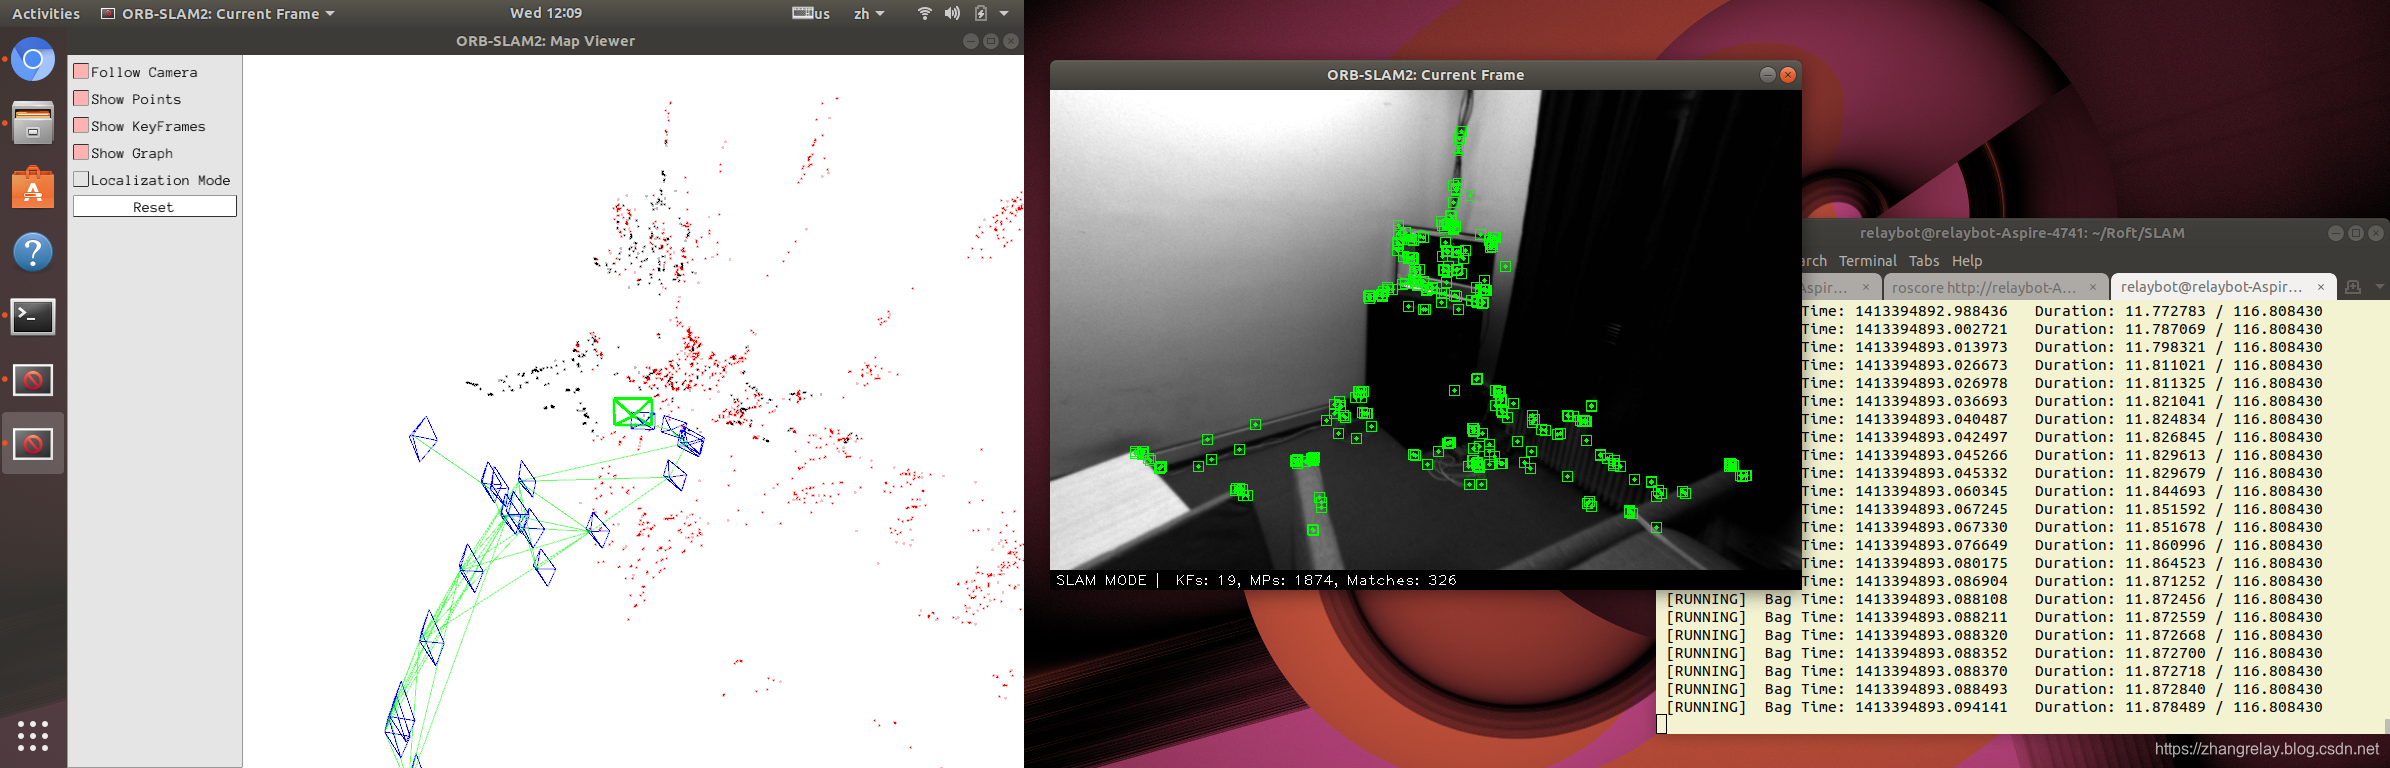
ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)_ros 2 slam 算法研究-CSDN博客
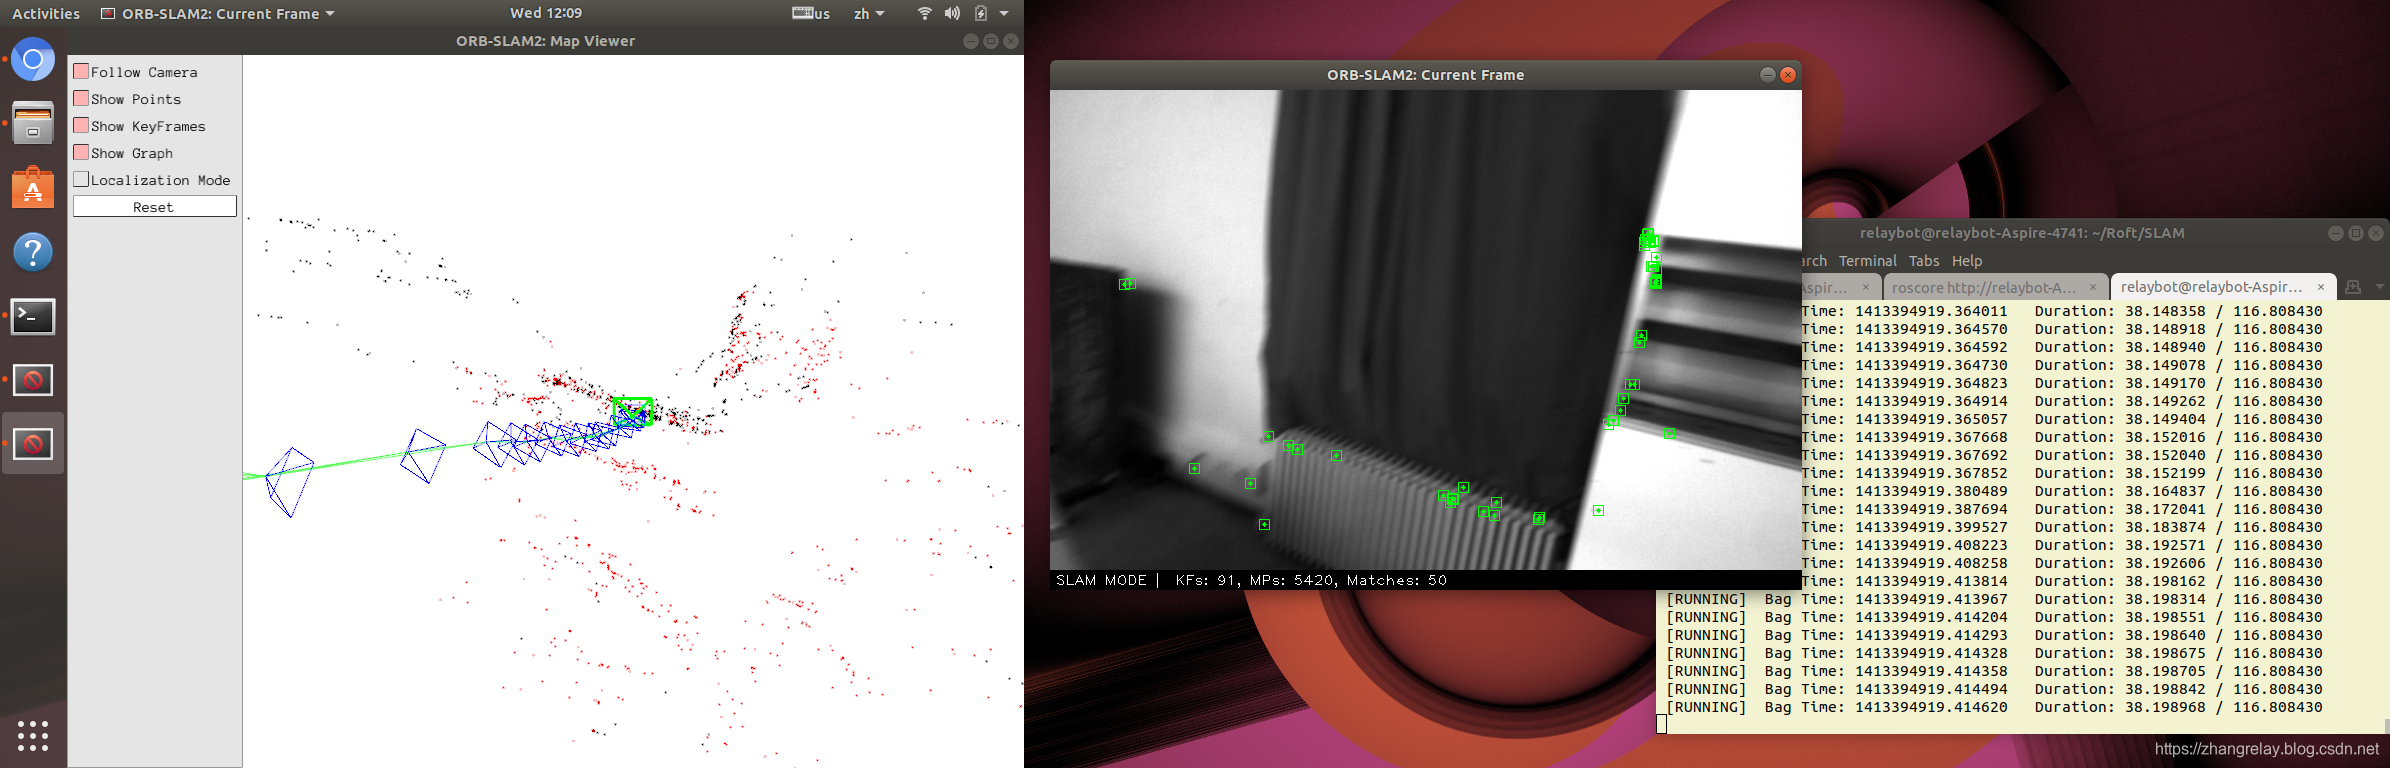
ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)_ros 2 slam 算法研究-CSDN博客

Block diagram of the ORB-SLAM2 algorithm. | Download Scientific Diagram

ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)-腾讯云开发者社区-腾讯云

【记录】ORB_SLAM2 例程(README文件里的单双目RDB-D、ROS、AR、外接摄像头、点云)_orbslam2运行双目数据集-CSDN博客
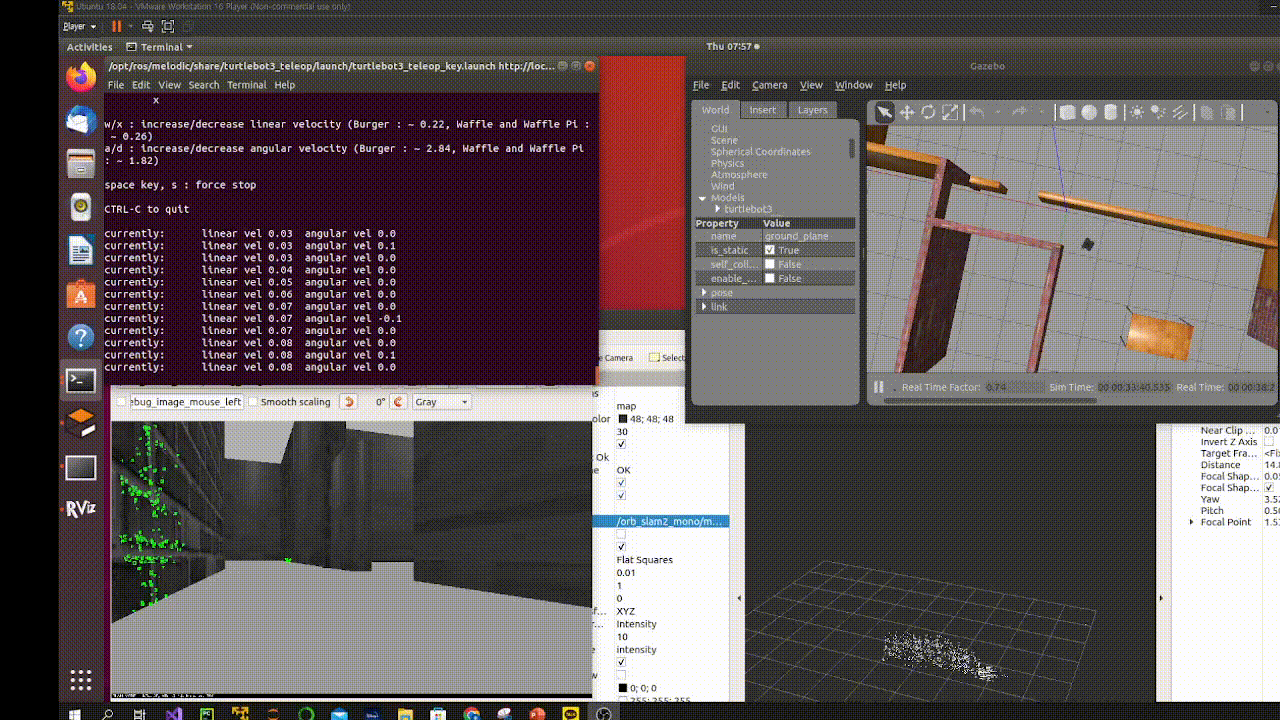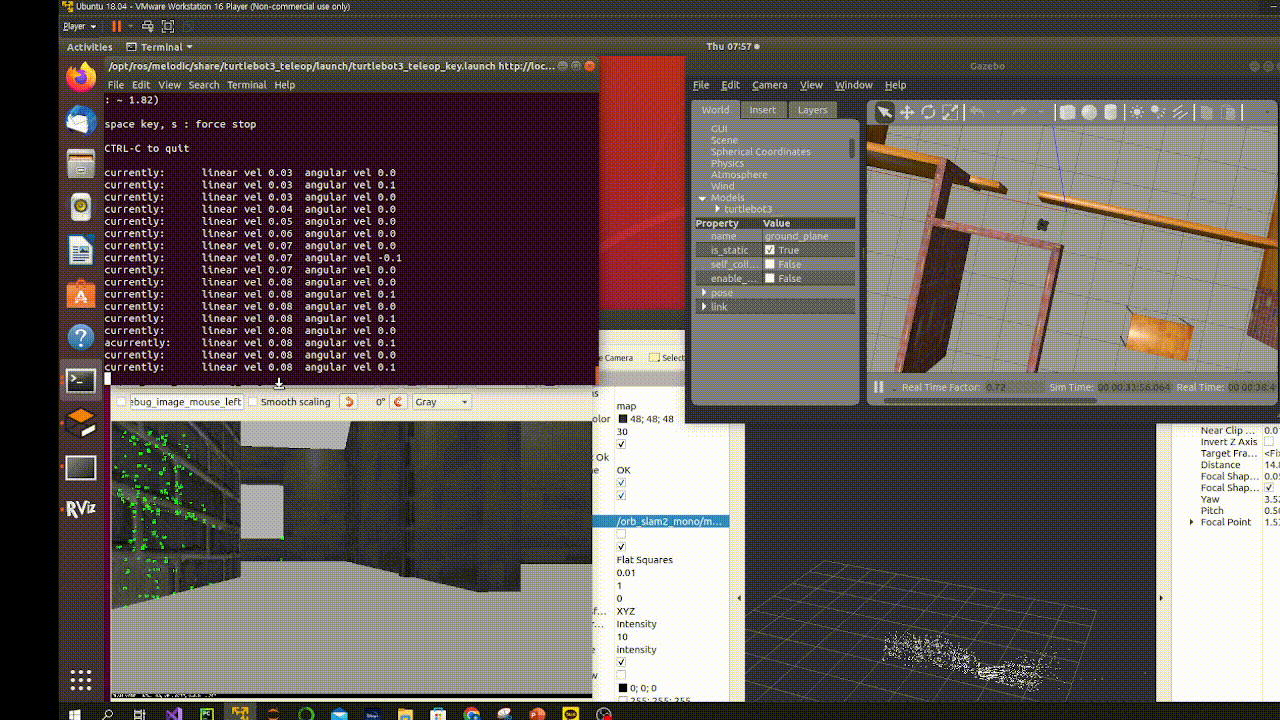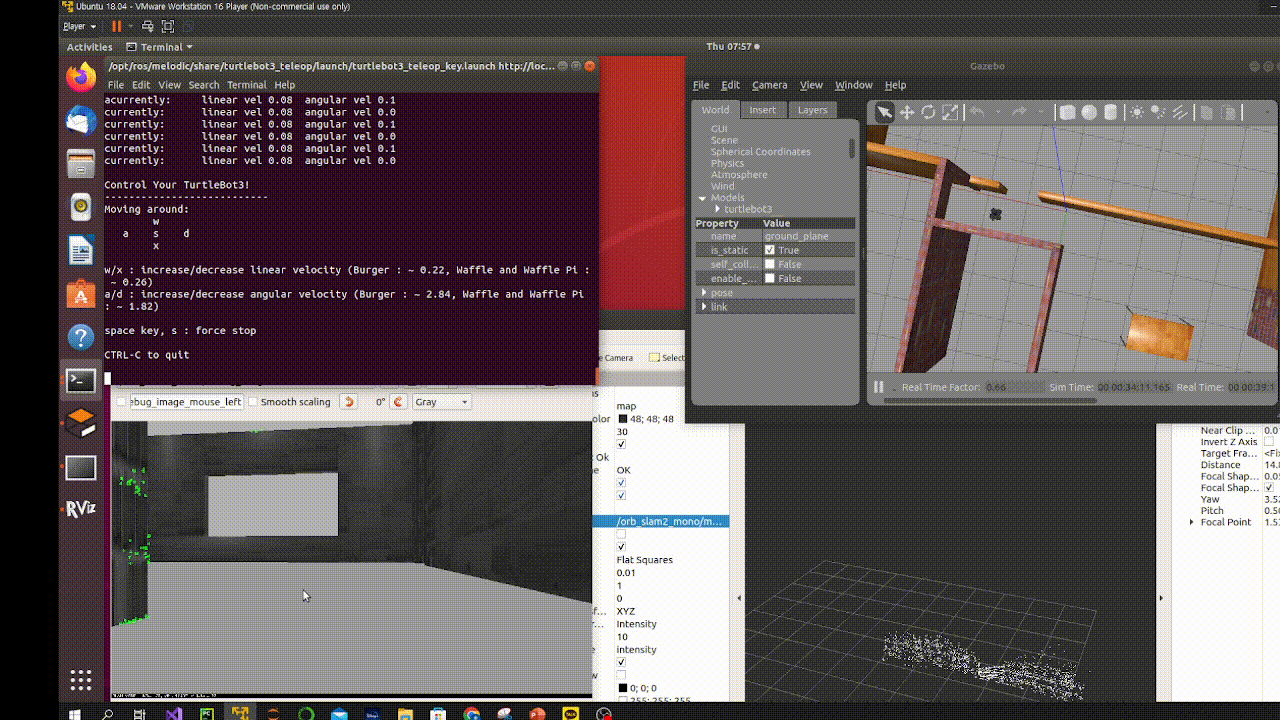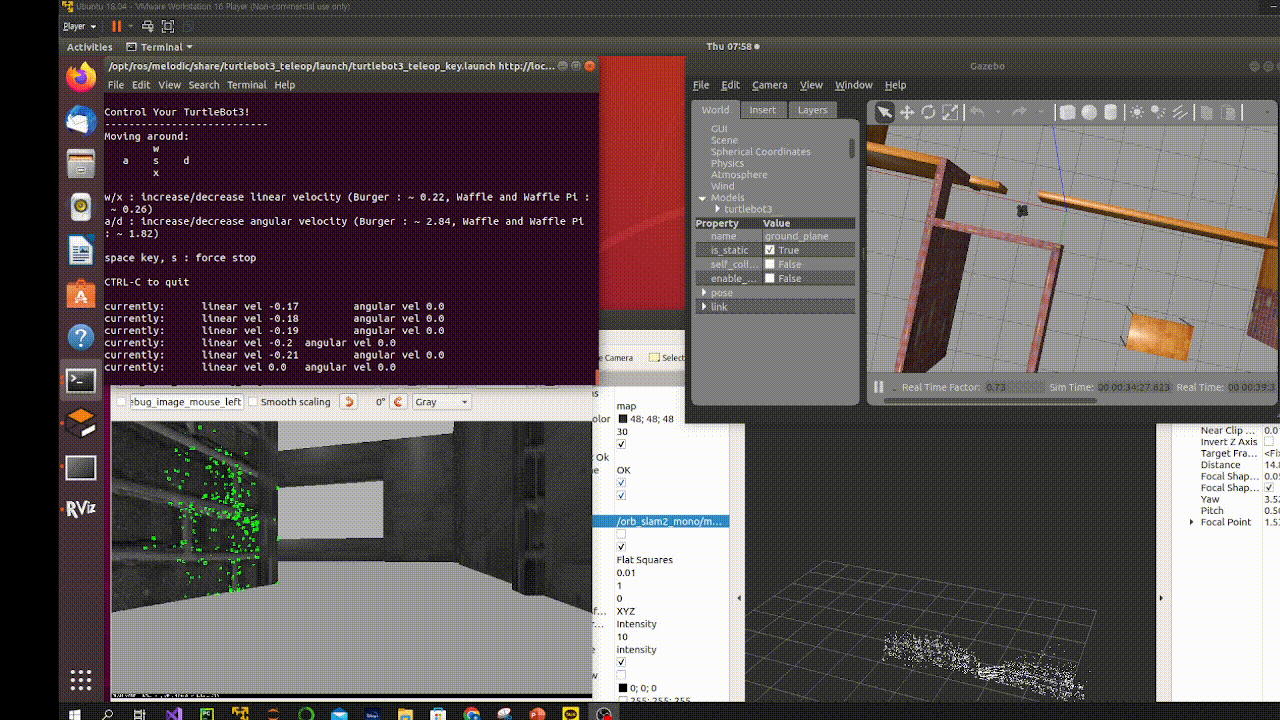
[ROS] ORB SLAM 실습

【SLAM】在 ubuntu 18.04 arm 中以ROS环境编译与运行ORB_SLAM3 - 技术栈
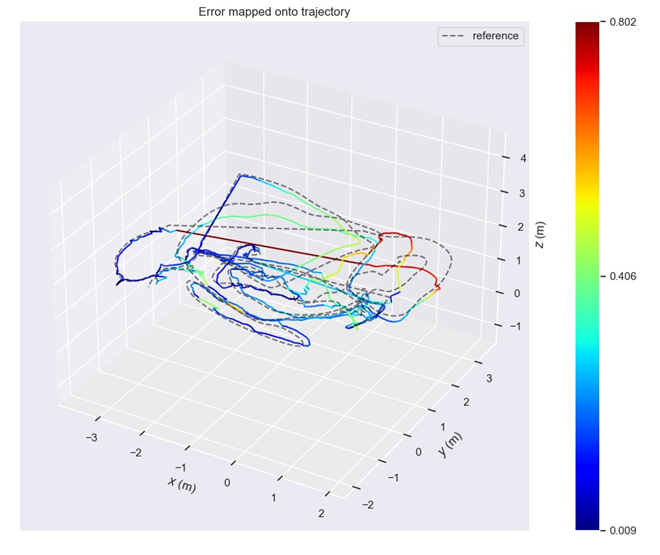
GitHub - YifanWang3744/My-Improved-ORB-SLAM2: In this project, I ...
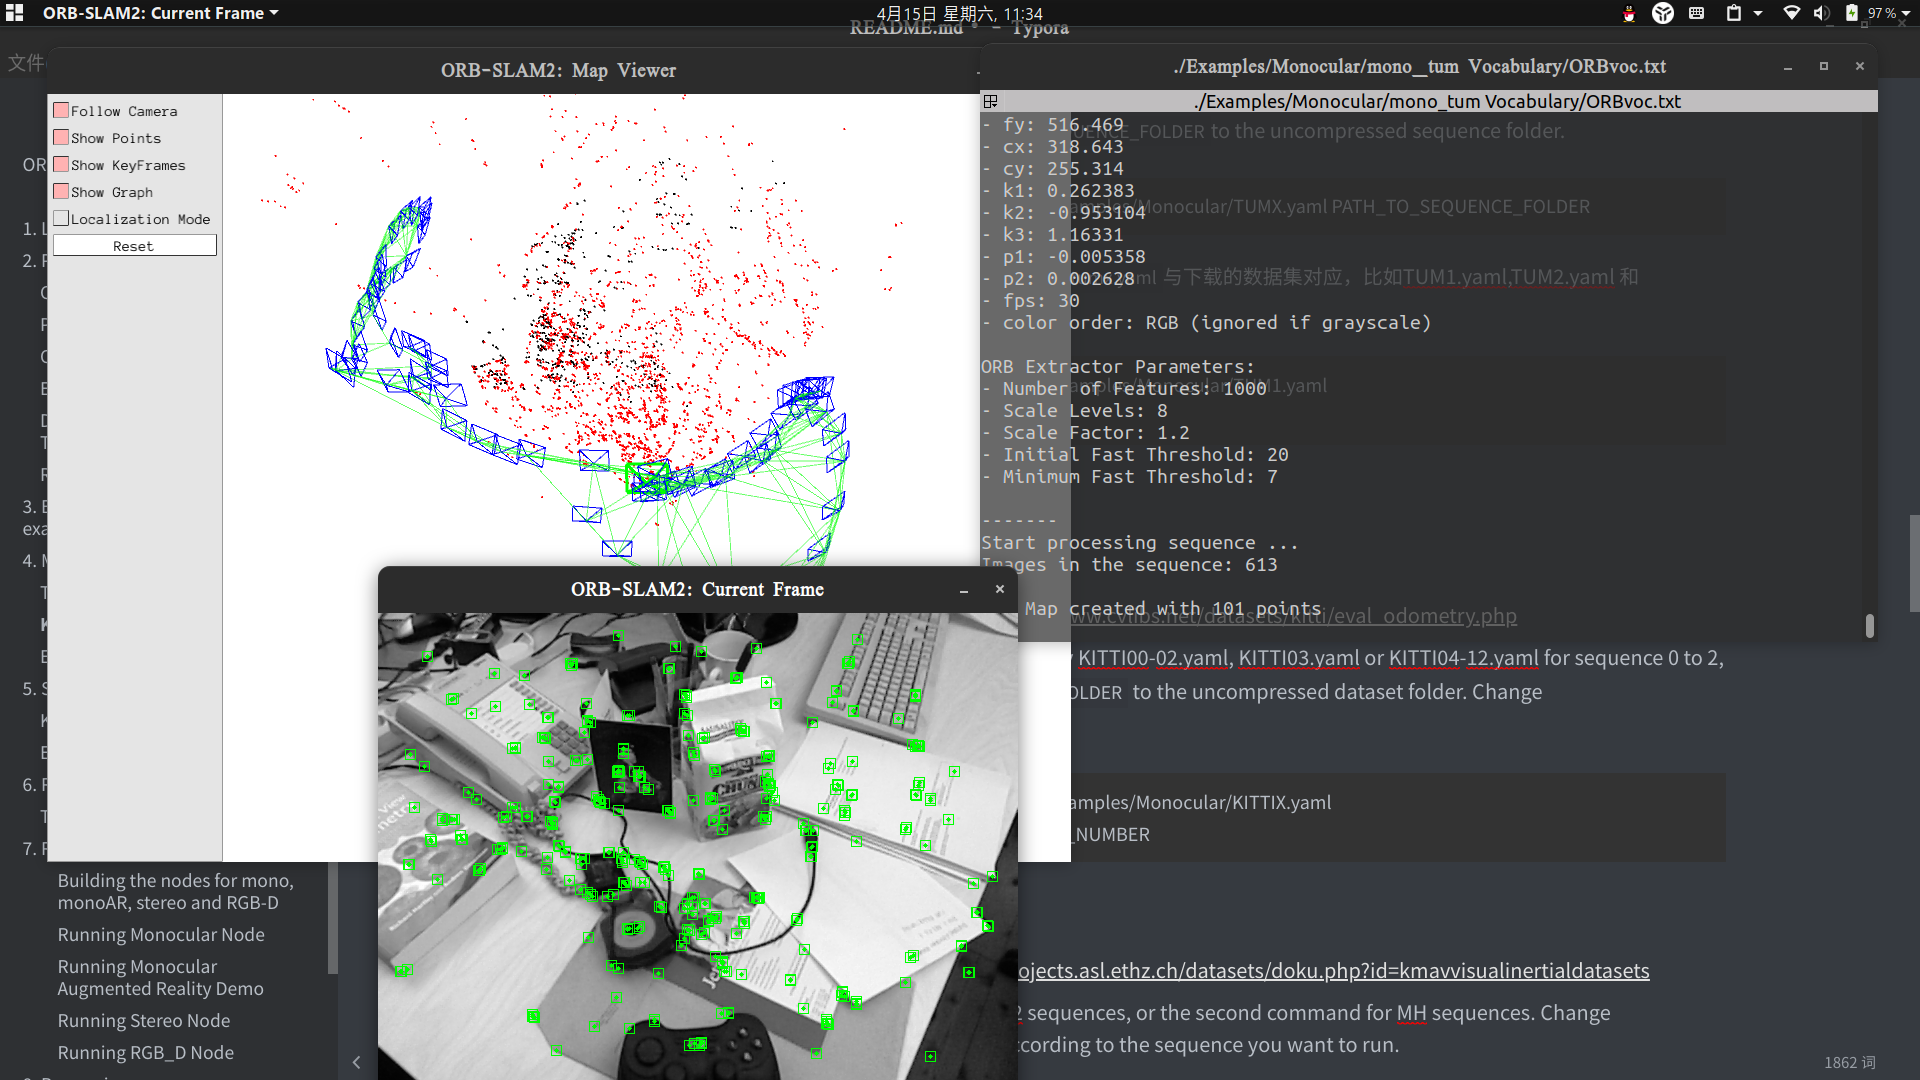
【记录】ORB_SLAM2 例程(README文件里的单双目RDB-D、ROS、AR、外接摄像头、点云)_orbslam2运行双目数据集-CSDN博客
Advertisement Space (336x280)

ROS2学习和使用SLAM算法(gmapping/cartographer/orb-slam等)_ros 2 slam 算法研究-CSDN博客

ORB-SLAM2环境配置及运行_orbslam2环境配置-CSDN博客

slam - Problem with Stereo ORB SLAM2 in ROS Creating Strange ...
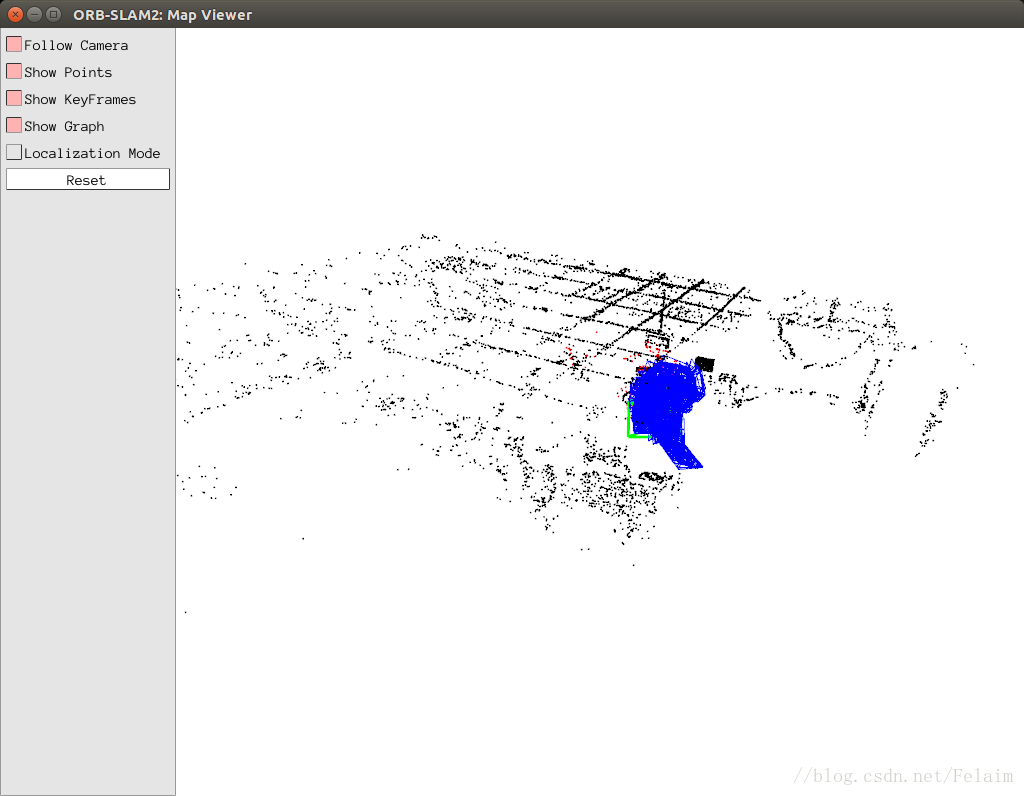
ROS(三):使用ROS跑通ORB_SLAM2_ros orbslam2-CSDN博客

ORB-SLAM2论文详解_orbslam2-CSDN博客

GitHub - HyeonJaeGil/orbslam2-ros: ready-to-use implementation of ORB ...

【SLAM】在 ubuntu 18.04 arm 中以ROS环境编译与运行ORB_SLAM3_orbslam3 ros-CSDN博客
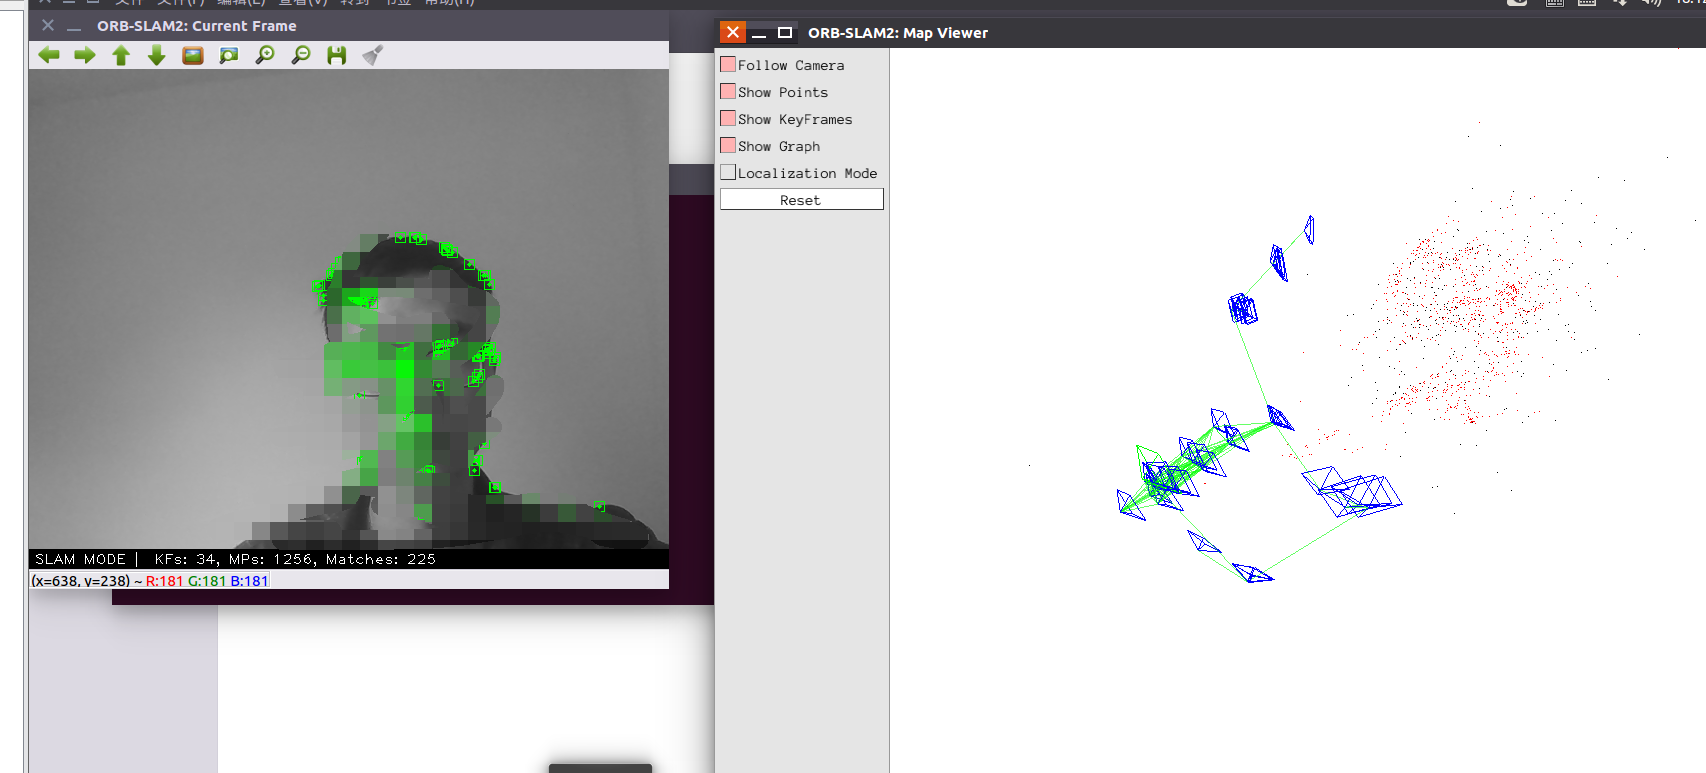
Run ORB-SLAM2 in real time under ROS - Programmer Sought

5.ORB_SLAM2 basics
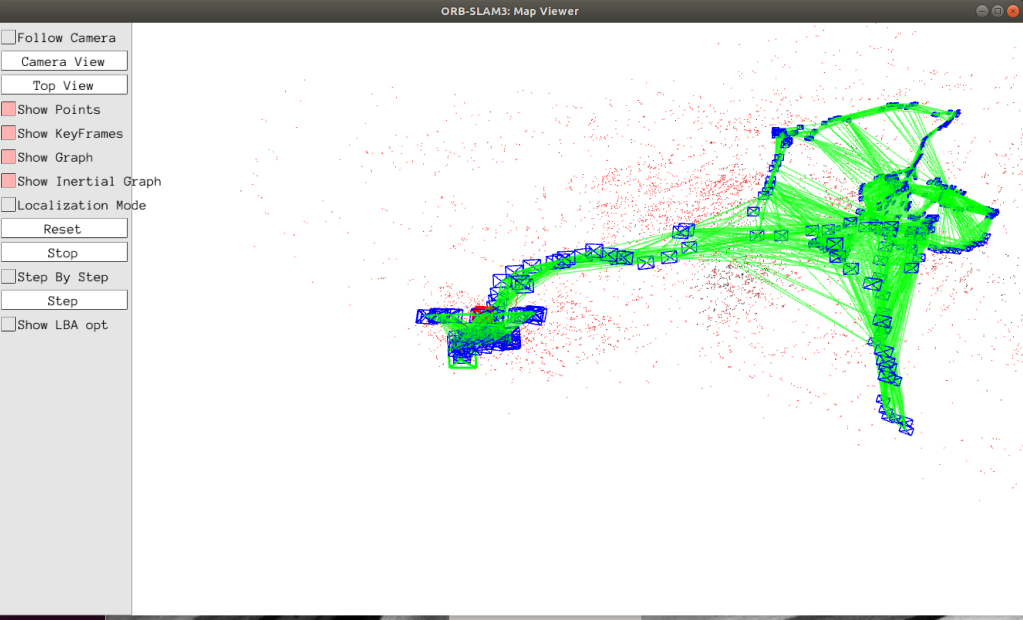
ORB_SLAM3 + ROS采坑实录 - 倔强小R - 博客园
Advertisement Space (336x280)
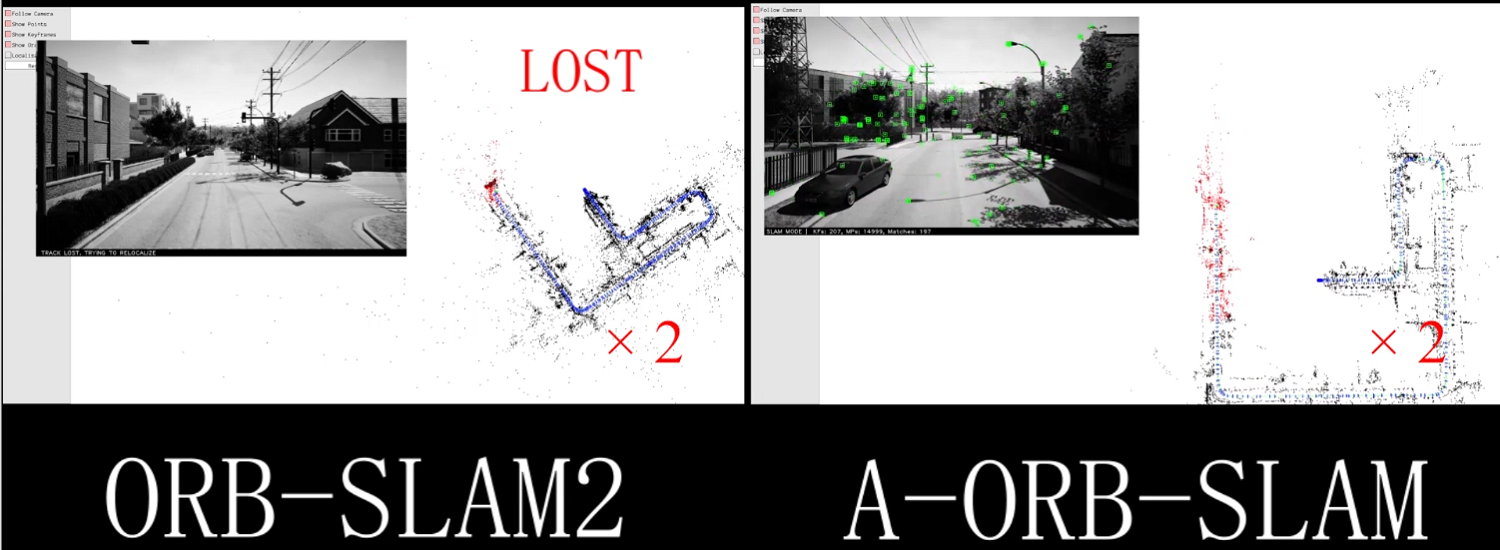
ImageMatchingBenchmark
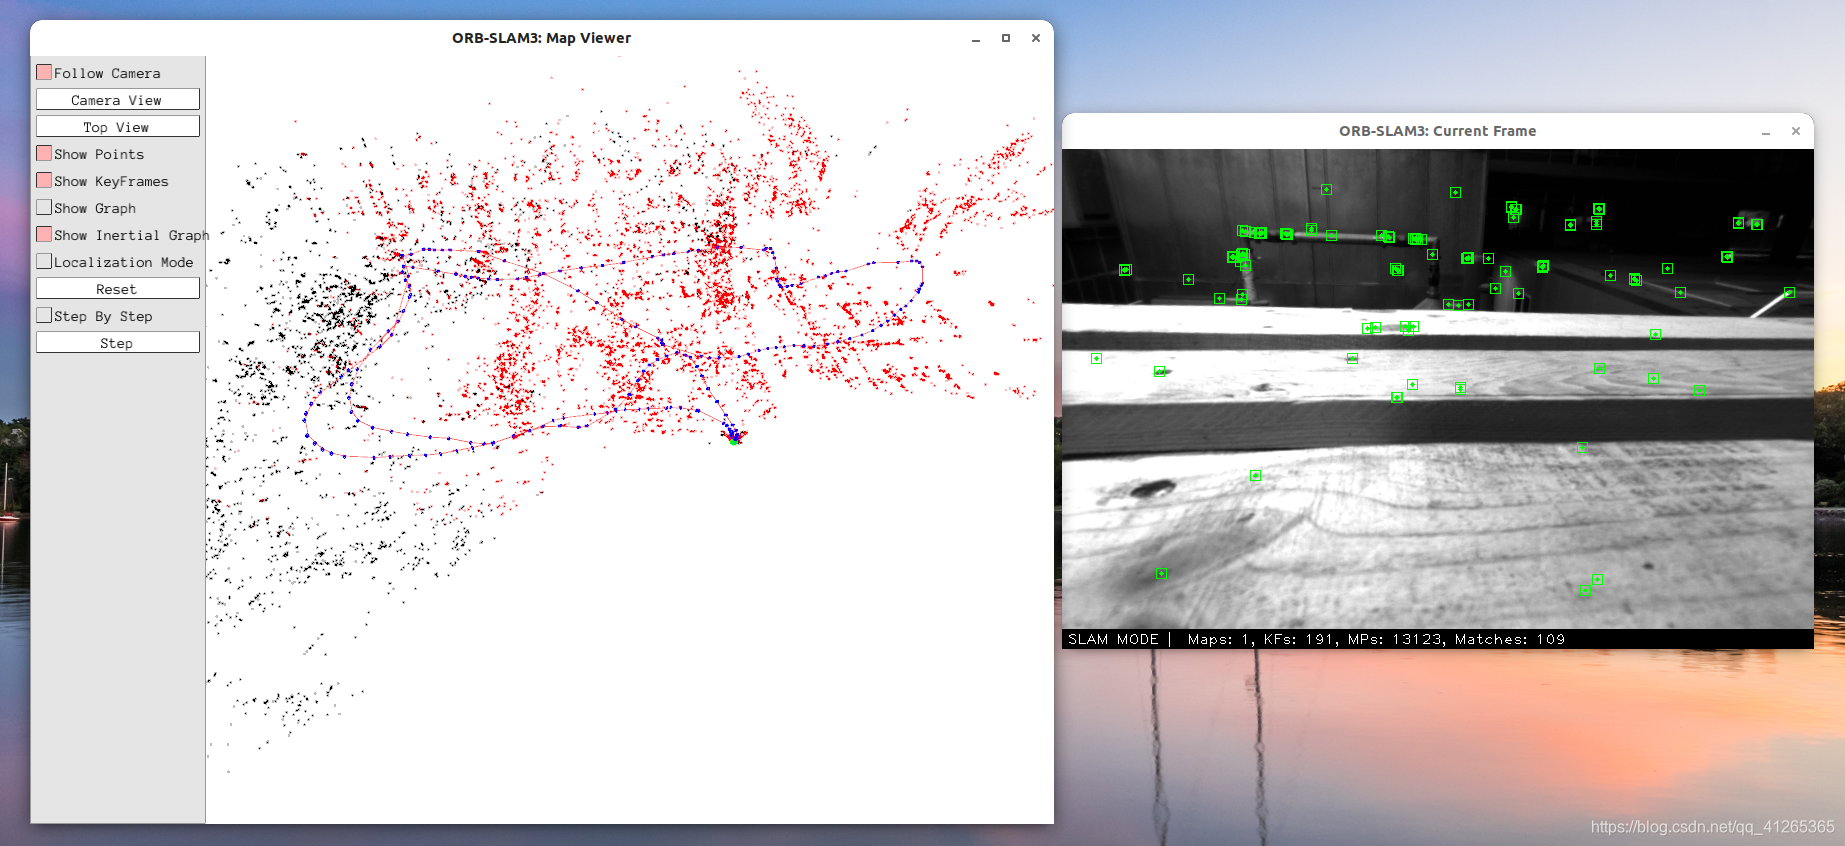
ORB-SLAM3 ROS 运行_orbslam3 ros-CSDN博客
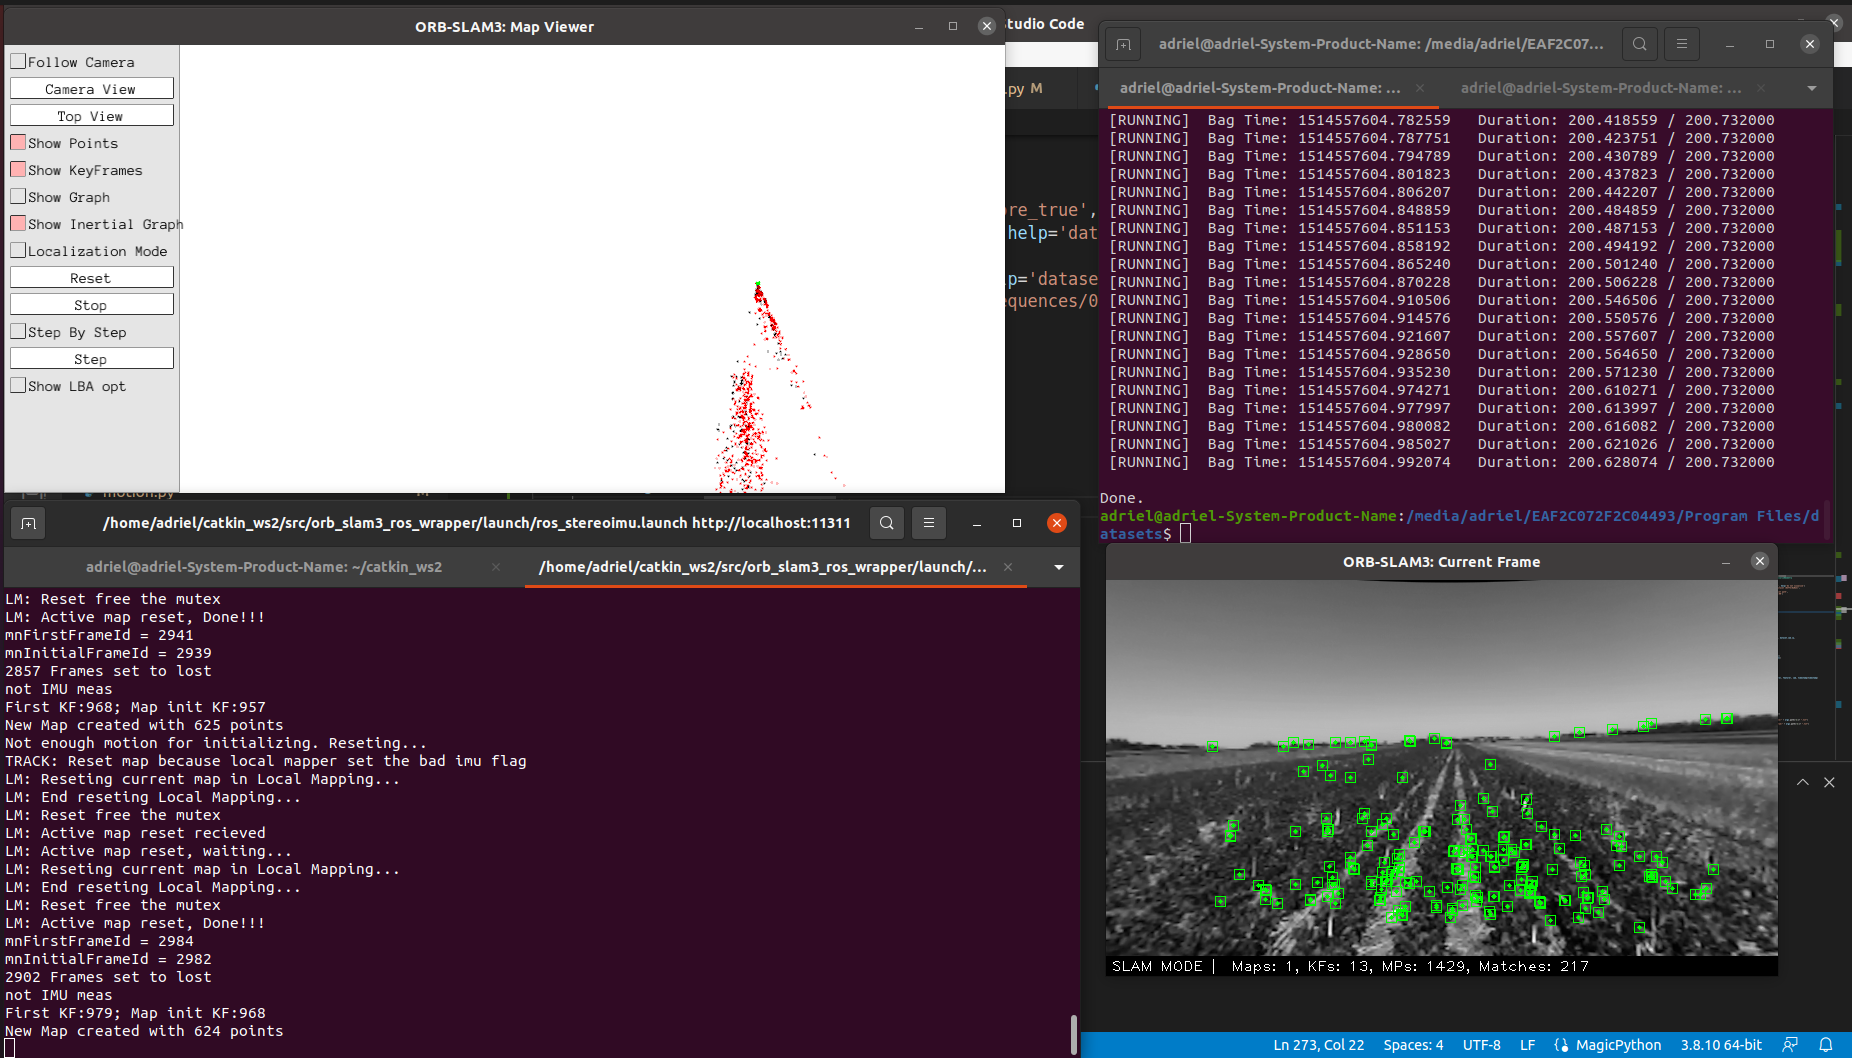
Problem trying to reproduce ORB-SLAM results in Rosario dataset · Issue ...

Ubuntu 20.04配置ORB-SLAM2和ORB-SLAM3运行环境+ROS实时运行ORB-SLAM+Gazebo仿真运行ORB ...

GitHub - lturing/ORB_SLAM3_ROS · GitHub

5.ORB_SLAM2 basics