
Paper Page Dro Grasp A Unified Representation Of Robot And Object

Paper page - D(R,O) Grasp: A Unified Representation of Robot and Object ...

Object Grasp Control of a 3D Robot Arm by Combining EOG Gaze Estimation ...

Object Grasp Control of a 3D Robot Arm by Combining EOG Gaze Estimation ...

Object Grasp Control of a 3D Robot Arm by Combining EOG Gaze Estimation ...

(PDF) Integrated grasp planning and visual object localization for a ...

Figure 2 from A Unified Knowledge Representation System for Robot ...
UniT: Unified Tactile Representation for Robot Learning - Paper Details

Illustration of manipulating one group object per a grasping time by ...
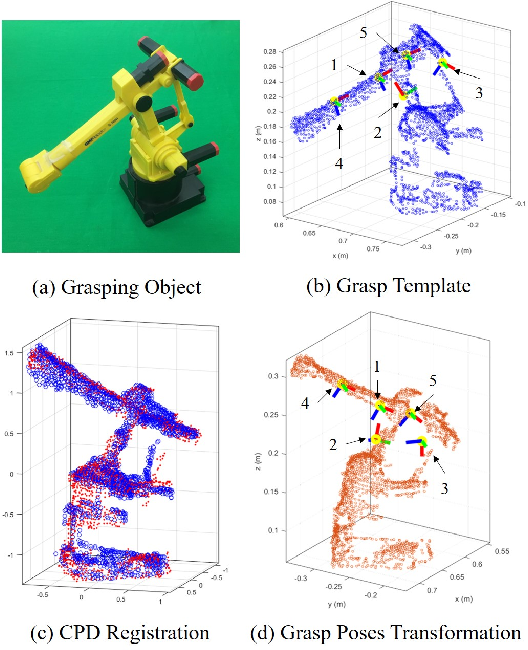
Figure 1 from A Framework for Robot Grasp Transferring with Non-rigid ...

Robot Grasp Planning: A Learning from Demonstration-Based Approach
Advertisement Space (300x250)

Robot Grasp Planning: A Learning from Demonstration-Based Approach

(PDF) UniGrasp: Learning a Unified Model to Grasp With Multifingered ...

Robot Grasp Planning: A Learning from Demonstration-Based Approach
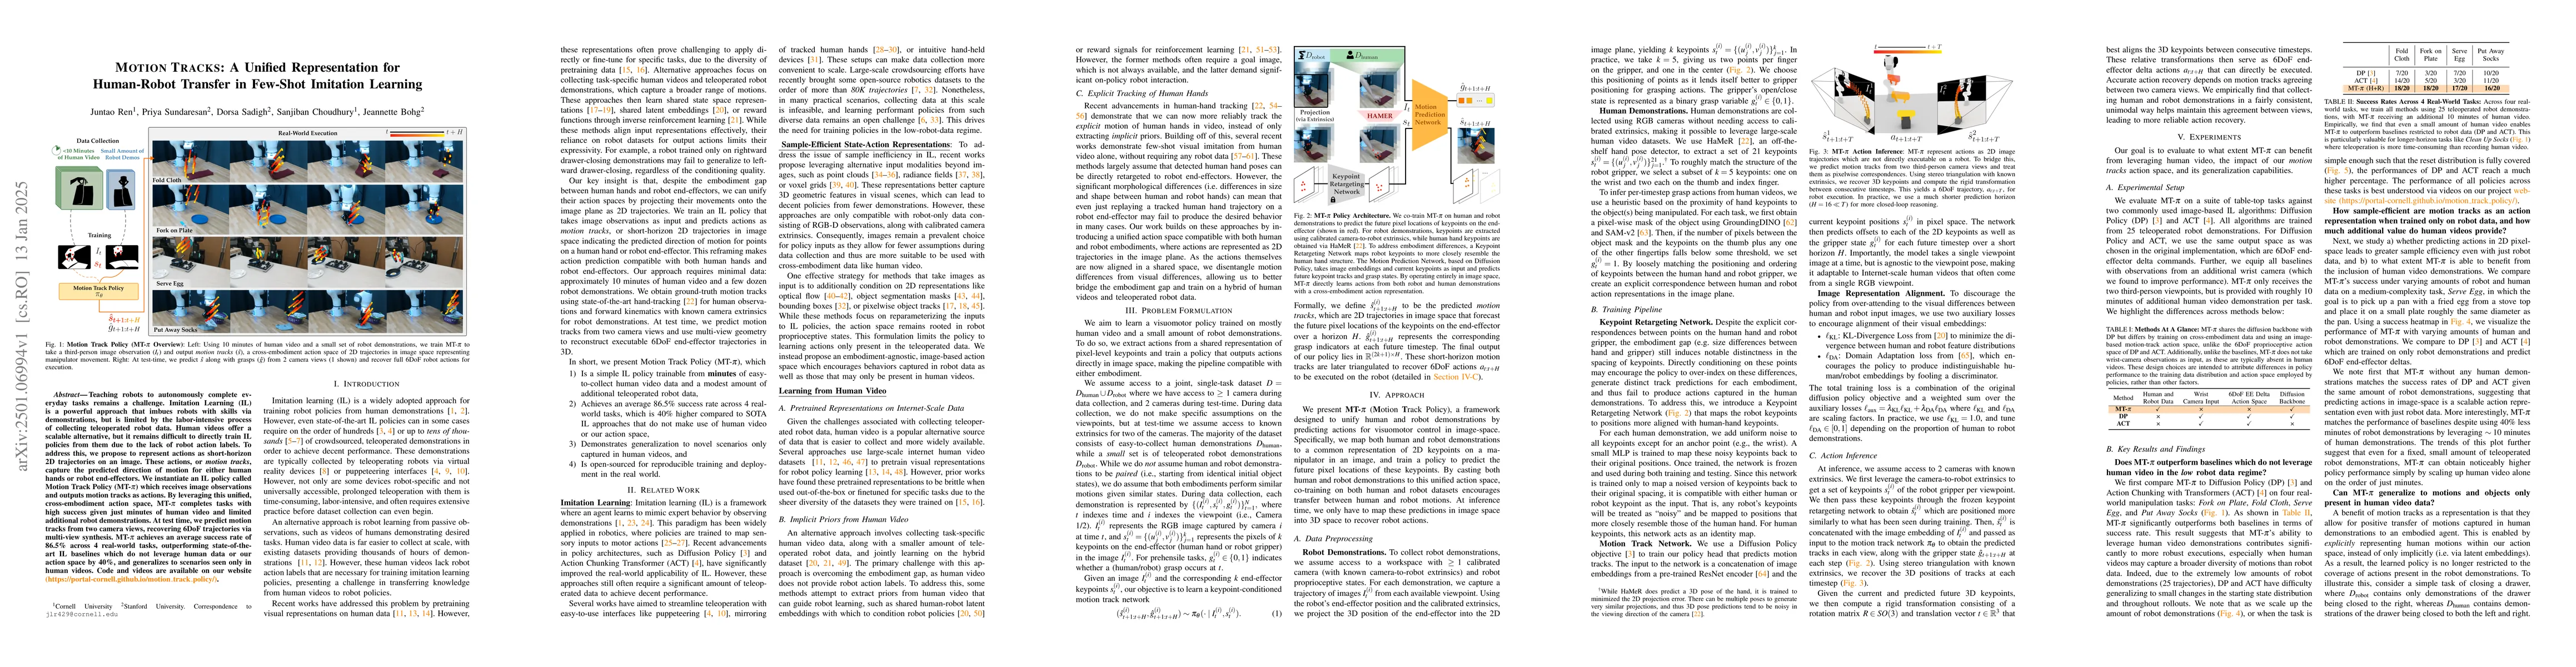
Motion Tracks: A Unified Representation for Human-Robot Transfer in Few ...

Robot Grasp Planning: A Learning from Demonstration-Based Approach

[论文评述] UniCoD: Enhancing Robot Policy via Unified Continuous and ...

Planning To Grasp and Position An Object For Forceful Human-Robot ...
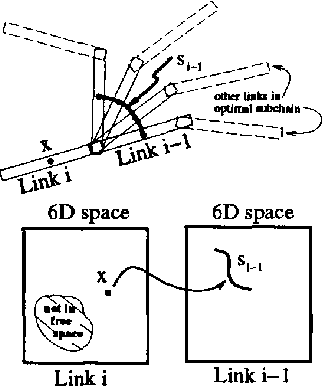
Figure 2 from Planning grasps for a robot hand in the presence of ...

Figure 1 from Simultaneous Object Reconstruction and Grasp Prediction ...

GitHub - zhenyuwei2003/DRO-Grasp: Official code repository of paper "D ...
Advertisement Space (336x280)

Illustration of the robot grasping the target object, where Og is the ...
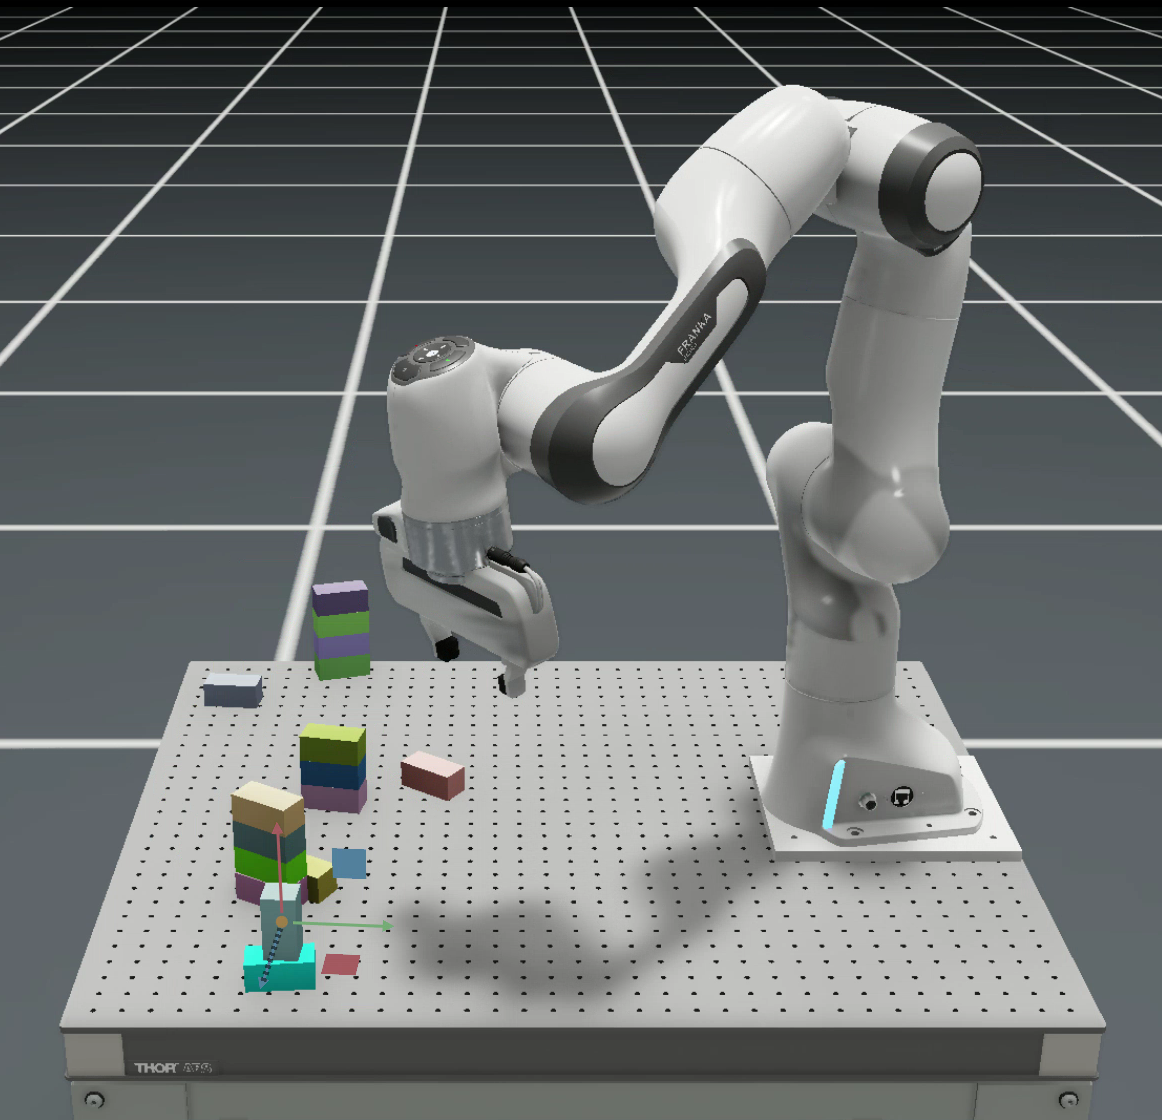
[2301.04195] Orbit: A Unified Simulation Framework for Interactive ...
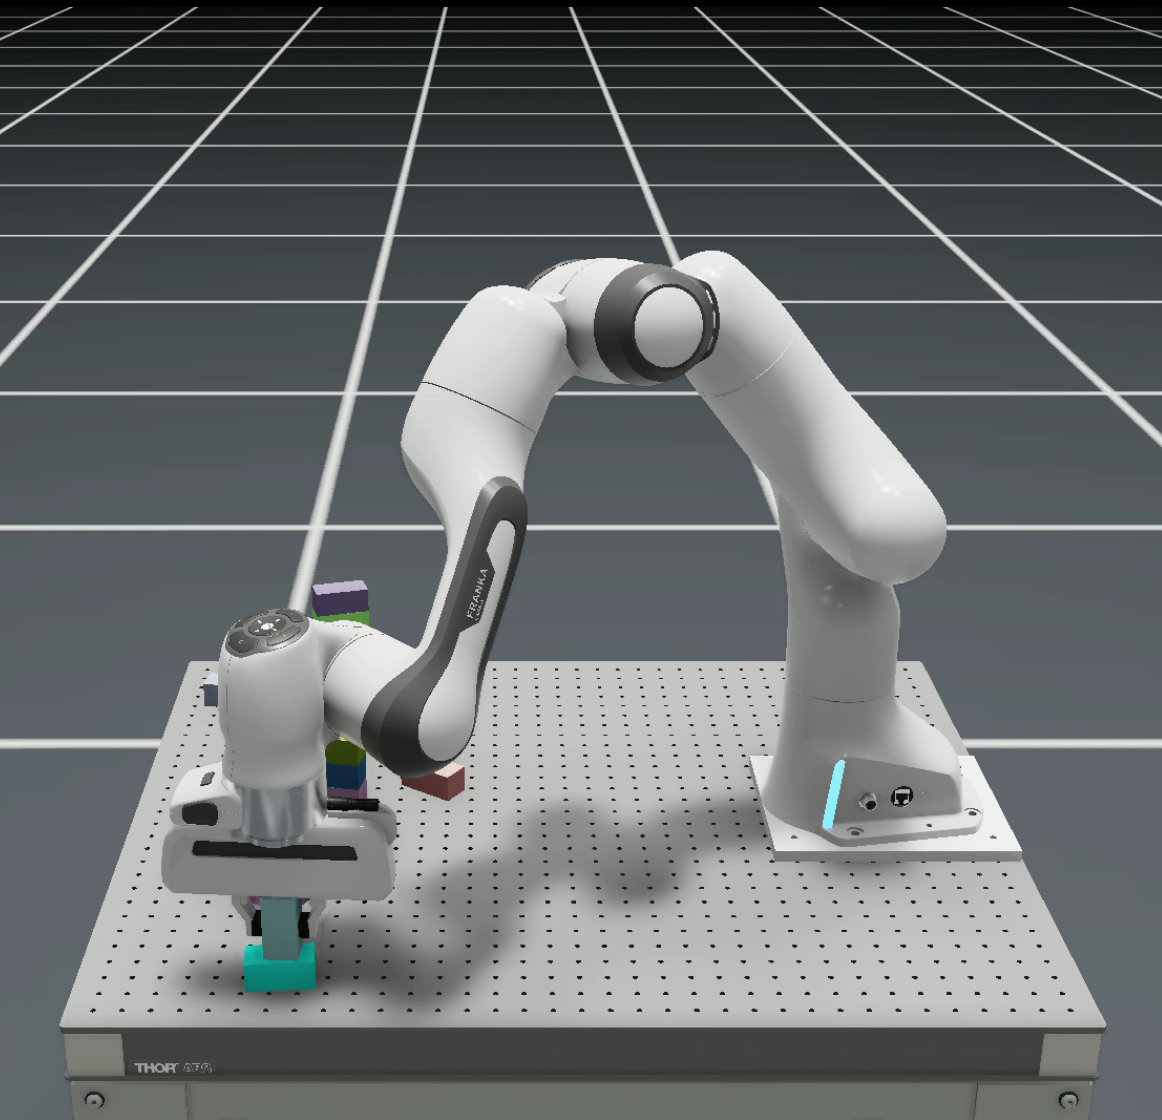
[2301.04195] Orbit: A Unified Simulation Framework for Interactive ...

Object Recognition and Grasping for Collaborative Robots Based on Vision
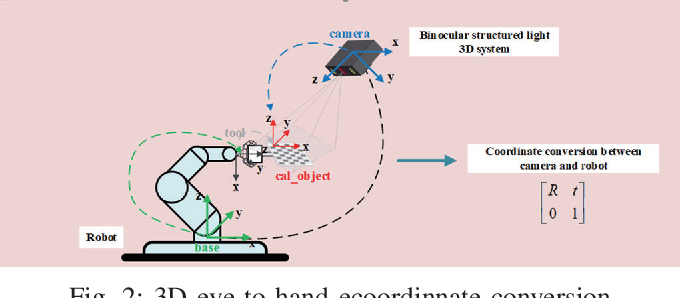
Figure 2 from 3D Eye-to-Hand Coordination for Uninstructed Robot Grasp ...

Human grasps are recognized and mapped to a robot. From one video ...

Figure 1 from Robot Grasp with Multi-object Detection based on RGB-D ...

(PDF) A skeleton-based approach to grasp known objects with a humanoid ...

Figure 2 from Robot Grasp with Multi-object Detection based on RGB-D ...
GitHub - zhenyuwei2003/DRO-Grasp: Official code repository of paper "D ...
Advertisement Space (336x280)
(PDF) Planning grasps for robotic hands using a novel object ...
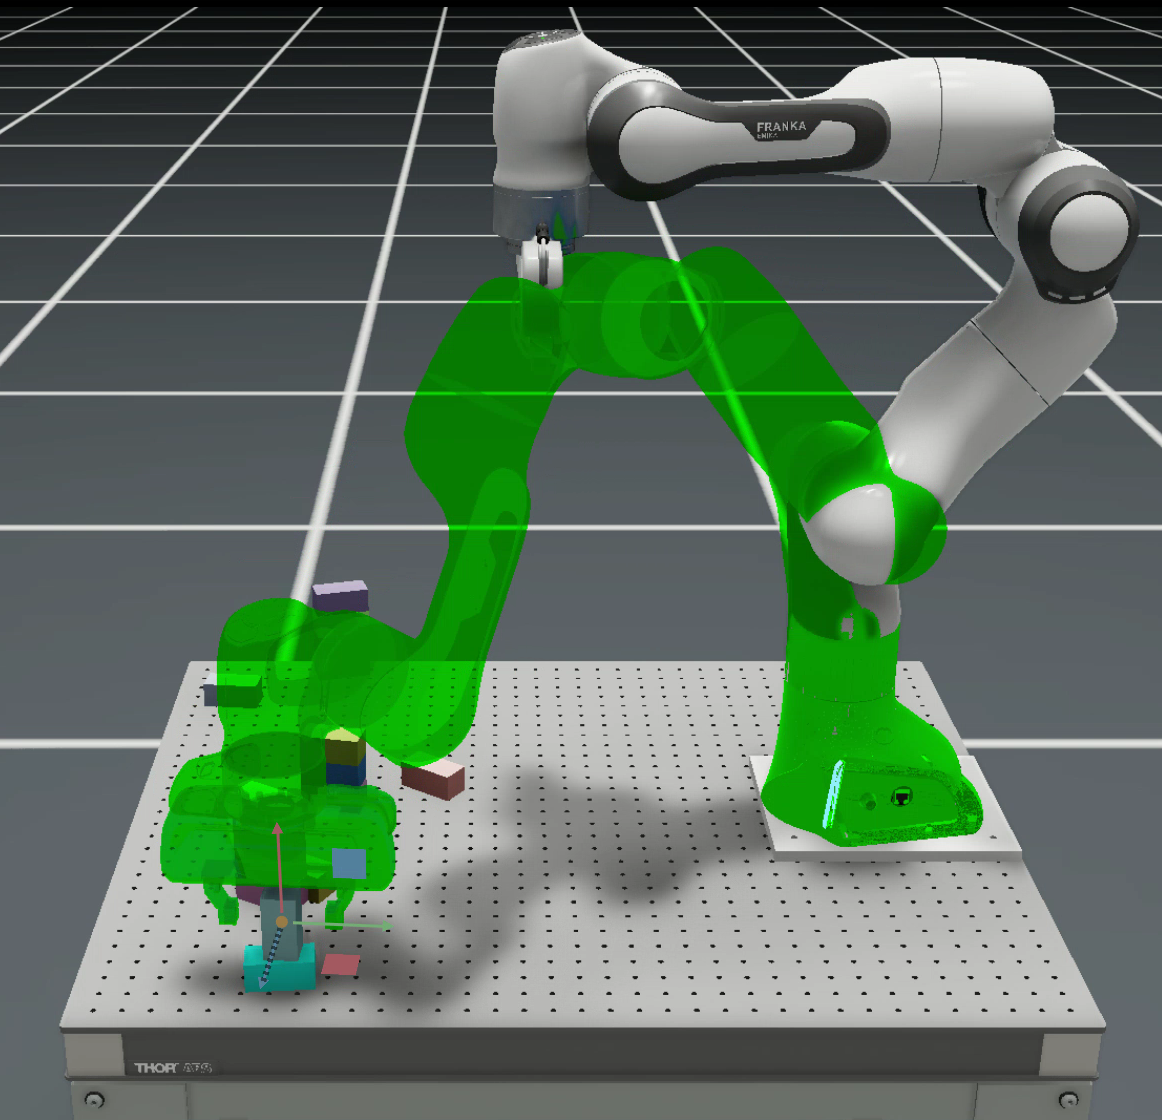
[2301.04195] Orbit: A Unified Simulation Framework for Interactive ...

| Examples of object grasping using the UR5 robot. In each subfigure ...

[Literature Review] Grasp Synthesis Matching From Rigid To Soft Robot ...
3DSGrasp: 3D Shape-Completion for Robotic Grasp | AI Research Paper Details

UniFucGrasp: Human-Hand-Inspired Unified Functional Grasp Annotation ...