
Ros2control Jazzy Hardwareinterfacesensorinterface Class Reference
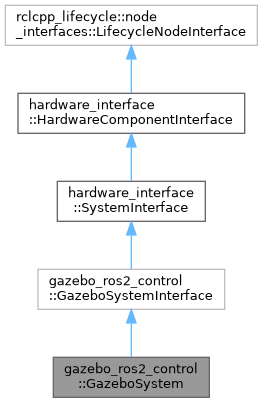
ros2_control - jazzy: gazebo_ros2_control::GazeboSystem Class Reference
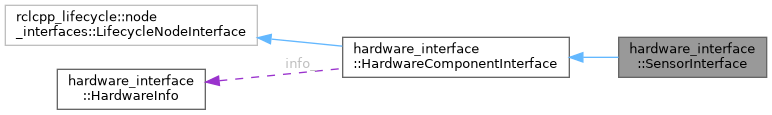
ros2_control - jazzy: hardware_interface::SensorInterface Class Reference
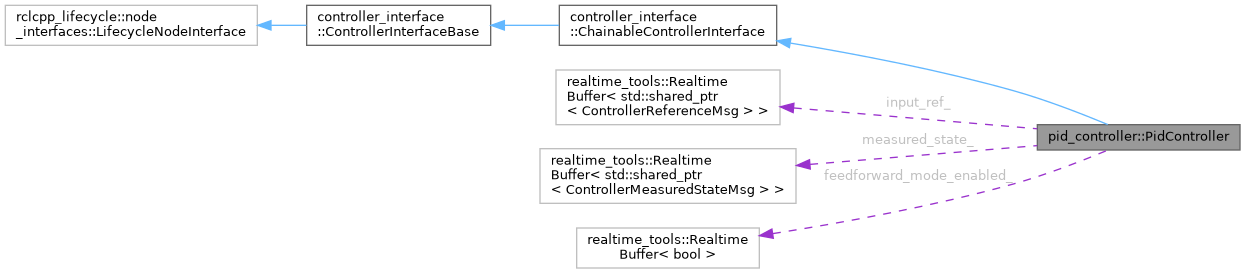
ros2_control - jazzy: pid_controller::PidController Class Reference
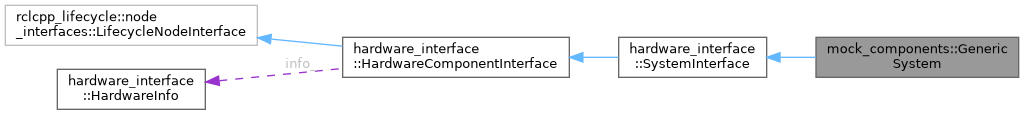
ros2_control - jazzy: mock_components::GenericSystem Class Reference
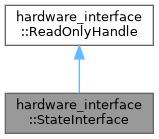
ros2_control - foxy: hardware_interface::StateInterface Class Reference
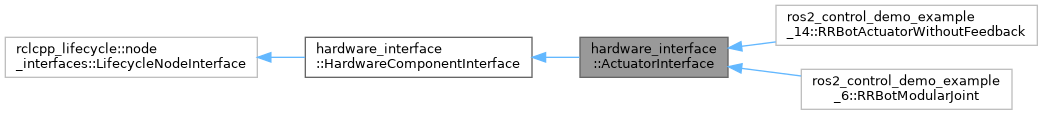
ros2_control - jazzy: hardware_interface::ActuatorInterface Class Reference
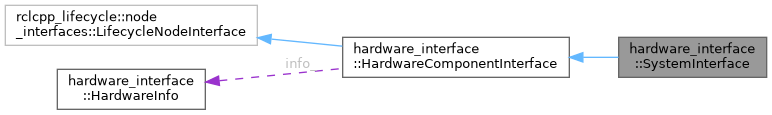
ros2_control - jazzy: hardware_interface::SystemInterface Class Reference

ros2_control - rolling: hardware_interface::Handle Class Reference
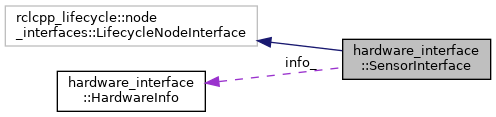
ros2_control - rolling: hardware_interface::SensorInterface Class Reference
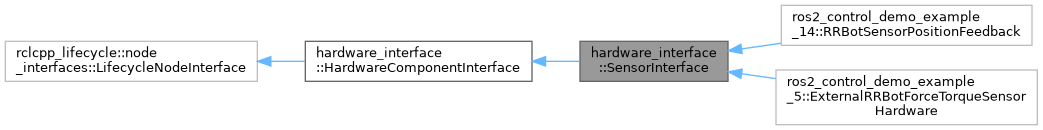
ros2_control - jazzy: hardware_interface::SensorInterface Class Reference
Advertisement Space (300x250)

ROS 2 rclcpp + rcl - jazzy: rclcpp::Executor Class Reference
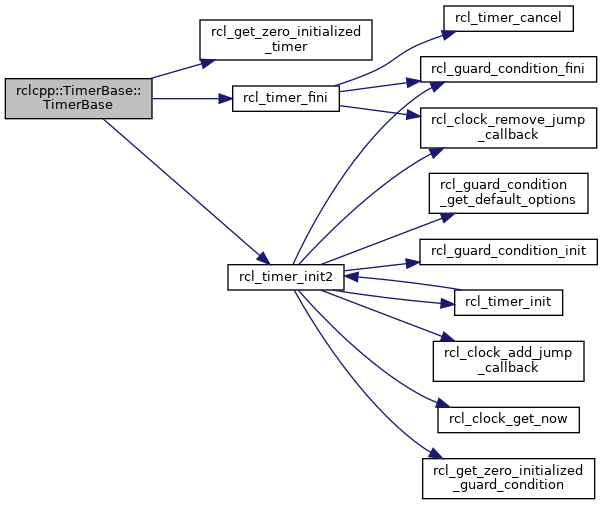
ROS 2 rclcpp + rcl - jazzy: rclcpp::TimerBase Class Reference
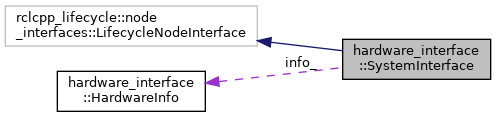
ros2_control - humble: hardware_interface::SystemInterface Class Reference

ROS 2 rclcpp + rcl - jazzy: rclcpp::Executor Class Reference
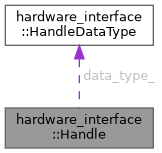
ros2_control - rolling: hardware_interface::Handle Class Reference

Resources — ROS2_Control: Jazzy Oct 2025 documentation
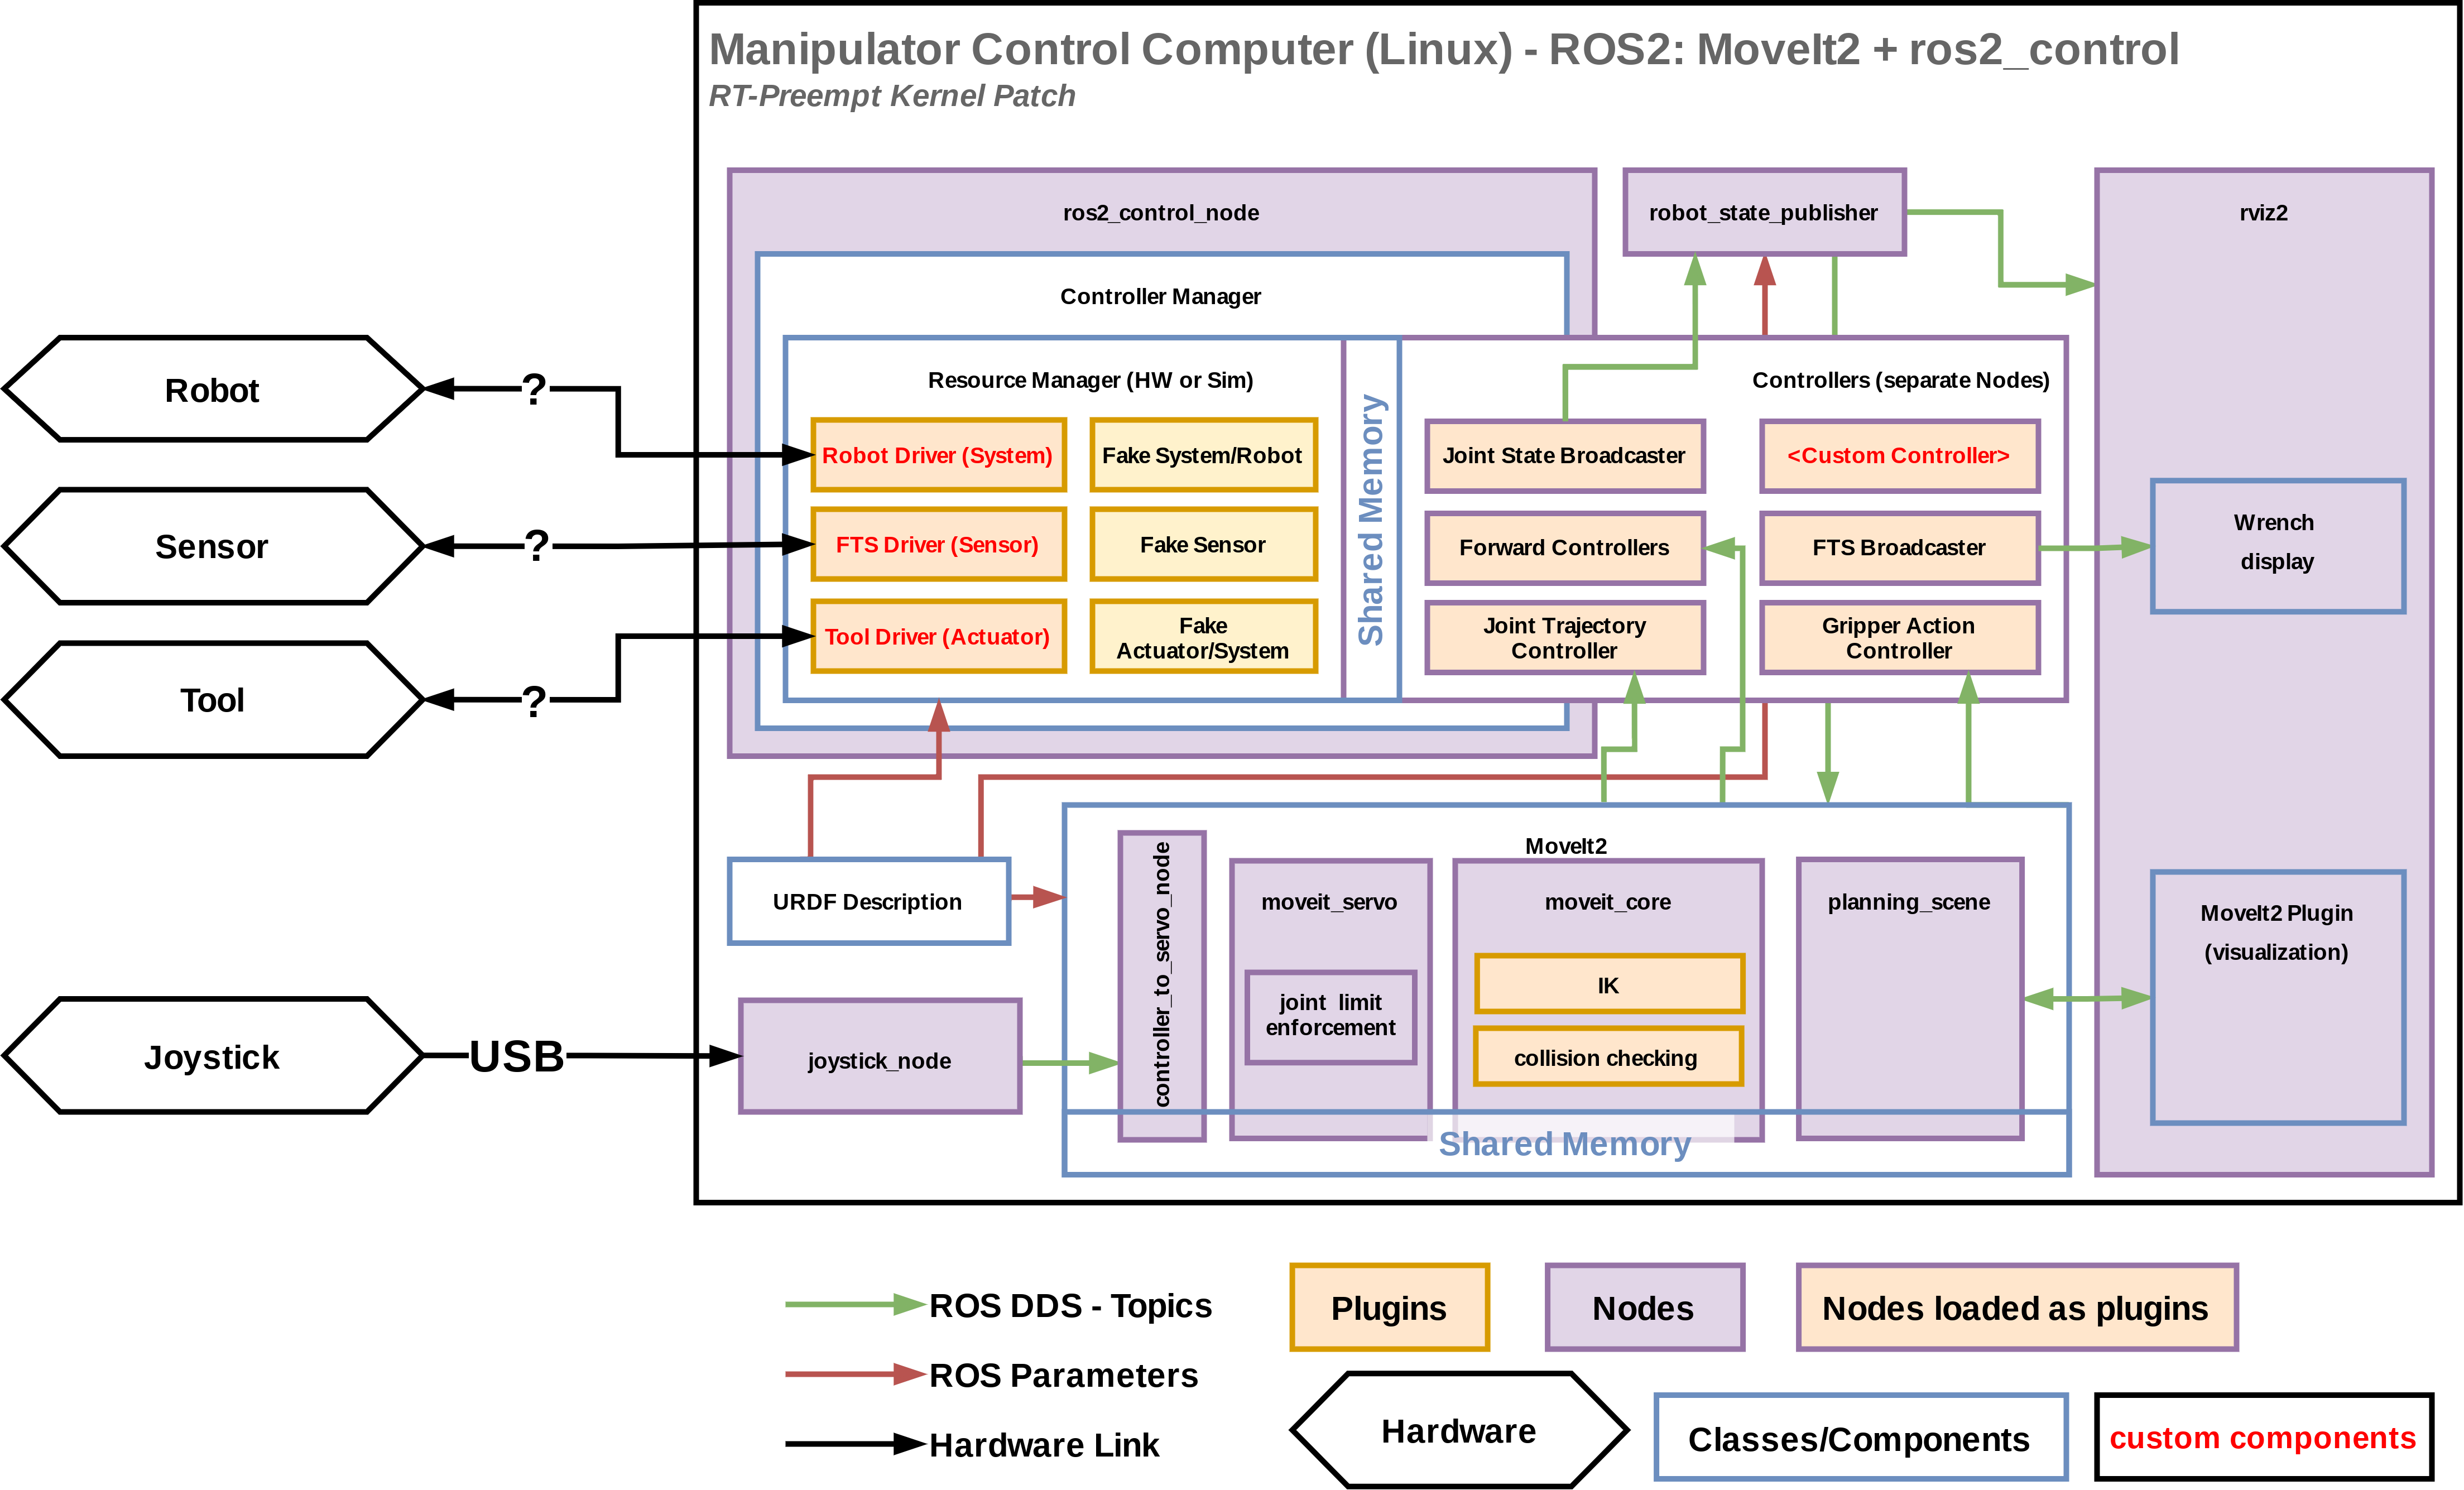
Resources — ROS2_Control: Jazzy Oct 2025 documentation

Getting Started — ROS2_Control: Jazzy Feb 2026 documentation

Resources — ROS2_Control: Jazzy Oct 2025 documentation

ROS2 Jazzy ros2_control controllers implementation and simulation in ...
Advertisement Space (336x280)

Resources — ROS2_Control: Jazzy Oct 2025 documentation

Disciplined ROS2 Jazzy C++ Control of Mobile Robot Tutorial - Embed ...
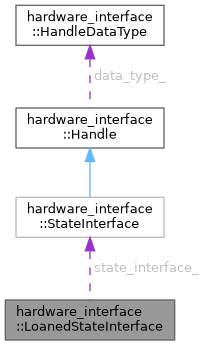
ros2_control - jazzy: hardware_interface::LoanedStateInterface Class ...

Resources — ROS2_Control: Jazzy Oct 2025 documentation
ros2_control - jazzy: ros2_control/hardware_interface Directory Reference

Resources — ROS2_Control: Jazzy Oct 2025 documentation

ROS2 Jazzy Tutorial: ros2_control library tutorial - Build and run ros2 ...
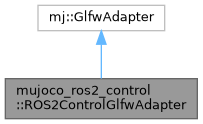
ros2_control - jazzy: mujoco_ros2_control::ROS2ControlGlfwAdapter Class ...
ros2_control - jazzy: ros2_control/ros2_control Directory Reference
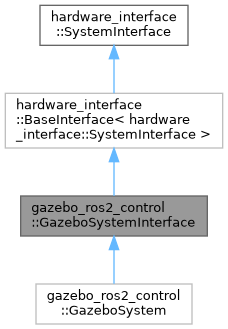
ros2_control - foxy: gazebo_ros2_control::GazeboSystemInterface Class ...
Advertisement Space (336x280)

Resources — ROS2_Control: Jazzy Oct 2025 documentation

Python Code and Manual for Using and Interfacing Camera in ROS2 Jazzy ...

ROS2 Jazzy C++: Set, Control, Publish, and Simulate Robot Joint States ...
How To Install ROS2 Jazzy Base On Raspberry Pi 4 or 5 (FULL INSTALL ...
ROS2 Jazzy Tutorial on tf2 transform library – tf2 Broadcaster in C++ ...
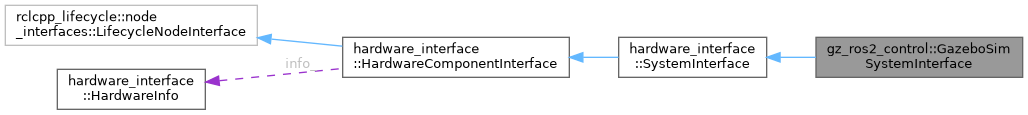
ros2_control - jazzy: gz_ros2_control::GazeboSimSystemInterface Class ...