Rtabmap Posegraph2h File Reference

rtabmap: posegraph2.h File Reference
rtabmap: graph_drawable.h File Reference
rtabmap: GeodeticCoords.h File Reference
rtabmap: segment.h File Reference
rtabmap: transformation3.h File Reference
rtabmap: Image.h File Reference
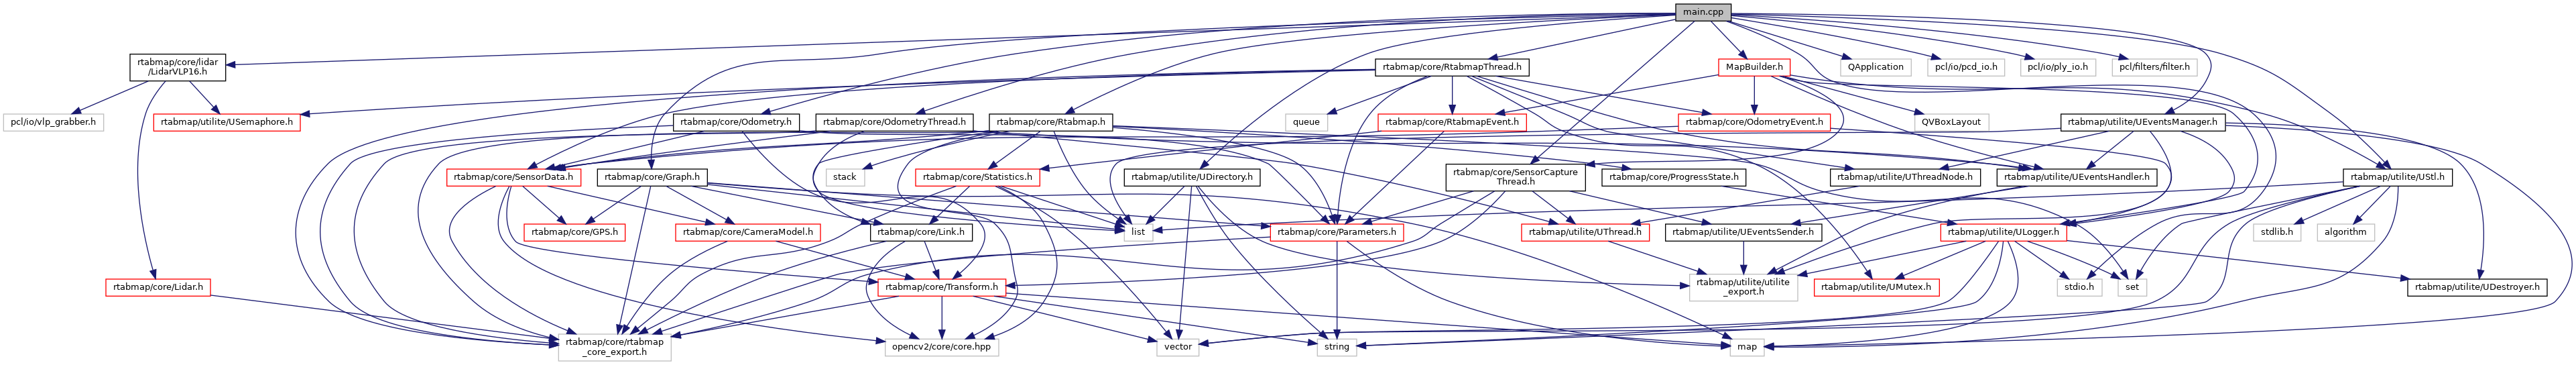
rtabmap: main.cpp File Reference
rtabmap: RegistrationIcp.h File Reference
rtabmap: setup.hpp File Reference
rtabmap: Rtabmap.cpp File Reference
rtabmap: dist.h File Reference
rtabmap: graph_drawable.cpp File Reference
rtabmap: Parameters.h File Reference
rtabmap: CameraStereoZedOC.h File Reference
rtabmap: any.h File Reference
rtabmap: nn_index.h File Reference
Run RTABMAP on multiple rosbags simultaneosly ยท Issue #862 ยท introlab ...
6.2.7 Real-time Mapping with Rtabmap and Navigation ยท GitBook
๐Ÿ‘จโ€๐Ÿ‘ฆ ๐Ÿ’‚๐Ÿผ ๐Ÿ‘จ๐Ÿพโ€๐ŸŽจ Localization and navigation in ROS using rtabmap ๐Ÿ‘ฉ๐Ÿฟโ€๐Ÿ’ผ ๐Ÿ›ฃ๏ธ ๐Ÿ‘ฉ๐Ÿพโ€๐Ÿ”ง
ROS: Simultaneous Mapping and Localization with RTABmap
๐Ÿ‘จโ€๐Ÿ‘ฆ ๐Ÿ’‚๐Ÿผ ๐Ÿ‘จ๐Ÿพโ€๐ŸŽจ Localization and navigation in ROS using rtabmap ๐Ÿ‘ฉ๐Ÿฟโ€๐Ÿ’ผ ๐Ÿ›ฃ๏ธ ๐Ÿ‘ฉ๐Ÿพโ€๐Ÿ”ง
slam - Interfacing Rtabmap and Robot_Localization - Robotics Stack Exchange
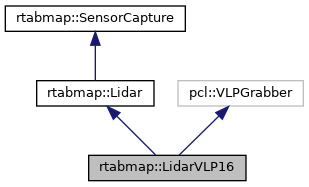
rtabmap: rtabmap::LidarVLP16 Class Reference
rtabmap: rtabmap::GridMap Class Reference
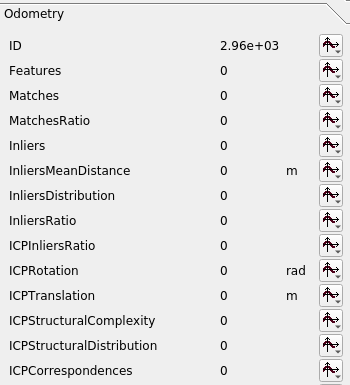
Parameters to use for RTABMap with ORB SLAM ยท Issue #910 ยท introlab ...
rtabmap: rtabmap::PdfPlotItem Class Reference
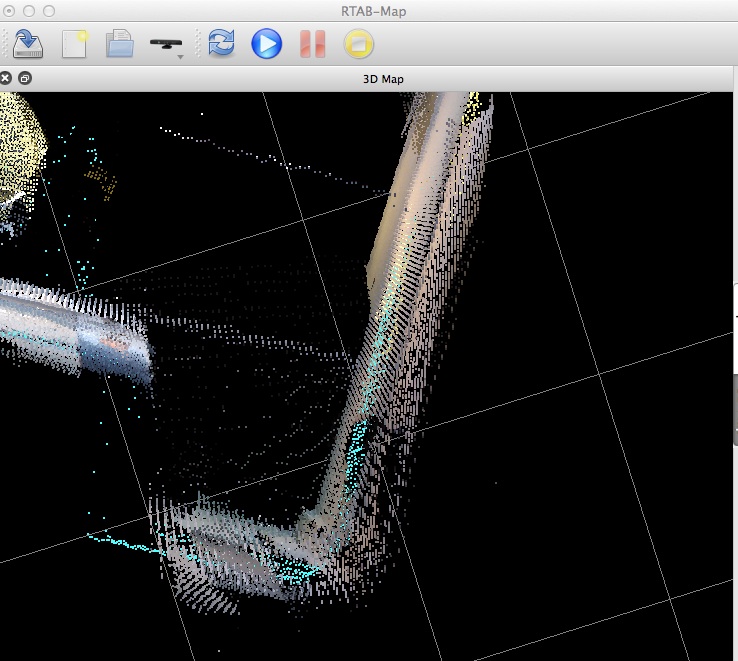
Official RTAB-Map Forum - Rtabmap mapping with two cameras | Page 4
๐Ÿ‘จโ€๐Ÿ‘ฆ ๐Ÿ’‚๐Ÿผ ๐Ÿ‘จ๐Ÿพโ€๐ŸŽจ Localization and navigation in ROS using rtabmap ๐Ÿ‘ฉ๐Ÿฟโ€๐Ÿ’ผ ๐Ÿ›ฃ๏ธ ๐Ÿ‘ฉ๐Ÿพโ€๐Ÿ”ง
Official RTAB-Map Forum - Extract Odometry Pose from Rtabmap database ...
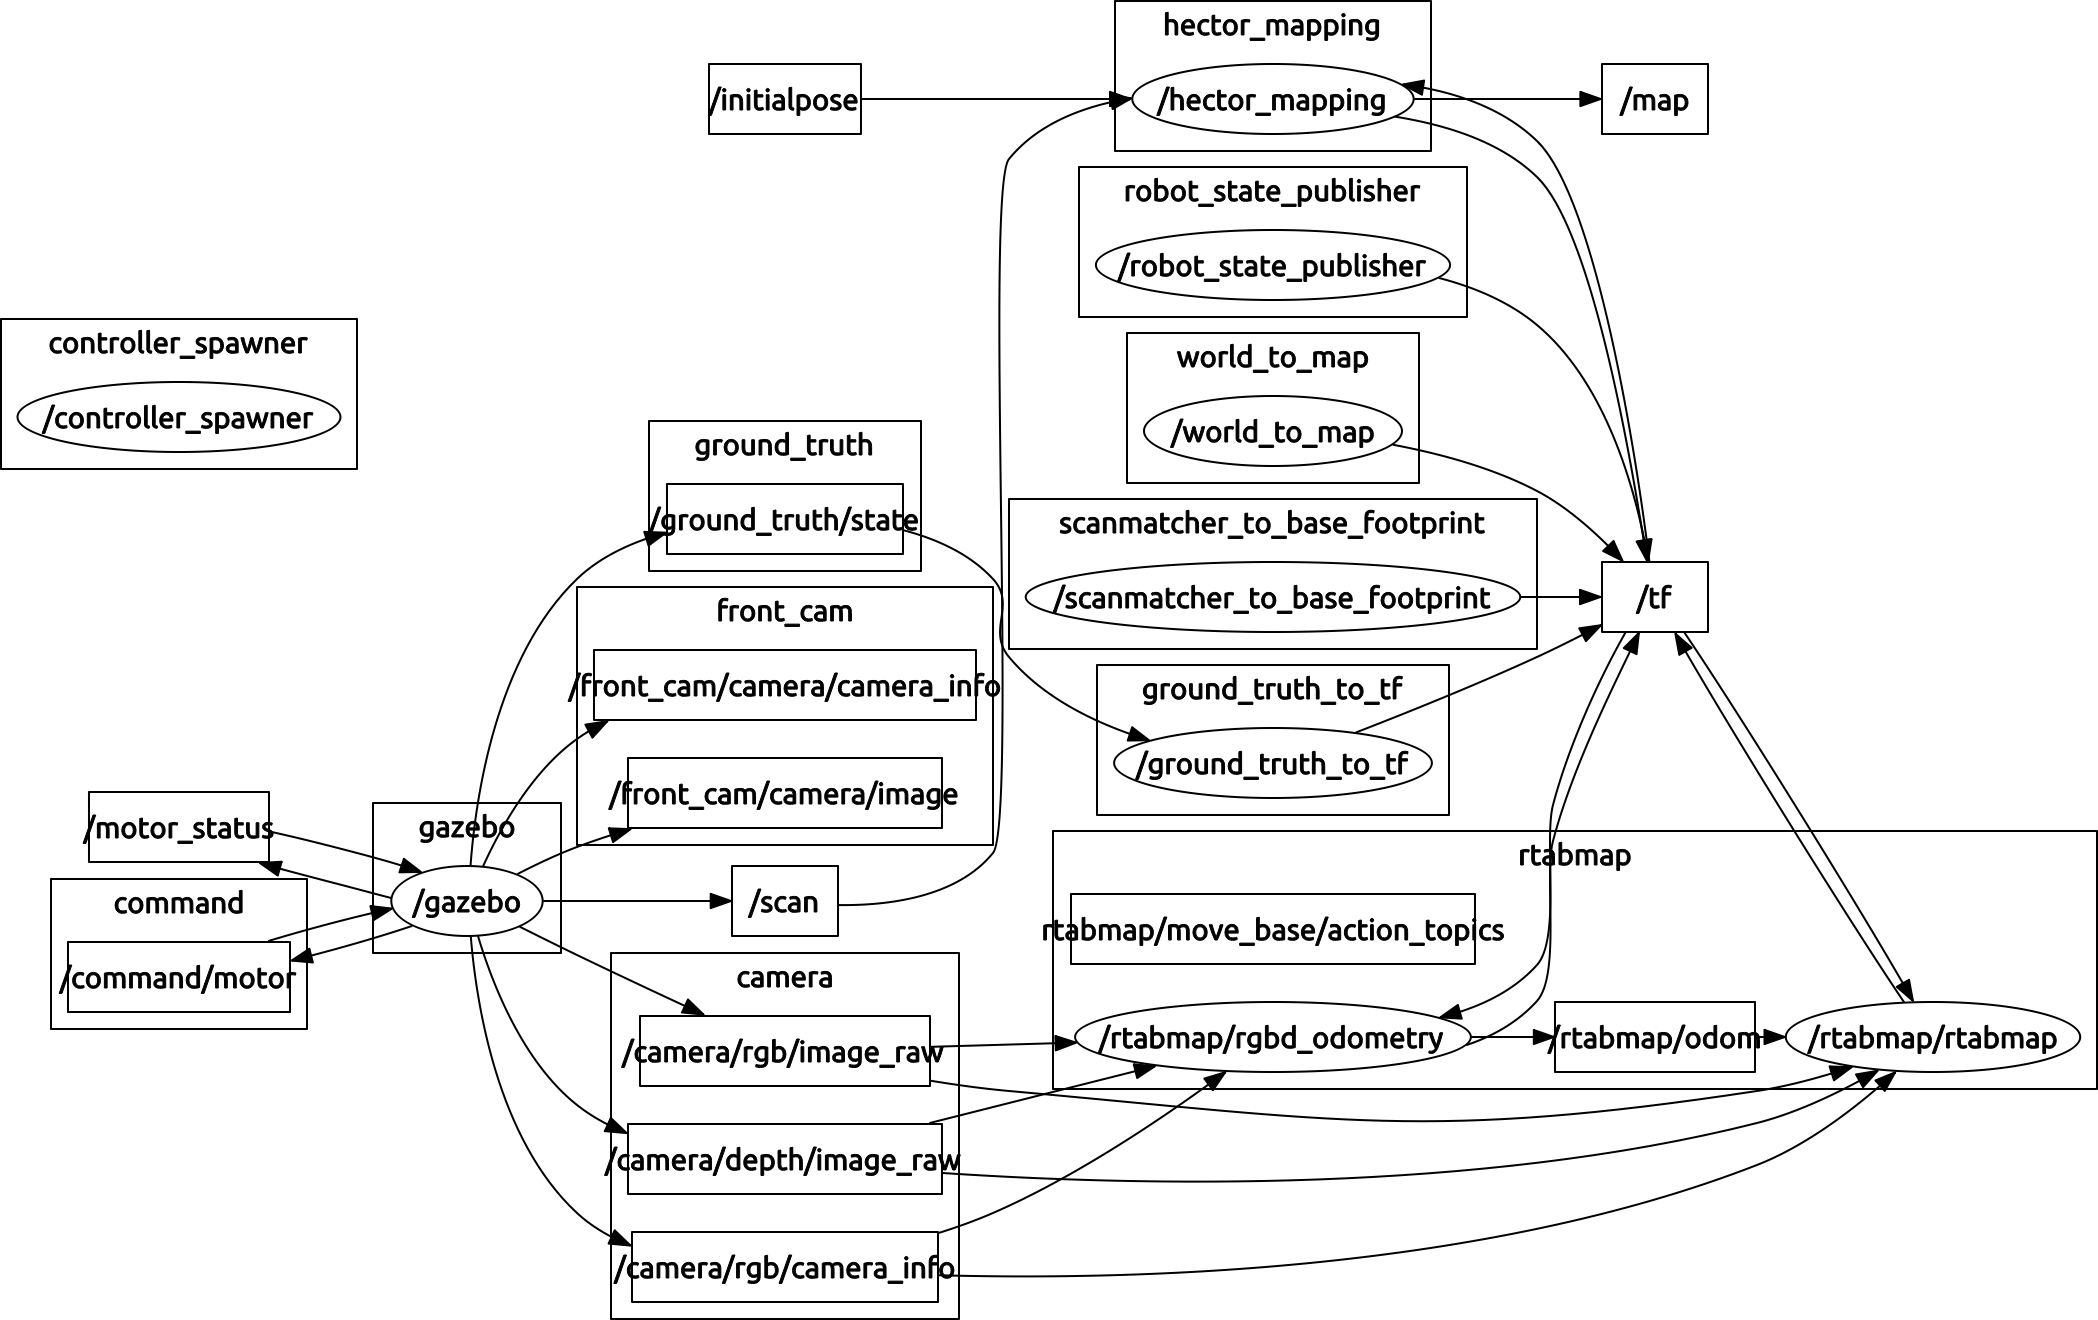
Official RTAB-Map Forum - rtabmap with octomap and hector slam
GitHub - gjcliff/RTABMap_Semantic_Mapping: Process RTABMap database ...
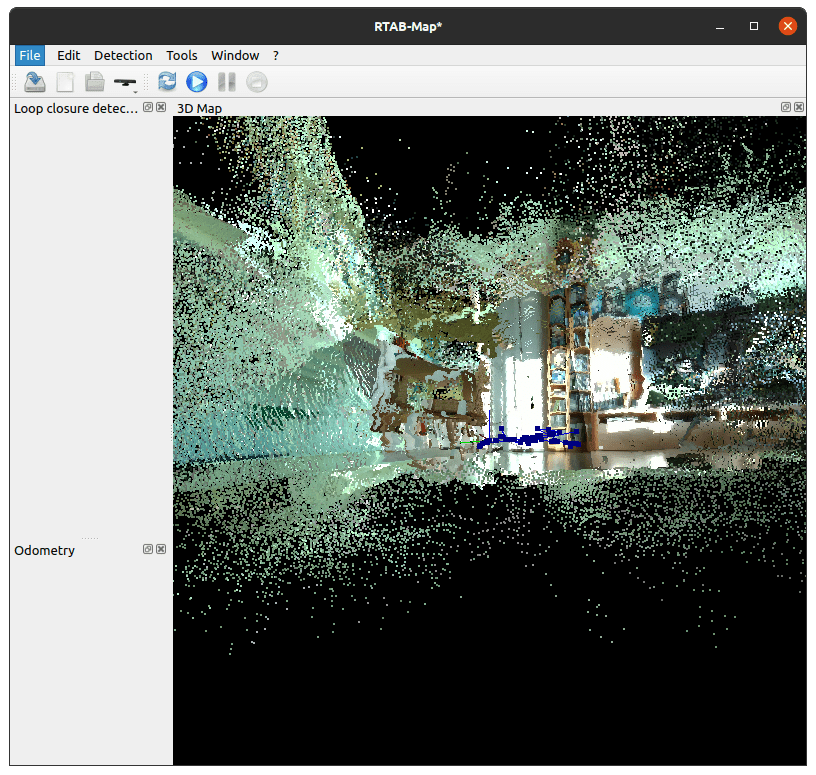
ROS: Simultaneous Mapping and Localization with RTABmap
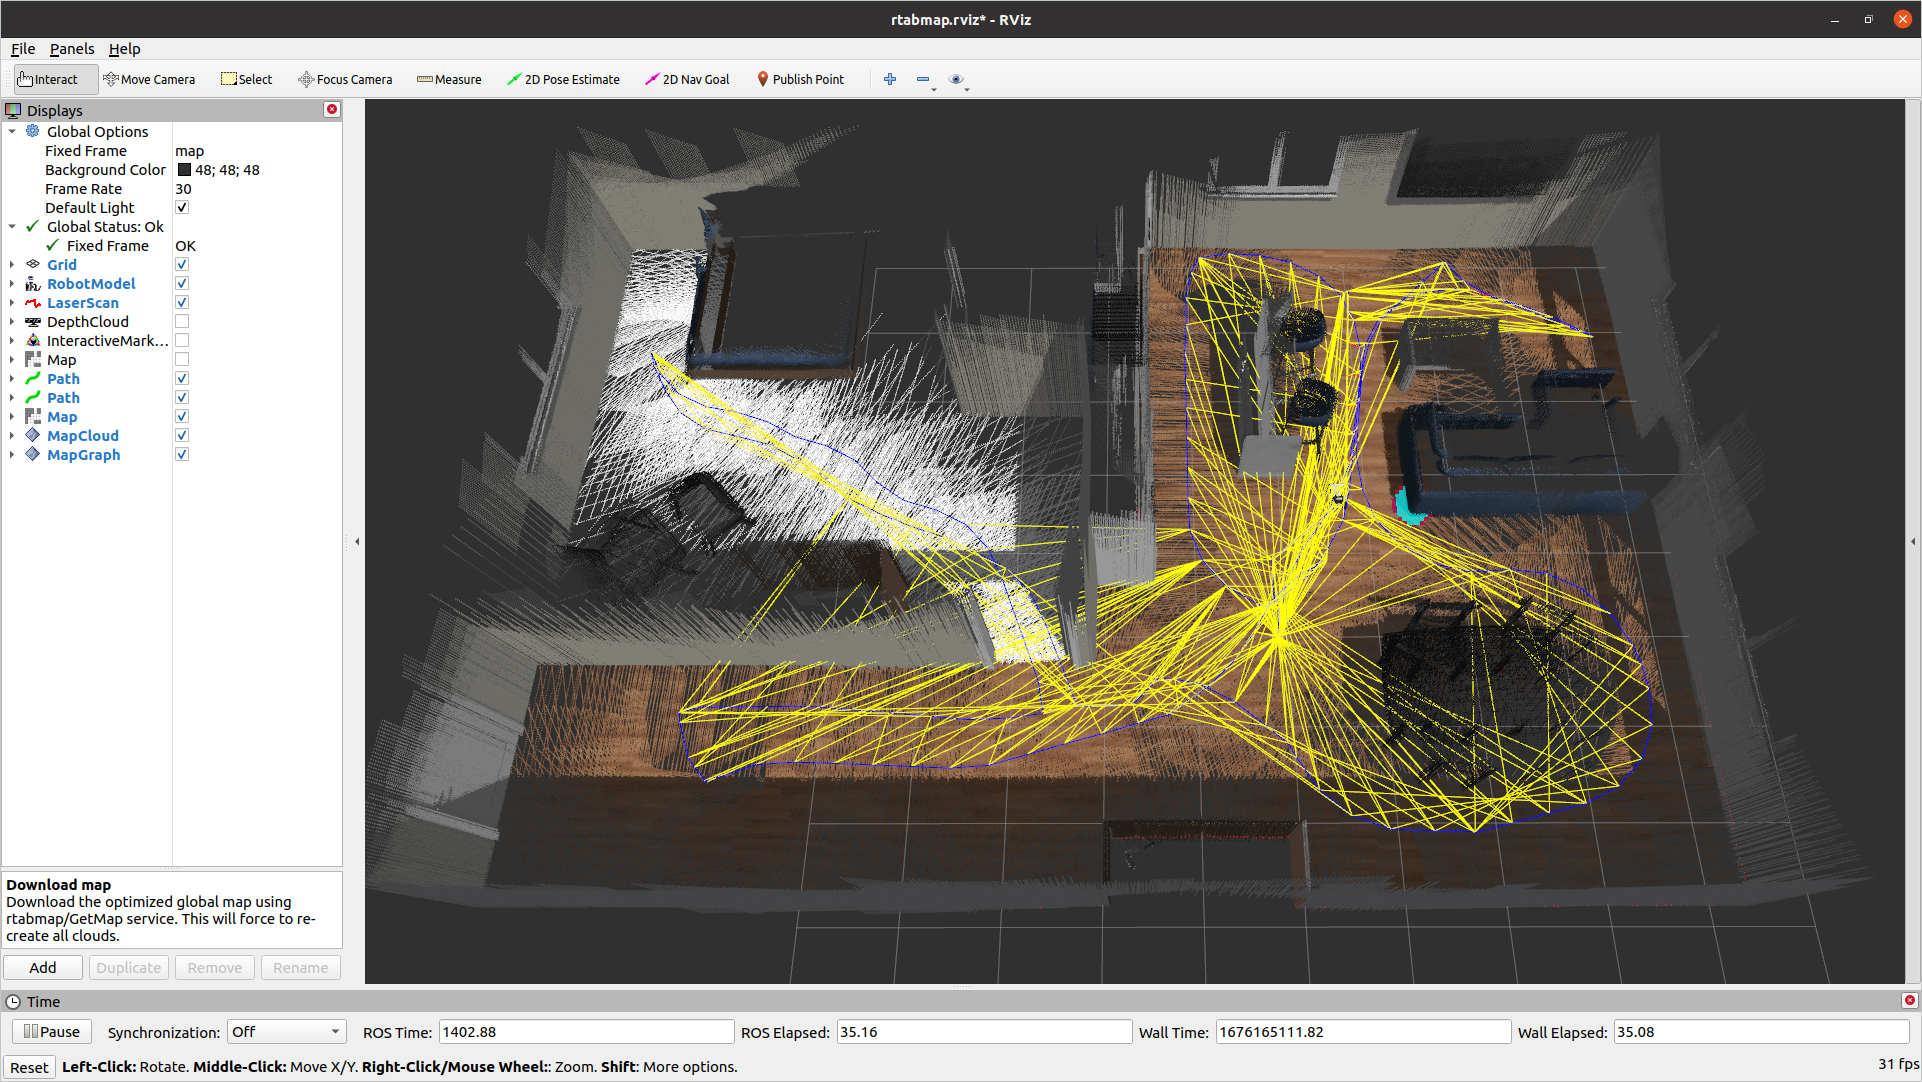
RTABMap โ€” limo-agx documentation

Loading image details...

Source
Dimensions